SO-101
A low-cost 3D-printed robot arm built as a leader and follower pair, for teleoperation and for teaching tasks by demonstration with LeRobot.
Robot armBeginnerBuildability 98/100 · Ready to build
- Works with AI
€226.30
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 2 · Ready to build first, then by buildability
A low-cost 3D-printed robot arm built as a leader and follower pair, for teleoperation and for teaching tasks by demonstration with LeRobot.
A low-cost, human-arm-scale open-source robotic arm compatible with Lerobot, based on the SO-100 arm, with a 600mm span and up to 500g payload.
A cost-effective, ROS2-compatible 5-DoF robotic manipulator with a leader-follower teleoperation setup, designed to lower the barrier to entry for Embodied AI.
An open-source leader and follower robot arm kit with 5 degrees of freedom plus a gripper, for teleoperation and imitation learning.
A 3D-printed collaborative robot arm for research, education and rapid prototyping in physical AI.
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
An open-source robotic arm controlled by an ESP32-C3 via a PCA9685 servo driver and an Xbox-compatible gamepad.
A low-cost, universal leader-follower teleoperation system for commercial robot arms with plug-and-play hardware configurations.
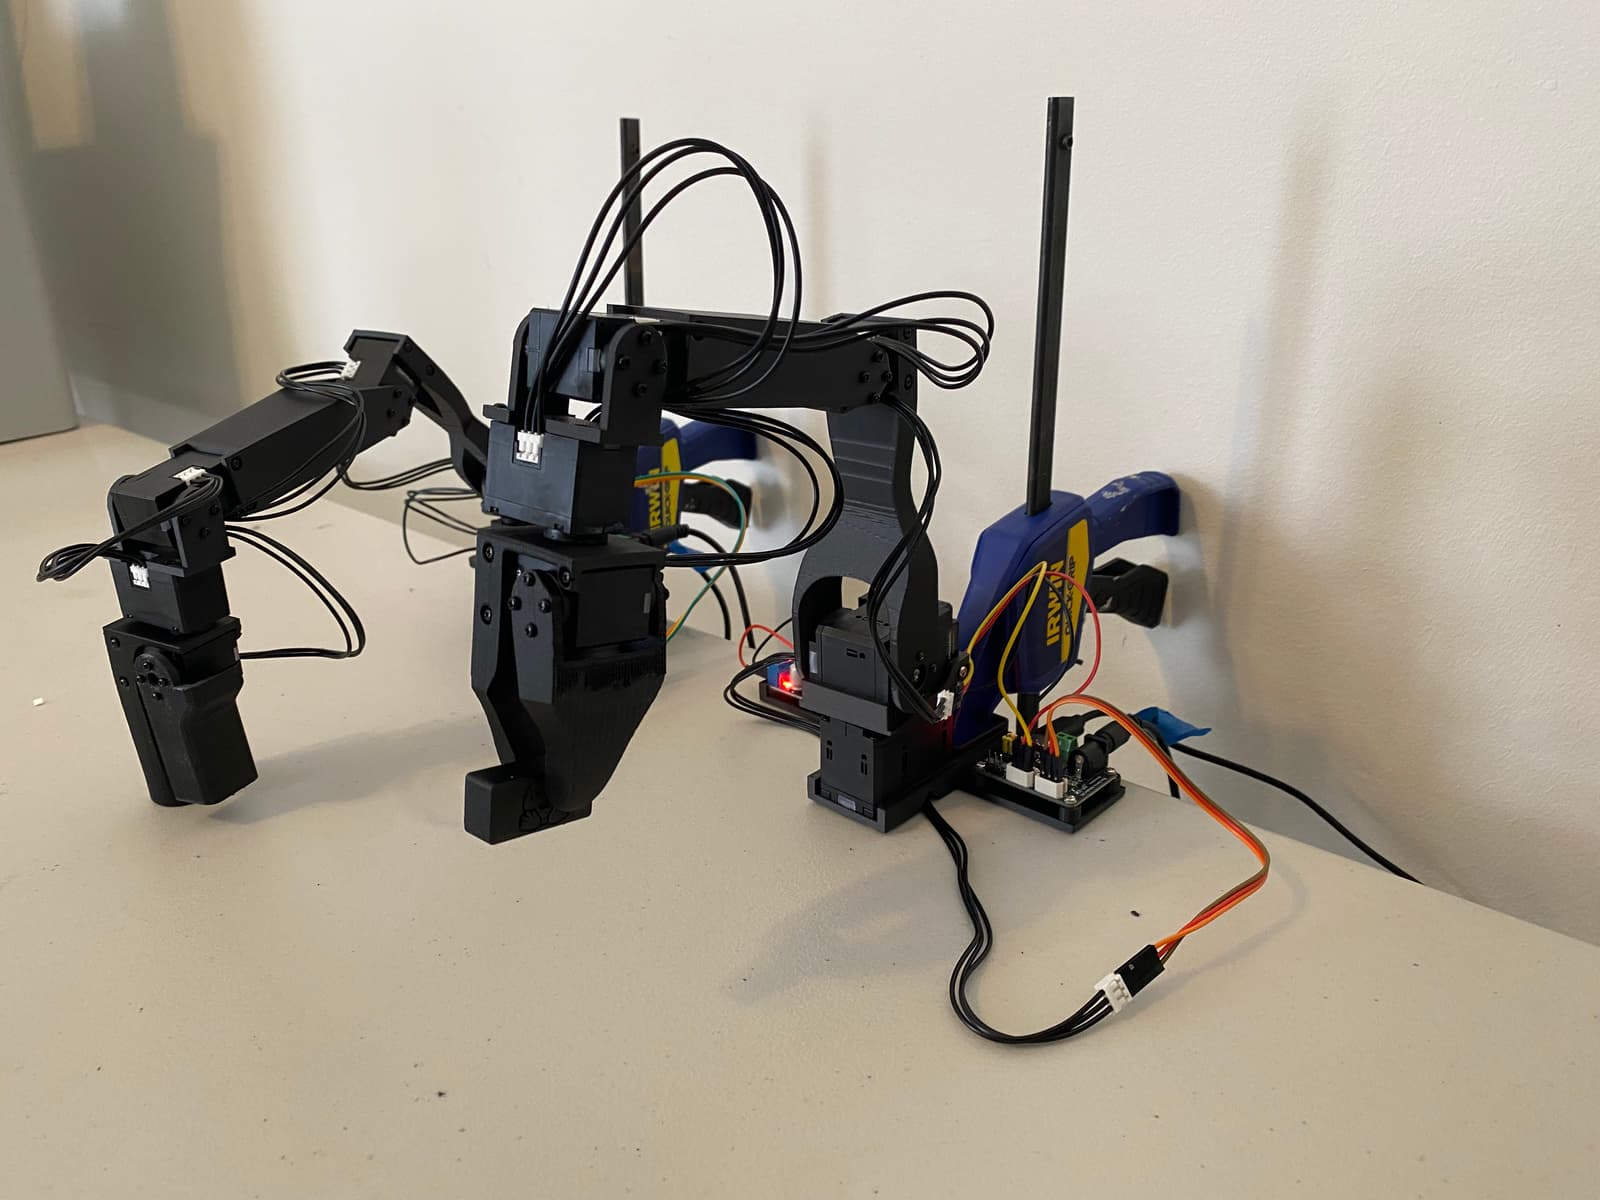
An improved version of Alexander Koch's low-cost robot arm, a leader and follower pair with Dynamixel servos for LeRobot. The price includes both arms.
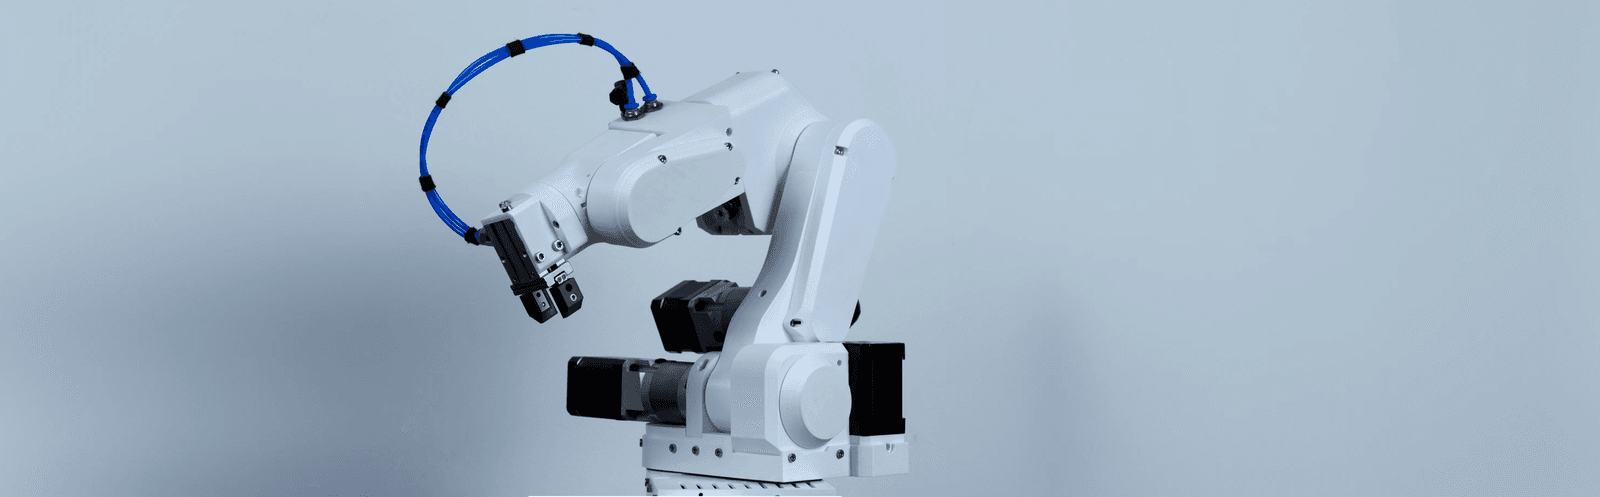
A 6-axis 3D-printed desktop robot arm with stepper motors, gearboxes and belts, modelled on industrial arms, with its own control firmware.

A 7-DOF personal robotic arm with ROS-based simulation and control.
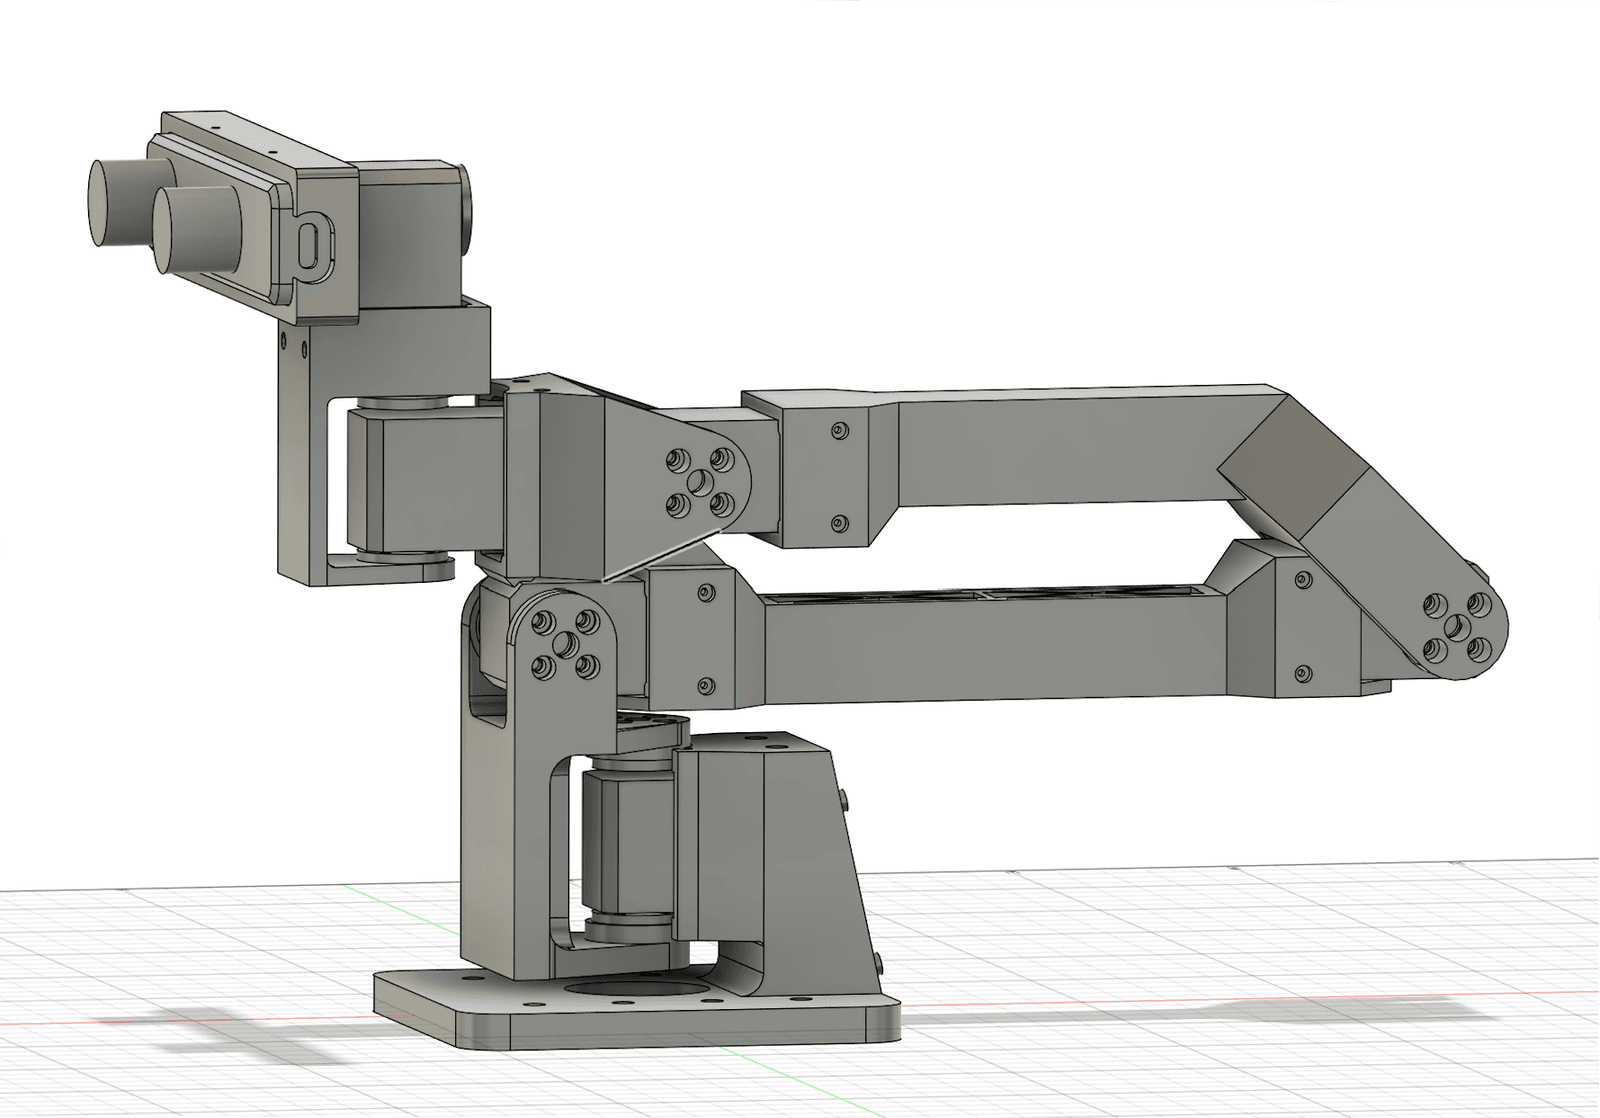
A 6-DOF camera arm with a ZED Mini stereo camera that streams video to a WebXR VR headset and follows head tracking for teleoperation.
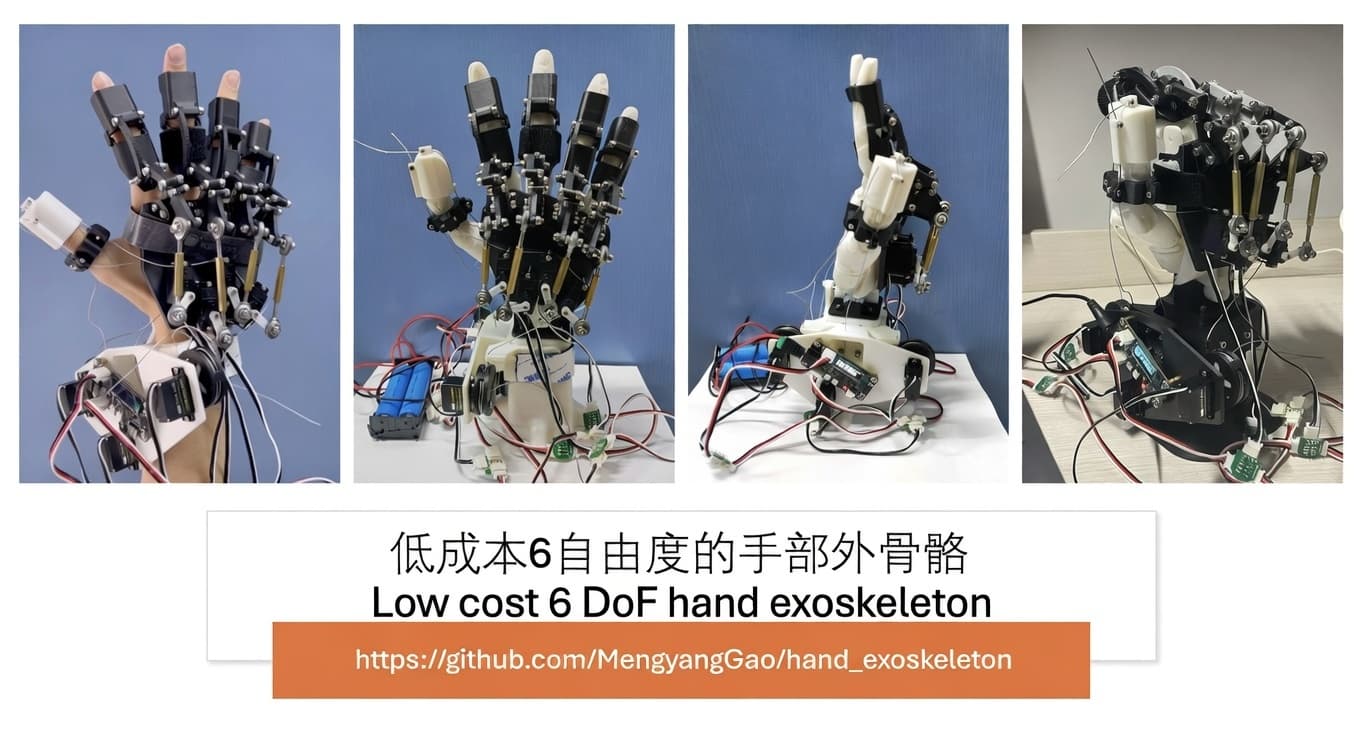
A low-cost 6DoF hand exoskeleton using linkage and tendon mechanisms, controlled by an ESP32 and seven SC09 bus servos.
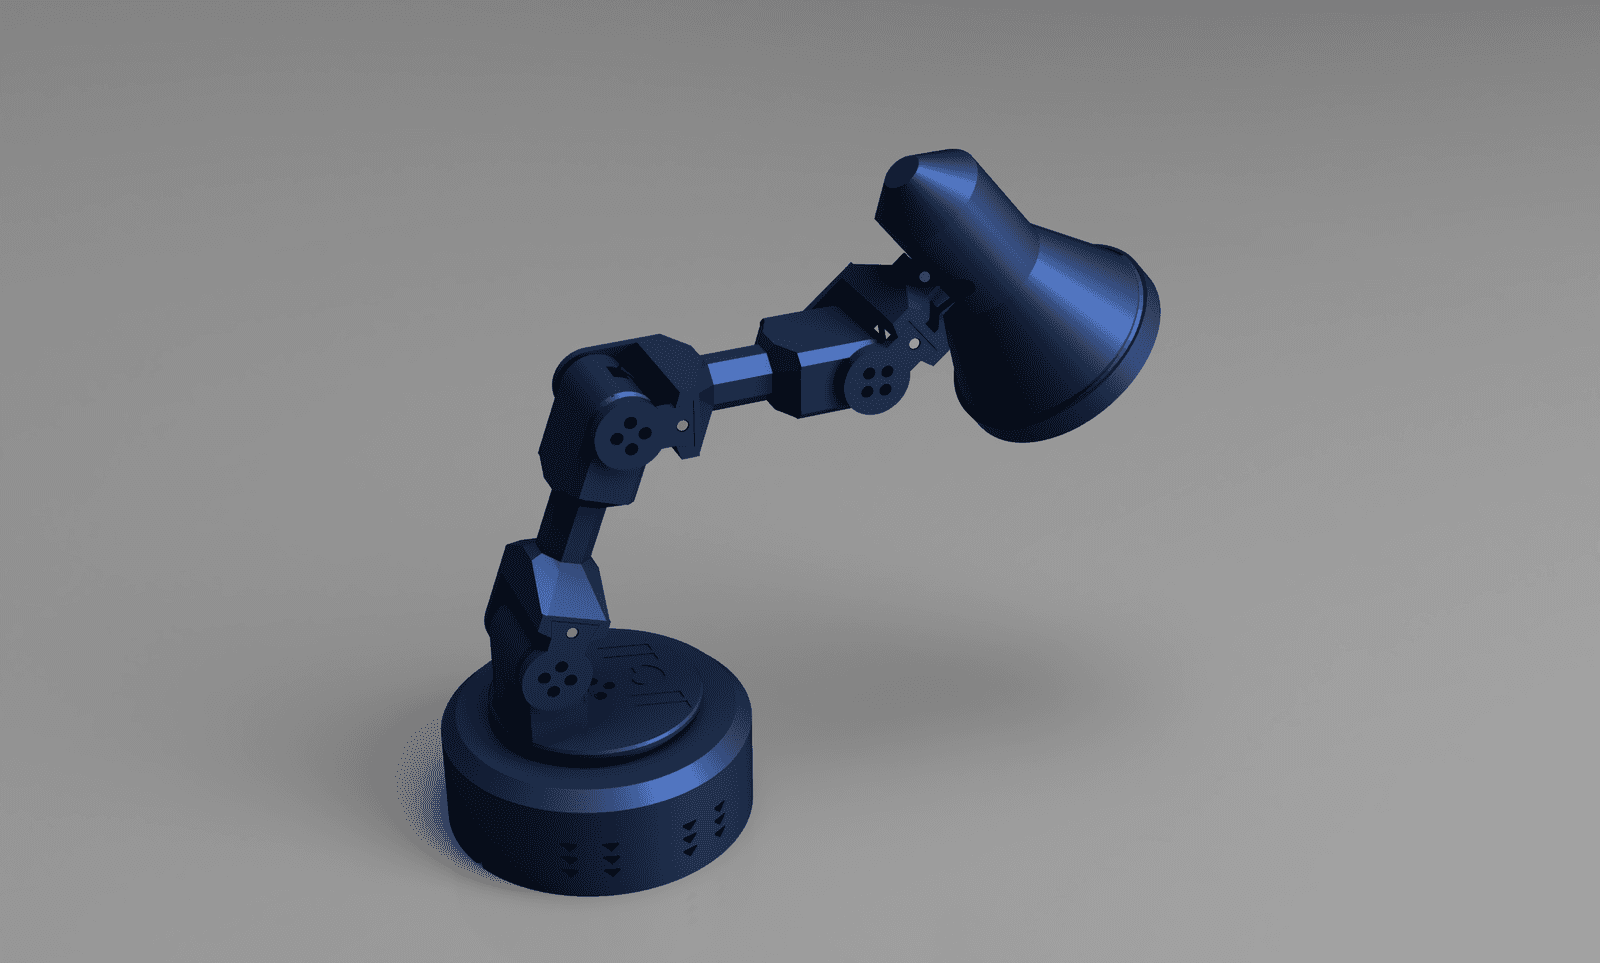
NormaCore is a unified open-source toolkit and platform for developing and operating physical systems, including a 7+1 DoF 3D-printed robotic arm (ElRobot) and a desk lamp.
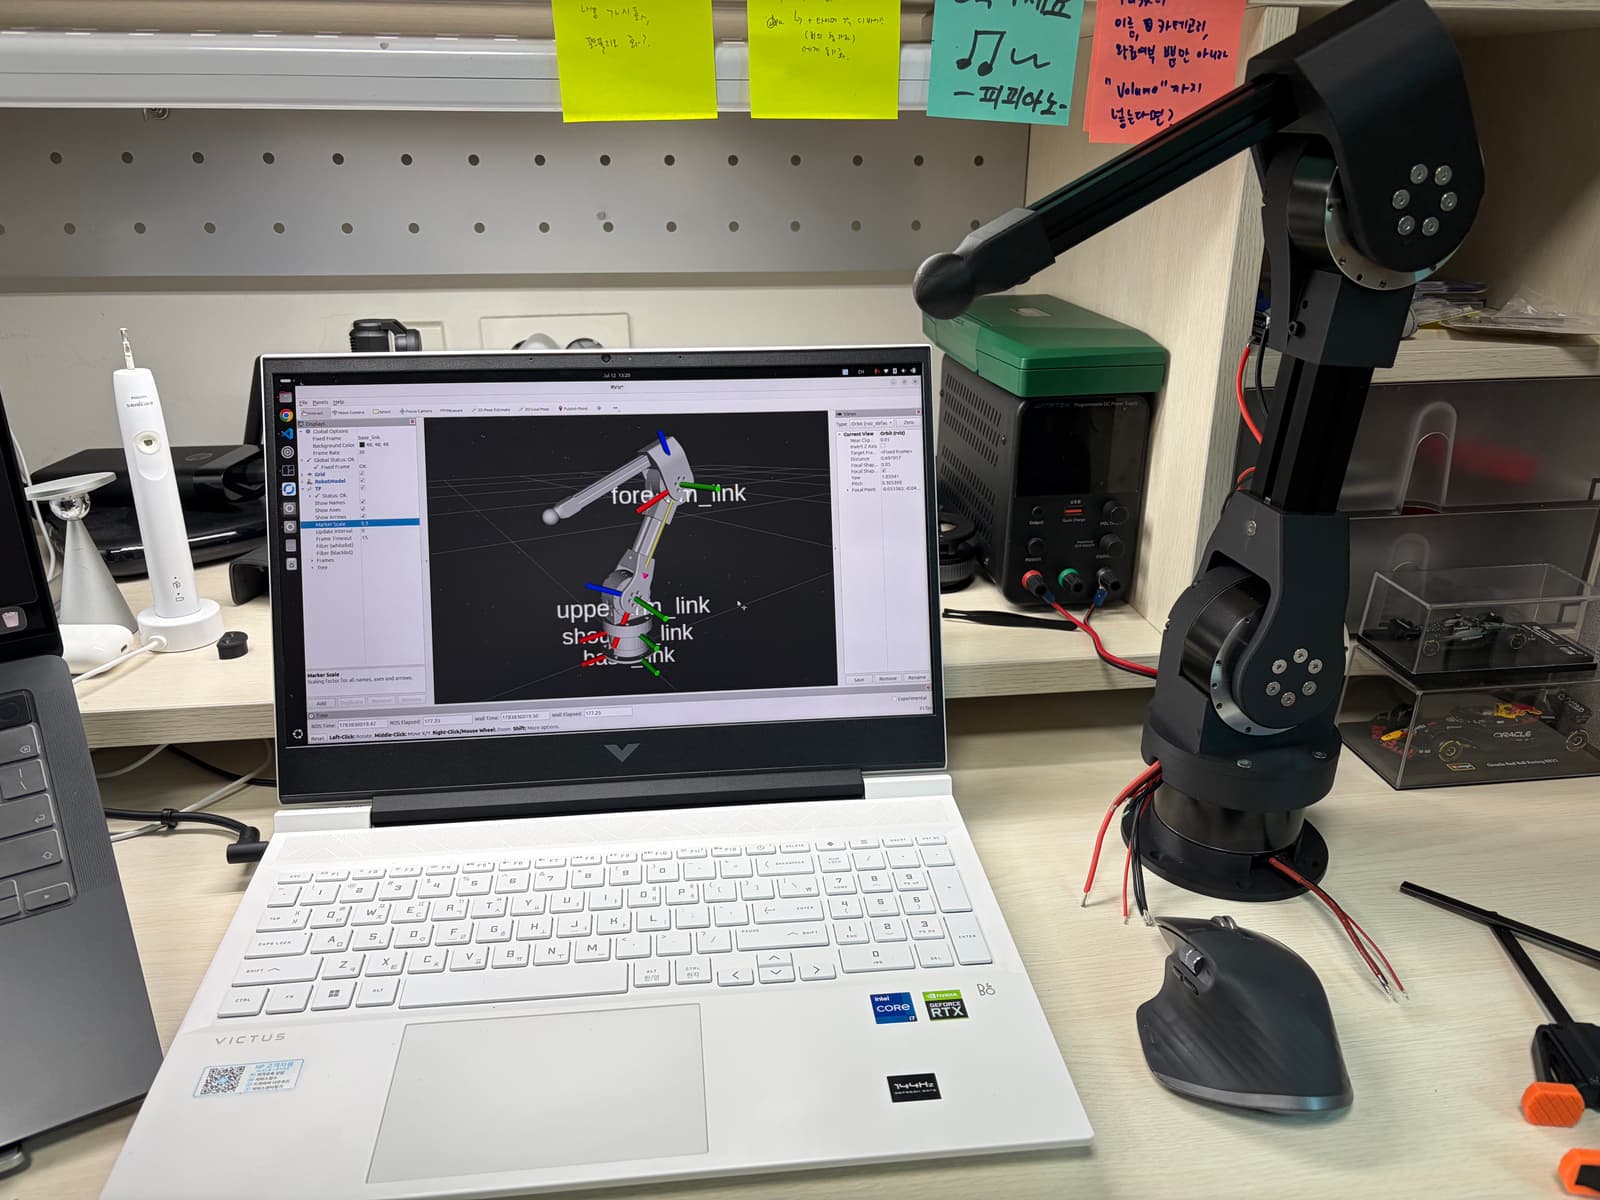
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
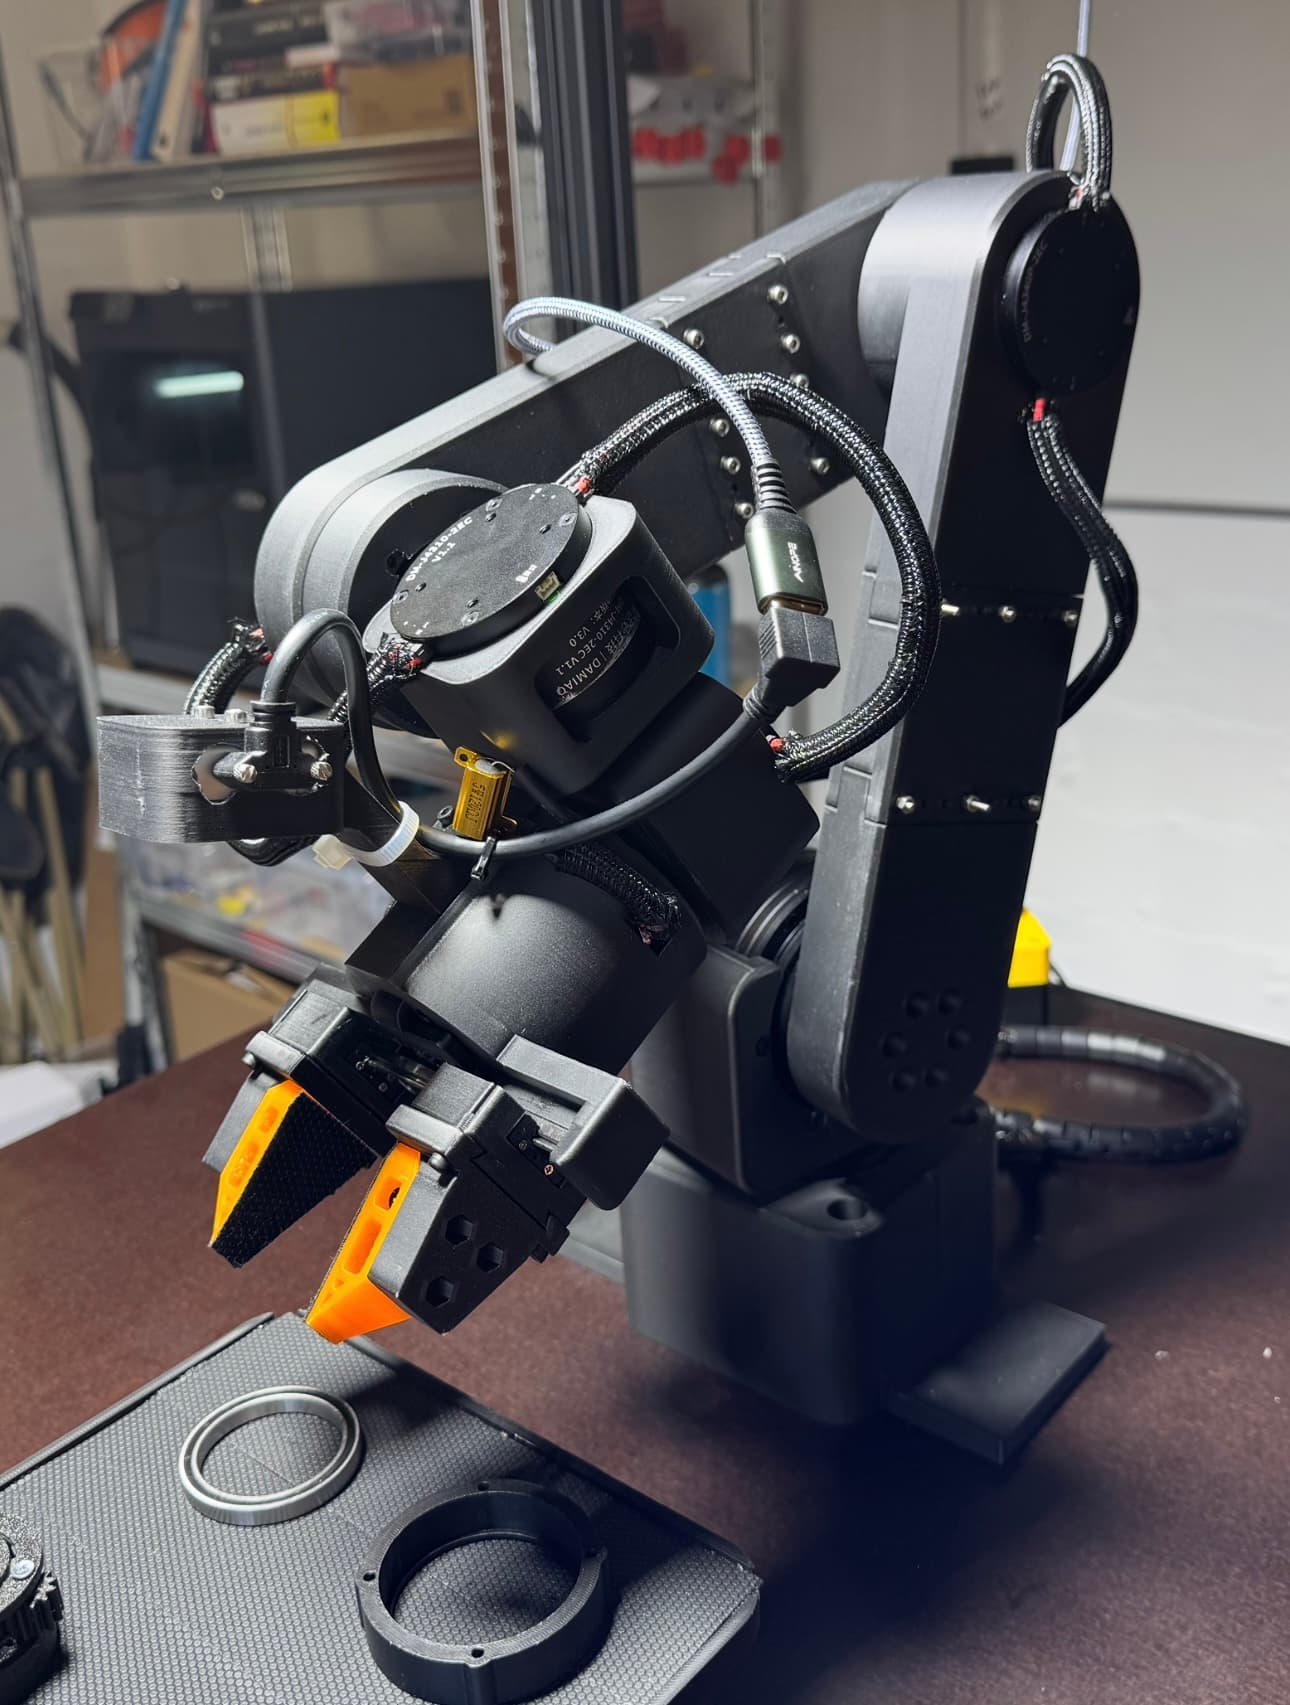
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.
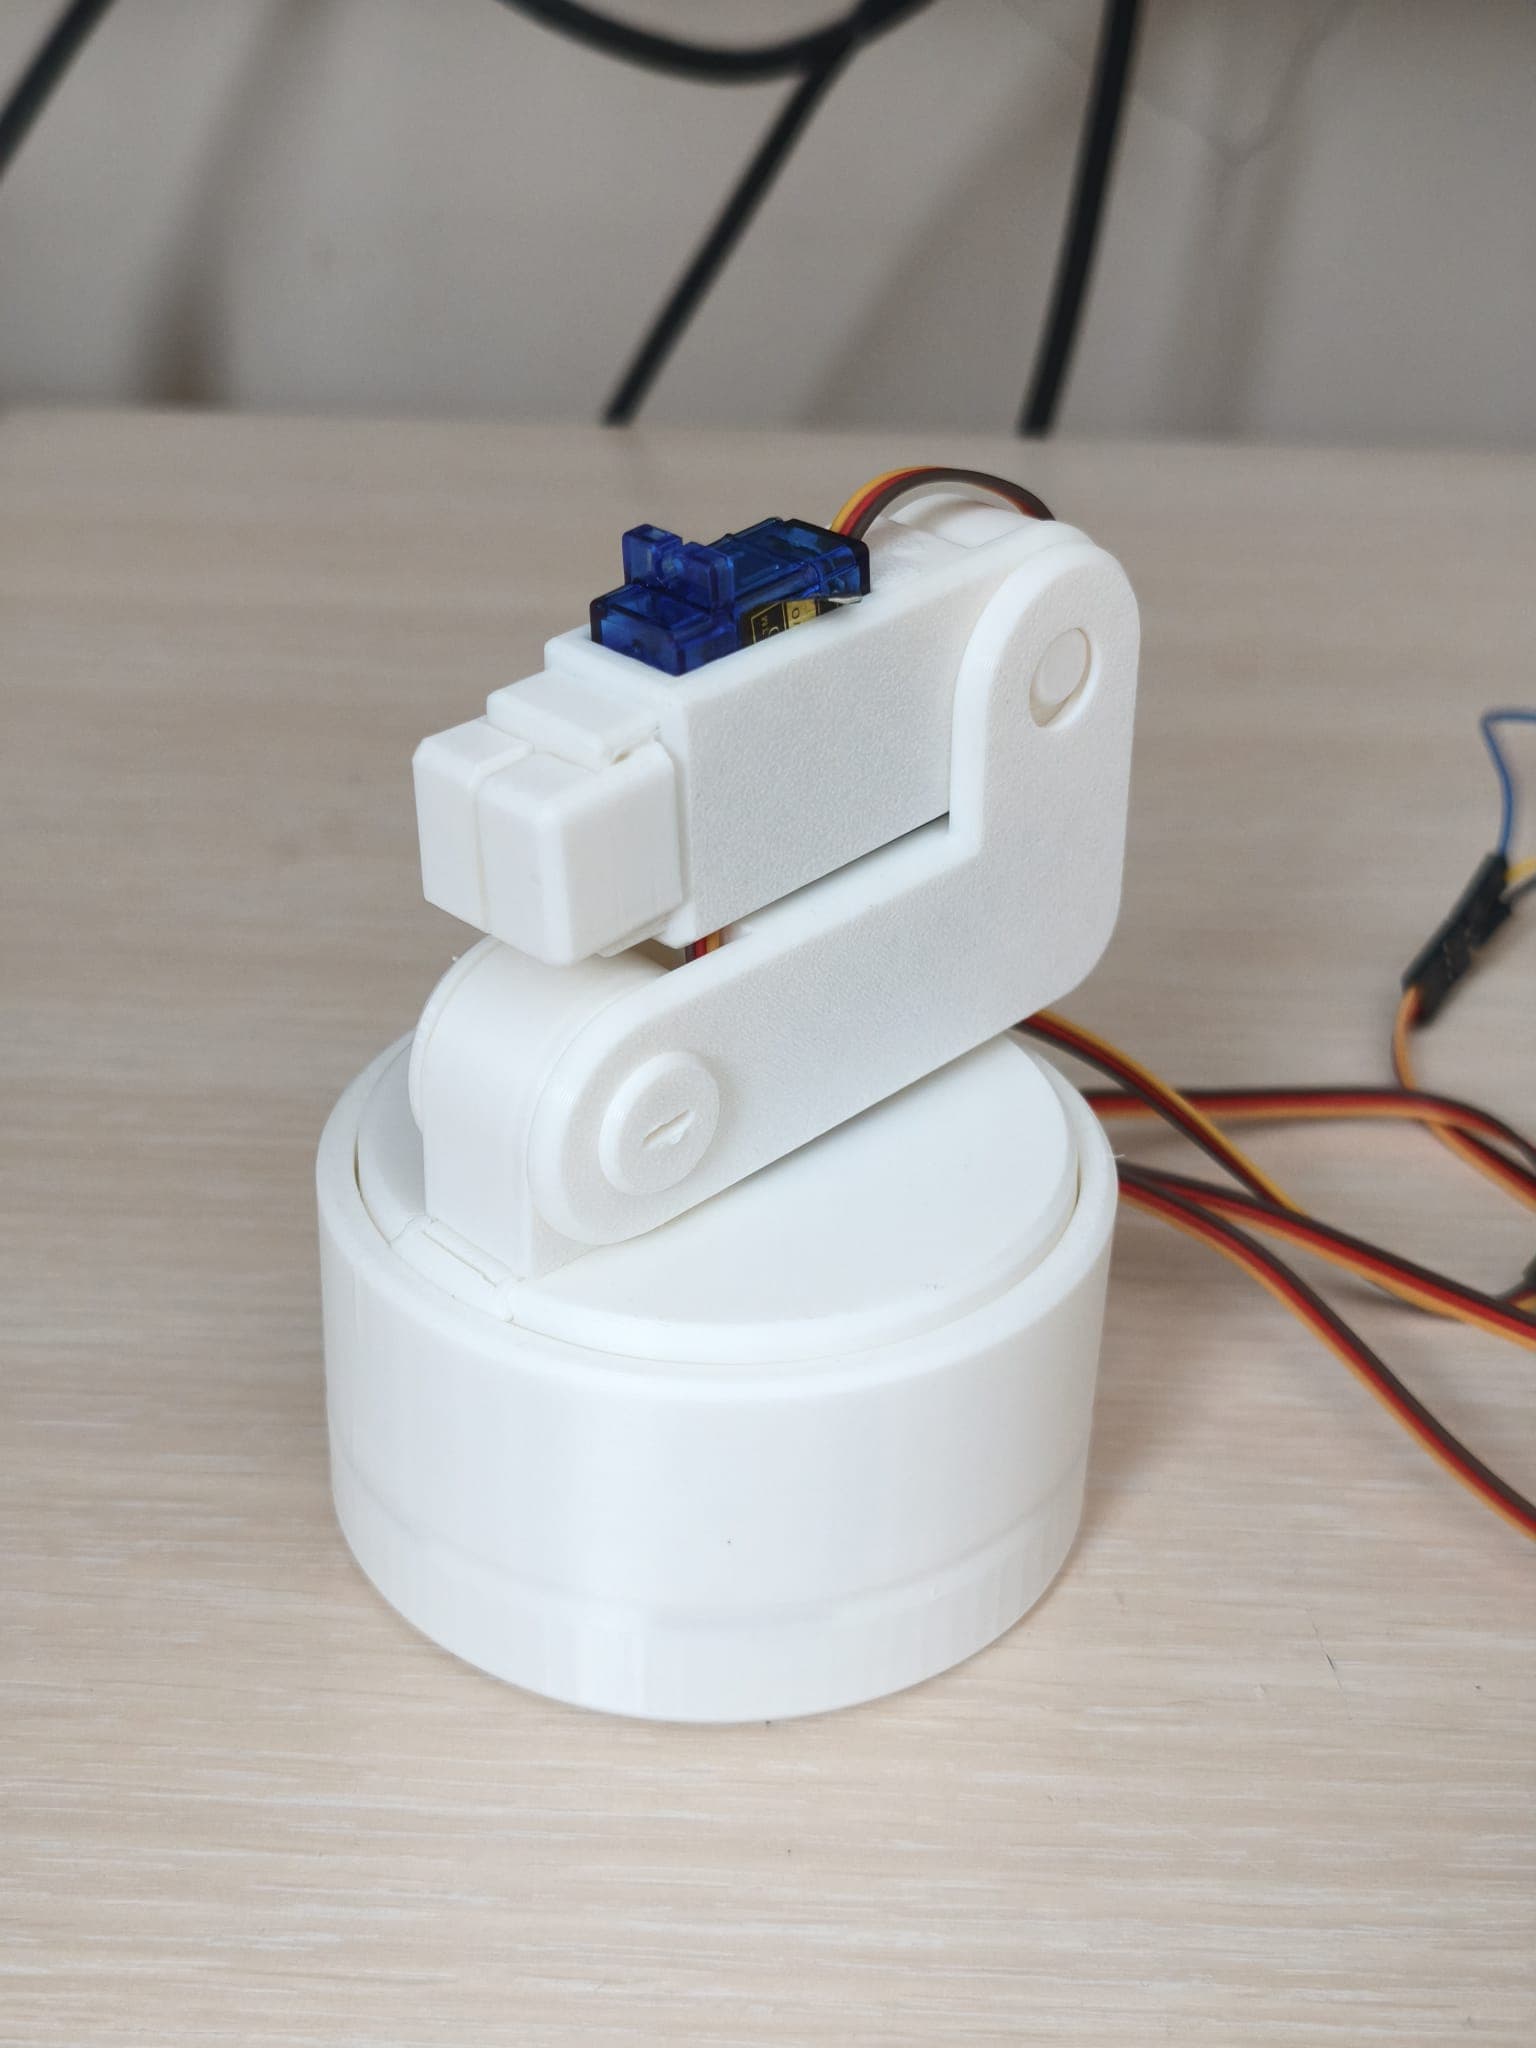
A compact 3D-printed desktop robot arm with a rotating base and gripper, controlled through a browser joystick over its own Wi-Fi access point.

A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.

A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
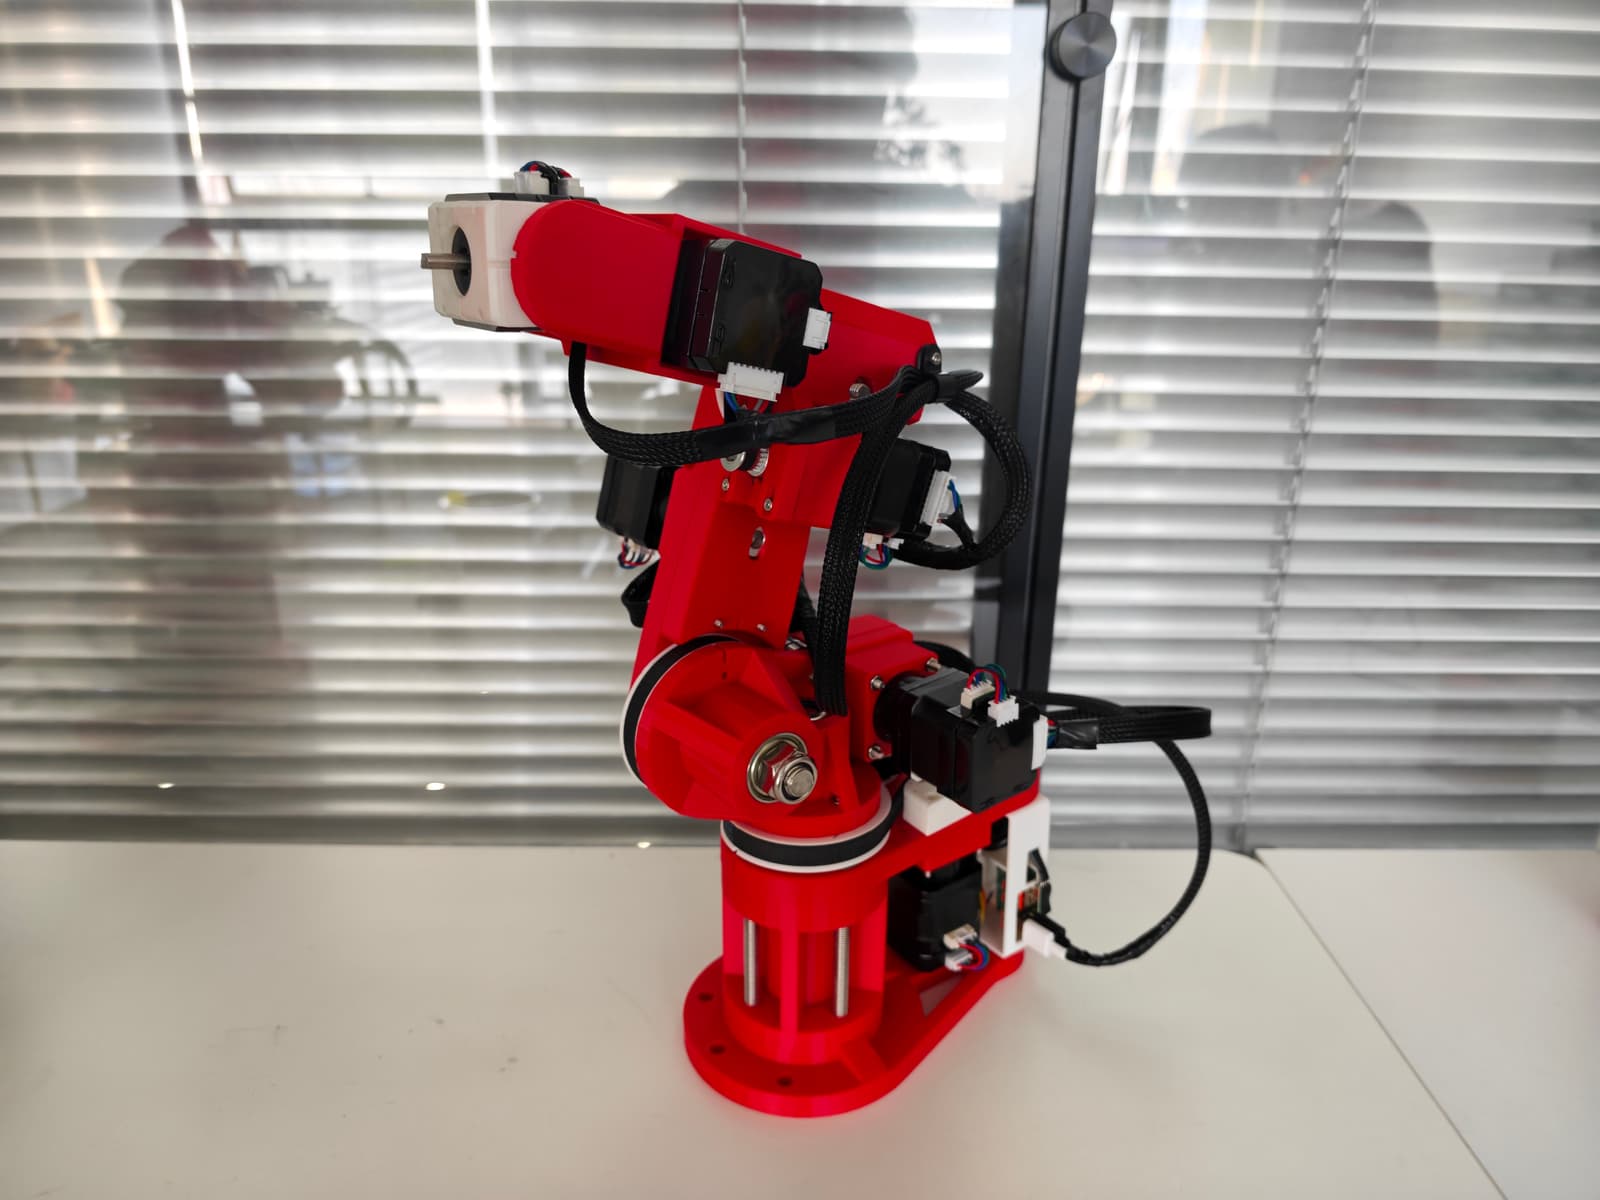
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
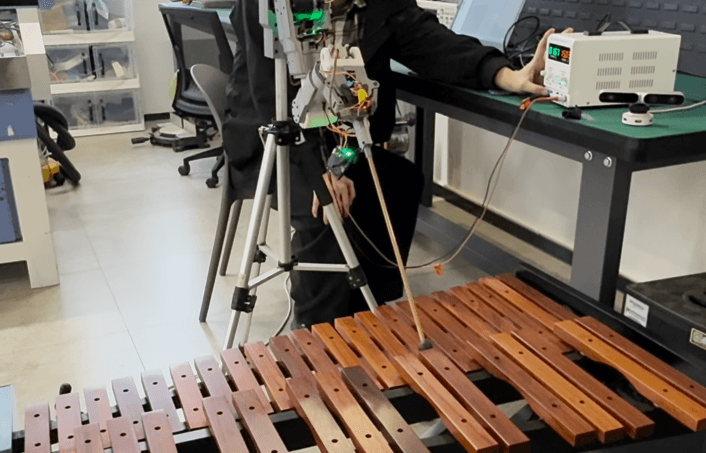
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
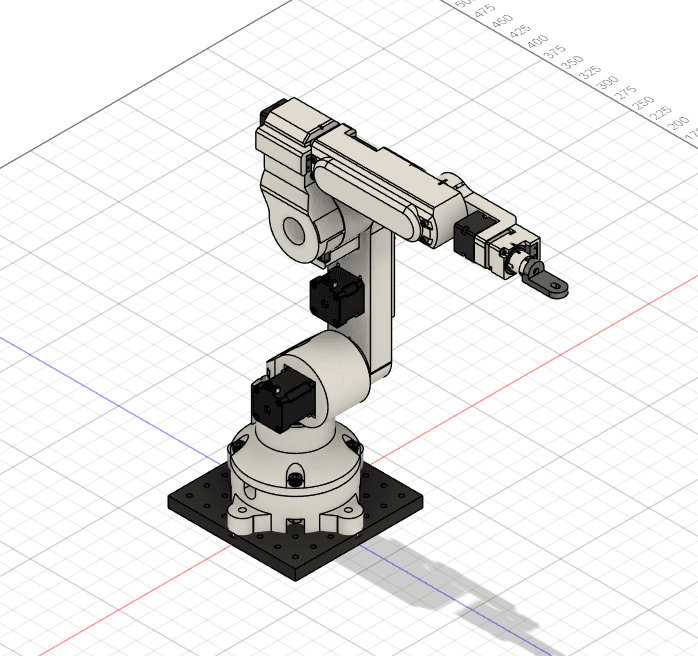
A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.
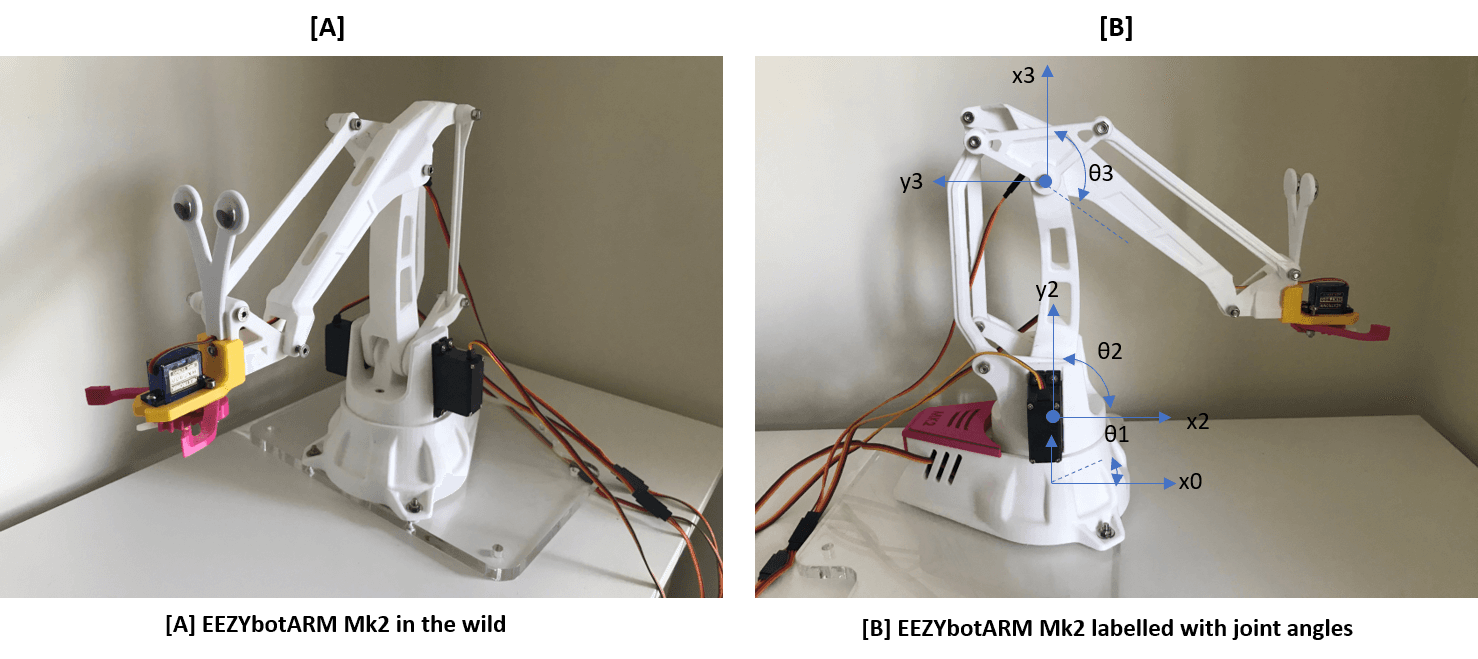
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
Robots 1–24 of 28