
DIY Delta robot
A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.
Robot armAdvancedBuildability 45/100 · Incomplete documentation
Cost not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 4 of 5 · Ready to build first, then by buildability
A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.

A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
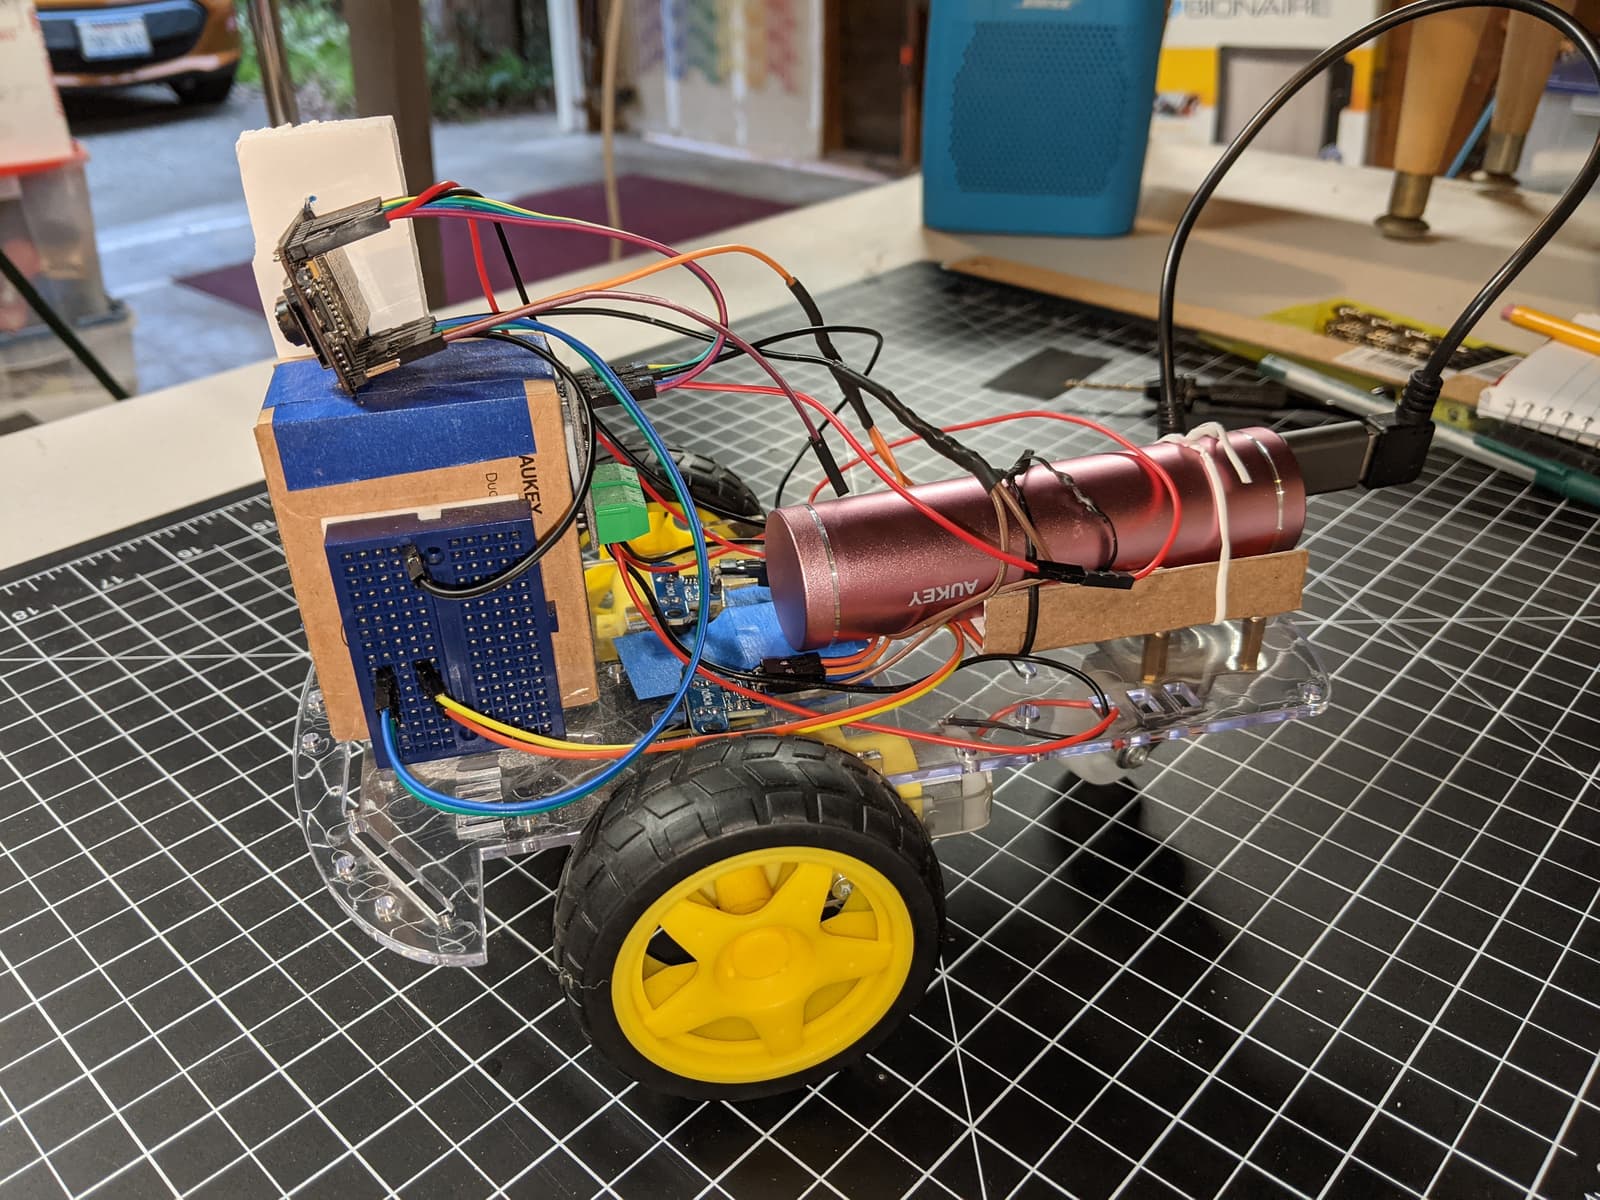
A cheap, extensible differential drive robot built on an ESP32-CAM, an L9110S motor driver and a Robot Car chassis, with closed-loop speed control, pose estimation and go-to-goal behavior.
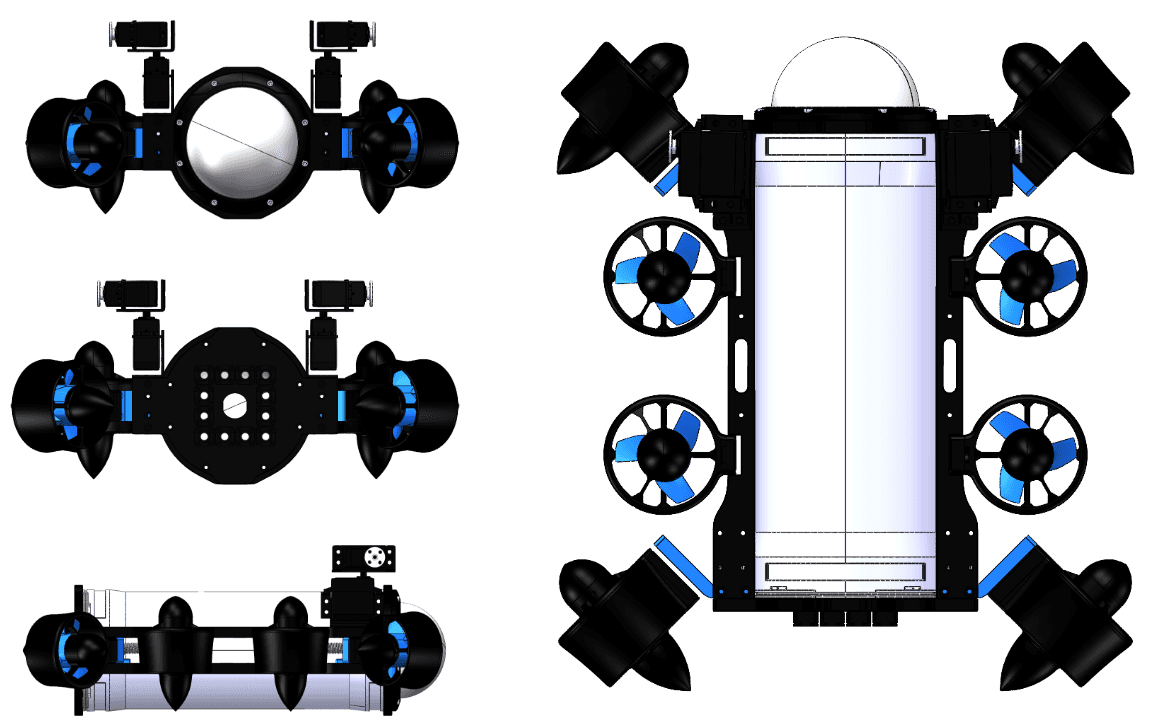
FinsROV is a low-cost, open-source underwater robot platform designed for underwater tasks and research in robotics and AI.
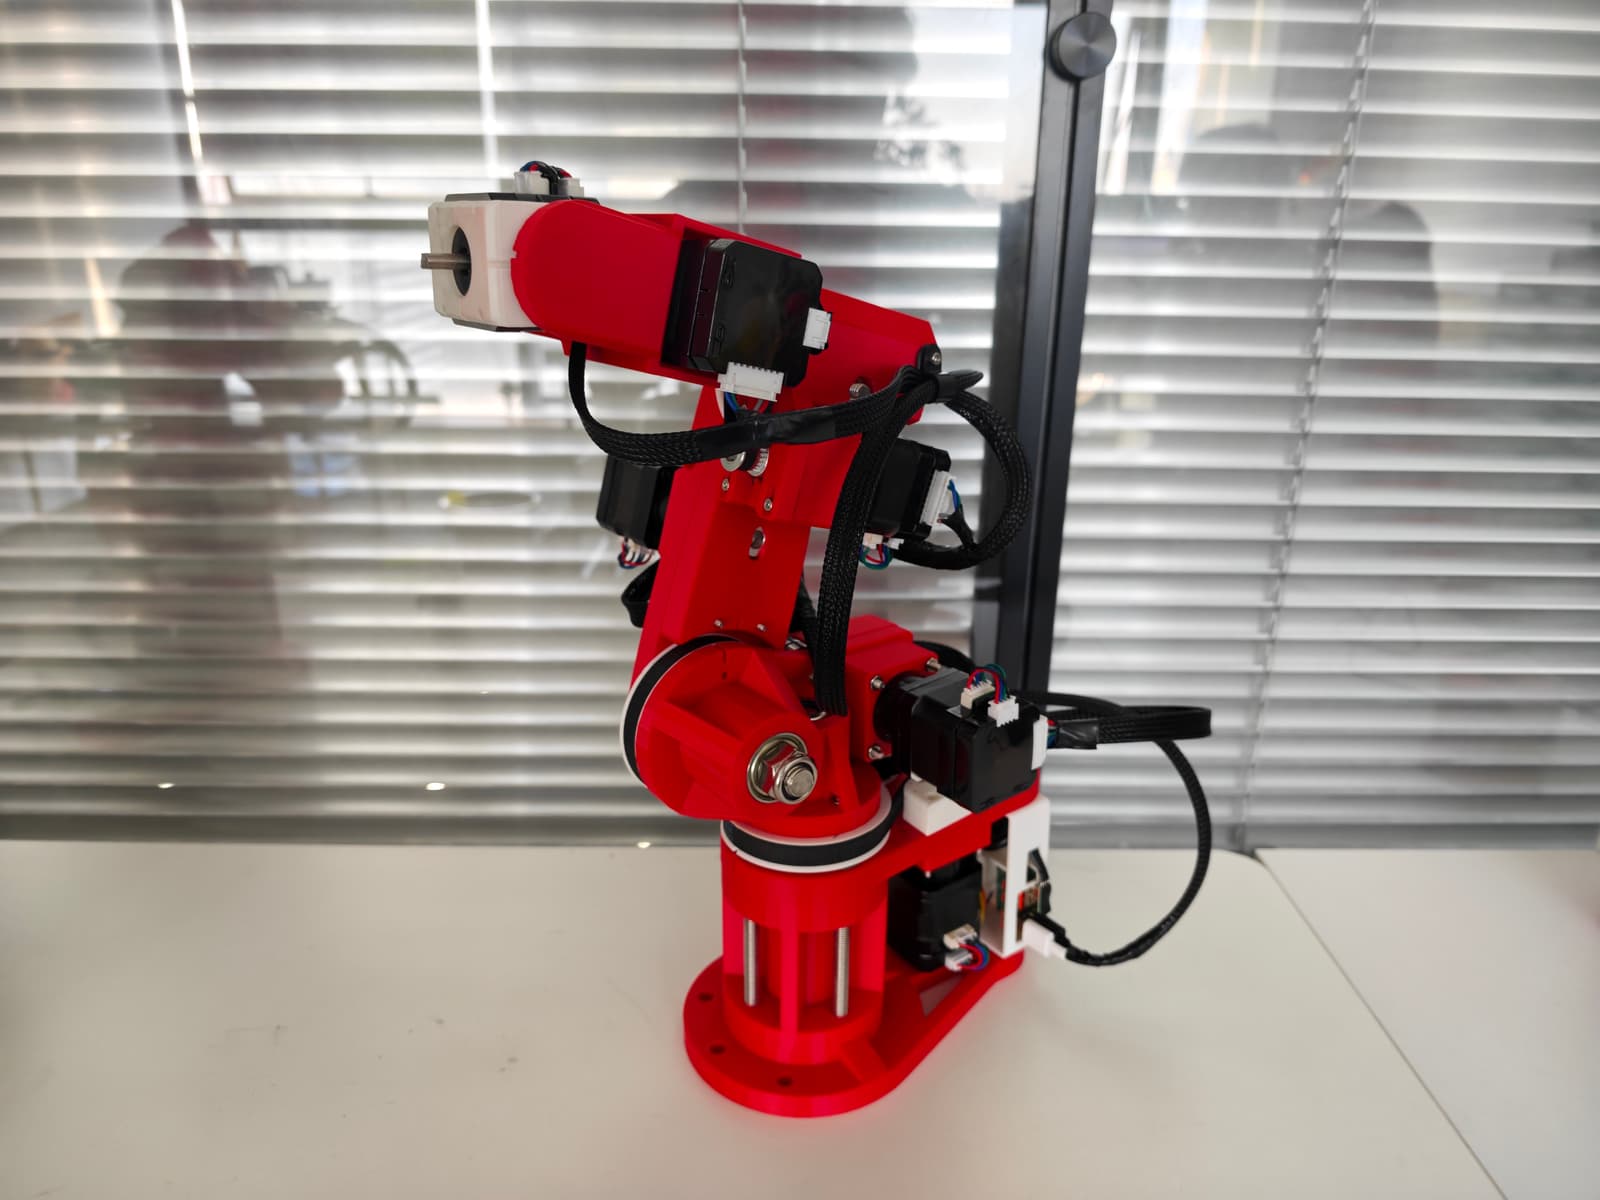
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
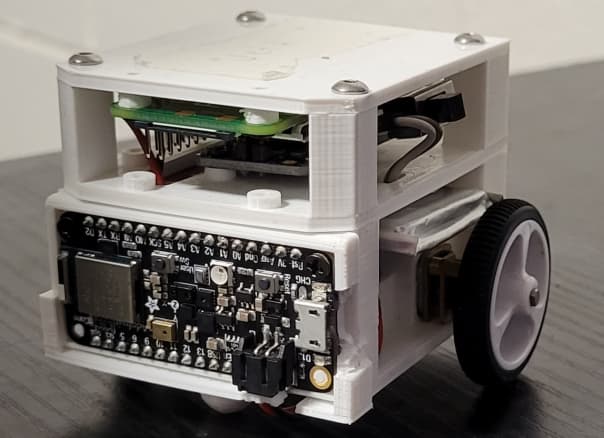
A fully-capable miniature swarm robot with multiple sensors, Wi-Fi and Bluetooth communication, Raspberry Pi Zero computing, and wheel odometry, designed for multi-robot research.
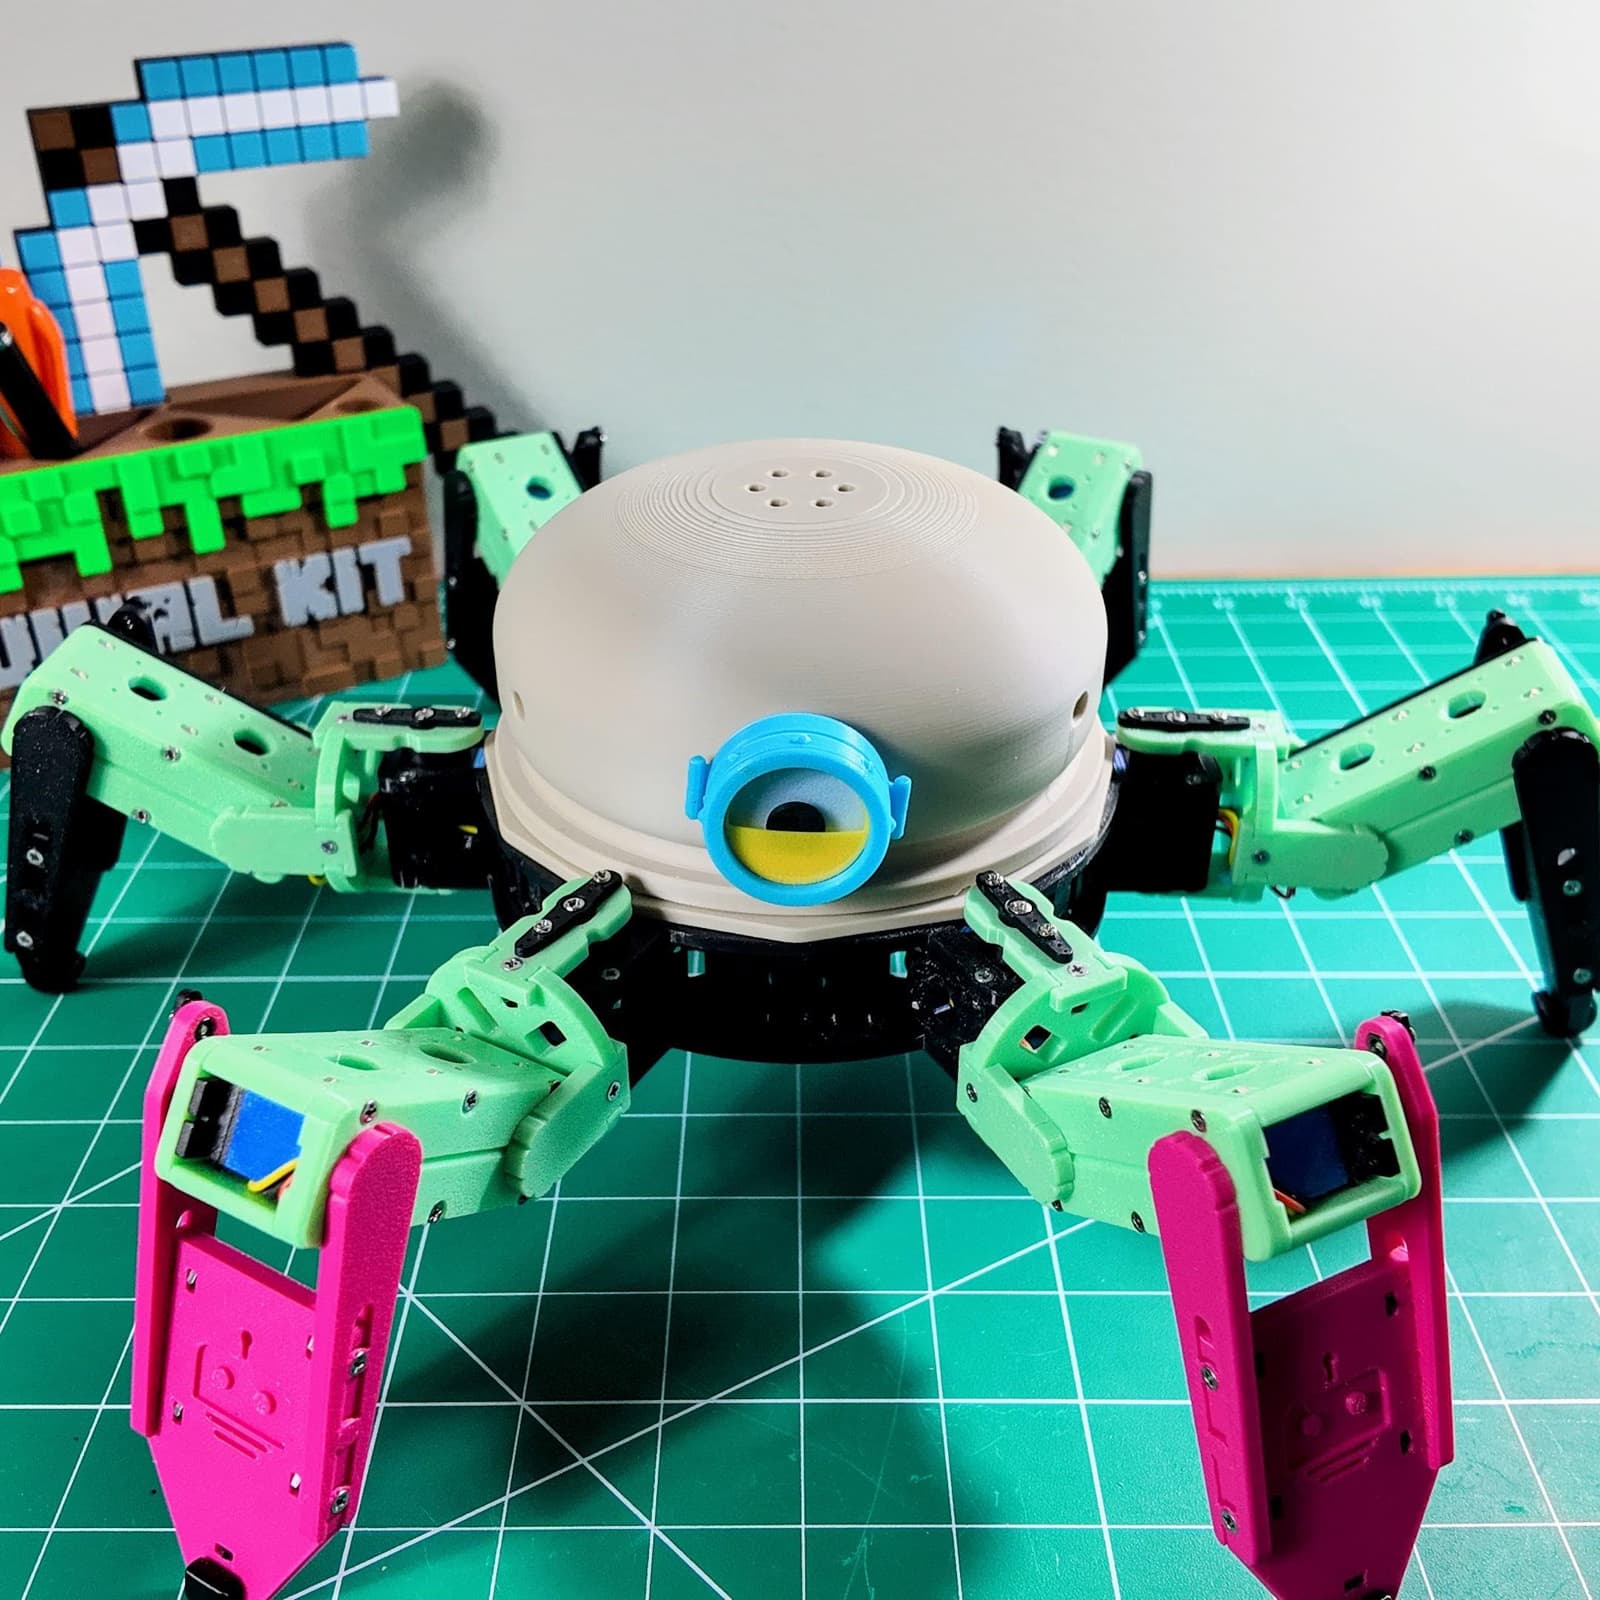
A family of 18-DOF, 3D-printed hexapod walking robots powered by an ESP32, controlled over WiFi or live pose streaming.
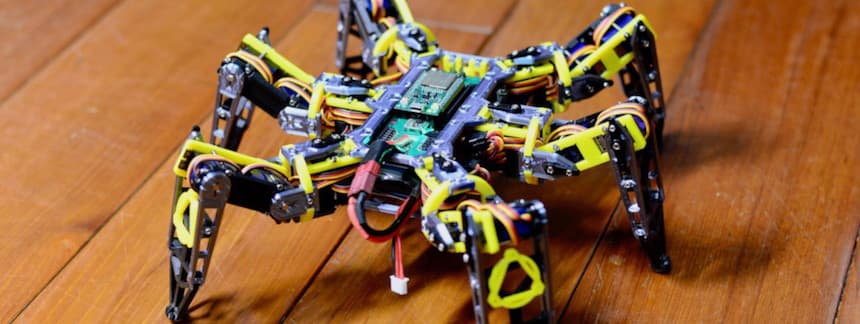
A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.
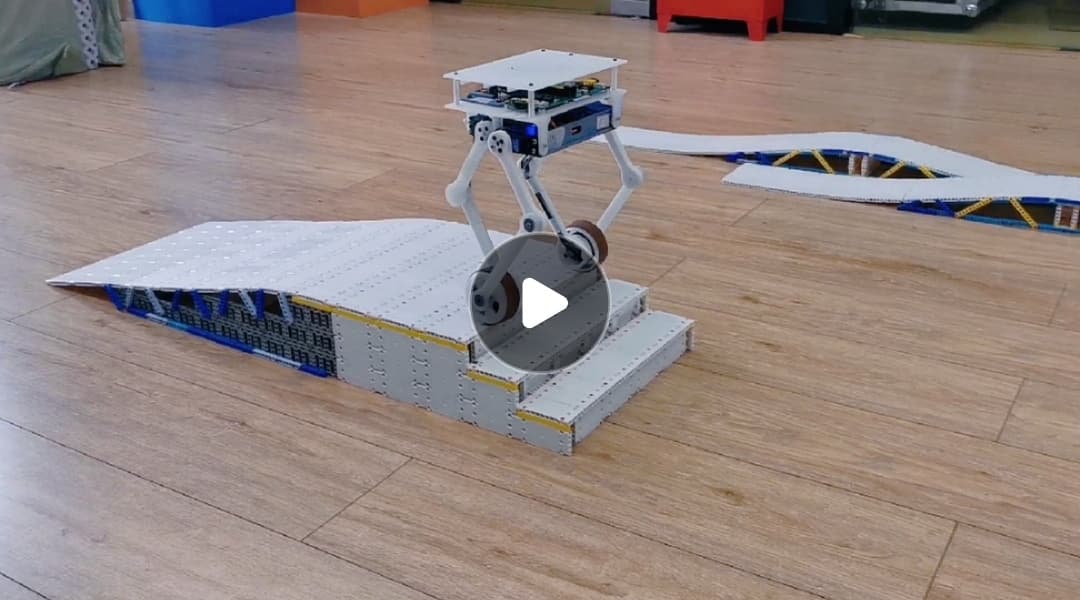
A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.
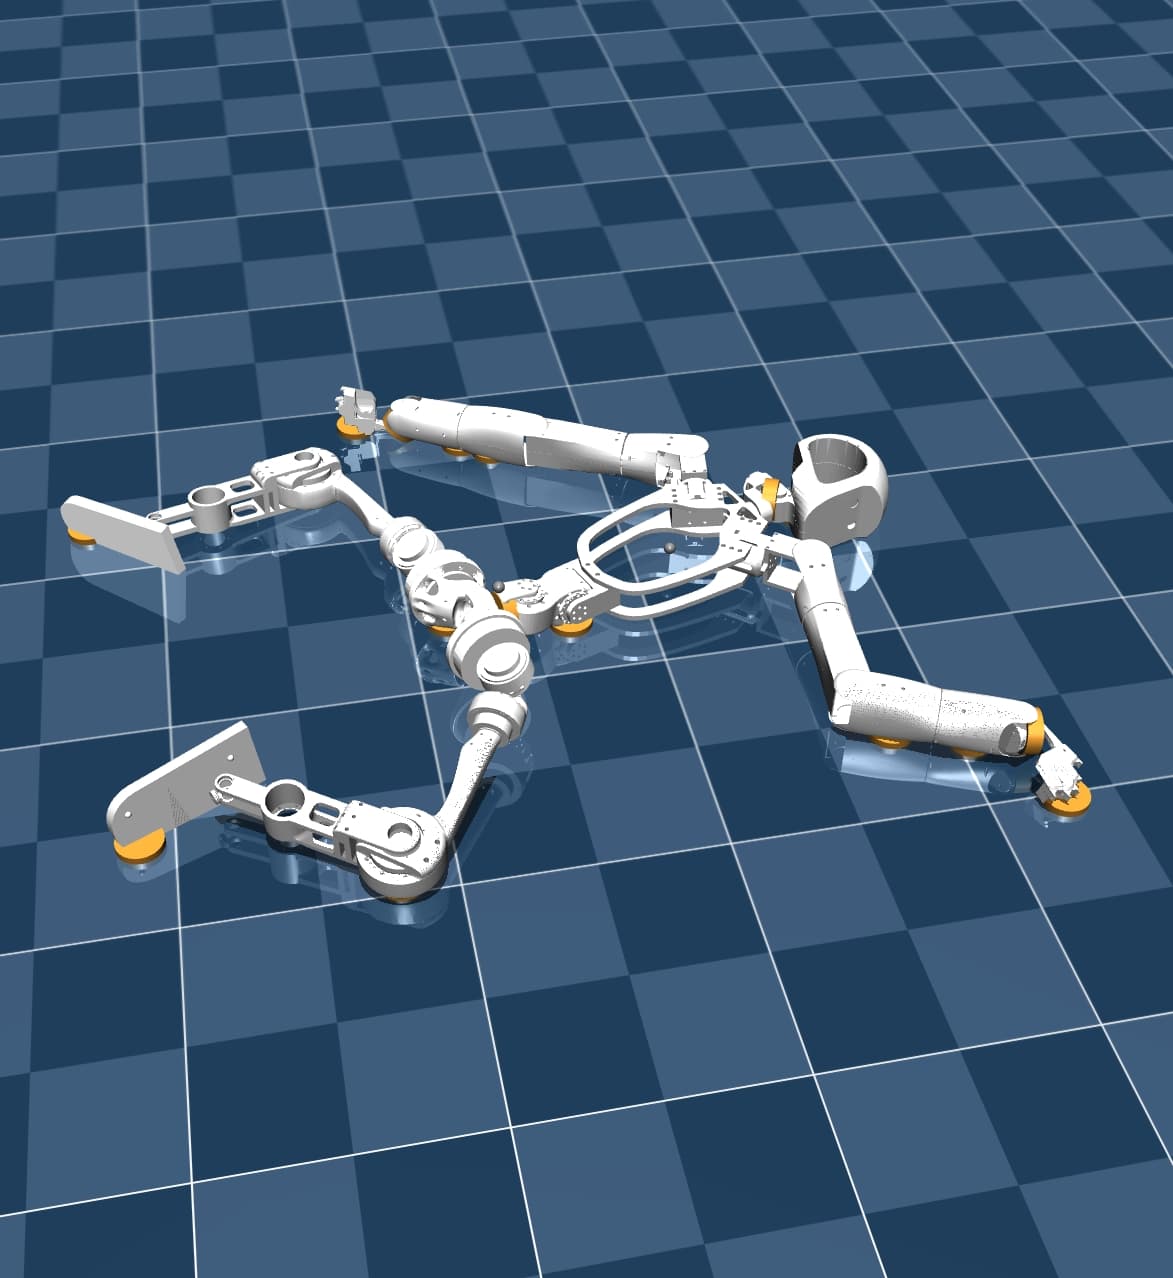
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
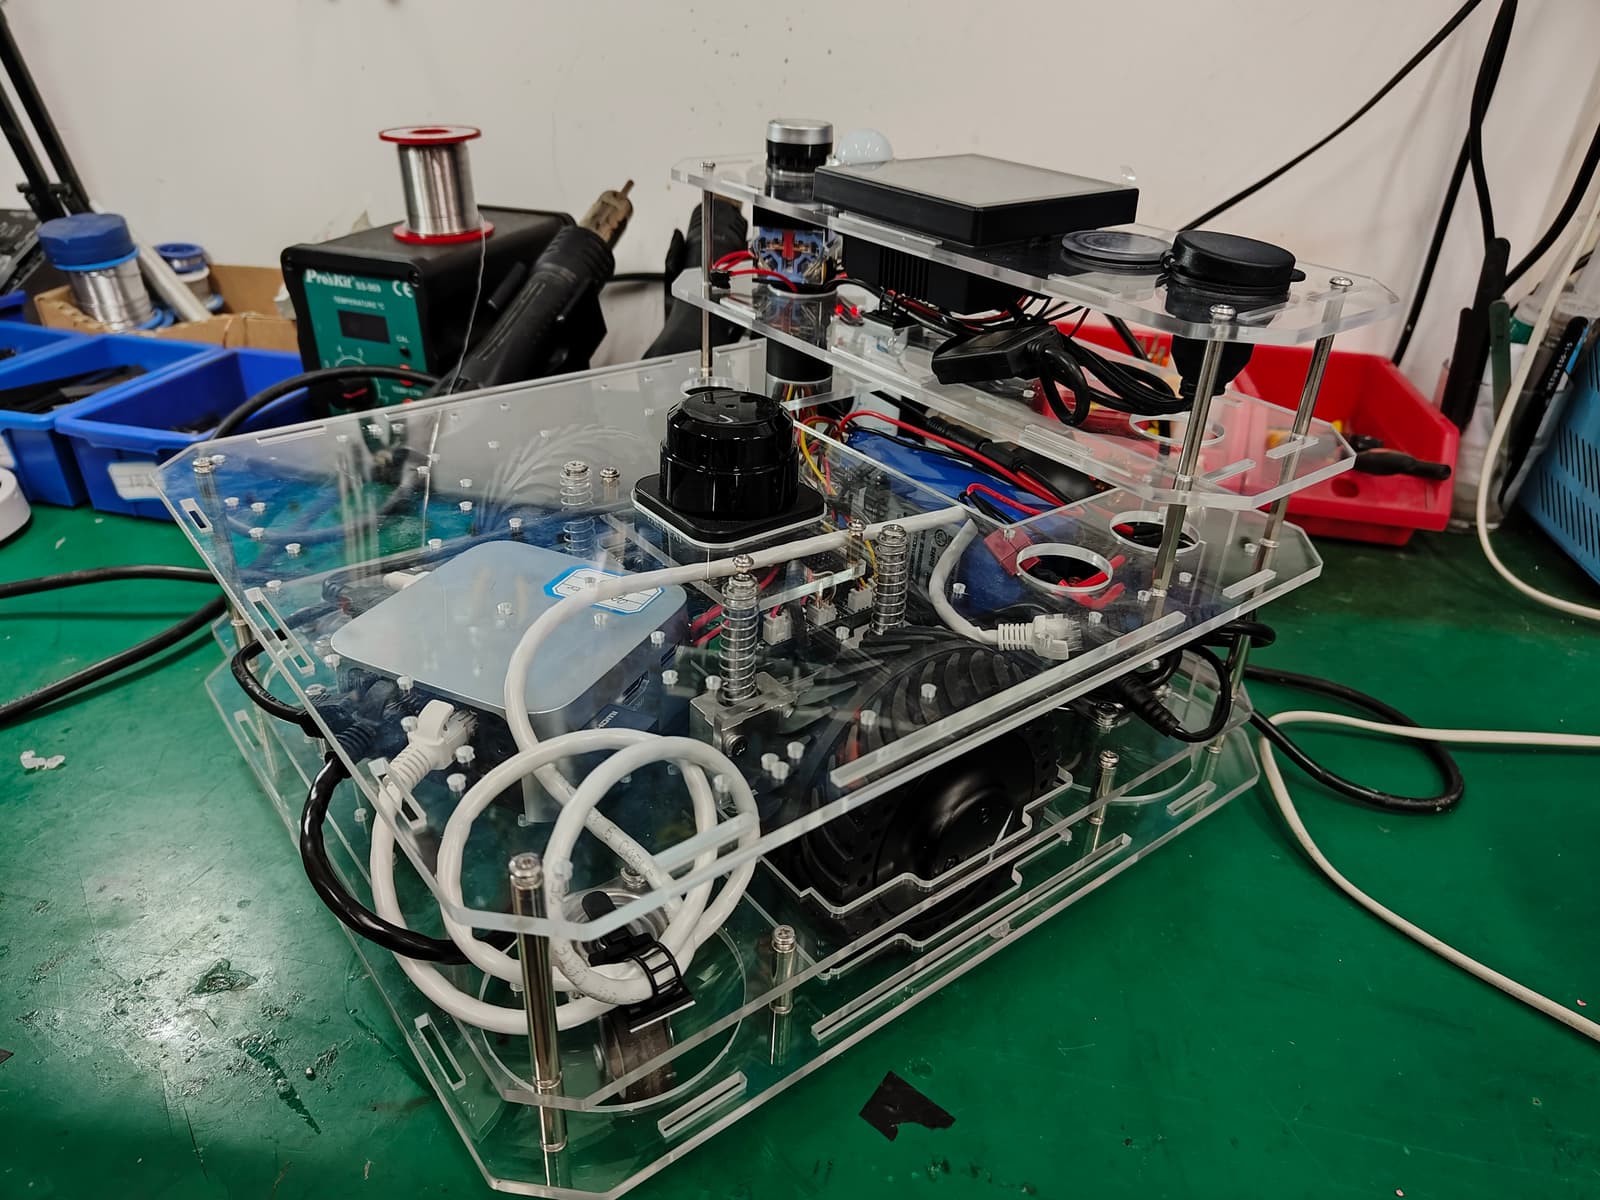
An open-source AGV chassis based on ROS for learning and practical applications.
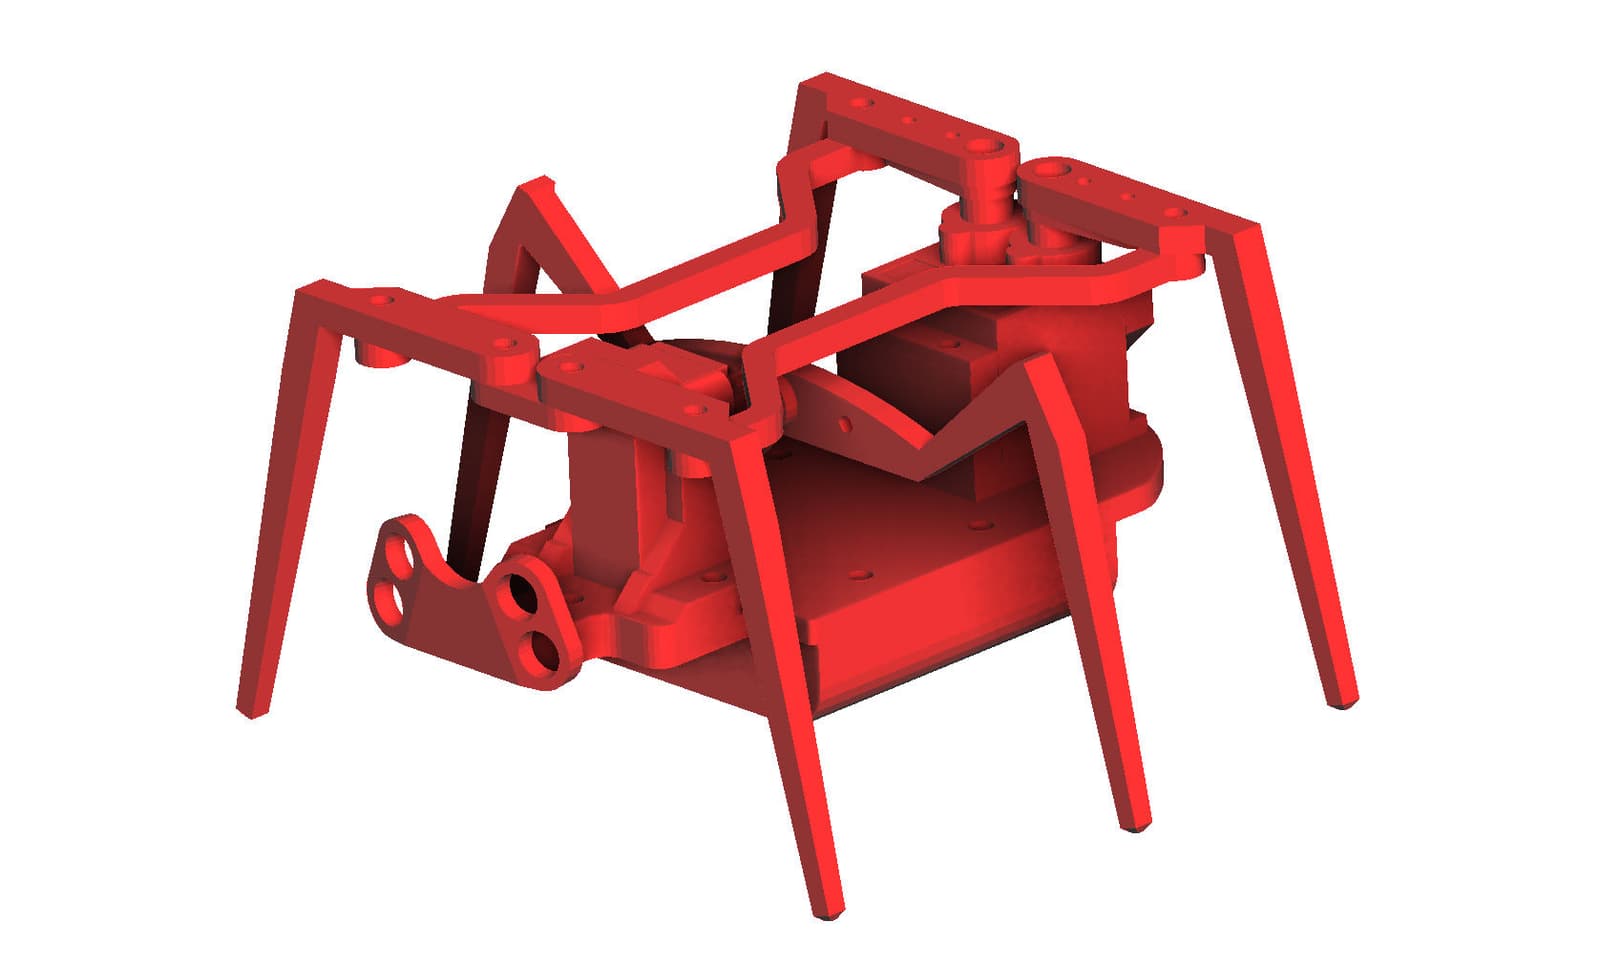
A low-budget three-servo hexapod robot that walks, dances and avoids obstacles using infrared proximity sensors.
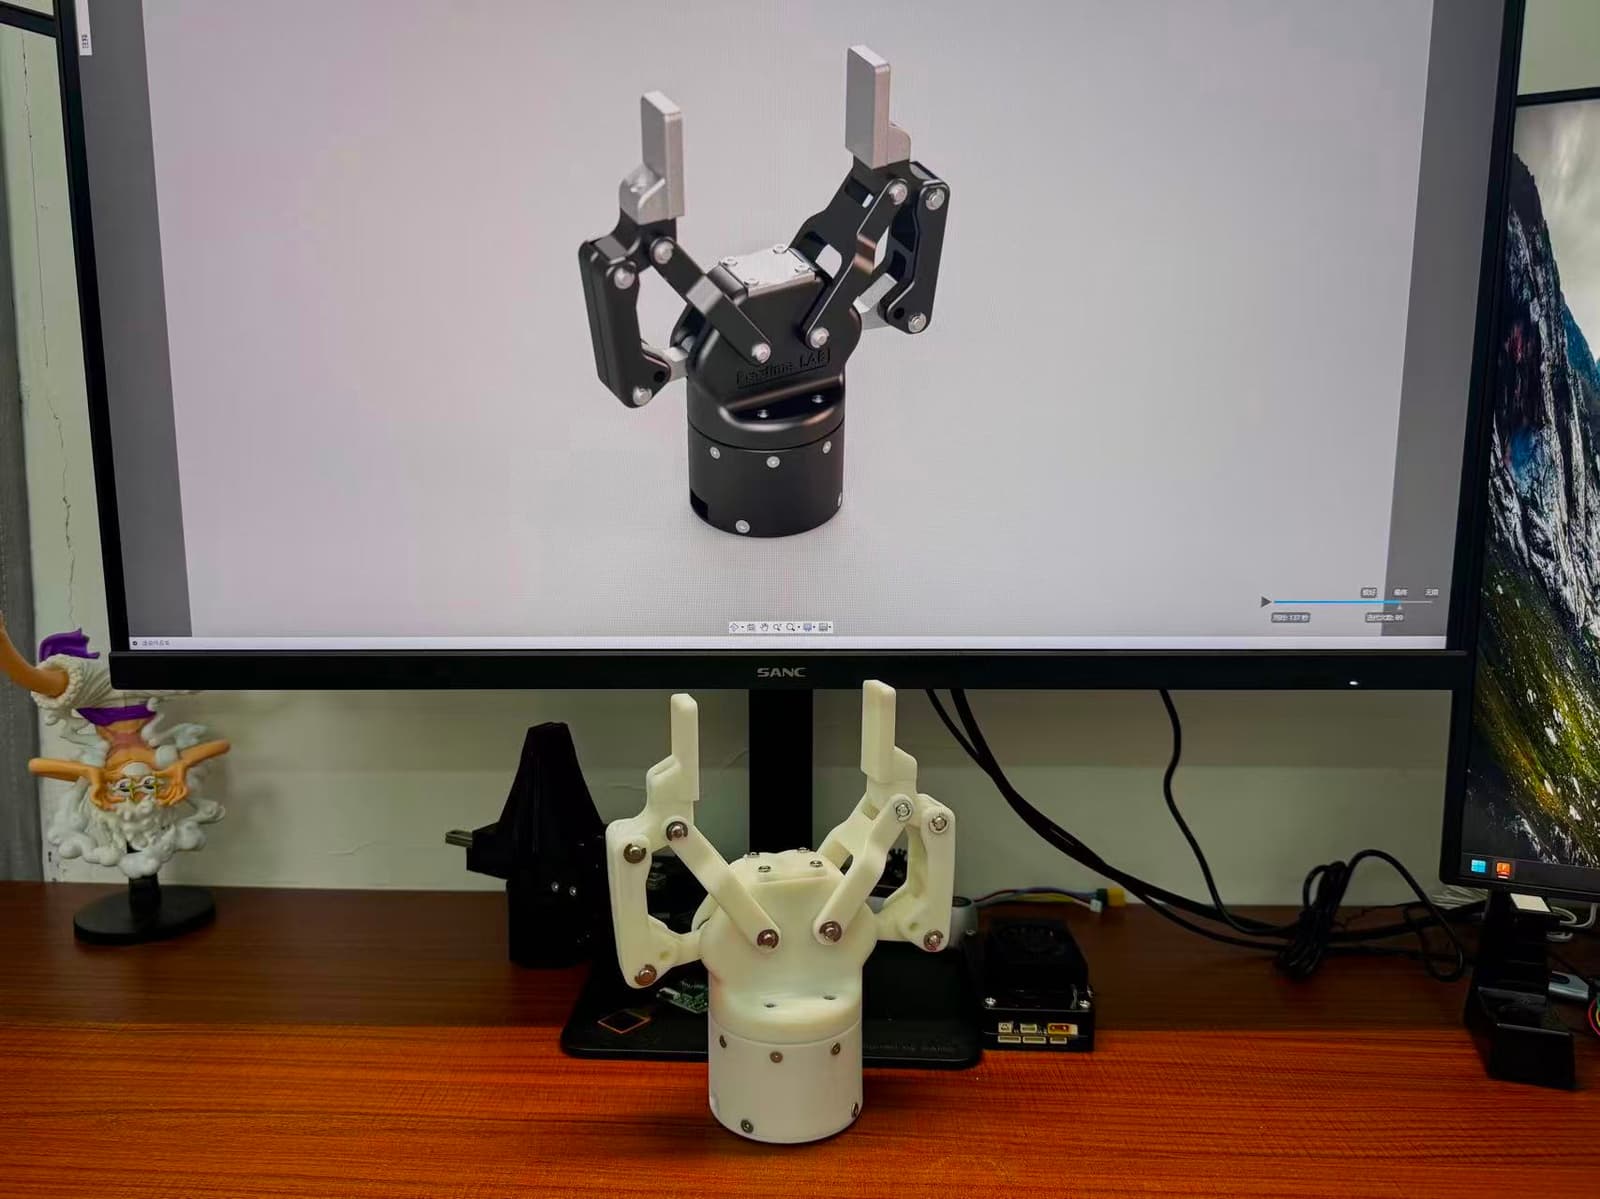
An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.
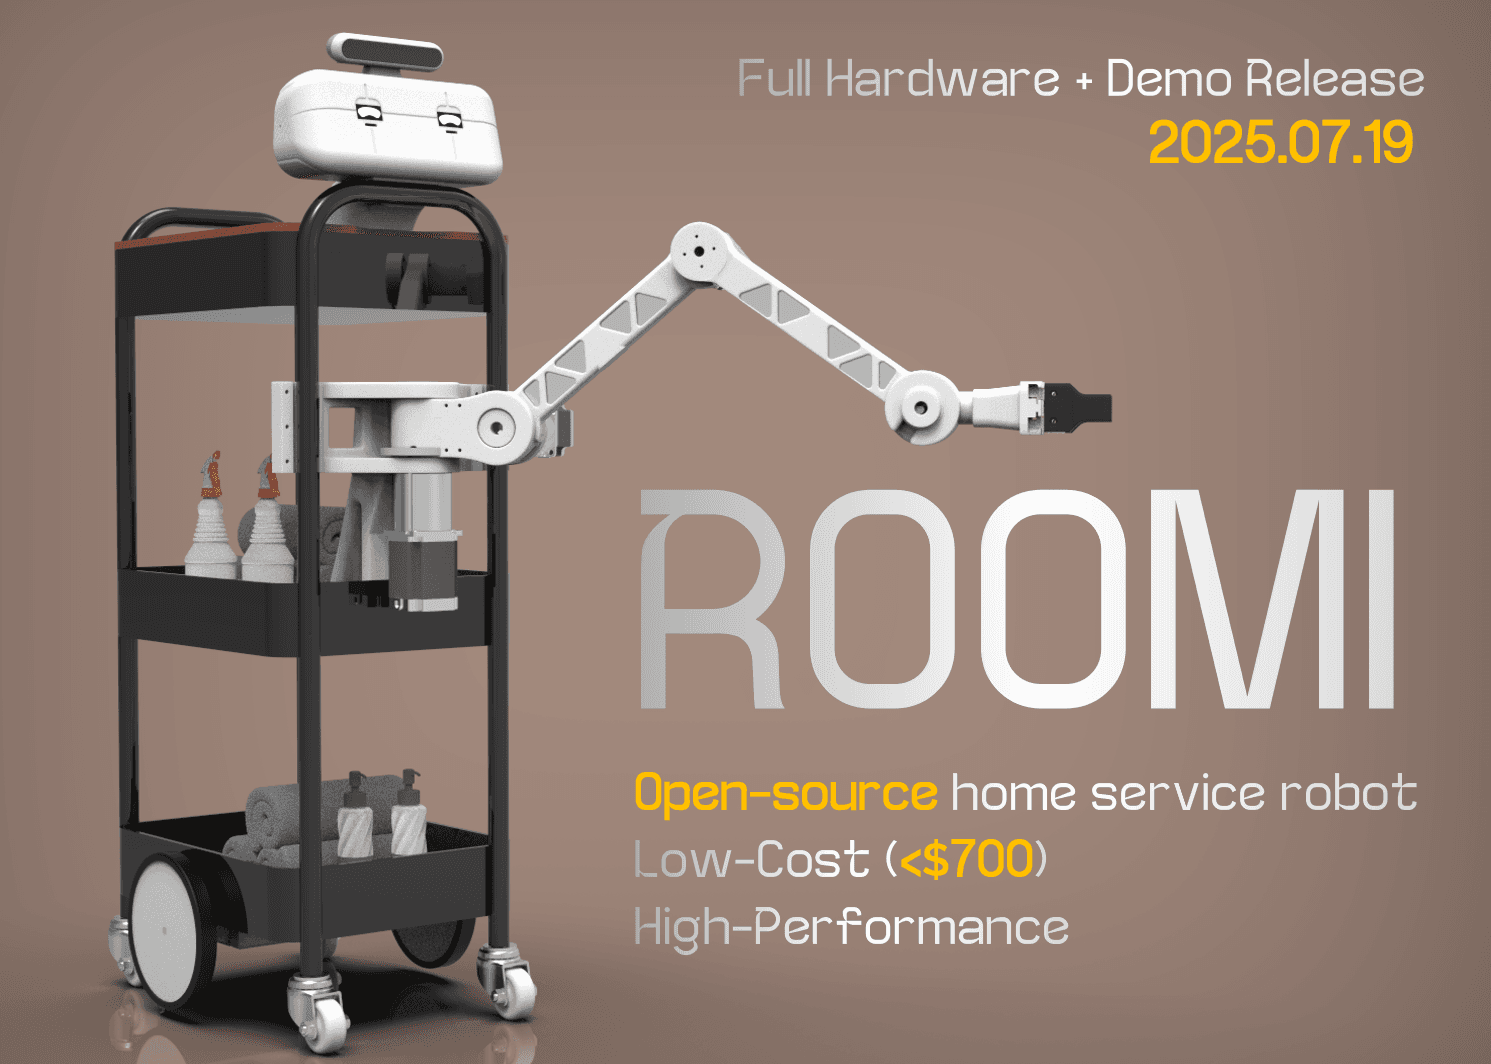
An open-source autonomous robot arm that cleans, makes beds and organizes rooms in hotels and homes.
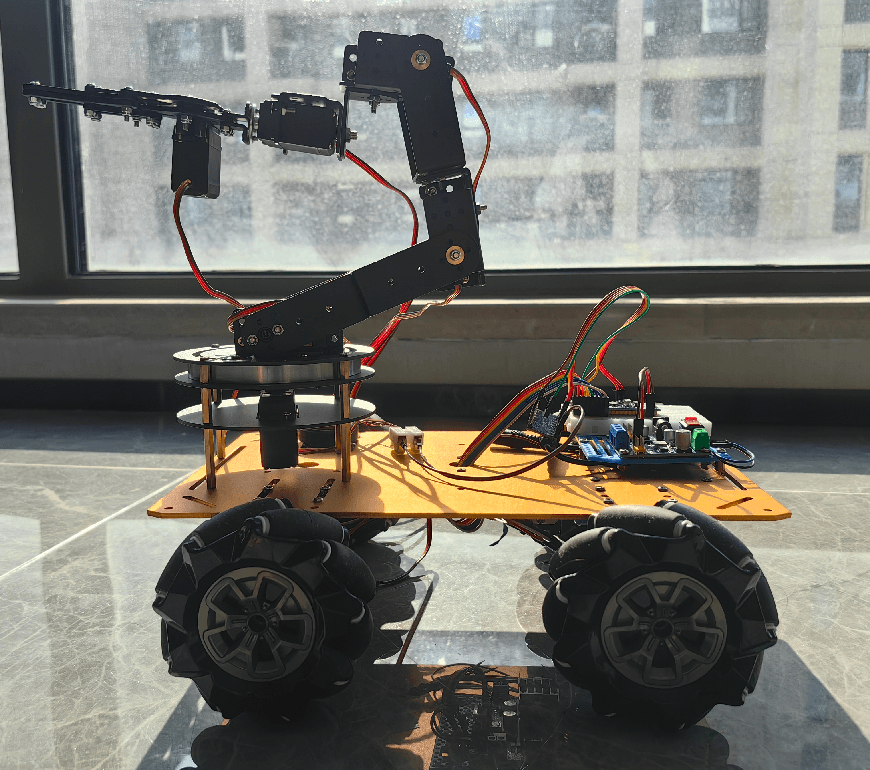
An intelligent omnidirectional wheel car inspired by the Unimog, featuring VLA control, PS2/Wi-Fi and voice control, camera monitoring, and robotic arm support.
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.

A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.
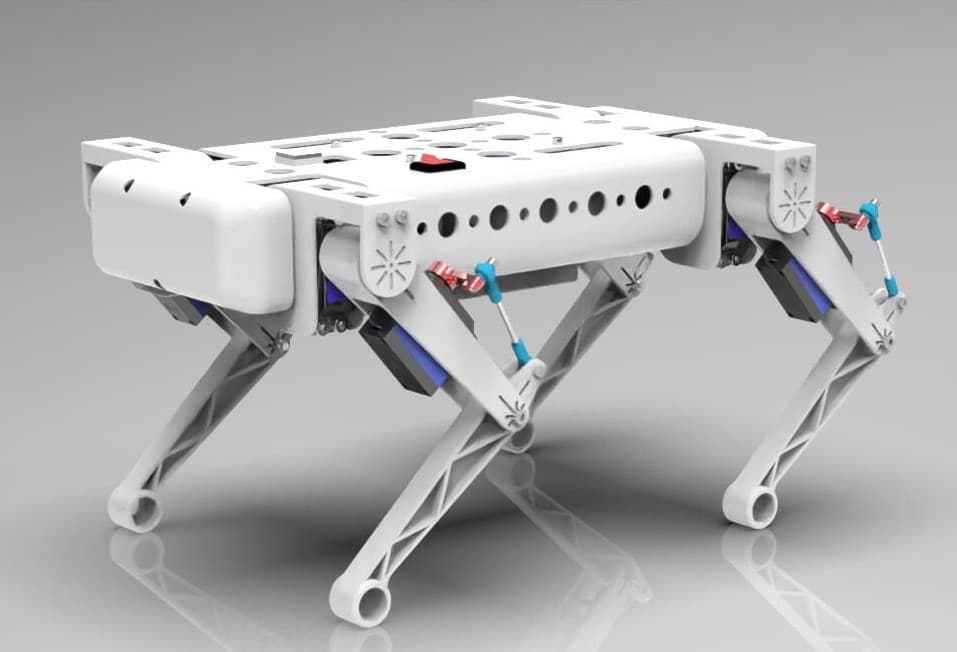
A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.
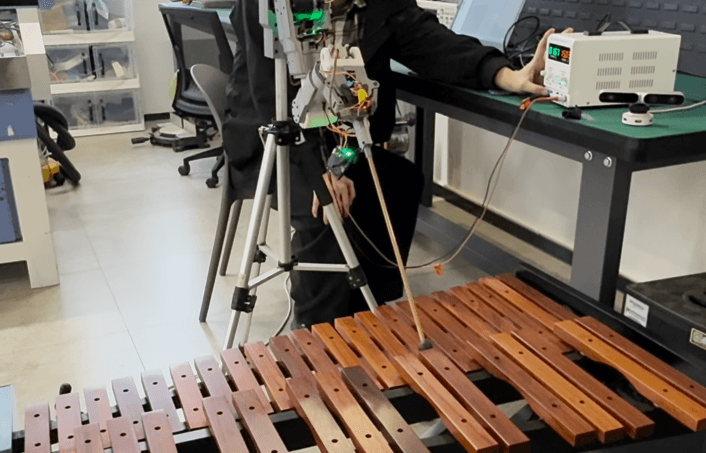
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
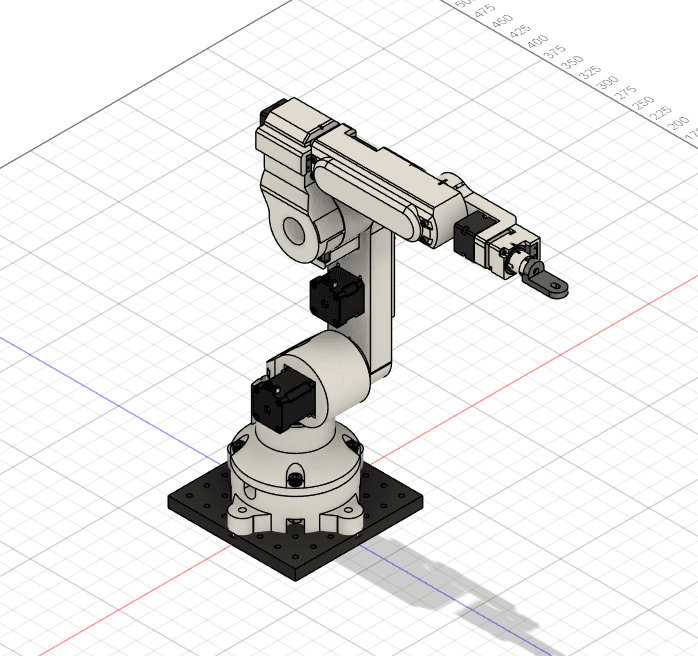
A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.
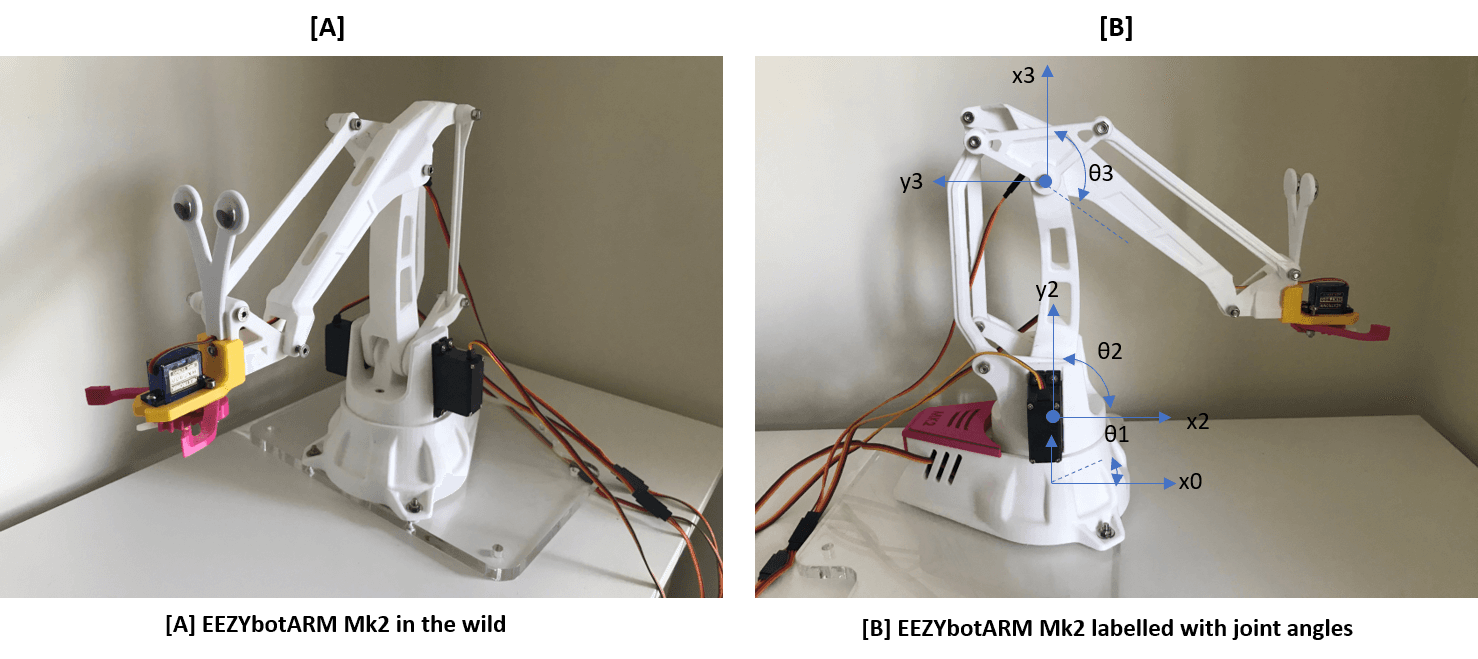
A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.
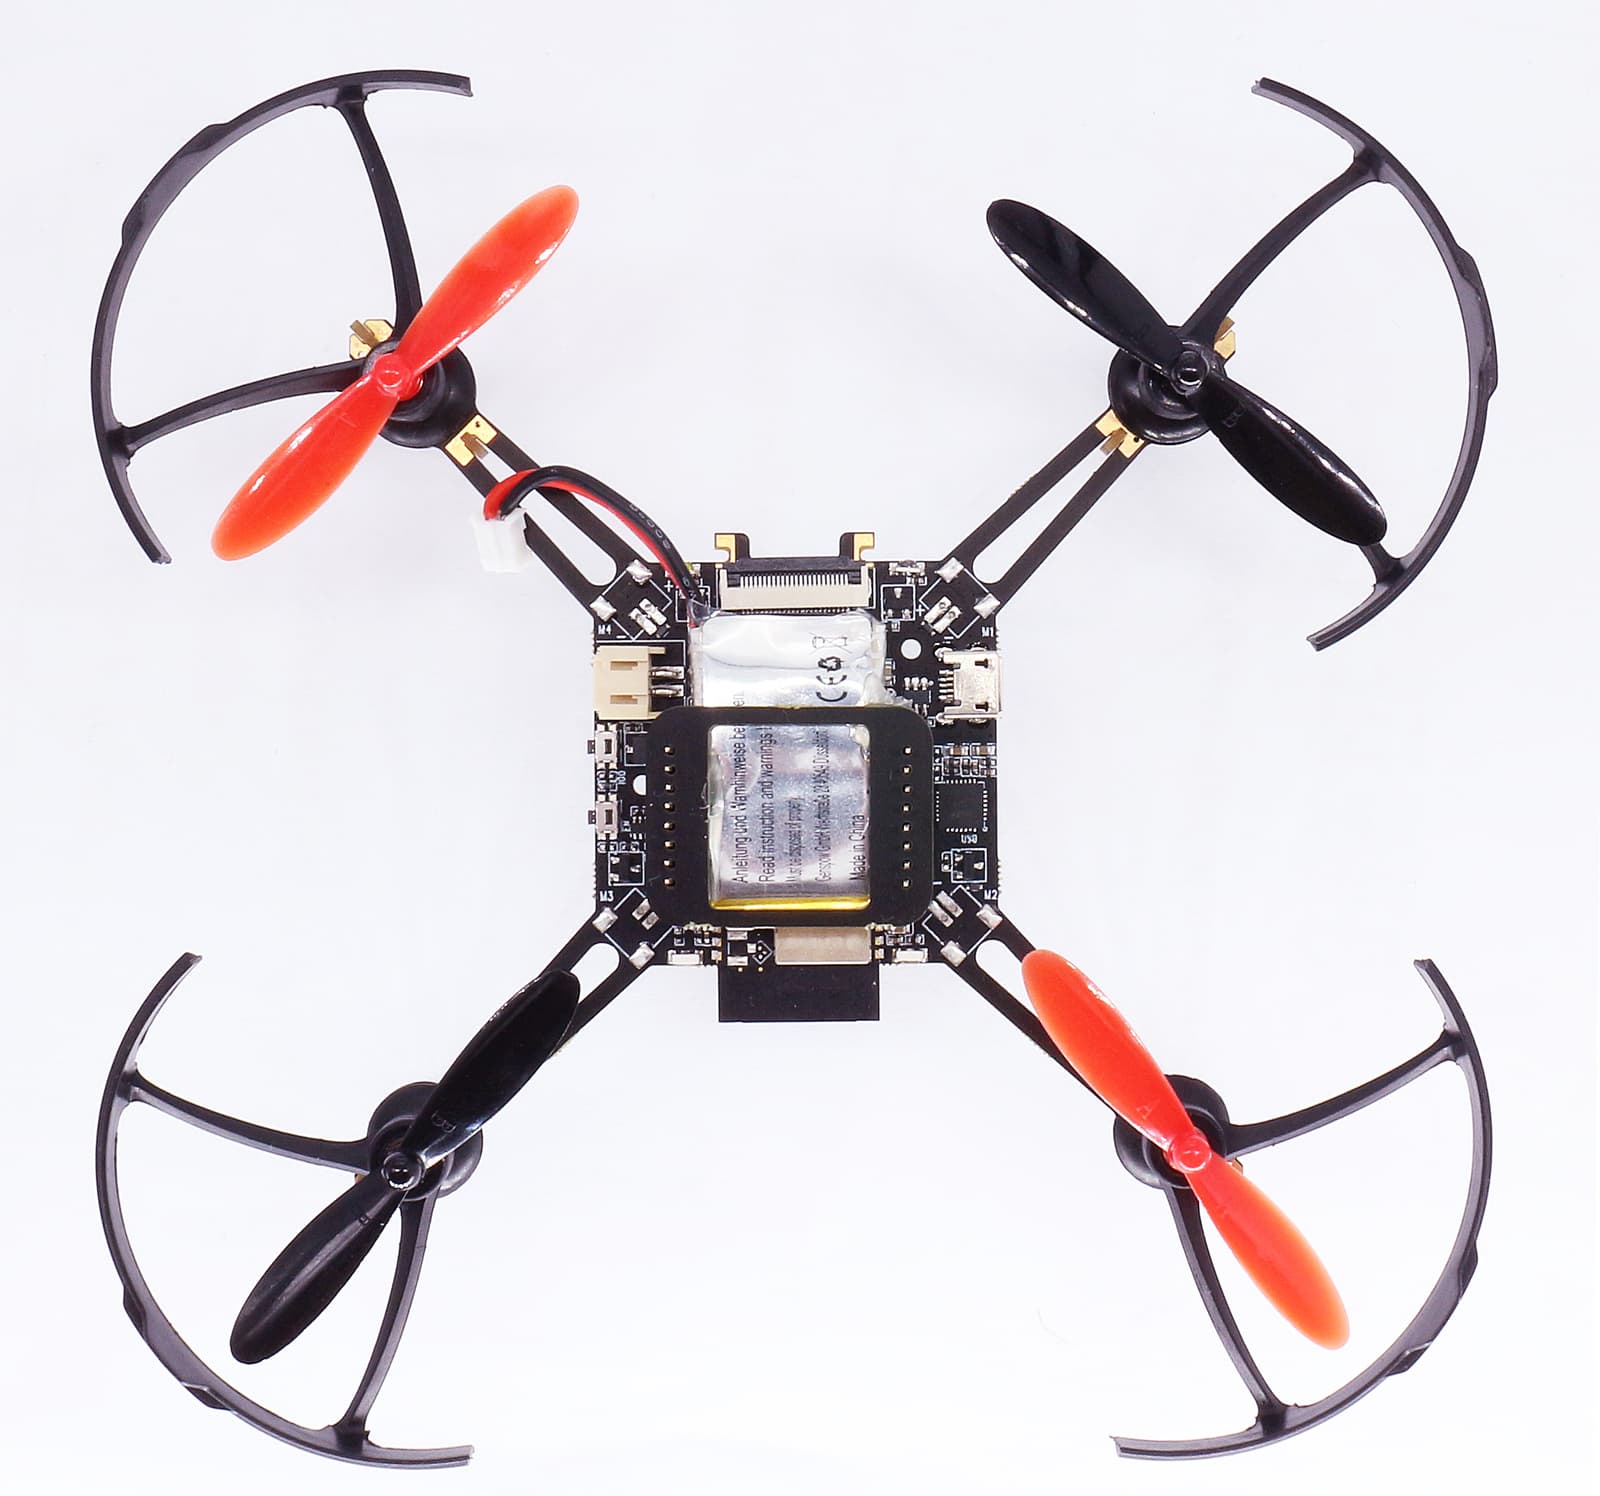
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
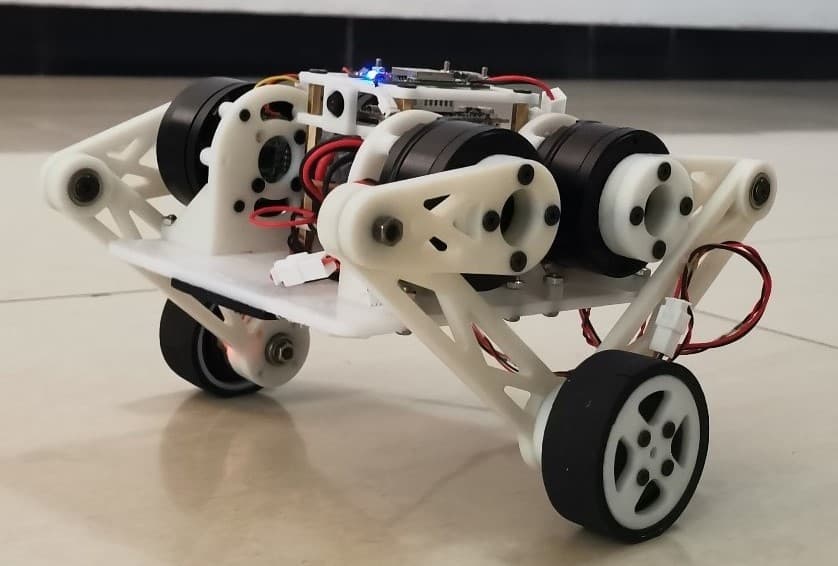
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
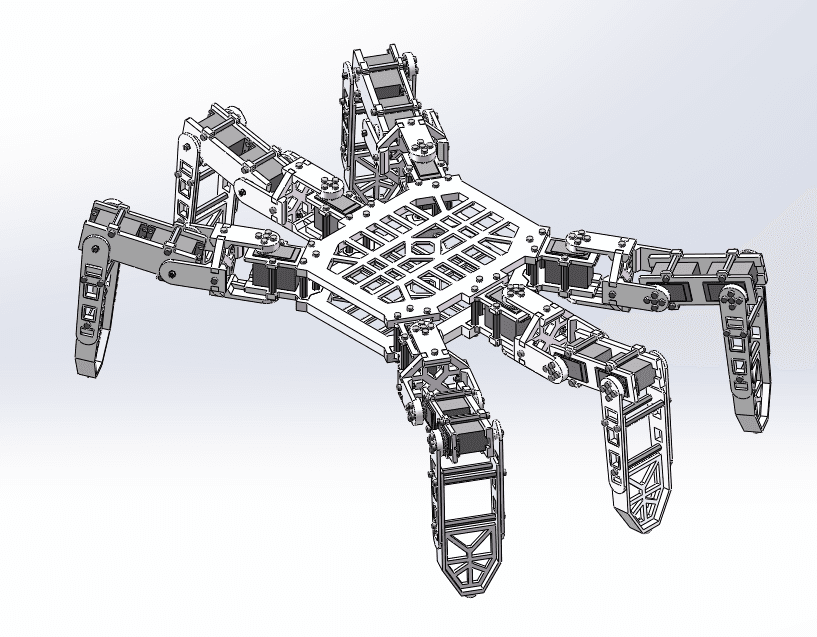
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
Robots 73–96 of 120