Skip to content

Photo and 3D model

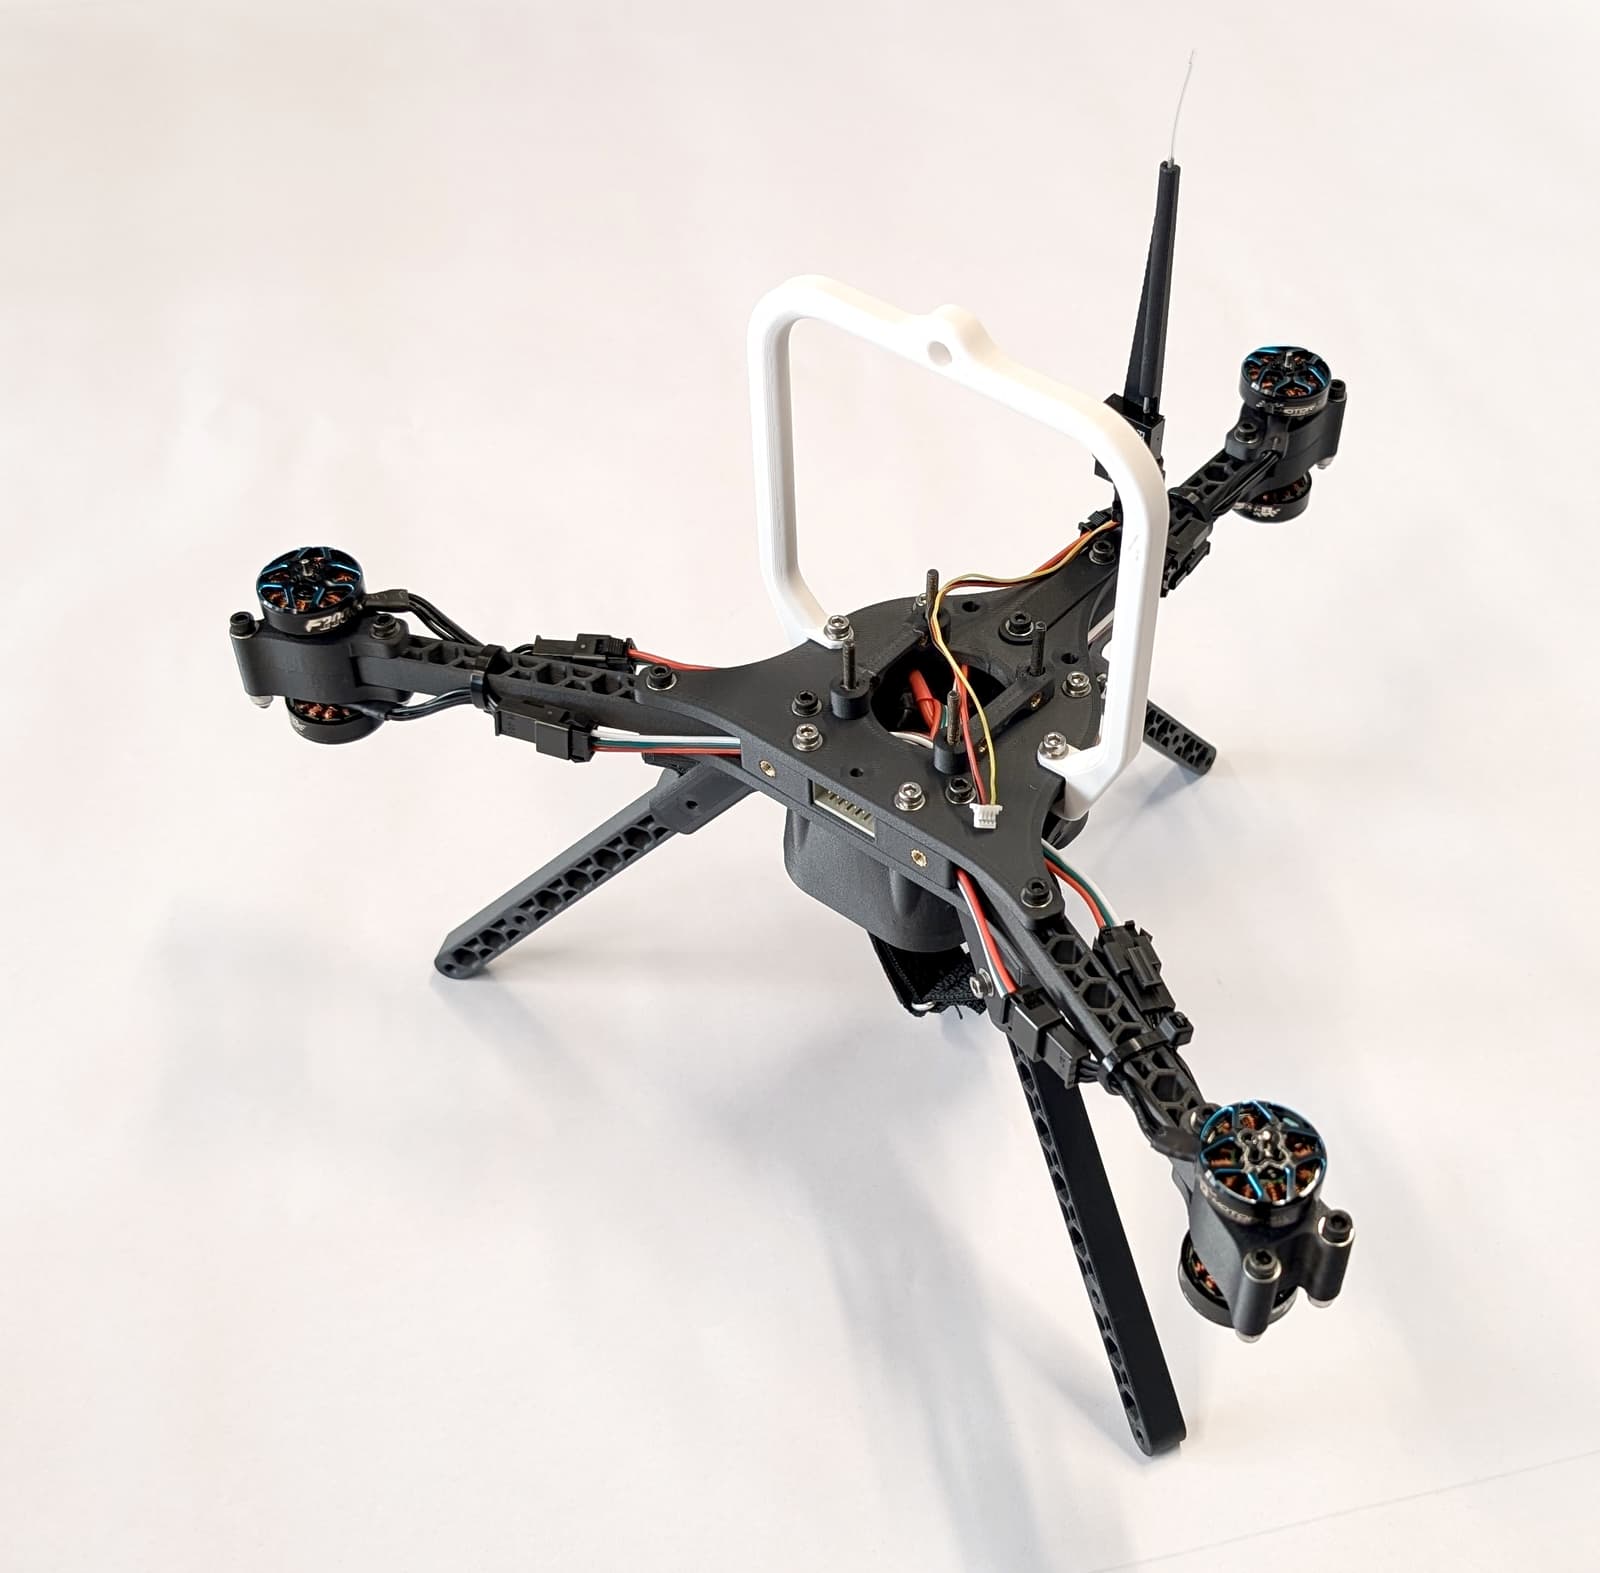
COMET, photo from its repository
Photo@uastw-embsys (opens in a new tab)CERN-OHL-W-2.0source file (opens in a new tab)

3D preview converted from github.com/uastw-embsys/comet at 9837b8d, under CERN-OHL-W-2.0. View the original files from GitHub (5.0 MB) (opens in a new tab)

Open source · free files

COMET

Drone

COMET is a cost-efficient, open-source Y6 hexacopter platform with a 3D-printed modular frame, designed for embedded and cyber-physical systems education and research.

Project information

Buildability
75/100Buildable with some effort
Estimated cost
under $600up to approx. €535 (ECB rate, 5 Nov 2026)excluding 3D-printing filamentAs stated by the creator in README.md.
Level
Intermediate
Parts
A spreadsheet
Tools
3D printer
Commercial use
Allowed
Height
30 cm

Suggested by Robotheca, created by @uastw-embsys (opens in a new tab), from github.com/uastw-embsys/comet (opens in a new tab), pinned to commit 9837b8d (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.

What to buy

The parts list is a spreadsheet in the repository. Robotheca can't read this file, so its quantities and prices are not checked here.

Open bill_of_materials.ods (opens in a new tab)

Why it scores 75

It measures the published files, not the robot · How we score

75/100

Buildable with some effort

How complete the published files are for rebuilding this robot, measured by Robotheca at commit 9837b8d. It isn't a rating of the robot. Counted out of 80 points and scaled to 100: the parts that don't apply to this robot are left out.

  1. 13D and CAD files18 printable parts (STL, 3MF), 31 CAD source files.20/20
  2. –Robot descriptionNo URDF. Not counted: the score is made of the parts that apply.Optional: add a URDF, and the robot can be seen in 3D and tried in the browser.Not counted
  3. 2Parts listA parts list in the repository as a spreadsheet (bill_of_materials.ods): Robotheca can't read its quantities, prices or shop links.Most points to gain: Add the parts list as a CSV or a Markdown table too, so its prices and shop links can be checked.10/20
  4. 3SoftwareCode in this repository, instructions to install or run it.Say which software framework it uses (ROS 2, LeRobot, Arduino…).10/15
  5. 4DocumentationREADME of 8,538 characters with 0 pictures; 5 build steps.Show the robot and its assembly in pictures in the README.10/15
  6. –SimulationNo simulation files. Not counted: the score is made of the parts that apply.Optional: add a simulation model (MuJoCo, Gazebo, Webots or Isaac).Not counted
  7. 5LicensesHardware: CERN-OHL-W-2.0; software: LGPL-3.0-only.10/10

Build it

The creator's 5 steps, each linked to its instructions
  1. Print the frame parts
  2. Assemble the Y-frame
  3. Mount the coaxial motors
  4. Install the flight controller
  5. Configure INAV and the ESCs

The guide appears here as you scroll.

Guide by @uastw-embsys (README.md), under CERN-OHL-W-2.0 (hardware) and LGPL-3.0-only (software).

More guides

Wiring and electronics

Notes written by Robotheca from the project's documents, not by its creator

Main parts: Robotheca's summary

  • Electronic speed controllers (ESCs) configured with Bluejay firmware.
  • Brushless DC motors, 2004 1600KV-1900KV.
  • 6S LiPo battery.
  • Radio receiver, calibrated with the flight controller.
  • Accelerometer and magnetometer on the flight controller, calibrated during setup.

Connections: Robotheca's summary

  • The wiring diagram in electronics/wiring/wiring-diagram.svg shows how components are connected and interfaced.
  • ESCs connect to the motors and to the flight controller through a standardized motor-controller connector.
  • ESC pinout and wiring diagrams are provided as images, including an XT30 battery connection.
  • An IDC pinout diagram is provided for connecting the flight controller.

What it can do: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator
  • COMET is a 30 cm, six-rotor Y6 hexacopter built for education and research in embedded and cyber-physical systems.
  • Uses coaxial brushless motors and propellers for propulsion redundancy.
  • Uses a standardized motor-controller connector to allow integration of a preferred flight controller.
  • Ships with a ready-to-fly INAV configuration and a Bluejay ESC configuration.
  • Recommended power is a 6S LiPo battery with 2004 1600KV-1900KV motors and 5.1x2.5 three-blade propellers.

Software

Framework
Not stated
Languages
Python
License
LGPL-3.0-only

Robotheca doesn't review code. Read it before running it.

How to run it: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator.

  1. 1Download a release ZIP or clone the repository from GitHub.
  2. 2Print the clearance gauge first, verify part dimensions, then print the frame and other parts from the 3MF projects.
  3. 3Apply the diff-*.txt configuration file to the INAV settings, save, and reboot.
  4. 4Calibrate the accelerometer, magnetometer, and radio.
  5. 5Use the ESC Configurator to flash the ESCs with Bluejay firmware, apply the parameter file, and power cycle.
  6. 6Verify the failsafe and the motor order and direction before flying, with propellers removed during configuration.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.

The code

Free files

Every file of the project, at commit 9837b8d.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/comet/badge.svg)](https://robotheca.org/robots/comet)
[![Robotheca buildability](https://robotheca.org/robots/comet/score.svg)](https://robotheca.org/robots/comet)

Other drones

All 52 drones
  • 3D render
    Ready to build

    Open source · free files

    HACK FLY 32

    Drone · Advanced

    Score
    Buildability 86 out of 100
    Cost
    $105≈ €94without the battery, the FPV camera and the radio you fly it with
  • Ready to build

    Open source · free files

    R.O.B.I.N. Ornithopter

    Drone · Advanced

    Score
    Buildability 81 out of 100
    Cost
    £206≈ €247
  • Open source · free files

    Agipix Quadrotor

    Drone · Advanced

    Score
    Buildability 82 out of 100
    Cost
    Not stated

≈ € values are approximate, converted at the ECB euro reference rate of 5 Nov 2026. The creator's original price always comes first.