Agipix Quadrotor
An open-source agile indoor quadrotor platform with a 3D LiDAR, RGB camera and IMU, running the same ROS 2 stack in Isaac Sim and on hardware.
- Drone
- Open source
- ROS 2
- 3D printable
Suggested by Robotheca, created by @SasaKuruppuarachchi (opens in a new tab), from github.com/SasaKuruppuarachchi/agipix (opens in a new tab). Pinned to commit 147a736 (opens in a new tab).
- Hardware license
- CC0-1.0 (opens in a new tab)
- Software license
- CC0-1.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
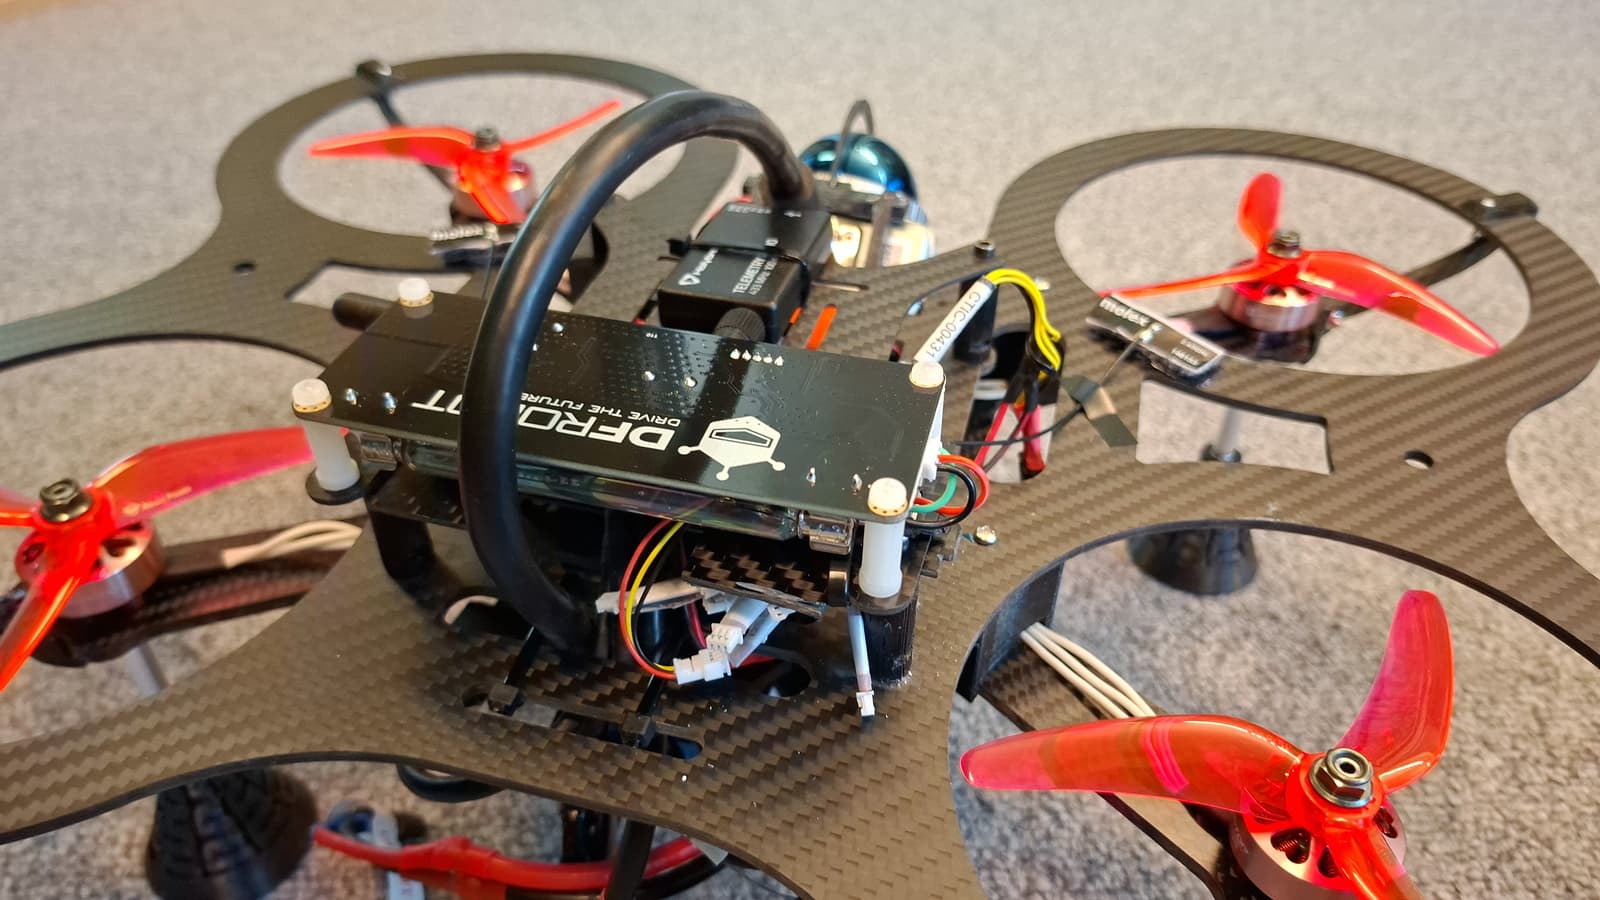
3D preview converted from github.com/SasaKuruppuarachchi/agipix at 147a736, under CC0-1.0. View the original files from GitHub (47.8 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Agile indoor aerial autonomy with a small 438×372 mm quadrotor platform
- Runs the same containerized ROS 2 stack in Isaac Sim and on the real robot
- Autonomous exploration and mapping using 3D LiDAR, RGB camera and IMU
- Modular perception, state estimation, mapping, planning, PX4 interface and logging as decoupled ROS 2 nodes
- Measured thrust-to-weight ratio of about 2.98:1 for maneuvering in tight spaces
- Mission supervision, teleoperation and human-in-the-loop control through a UI
Bill of materials
18 parts18 of 18 parts shown
| # | Component | Quantity | Est. price | Supplier |
|---|---|---|---|---|
| 1 | Main compute unit | 1 | – | – |
| 2 | Breakout Board | 1 | – | – |
| 3 | NX heatsink | 1 | – | – |
| 4 | ESC | 1 | – | – |
| 5 | XT60 | 3 | – | – |
| 6 | Battery straps | 1 | – | – |
| 7 | Motors | 4 | – | – |
| 8 | Propeller | 4 | – | – |
| 9 | Receiver | 1 | – | – |
| 10 | FC | 1 | – | – |
| 11 | RGB Camera | 1 | – | – |
| 12 | RGBD camera | 1 | – | – |
| 13 | Lidar | 1 | – | – |
| 14 | Optical flow | 1 | – | – |
| 15 | Nut bolt set | 2 | – | – |
| 16 | Heat shrinks | 1 | – | – |
| 17 | Cable tie | 2 | – | – |
| 18 | Mounting foam | 2 | – | – |
18 of 18 parts have no price in the source, so there is no parts total. Read from bom.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Hardware assembly
- 2Flashing and firmware
- 3Software setup on the robot
The guide appears here as you scroll.
Guide by @SasaKuruppuarachchi (README.md), under CC0-1.0.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Jetson Orin NX companion computer on a Hadron carrier board
- Flight controller (FC) running PX4
- Electronic speed controllers (ESC) driving the motors
- Brushless motors with propellers and a radio receiver
- Livox Mid-360 3D LiDAR
- RGB camera and optional RGBD camera
- IMU and optical flow sensor
- XT60 battery connector with battery straps
Connections
- Livox Mid-360 LiDAR connects to the compute unit over Ethernet, as shown in the mid360 wiring diagram
- PX4 flight controller wiring is documented in a dedicated wiring diagram
- Power is distributed from the battery through XT60 connectors to the ESCs and components
- Layered decks provide accessible power and data breakouts for sensor or compute upgrades
Cables and connectors
From the parts list.
- XT60 × 3
- Cable tie × 2


