HACK FLY 32
A compact 3-inch 3D printed FPV drone with a custom flight controller PCB, ESC support and GPS, running Betaflight firmware.
- Drone
- Open source
- 3D printable
Suggested by Robotheca, created by @minhazislamnafi (opens in a new tab), from github.com/minhazislamnafi/HACK-FLY-32 (opens in a new tab). Pinned to commit 2e8cfc7 (opens in a new tab).
- Hardware license
- CERN-OHL-S-2.0 (opens in a new tab)
- Software license
- CERN-OHL-S-2.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
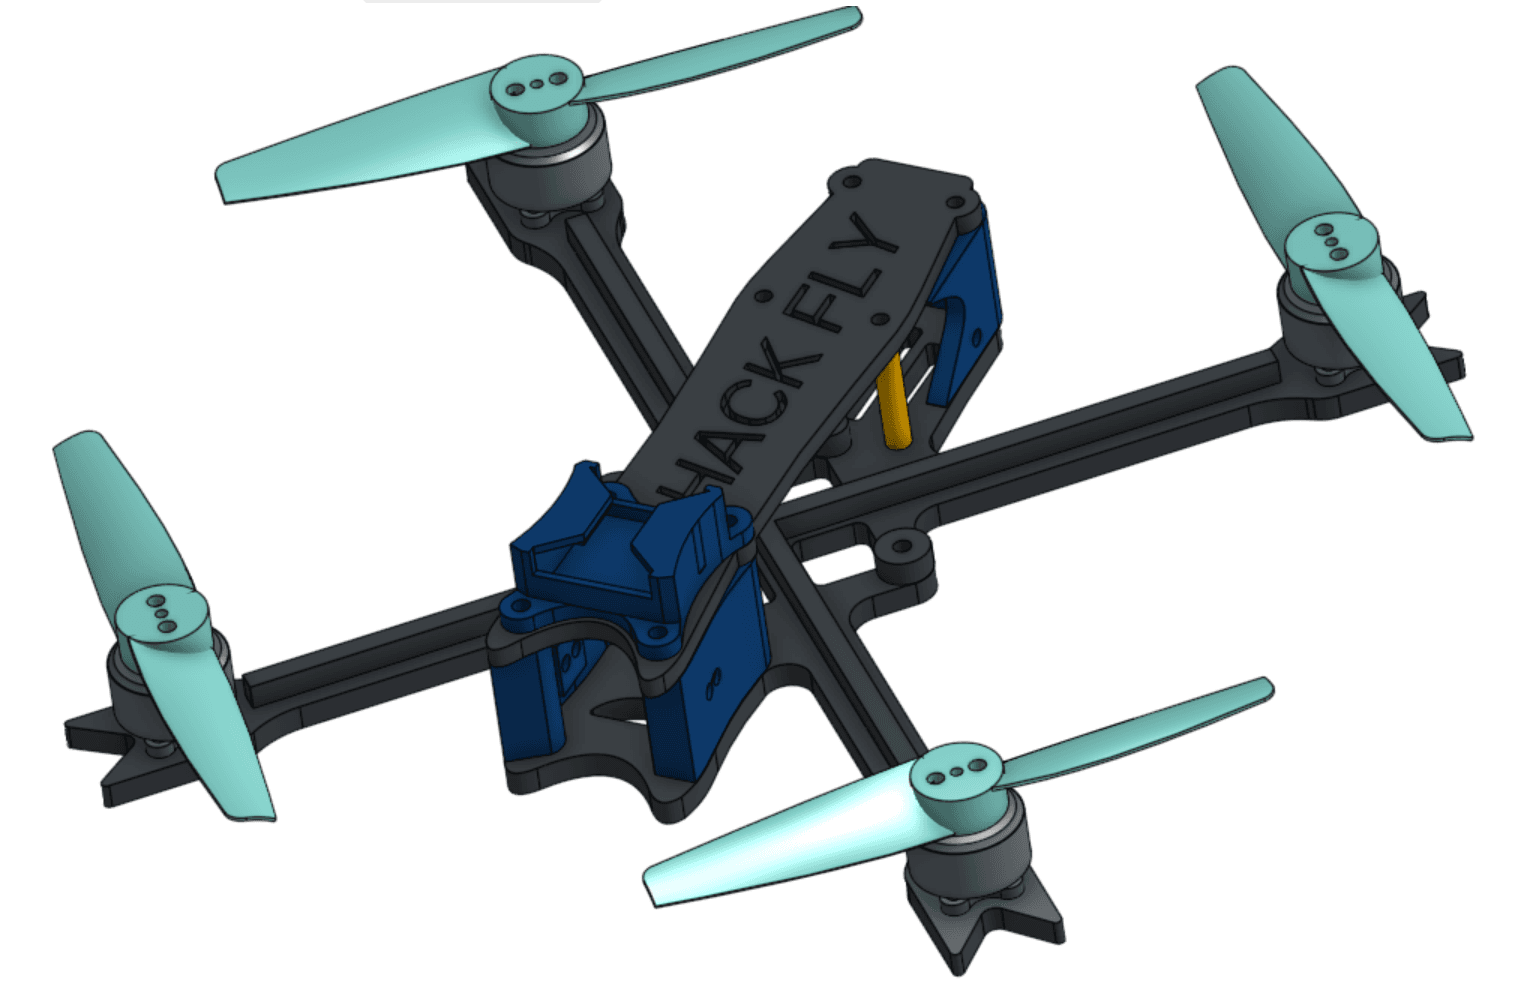
3D preview converted from github.com/minhazislamnafi/HACK-FLY-32 at 2e8cfc7, under CERN-OHL-S-2.0. View the original files from GitHub (6.4 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Compact 3-inch 3D-printed FPV drone designed for efficiency, stability and extended flight time.
- Runs Betaflight firmware on a custom flight controller board.
- Uses ExpressLRS (ELRS) for radio control communication.
- Supports GPS navigation with a 15x15mm GPS module (HGLRC M100 Mini suggested).
- Supports PPM, SBUS, IBUS and CRSF receiver protocols.
- Intended for long-range FPV, exploration and experimental flight testing.
- Battery support for 2S to 3S LiPo packs, with 900-1500mAh 3S suggested.
Bill of materials
32 parts32 of 32 parts shown
32 of 32 needed parts have no price in the source, so there is no parts total. Read from bom.csv at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Purchase the parts listed in the BOM
- 2Order the flight controller PCB using the Gerber file
- 3Solder the SMD components of the PCB by hand or order PCBs with SMT service
- 4Solder the ESCs and battery connector to the PCB using the wiring diagram
- 5Assemble everything
The guide appears here as you scroll.
Guide by @minhazislamnafi (README.md), under CERN-OHL-S-2.0.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Seeed Studio Xiao ESP32 S3 microcontroller board.
- MPU6050M QFN-24 motion sensor.
- Four 1104 4300KV motors.
- Four 2-3S micro 8A ESCs.
- Gemfan 3018 bi-blade propellers.
- 2.4GHz ELRS receiver.
- HGLRC M100 Mini GPS module.
- HGLRC Zeus Nano 350mW video transmitter (VTX).
- MP1584EN-LF voltage regulator and passive components, including red and green LEDs.
- Optional 18650 Li-ion battery for longer flight time.
Connections
- ESCs and the battery connector are soldered to the flight controller PCB following the wiring diagram.
- Pin headers (2.54mm) are used for connecting modules to the board.
- Wiring diagram is provided in the repository images.
Schematics, boards and diagrams
- docs/Images/wiring_diagram.pngDiagram
- Flight Controller/PCB/Gerber_HACK_FLY_PCB_V1.2_2026-04-11.zipGerber (PCB manufacturing)
- Flight Controller/PCB/Schematic_HACK_FLY_2026-04-11.svgDiagram
- Flight Controller/PCB/Source file/PCB_HACK_FLY_ALTIUM_2026-04-11.pcbdocAltium
- Flight Controller/PCB/Source file/PCB_PCB_HACK_FLY_EASYEDA_2026-04-11.jsonEasyEDA

