VLS-AGV
An open-source, low-cost autonomous guided vehicle (AGV) with vertical linear stage capabilities and modular expansion for robotic arm integration.
- Wheeled
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @zhangdong-cheku (opens in a new tab), from github.com/zhangdong-cheku/VLS-AGV (opens in a new tab). Pinned to commit 4b86f09 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo
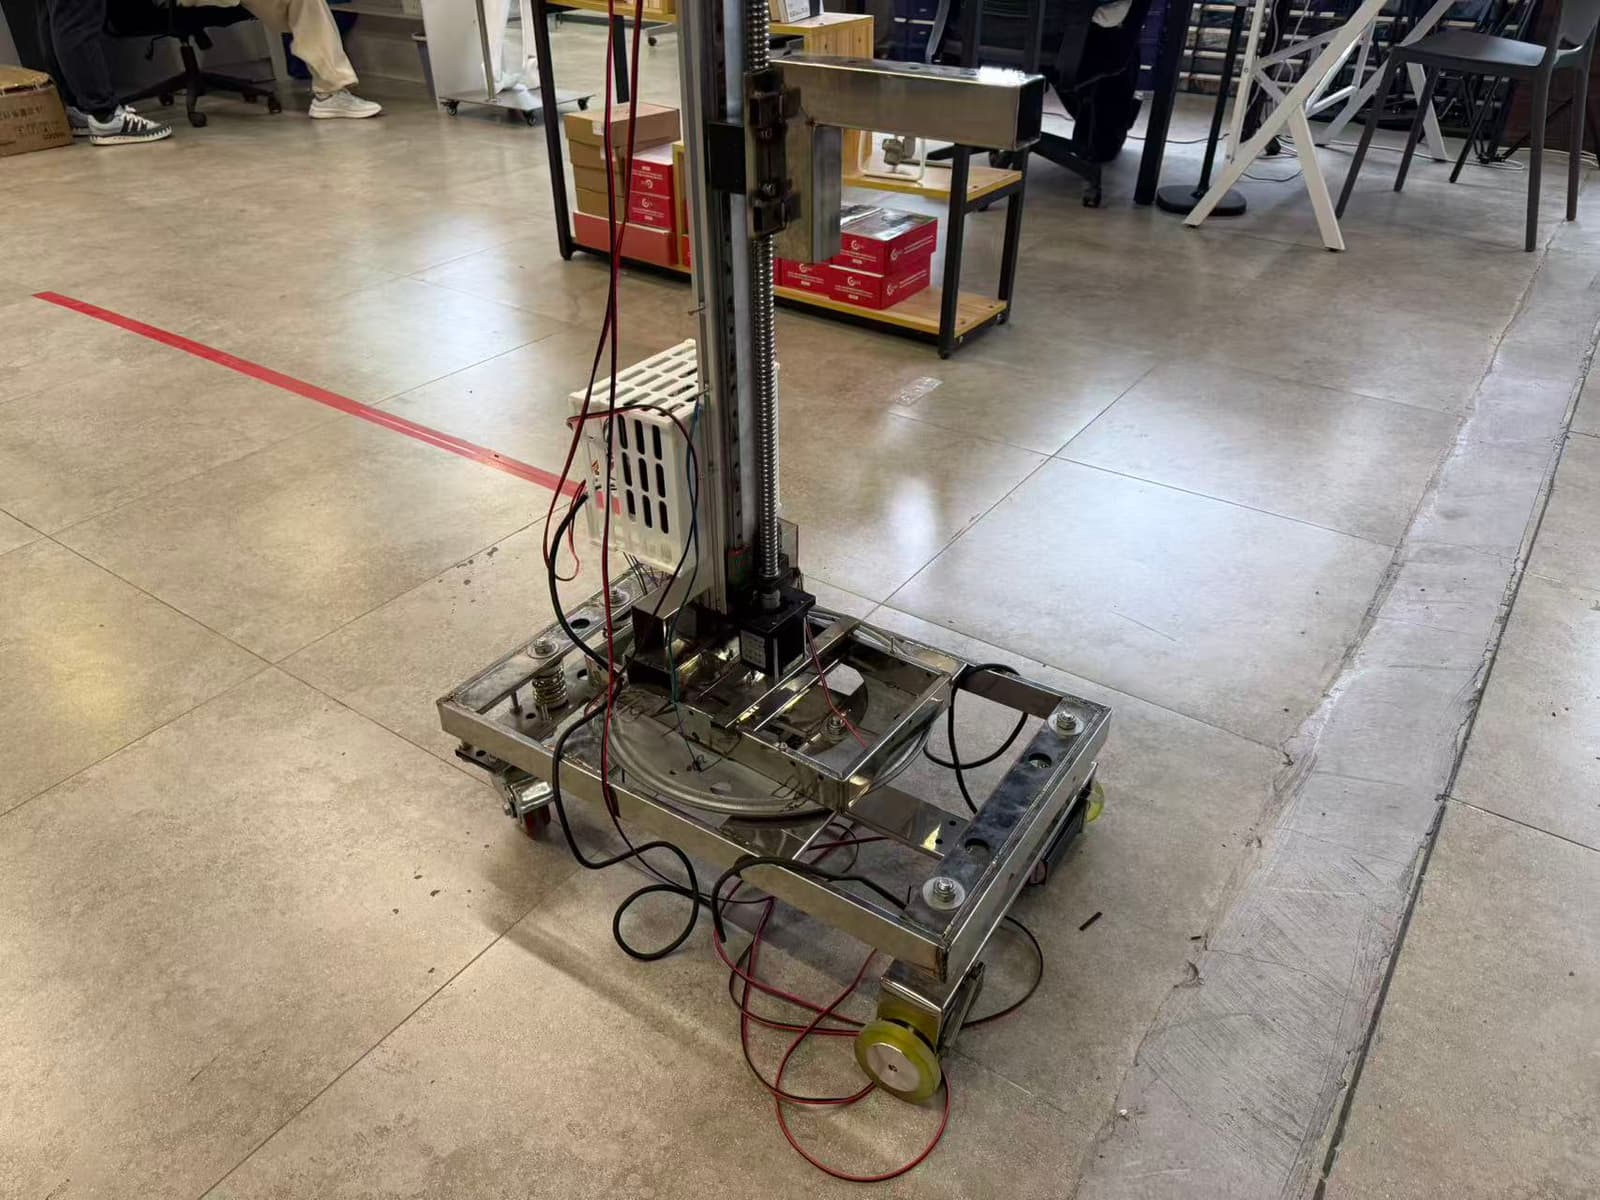
- Reach
- 412 mm
- Height
- 1,121 mm
- Weight
- 680 mm
What it can do
Written by Robotheca from the project's documents.
- Moves on flat floors using encoder metering wheels
- Rotates the upper structure with a servo for directional adjustment
- Moves a linear sliding module vertically for lifting tasks
- Supports attachment of a robotic arm for extended functionality
- Operates autonomously or can be manually controlled
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Assemble the chassis and base
- 2Install the slewing bearing and linear sliding module
- 3Mount the encoder metering wheels and stepping motors
- 4Connect the shock-absorbing springs
- 5Install the hollow turntable and servo motor
- 6Set up the Arduino-based control system
- 7Integrate the mechanical arm expansion base
The guide appears here as you scroll.
Guide by @zhangdong-cheku (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino controller board
- Stepper motor for driving the encoder metering wheel
- Servo motor for rotating the upper structure
- Linear sliding module for vertical movement
- Encoder for metering wheel feedback
- Battery for power supply
Connections
- Arduino connected to stepper motor driver for wheel control
- Servo motor wired to Arduino for upper structure rotation
- Encoder signals wired to Arduino for wheel feedback
- Linear sliding module connected to Arduino for vertical movement control