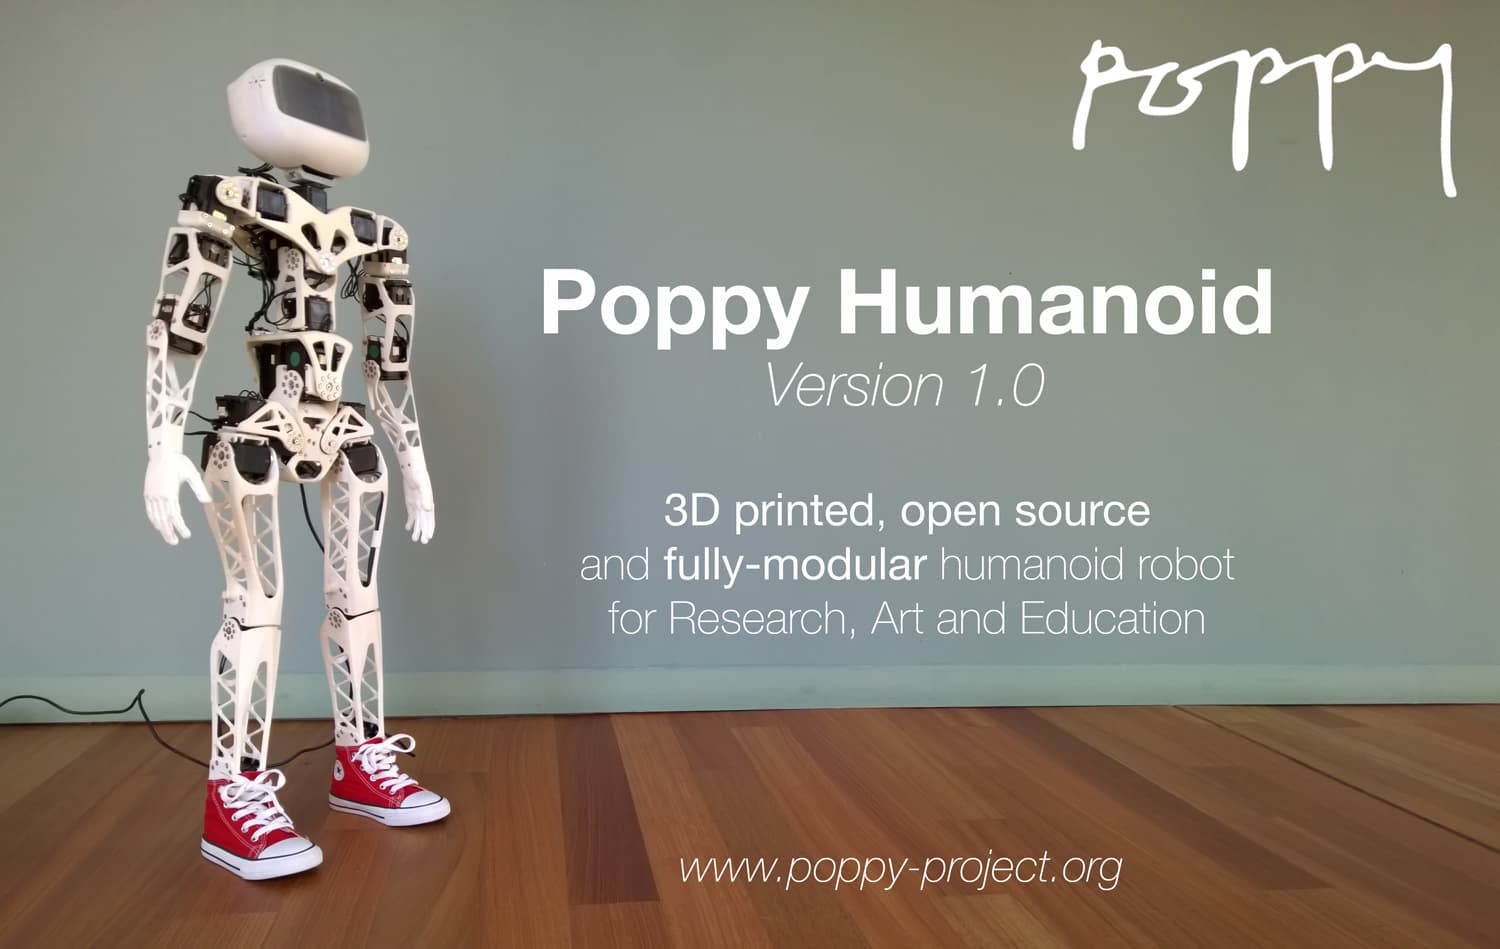
Poppy Humanoid
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
Robots whose repository includes a URDF model of the robot. 40 robots on Robotheca, each with its licenses and its source on GitHub.
Page 2 of 2 · Ready to build first, then by buildability
An open-source, 3D printed humanoid robot designed for research and education, with modular parts for many applications and experiments.
A 7-DOF personal robotic arm with ROS-based simulation and control.
An open-source 6-DOF collaborative robotic arm system with mechanical structure, electronics, and software.
An open-source 6-degree-of-freedom robotic arm designed for simulation, kinematics research, and reinforcement learning-based end-effector control.
A 6-DOF camera arm with a ZED Mini stereo camera that streams video to a WebXR VR headset and follows head tracking for teleoperation.
An open-source desktop quadruped robot featuring high-torque HTDW4438 motors, URDF models, and real-machine SDK for development and Sim2Real integration.
NormaCore is a unified open-source toolkit and platform for developing and operating physical systems, including a 7+1 DoF 3D-printed robotic arm (ElRobot) and a desk lamp.
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
A modular humanoid robot designed for research and education with ROS2 integration.
An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
An open-source, low-cost humanoid robot designed for AI experimentation and education.
An open-source humanoid robotics research platform that minimizes leg inertia by concentrating mass near the limb roots using timing belts and parallel linkages.
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
A fully open-source, low-cost, 3D-printable bipedal robot designed for hobbyists, educators, and researchers.
A 40 cm-class open-source humanoid robot designed for education and algorithm verification, featuring 10 DOF and Damiao actuators.
Robots 25–40 of 40