LeLamp
An open-source expressive robot lamp with 5-axis servo movement, Pi Camera vision, microphone and speaker audio, and 24 programmable LEDs for expressions.
- Home
- Open source
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @humancomputerlab (opens in a new tab), from github.com/humancomputerlab/LeLamp (opens in a new tab). Pinned to commit 4a0ef2c (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
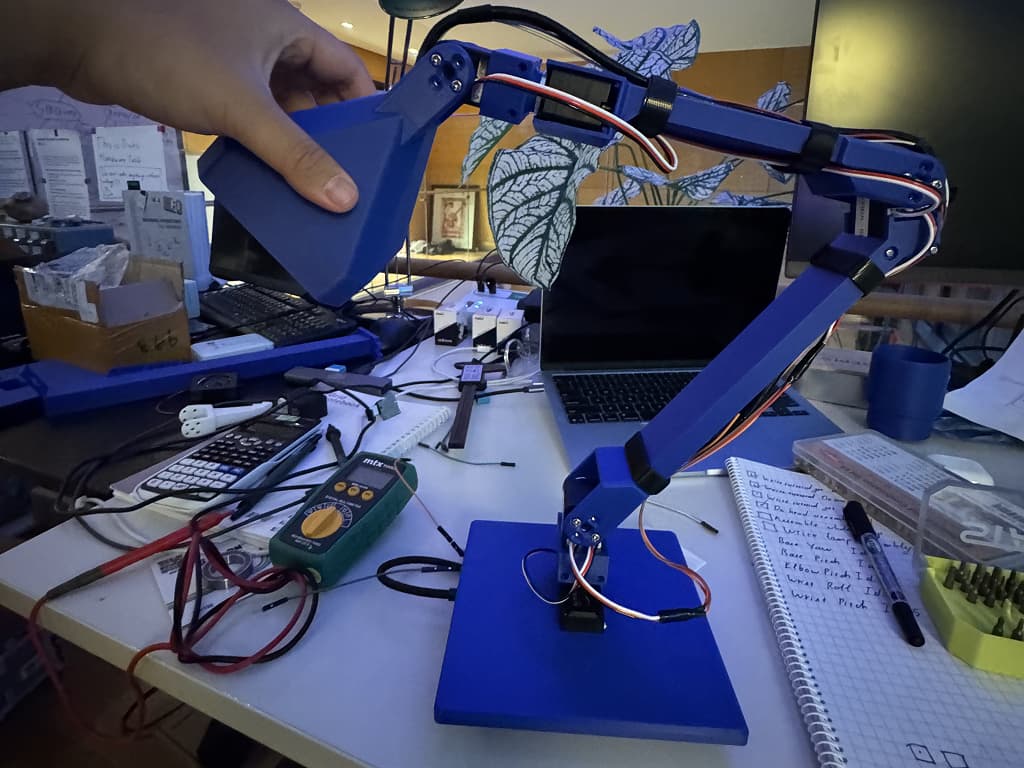
3D preview converted from github.com/humancomputerlab/LeLamp at 4a0ef2c, under GPL-3.0-only. View the original files from GitHub (4.8 MB) (opens in a new tab)
- Degrees of freedom
- 5
What it can do
Written by Robotheca from the project's documents.
- Five-axis articulated movement driven by servo motors for expressive lamp motion
- Computer vision through a Pi Camera
- Audio interaction using a microphone and speaker
- LED expressions using 24 programmable LEDs
- Record and replay of custom movements
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Prerequisites & Planning
- 2Components & 3D Printed Parts
- 3Lamp Assembly
- 4Lamp Setup
- 5Lamp Control
- 6Common Issues
The guide appears here as you scroll.
Guide by @humancomputerlab (README.md), under GPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi controlling servos, audio and LEDs, mounted in the base
- ReSpeaker Hat on the Raspberry Pi for audio
- Motor driver board driving the servo motors
- STS3215 servo motors for the lamp joints
- Speaker rated 4 ohm / 3 W in the lamp head
- WS2812B programmable LED matrix in the lamp head
- Two power supplies: a 5V 2A DC supply for servos and a 5V 2A USB Type-C charger for the Raspberry Pi
Connections
- Head connects to base through a stripped Ethernet cable carrying power and data
- Ethernet wires follow color convention: black for GND, red for 5V, yellow for data
- Motor driver connects to the Raspberry Pi over USB Type-C
- ReSpeaker Hat header pins are matched to the head wires, with a JST2.0 connector for the speaker
- Servos are daisy-chained from the wrist pitch servo to the base yaw servo, which connects directly to the motor driver
