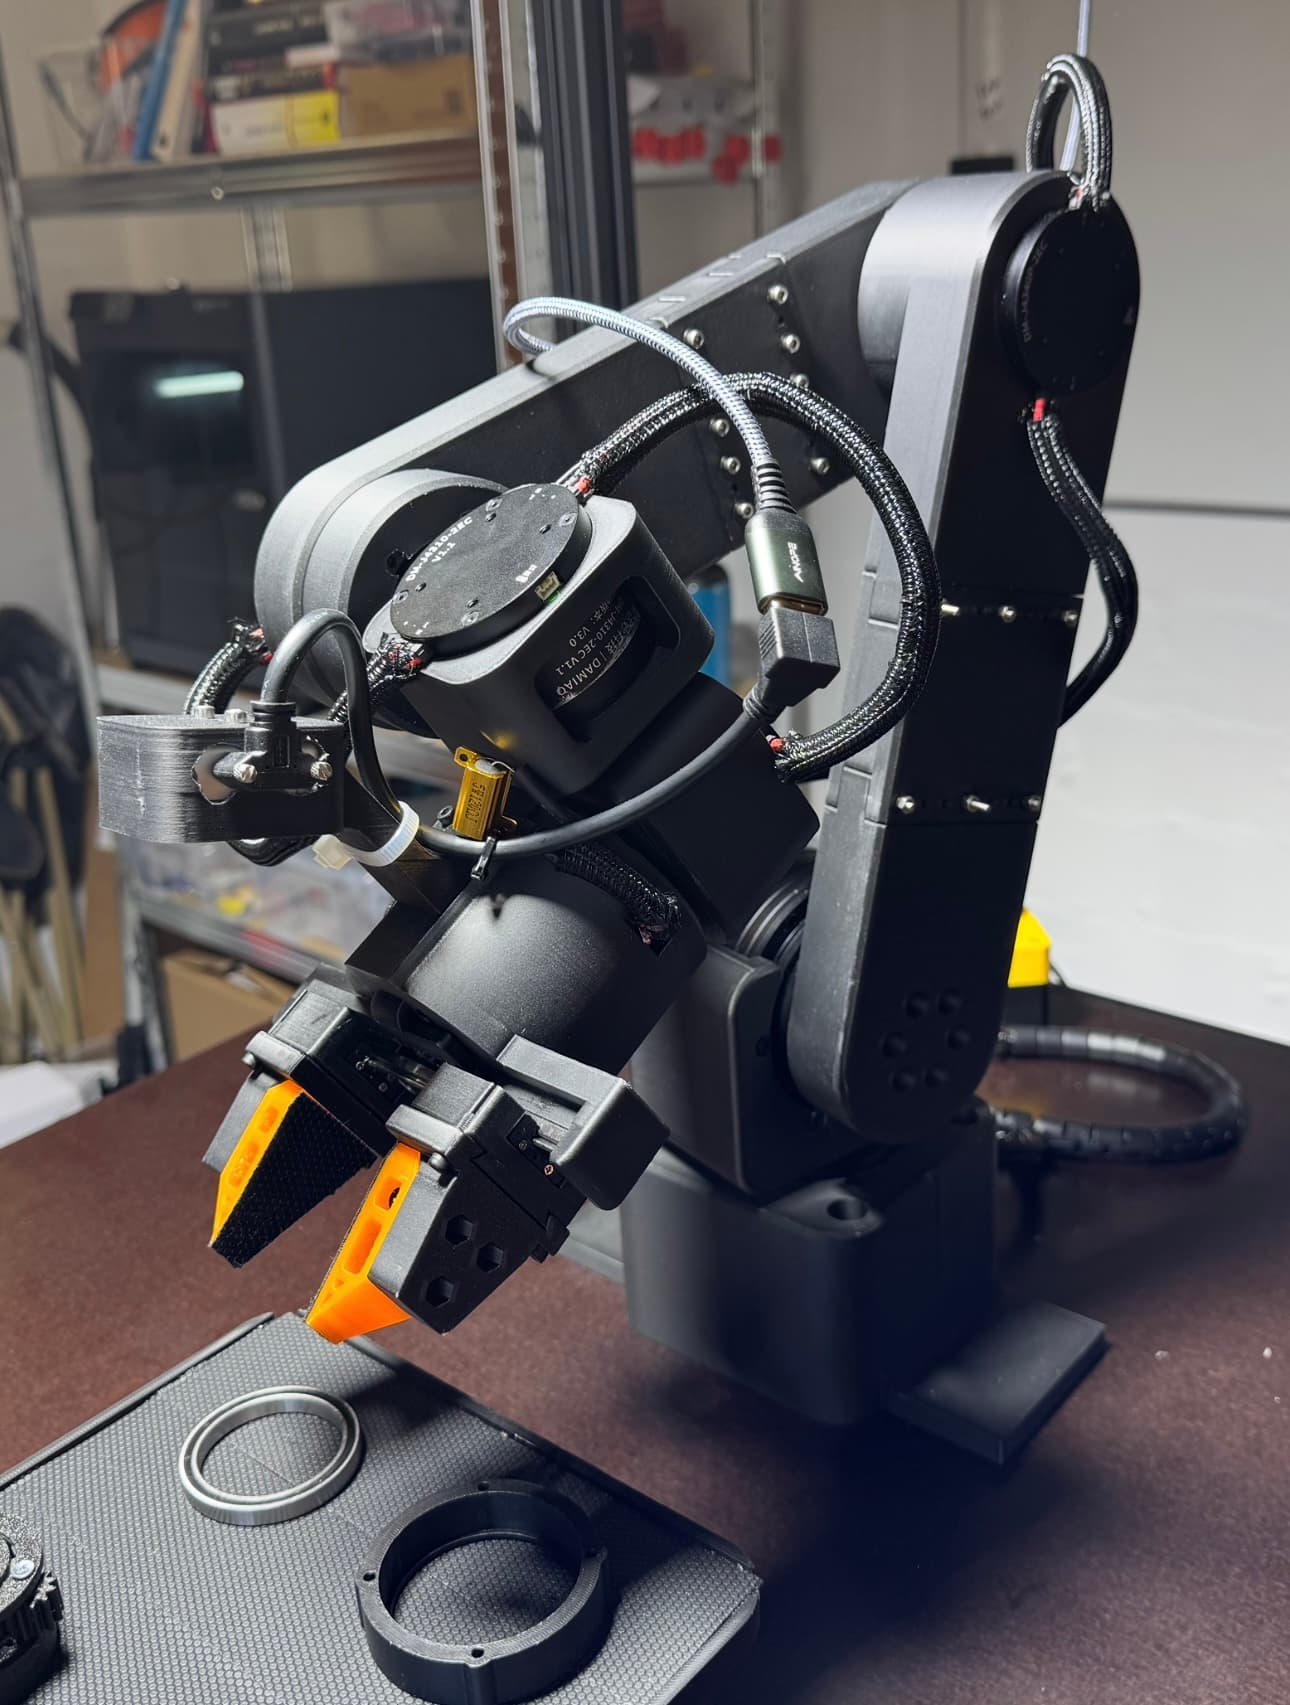
 Robot arm
AIRA
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
- Works with AI
- Level
- Advanced
- Buildability
- 57/100
- Buildable with some effort
- Cost
- €2,000
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 3 of 12 · Ready to build first, then by buildability
Robot armA 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
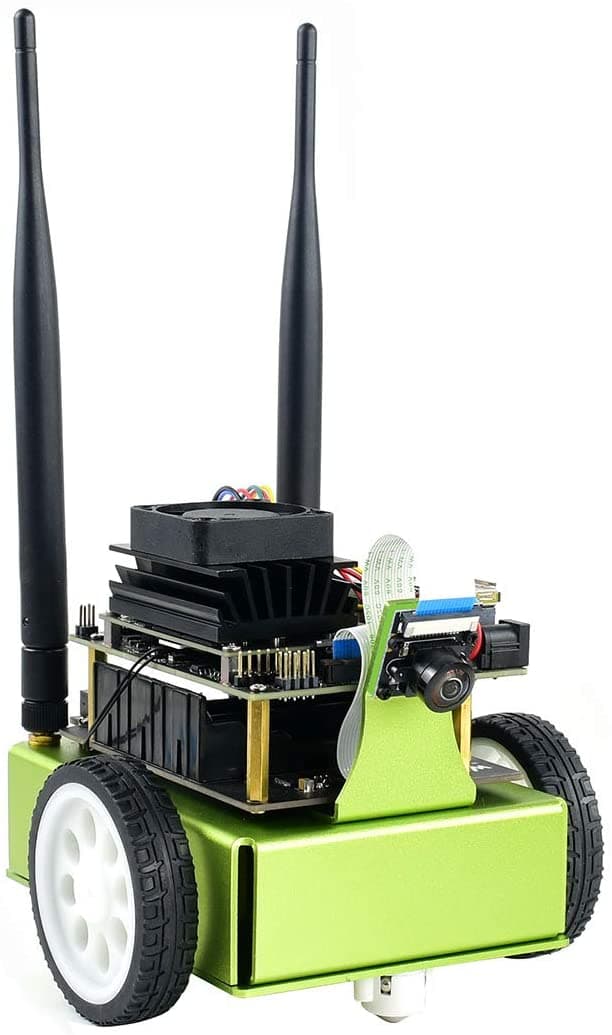 Wheeled
An educational open-source AI robot platform built on NVIDIA Jetson Nano for learning and experimenting with AI-based motion and collision avoidance.
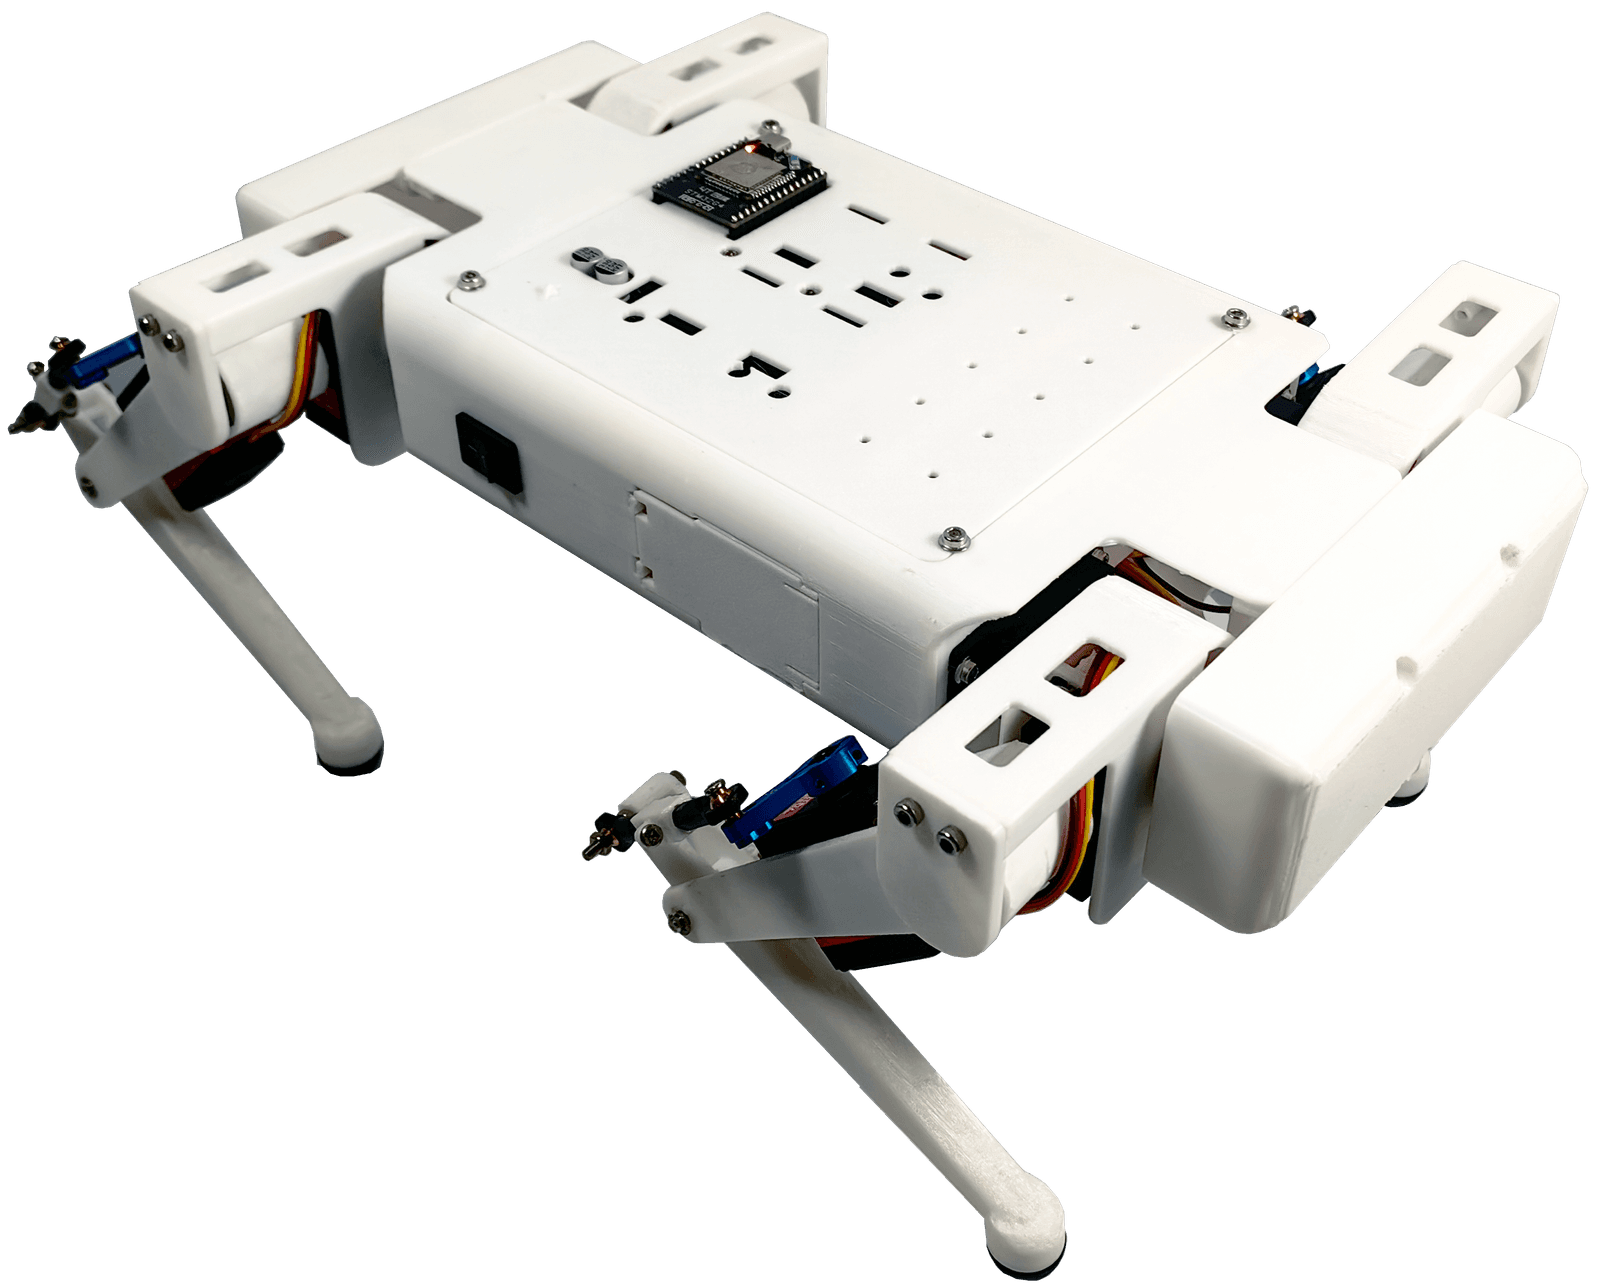 Quadruped
An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
A modular humanoid robot designed for research and education with ROS2 integration.
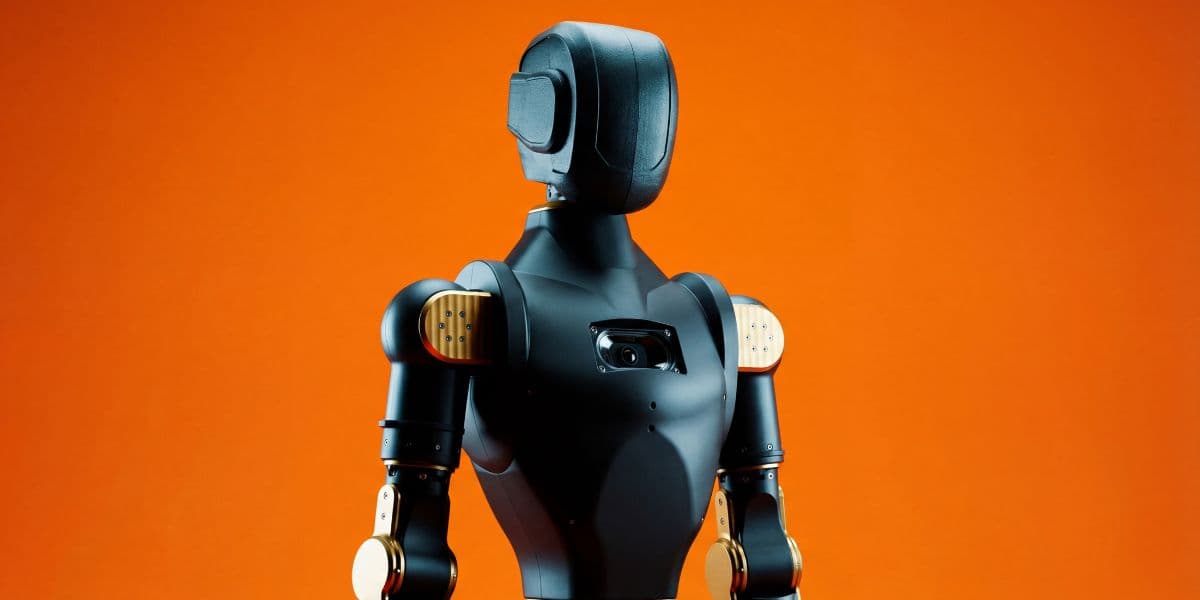 Humanoid
An open-source 1.2 m, 35 kg humanoid biped with 25 actuated degrees of freedom that can be built, simulated and customized.
 Other
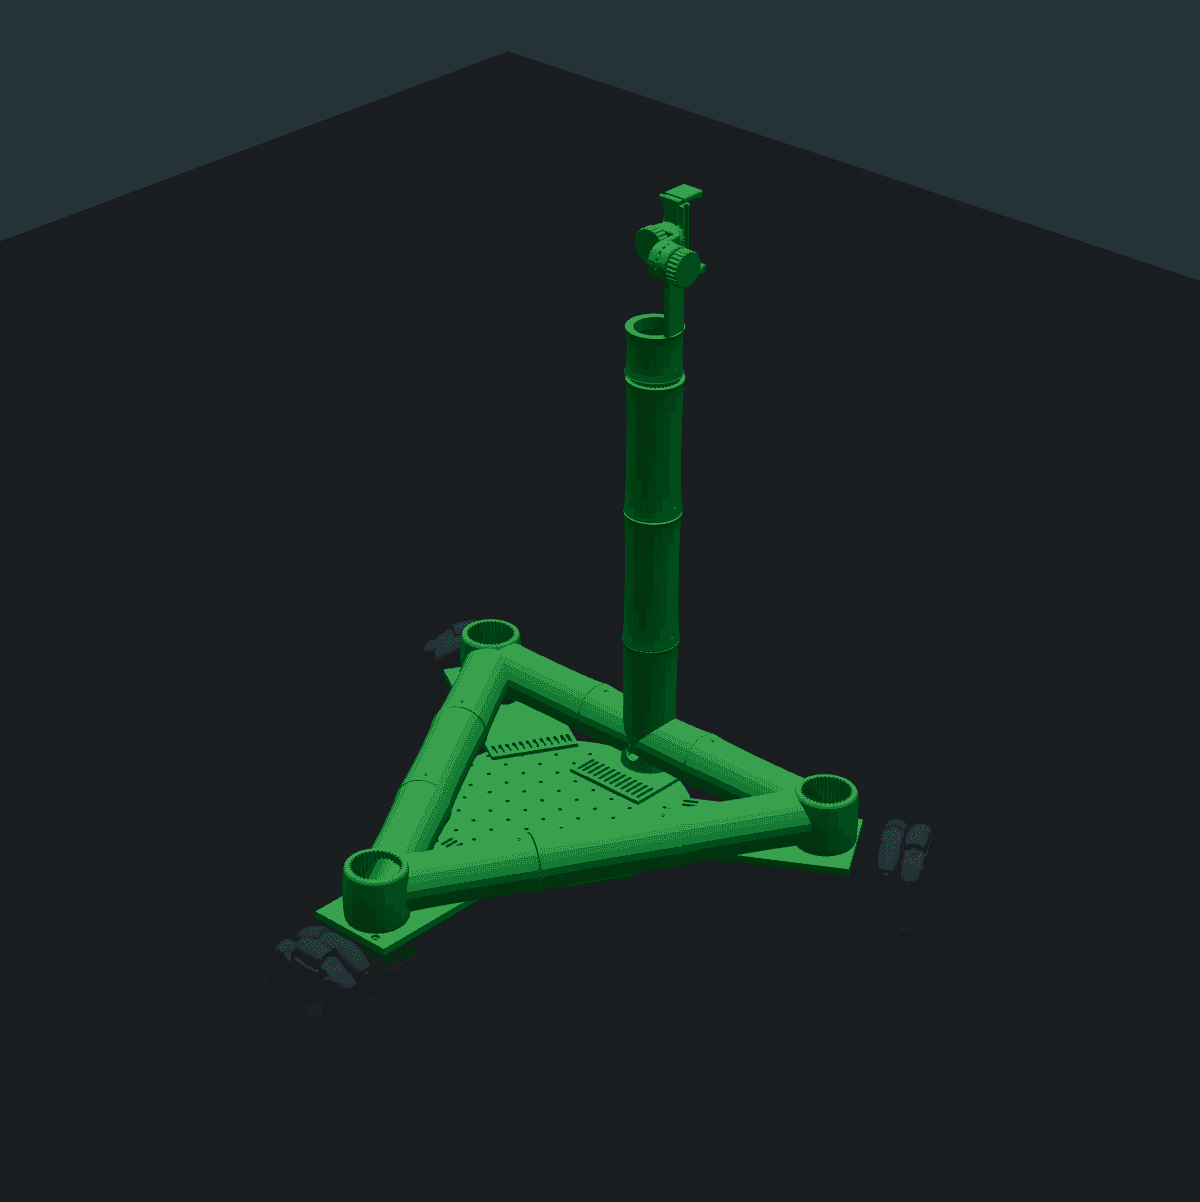
A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.
 Humanoid
An open-source, low-cost humanoid robot designed for AI experimentation and education.
An open-source humanoid robotics research platform that minimizes leg inertia by concentrating mass near the limb roots using timing belts and parallel linkages.
 Other
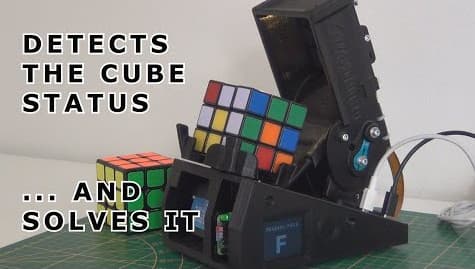
A small, 3D printed robot that solves a Rubik's cube autonomously on a Raspberry Pi.
 Other
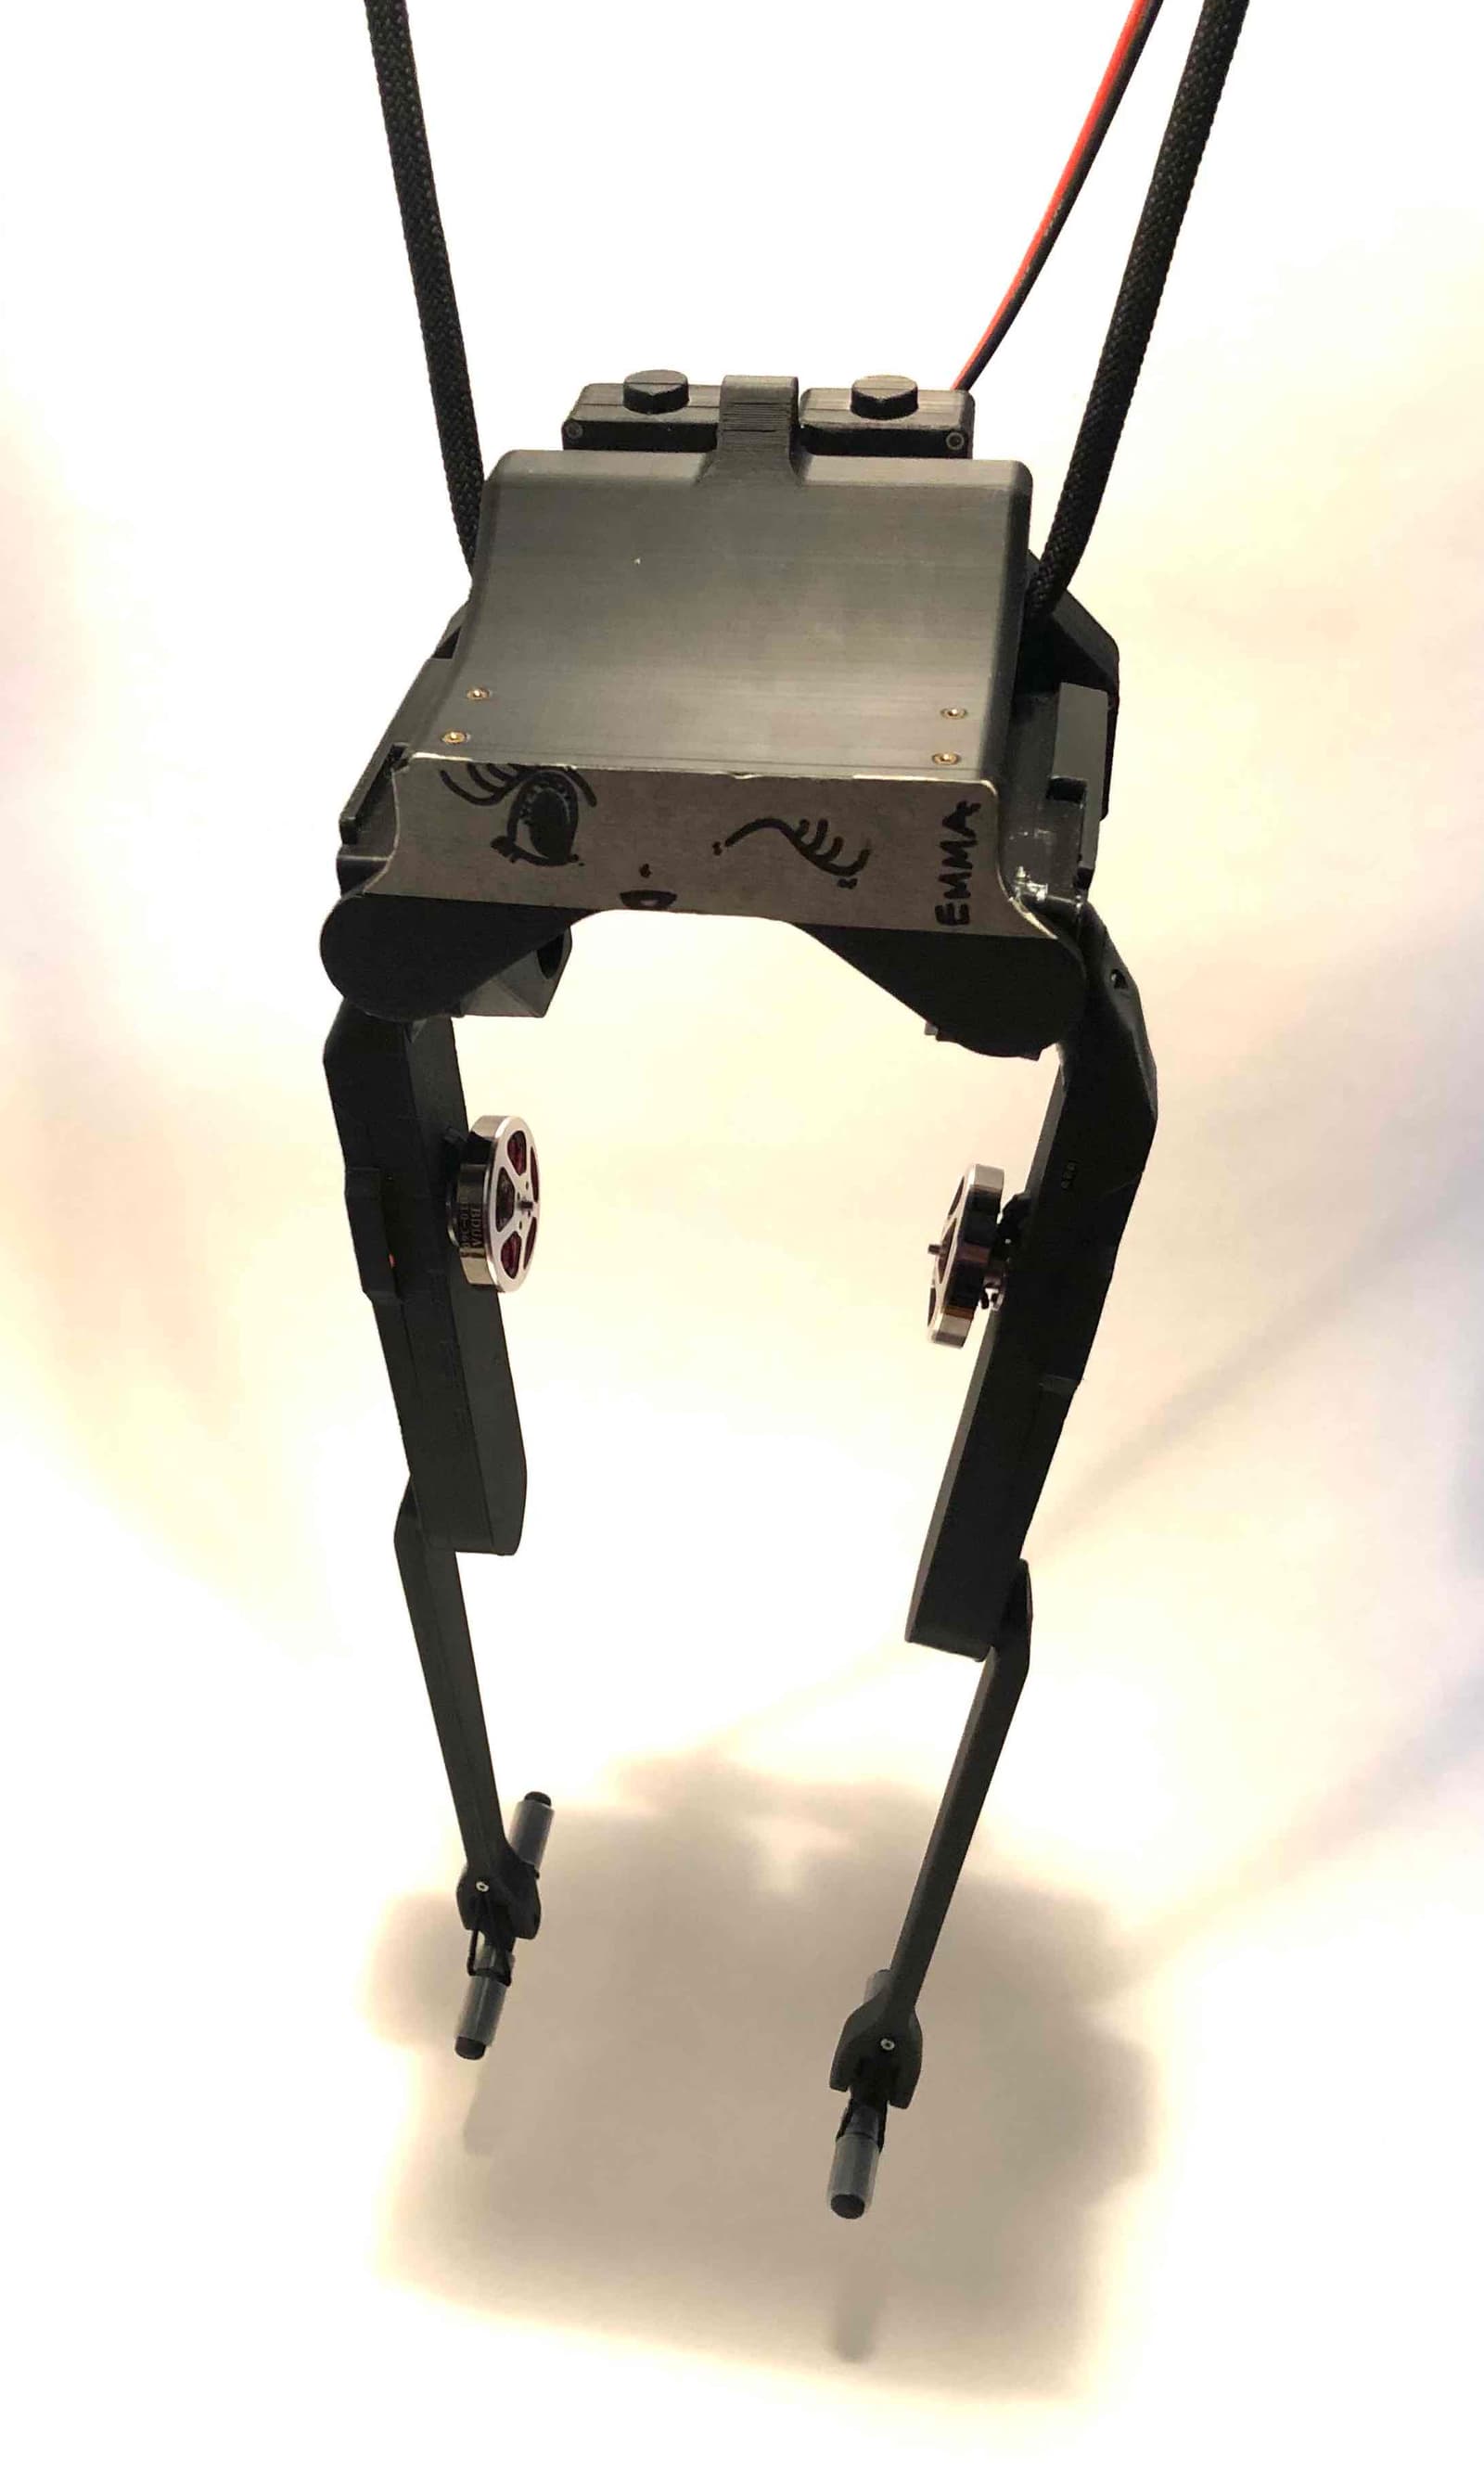
A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.
 Humanoid
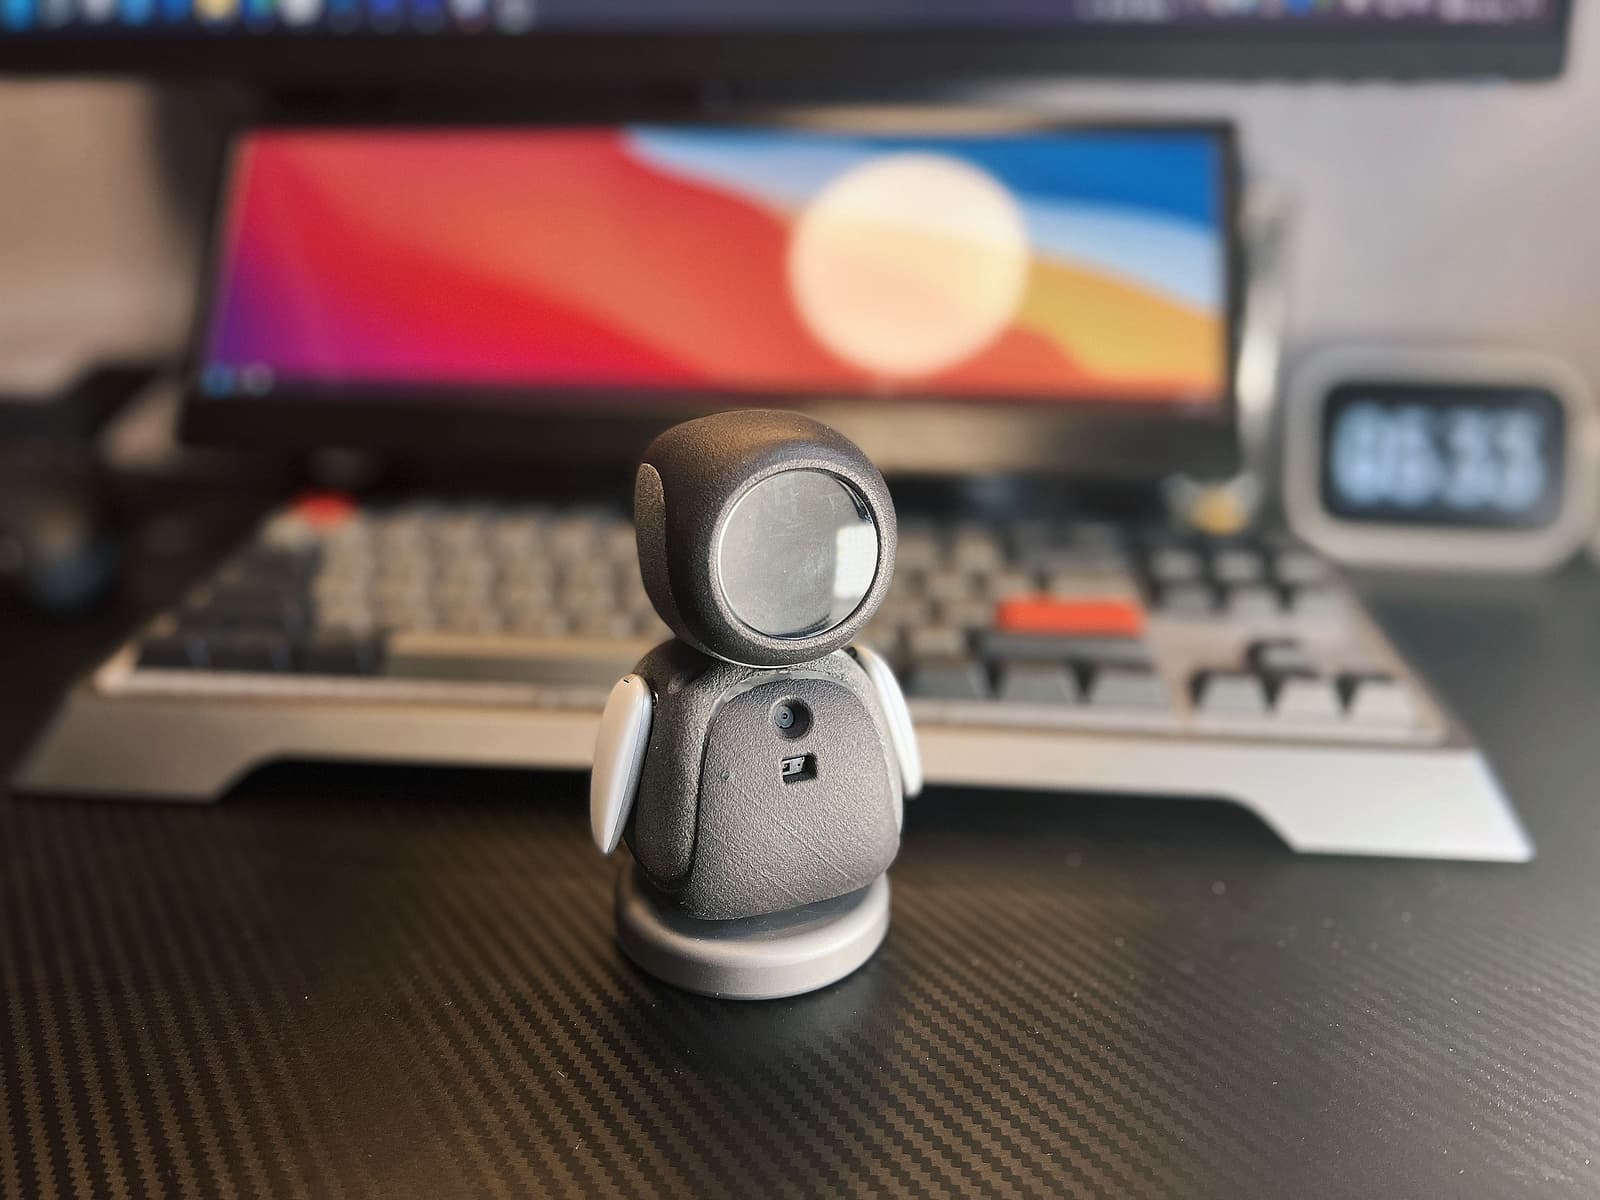
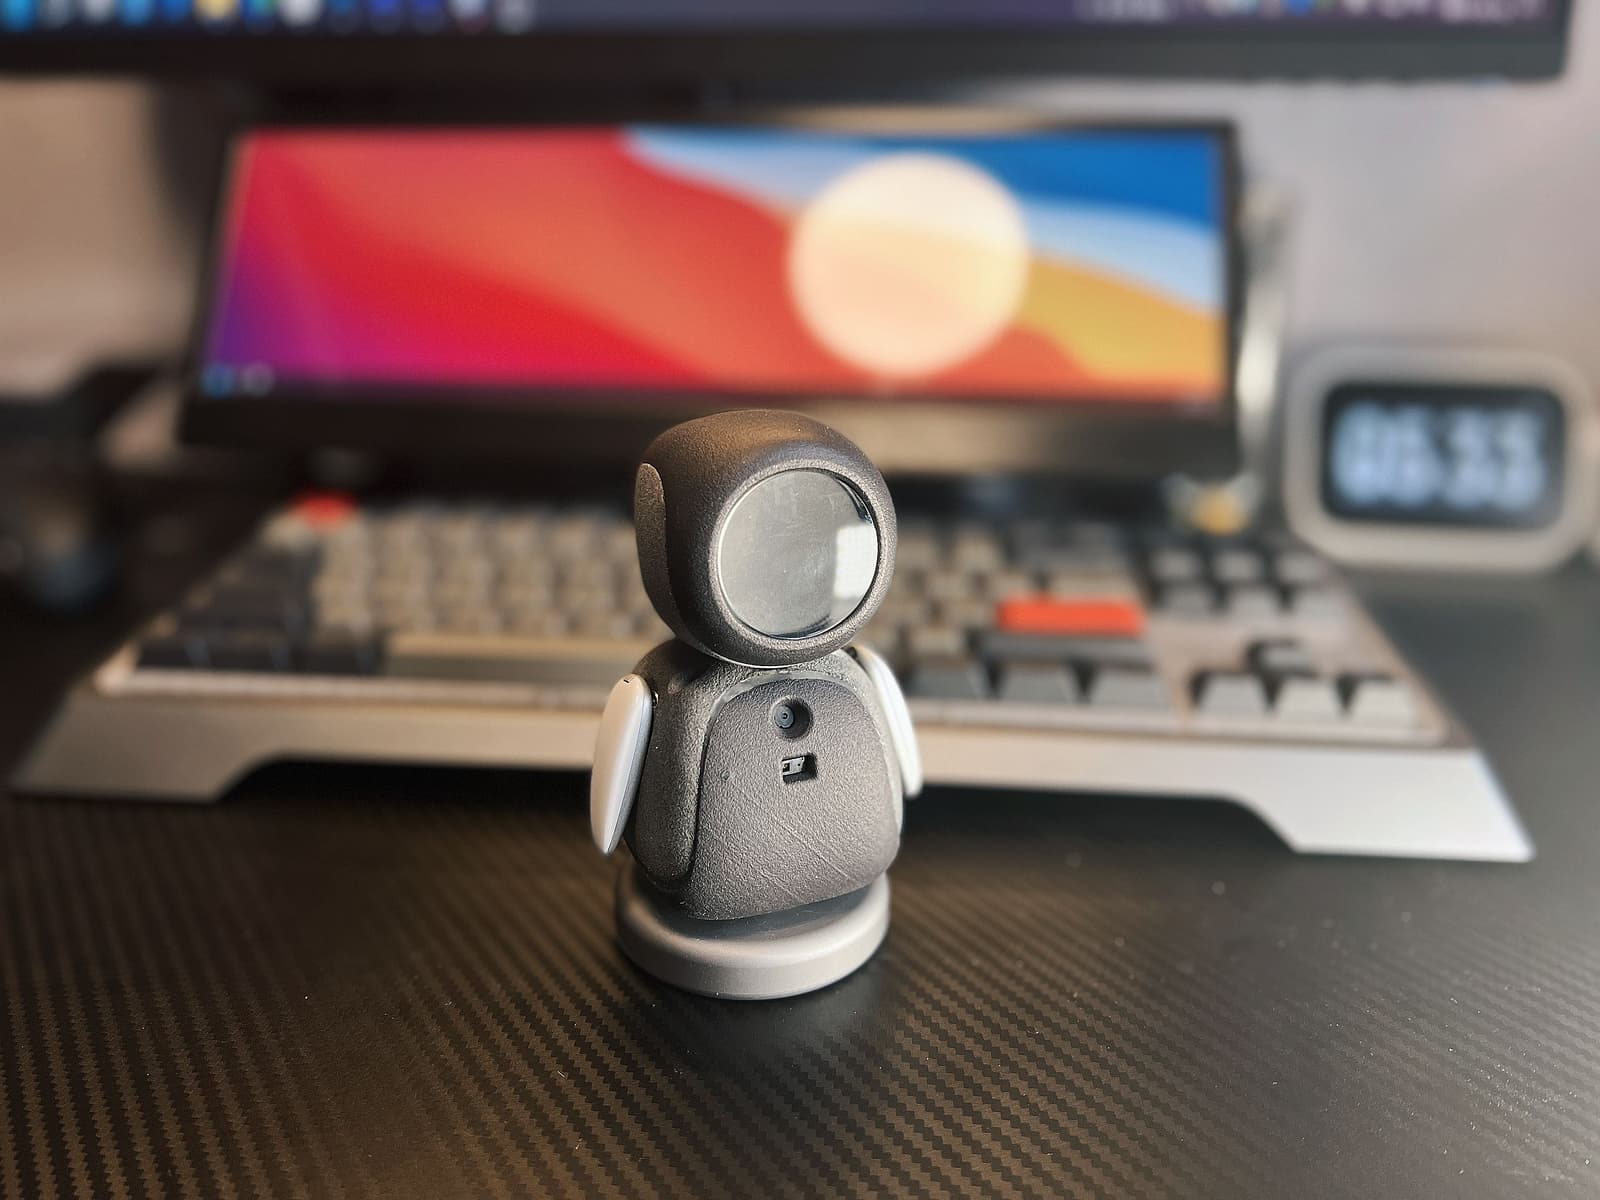
A mini desktop robot with 6 degrees of freedom, USB communication, and a display screen, inspired by WALL-E's EVE.
 Robot arm
A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.
 Self-driving 1:10
An autonomous self-balancing bicycle robot designed for outdoor track racing, featuring lane detection, obstacle recognition, and balance control algorithms.
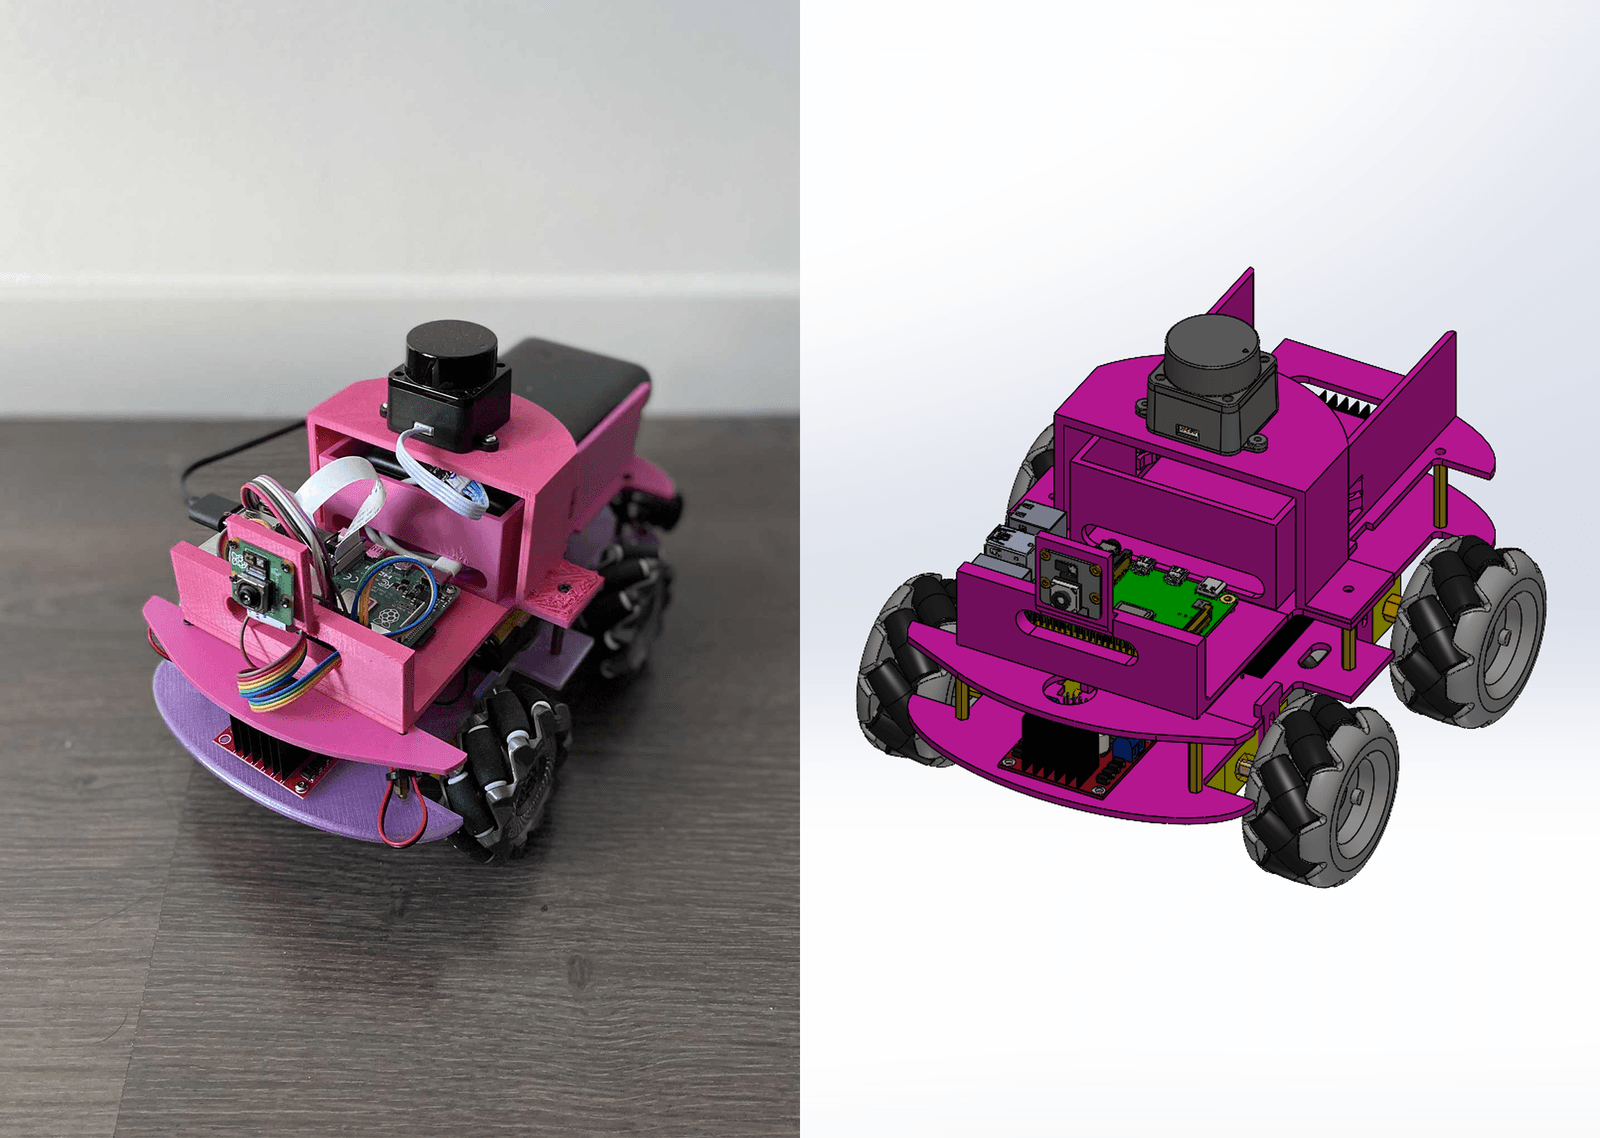 Wheeled
An open-source autonomous mecanum wheel robot for learning and experimentation that navigates manually or autonomously using a Lidar.
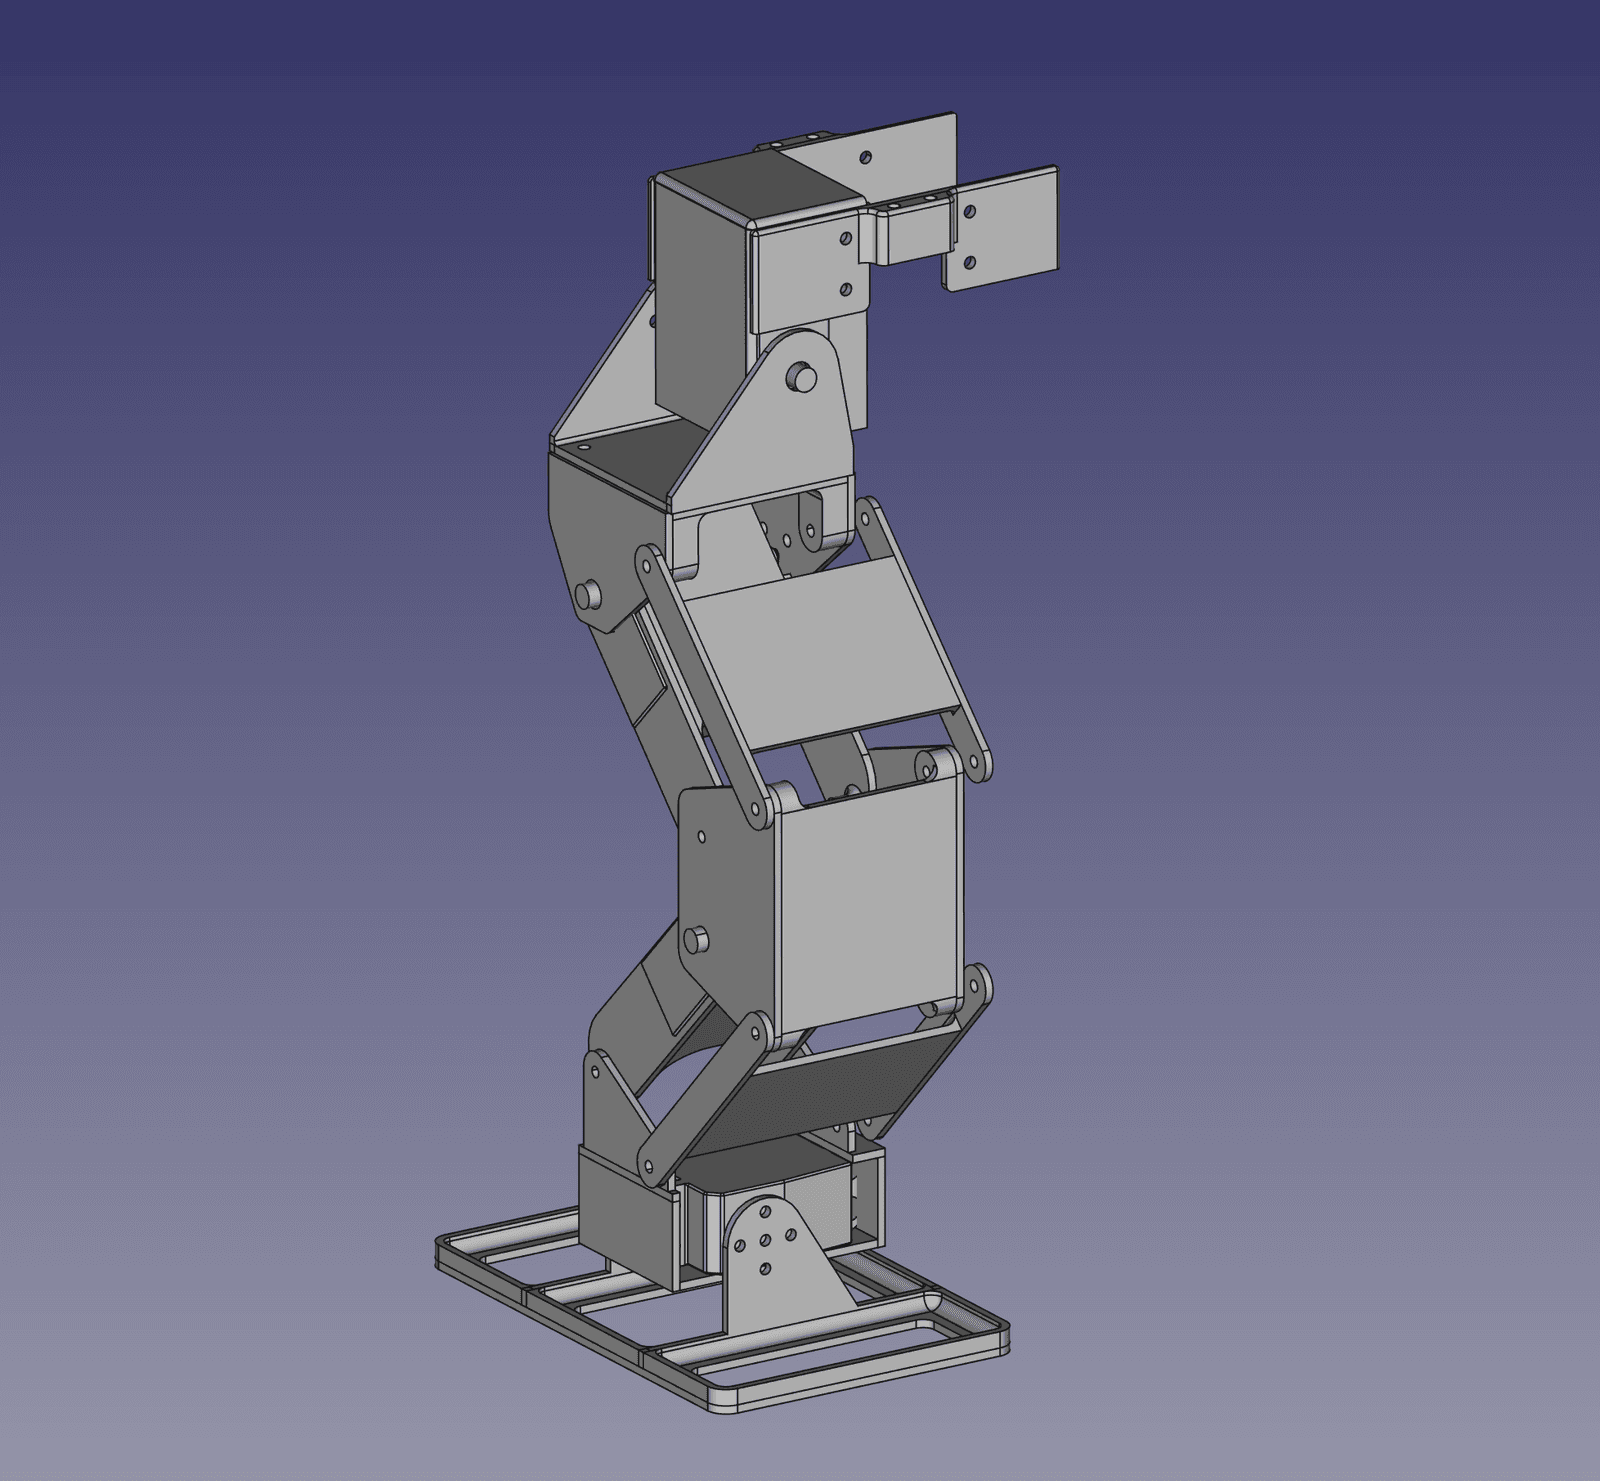 Humanoid
An easy to modify, 3D printable open-source humanoid robot evolved by the community that walks, lifts and can be simulated.
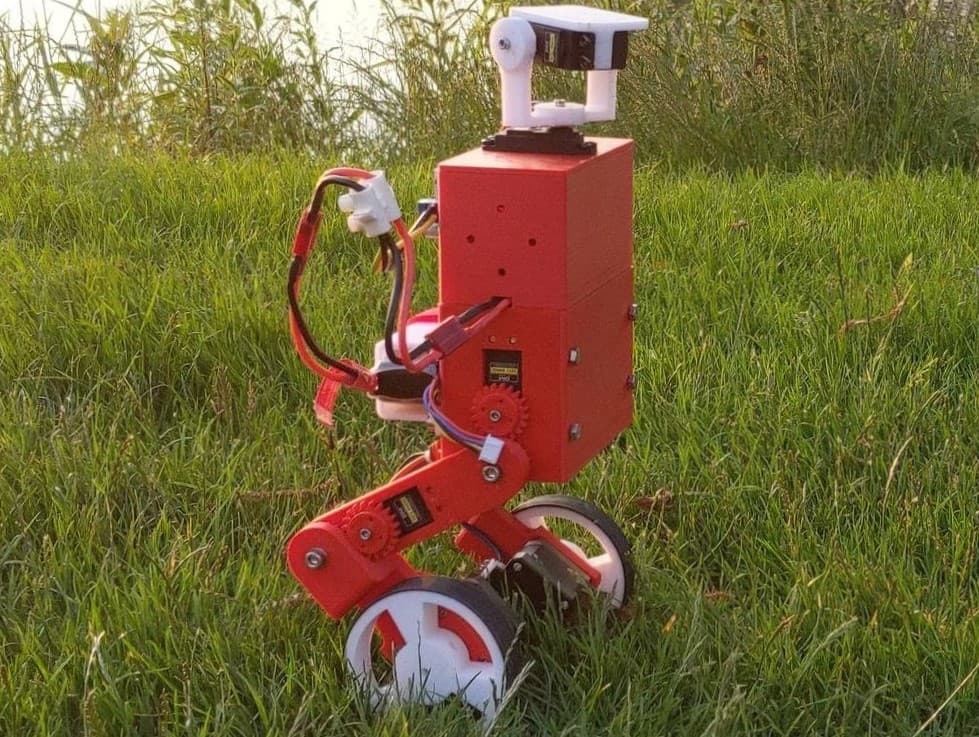 Other
MABEL is an open-source legged balancing robot based on the Boston Dynamics Handle, with articulated legs that can adjust height and balance in multiple axes.
A tiny desktop two-wheeled legged robot with ESP32 control and brushless motors.
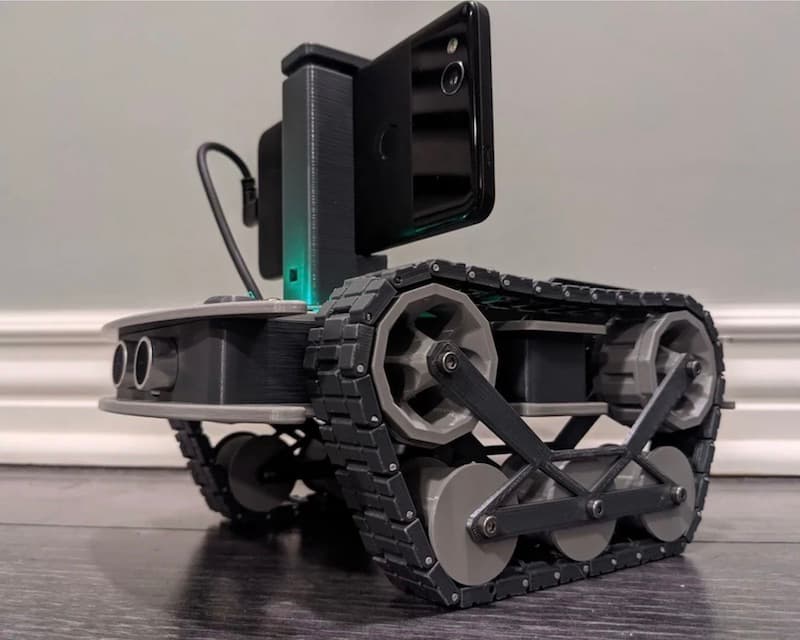 Wheeled
A low-cost small electric vehicle body that uses an Android smartphone as its brain, supporting person following and autonomous navigation.
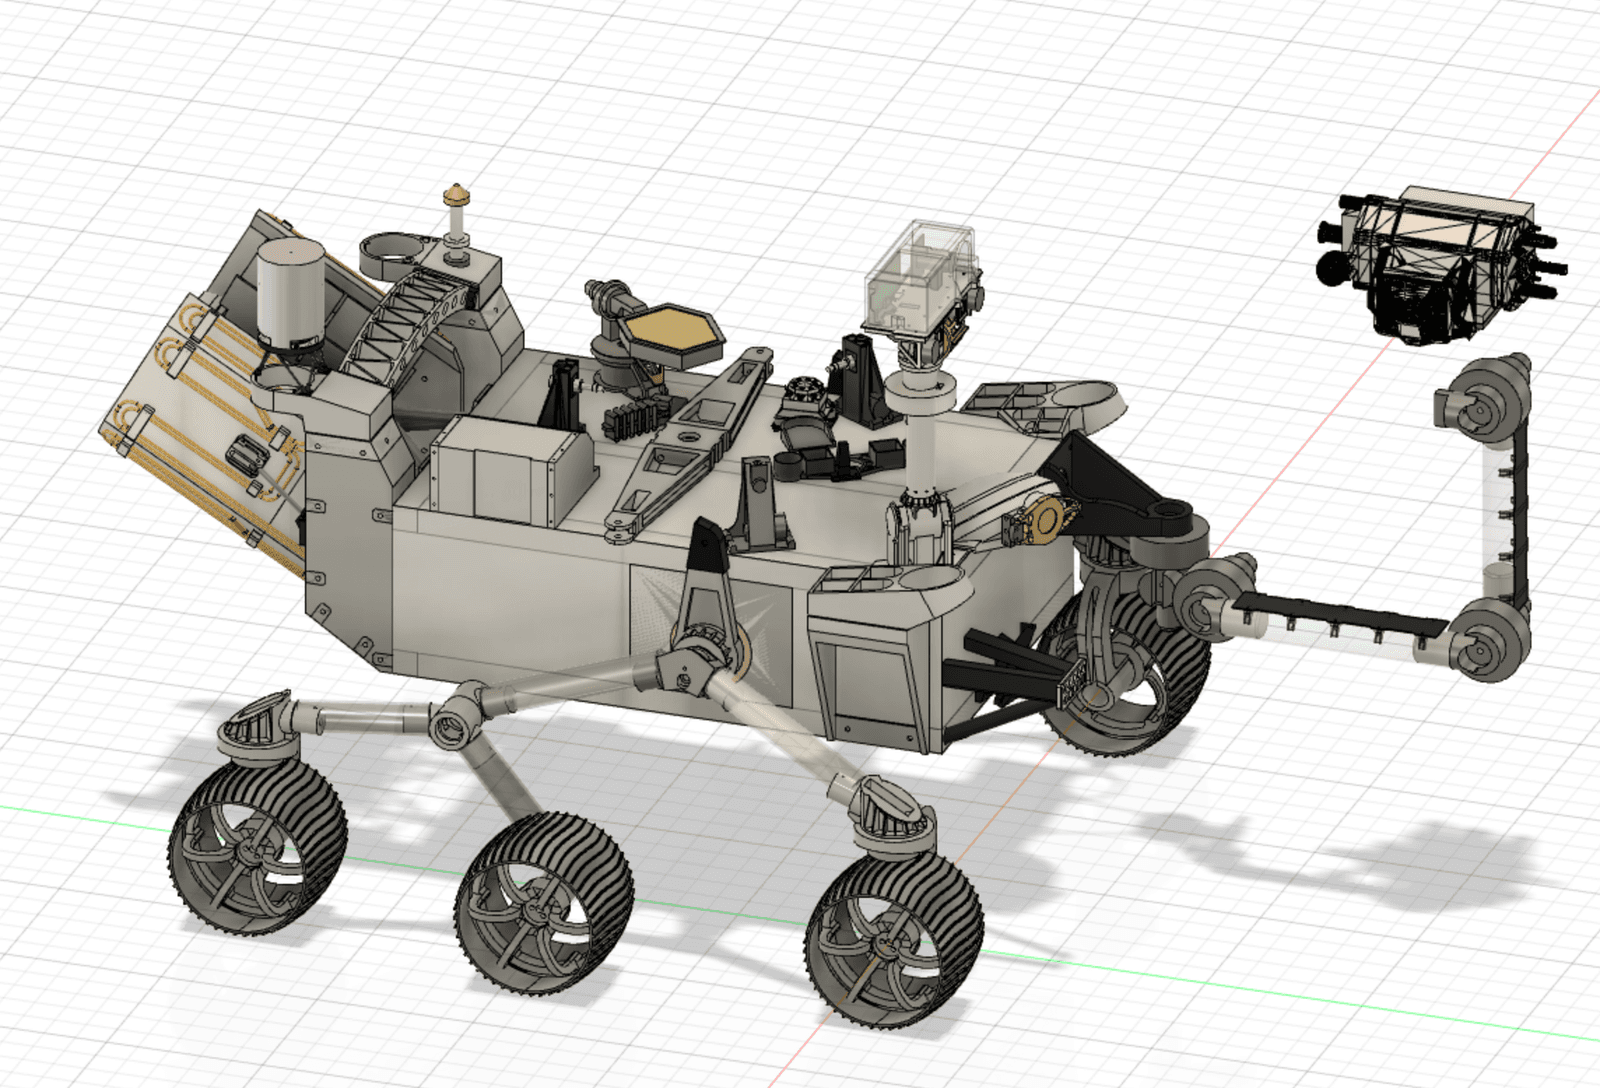 Wheeled
A 3D printed, remote controlled rover modeled on NASA's Perseverance Mars rover, built from open-source printable parts.
Open-source, fully 3D-printable ESP32 rover platform with WiFi or ExpressLRS control, available in two variants.
 Other
A low-cost, modular open-source soft robotics platform with tendon-driven continuum robots controlled by force-feedback actuators over serial and I2C.
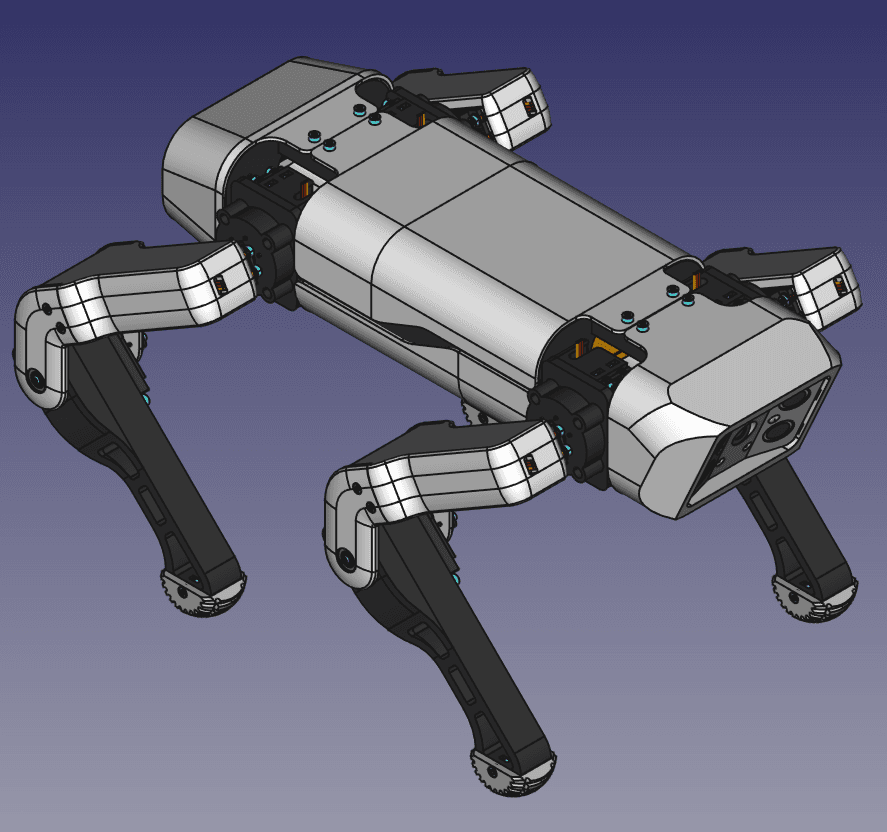 Quadruped
A 3D-printable quadruped robot dog with support-free printed parts, controlled by an ESP32-DevKitC with heavy computation offloaded to external devices.
 Wheeled
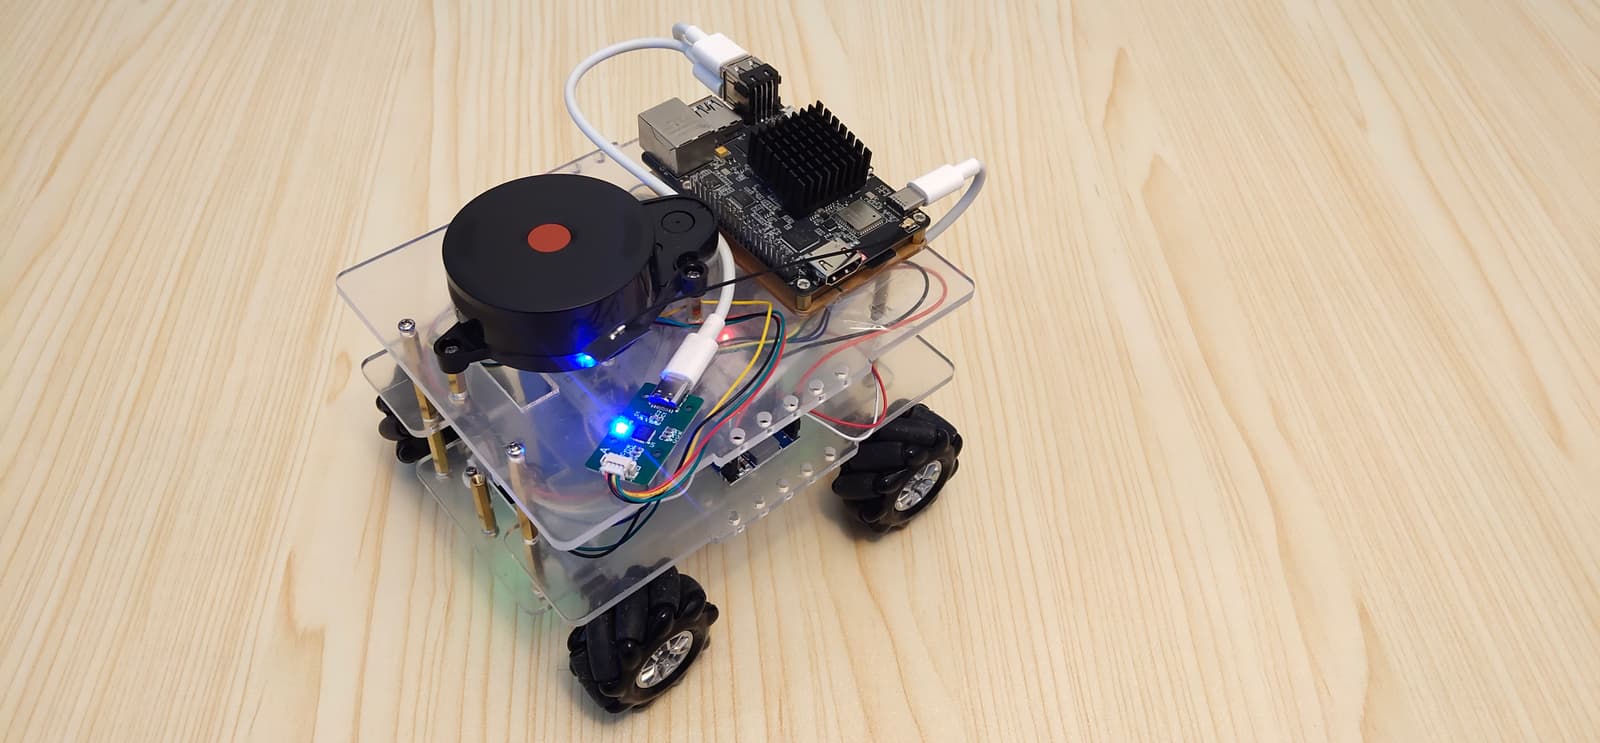
A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.
 Wheeled
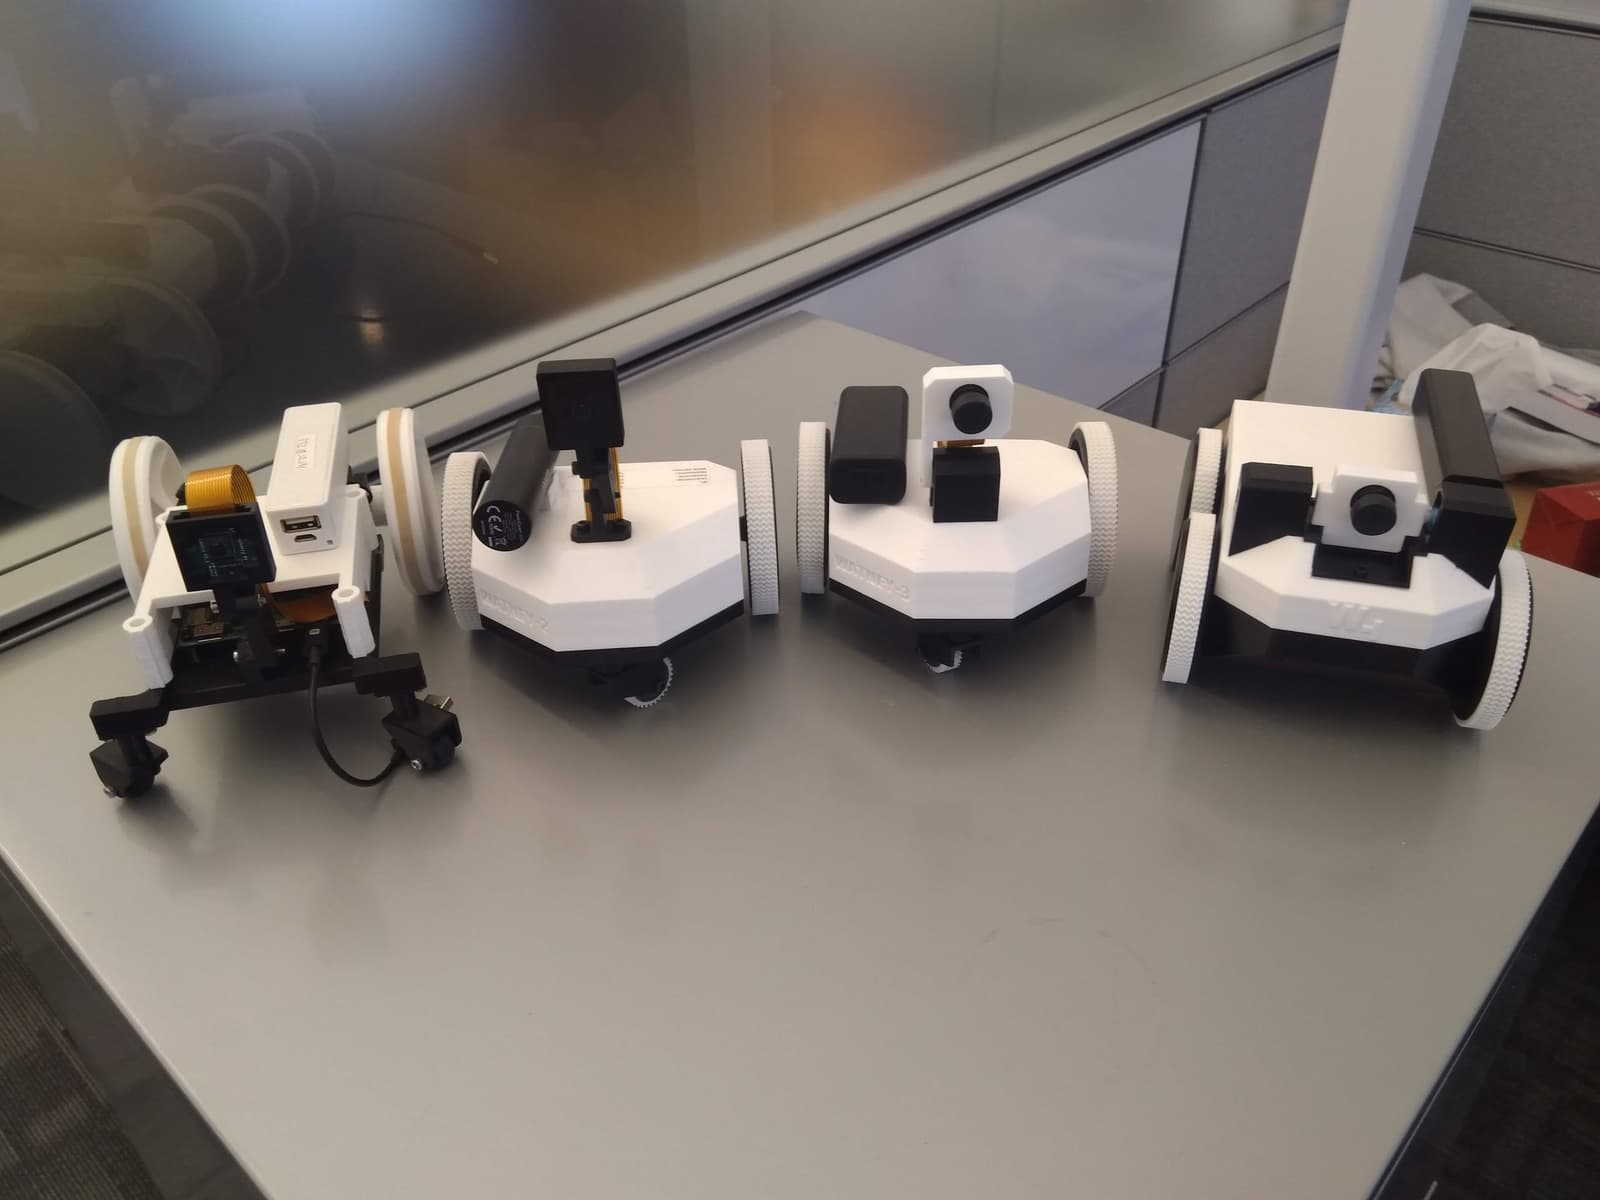
Watney is a low-cost, 3D-printable, Raspberry Pi-based FPV telepresence rover with HD video and bi-directional audio.
Robots 49–72 of 270