VVS Ballers RoboCup Soccer Robots
Two autonomous RoboCupJunior Soccer (Infrared league) robots, an attacker and a defender, built on a multi-board Teensy 4.1 electronics stack with IR ball sensing and a solenoid kicker.
- Wheeled
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @Kushal-Sachdeva78 (opens in a new tab), from github.com/Kushal-Sachdeva78/VVS-Ballers-RoboCup (opens in a new tab). Pinned to commit 958320a (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
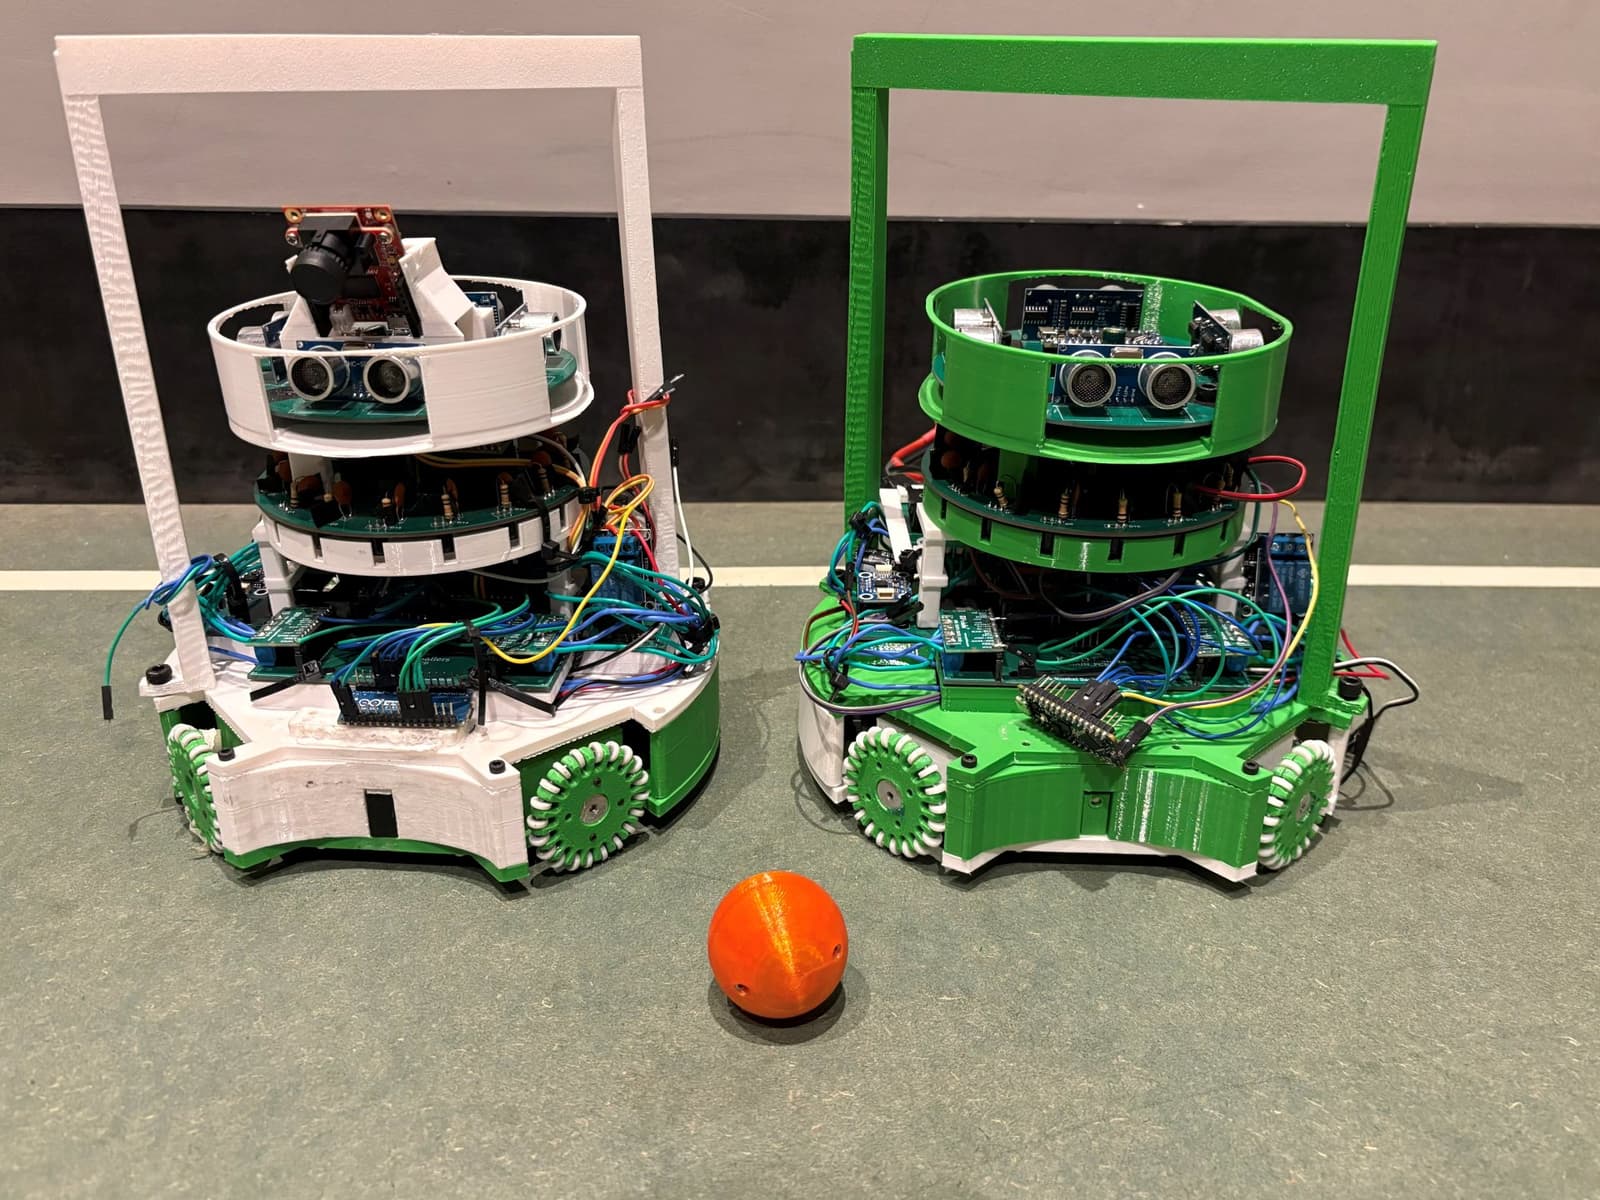
3D model loaded from the original files on GitHub at 958320a, under MIT. View the original files from GitHub (5 KB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Two autonomous robots, an attacker and a defender, for RoboCupJunior Soccer Infrared league play.
- Attacker chases an infrared-emitting ball using a 16-sensor IR ring to find its bearing.
- Attacker uses an OpenMV camera to find the goal and aims at the open corner before kicking.
- Attacker fires a 48 V solenoid kicker, gated on the camera aim.
- Attacker stays in bounds by fusing line ring and ultrasonic readings before fleeing a boundary.
- Defender holds the goal mouth using the line ring to ride the edge of the goal area and clears the ball on contact.
- Robot pins out RoboCupJunior Communication Module GO/STOP inputs for referee start and stop.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Kushal-Sachdeva78 (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Teensy 4.1 IR ring board with 16 TSSP58038 infrared receivers for ball bearing and distance.
- Teensy 4.1 line ring board with four QTR-MD-05A reflectance sensors (18 channels) for white-line detection.
- Arduino Nano Every ultrasonic board with four HC-SR04 sensors for wall distances.
- OpenMV H7 camera for goal, keeper and open-corner vision.
- Power board providing 12 V, 5 V and 3.3 V rails plus a 48 V solenoid boost converter.
- Optional Arduino Nano Every motor-current board monitoring DRV8263H stall and over-current.
Connections
- Subsystem boards communicate with the main board over UART links.
- IR ring to main board uses Serial4 with plain ASCII delimited messages and no checksum.
- Ultrasonic board to main board uses Serial3 with a 13-byte CRC-8 framed message.
- Line ring to main board uses Serial8 with a 9-byte CRC-8 framed message.
- Camera to main board uses Serial2 with an 11-byte CRC-8 framed message.
- Binary links use a 2-byte sync and CRC-8 with polynomial 0x07 to reject corrupted frames.
- Per-board wiring is documented in PDFs under PCB/Wiring for the Main, Power, IR and Line boards.
Schematics, boards and diagrams
- RoboCup Internationals 2025-26/Docs/Images/Electronics/5V_3.3V_UART_Wiring.jpgDiagram
- RoboCup Internationals 2025-26/Docs/Images/Electronics/IR_PCB_RC_Circuit.jpgDiagram
- RoboCup Internationals 2025-26/Docs/Images/Electronics/IR_Schematic.pngDiagram
- RoboCup Internationals 2025-26/Docs/Images/Electronics/Line_Schematic.pngDiagram
- RoboCup Internationals 2025-26/Docs/Images/Electronics/Main_PCB_2.0_Schematic.pngDiagram
- RoboCup Internationals 2025-26/Docs/Images/Electronics/Power_Schematic.pngDiagram
- RoboCup Internationals 2025-26/Docs/Images/Electronics/Ultrasonic_Schematic.pngDiagram
- RoboCup Internationals 2025-26/Legacy/PCB/Main_v1Gerber (PCB manufacturing)
- RoboCup Internationals 2025-26/Legacy/PCB/Main_v1/Main_PCB.kicad_pcbKiCad
- RoboCup Internationals 2025-26/Legacy/PCB/Main_v1/Main_PCB.kicad_schKiCad
- RoboCup Internationals 2025-26/PCB/IRGerber (PCB manufacturing)
- RoboCup Internationals 2025-26/PCB/IR/IR_PCB.kicad_pcbKiCad
- RoboCup Internationals 2025-26/PCB/IR/IR_PCB.kicad_schKiCad
- RoboCup Internationals 2025-26/PCB/LineGerber (PCB manufacturing)
- RoboCup Internationals 2025-26/PCB/Line/Line_PCB.kicad_pcbKiCad
- RoboCup Internationals 2025-26/PCB/Line/Line_PCB.kicad_schKiCad
- RoboCup Internationals 2025-26/PCB/MainGerber (PCB manufacturing)
- RoboCup Internationals 2025-26/PCB/Main/Main_PCB_2.0.kicad_pcbKiCad
- RoboCup Internationals 2025-26/PCB/Main/Main_PCB_2.0.kicad_schKiCad
- RoboCup Internationals 2025-26/PCB/PowerGerber (PCB manufacturing)
- RoboCup Internationals 2025-26/PCB/Power/Power_PCB.kicad_pcbKiCad
- RoboCup Internationals 2025-26/PCB/Power/Power_PCB.kicad_schKiCad
- RoboCup Internationals 2025-26/PCB/UltrasonicGerber (PCB manufacturing)
- RoboCup Internationals 2025-26/PCB/Ultrasonic/Ultrasonic_PCB.kicad_pcbKiCad
- RoboCup Internationals 2025-26/PCB/Ultrasonic/Ultrasonic_PCB.kicad_schKiCad


