LokaBot
An open-source, palm-sized autonomous robot built around a CodeCell C3, a DRV8833 motor driver and a multi-zone Time-of-Flight sensor.
- Wheeled
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @faajmid (opens in a new tab), from github.com/faajmid/Loka (opens in a new tab). Pinned to commit e106c5d (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
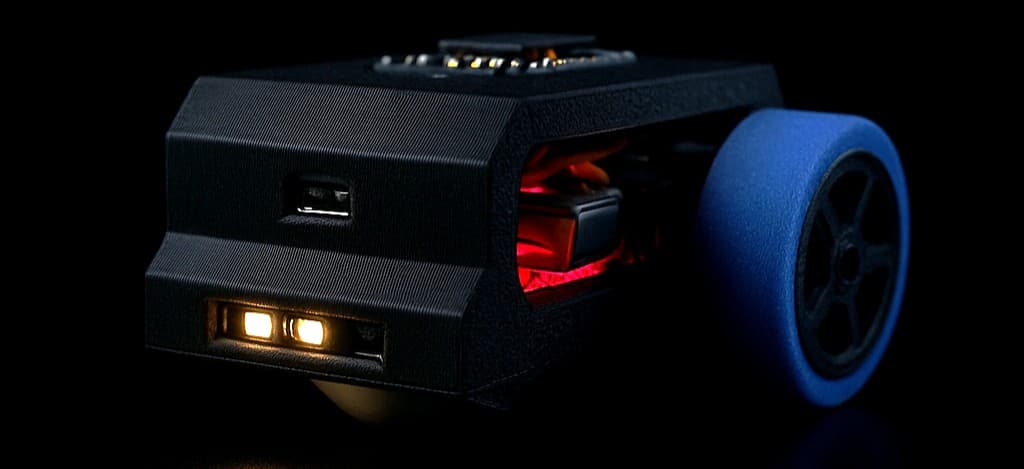
3D preview converted from github.com/faajmid/Loka at e106c5d, under MIT. View the original files from GitHub (21.4 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Palm-sized autonomous two-wheel robot with obstacle avoidance, light following and IMU-based behaviour as stated project goals
- Drives two N10 DC motors forward, reverse, left and right at a low duty cycle
- Reads a 4x4 multi-zone distance frame and computes left, centre and right obstacle distances with a basic steering decision
- Reads onboard light/proximity, rotation, acceleration, tap, motion state and battery level
- Project status: mechanical design and hardware documentation are primary; examples are hardware tests and starting points
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Inspect for shorts and reversed battery polarity
- 2Power the CodeCell from USB without the motors connected
- 3Upload the CodeCell sensor example and verify Serial Monitor output
- 4Connect the ToF sensor and run the SparkFun ToF example
- 5Raise the robot so its wheels are clear of the table
- 6Connect the DRV8833 and motors, then run the motor example at low duty cycle
- 7Reverse a motor's two output wires if its physical direction is opposite to the
The guide appears here as you scroll.
Guide by @faajmid (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- DRV8833 dual H-bridge motor driver
- Two N10 3 V DC motors, about 298 RPM, 3 mm D-shaft
- VL53L5CX-compatible multi-zone Time-of-Flight breakout board
- Compact 1S LED battery indicator
Connections
- CodeCell IO1 and IO2 connect to DRV8833 AIN1 and AIN2 for the left motor
- CodeCell IO5 and IO6 connect to DRV8833 BIN1 and BIN2 for the right motor
- CodeCell VO connects to DRV8833 VM as motor supply and GD to GND as common ground
- Left motor goes to AOUT1/AOUT2 and right motor to BOUT1/BOUT2; swap a motor's two wires if it turns the wrong way
- ToF board uses CodeCell 3V3 for power, GD for ground, and SDA and SCL on the default I2C bus at 400 kHz