
ZeroBug
A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.
OtherAdvancedBuildability 45/100 · Incomplete documentation
Cost not stated
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 3 of 4 · Ready to build first, then by buildability
A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.
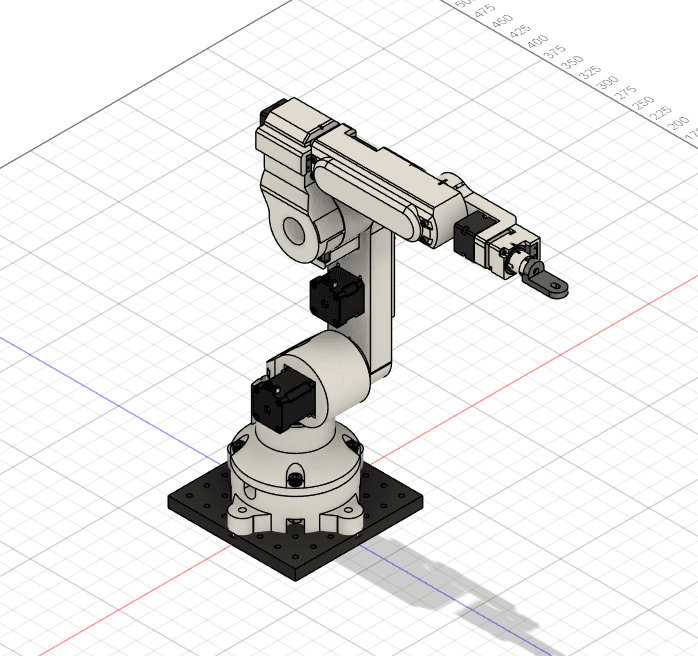
A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.
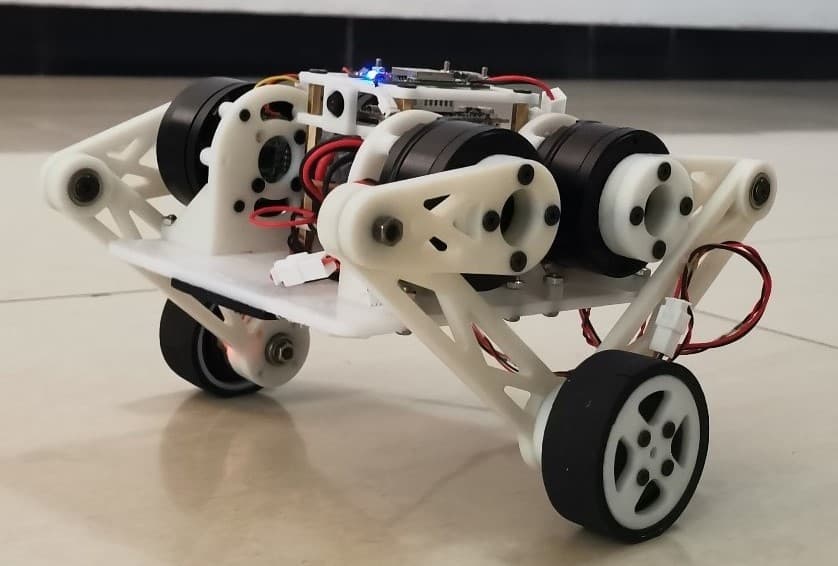
An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.
A biomimetic robot head with tendon-driven neck controlled via Raspberry Pi and PCA9685 servos.
A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.
A quadruped robot dog built from 3D-printed PLA parts, driven by ODrive-controlled motors with AS5047 absolute encoders and a remote-controlled walking mode.
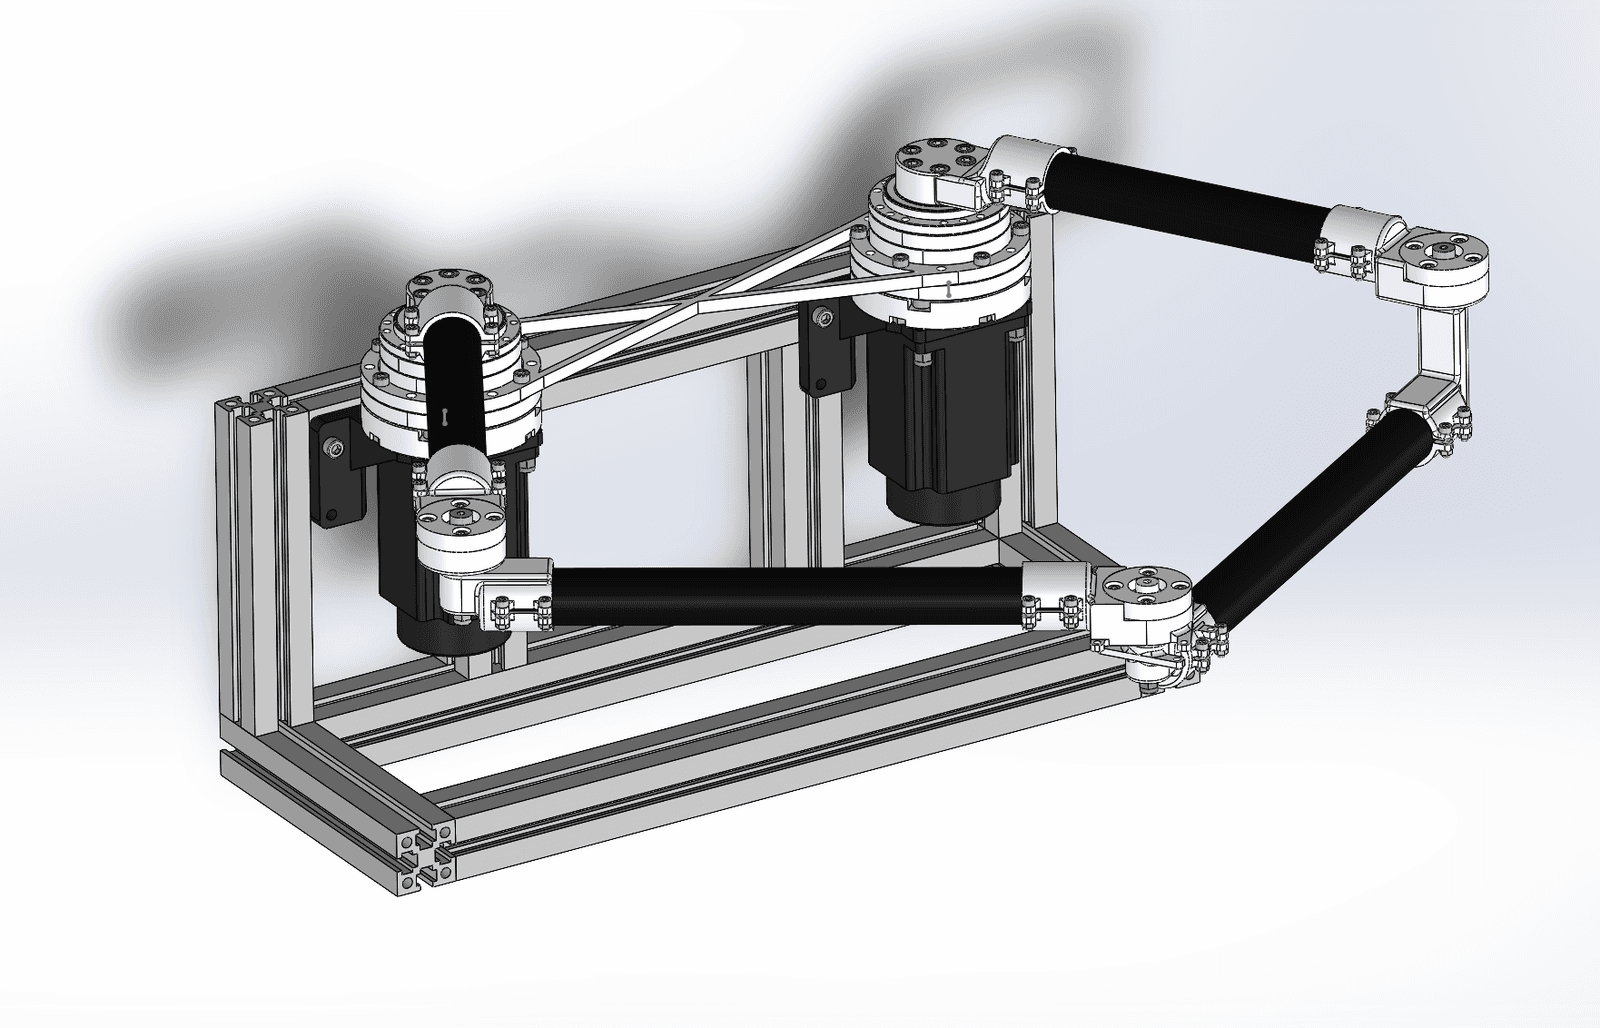
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
An open-source coaxial twin-rotor drone (helicopter-style swashplate control) that can be 3D printed and rebuilt by hobbyists.
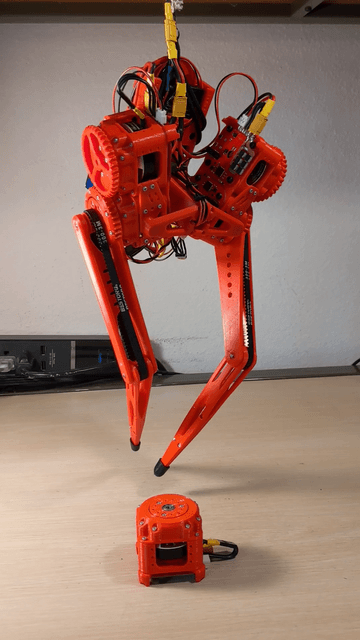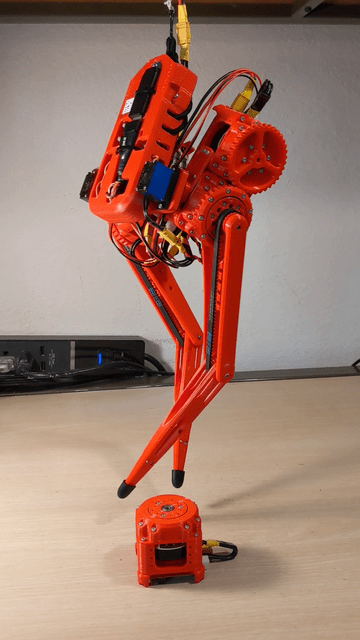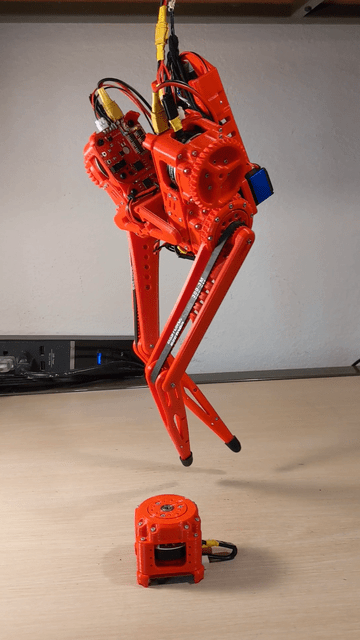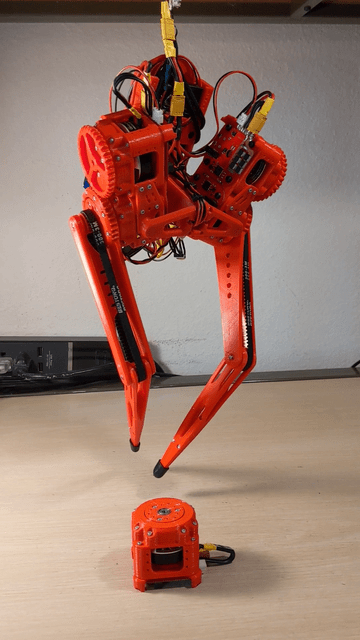
A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.
An ROV/AUV underwater robot controlled by STM32 and Raspberry Pi for navigation and sensor data processing.
Open-source wheeled biped robot with wheels for balance and legs for uneven terrain, controllable in simulation and on hardware.
A fully autonomous mobile robot designed for counter-terrorism, bomb disposal, and rescue tasks, featuring a four-wheel drive chassis, five-degree-of-freedom robotic arm, and multi-vision systems.
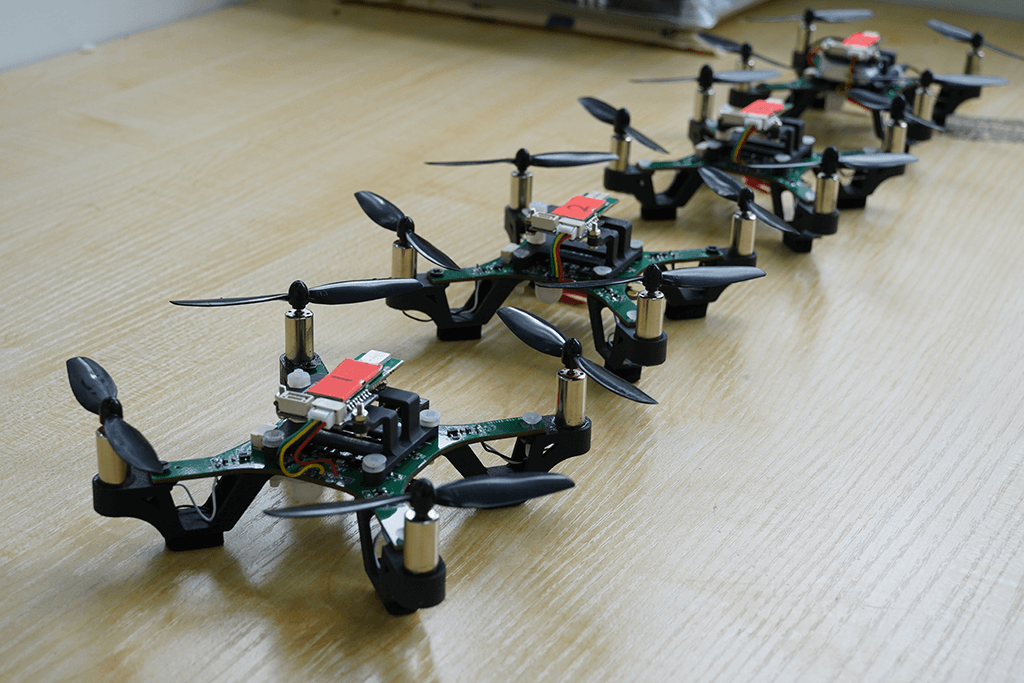
A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.
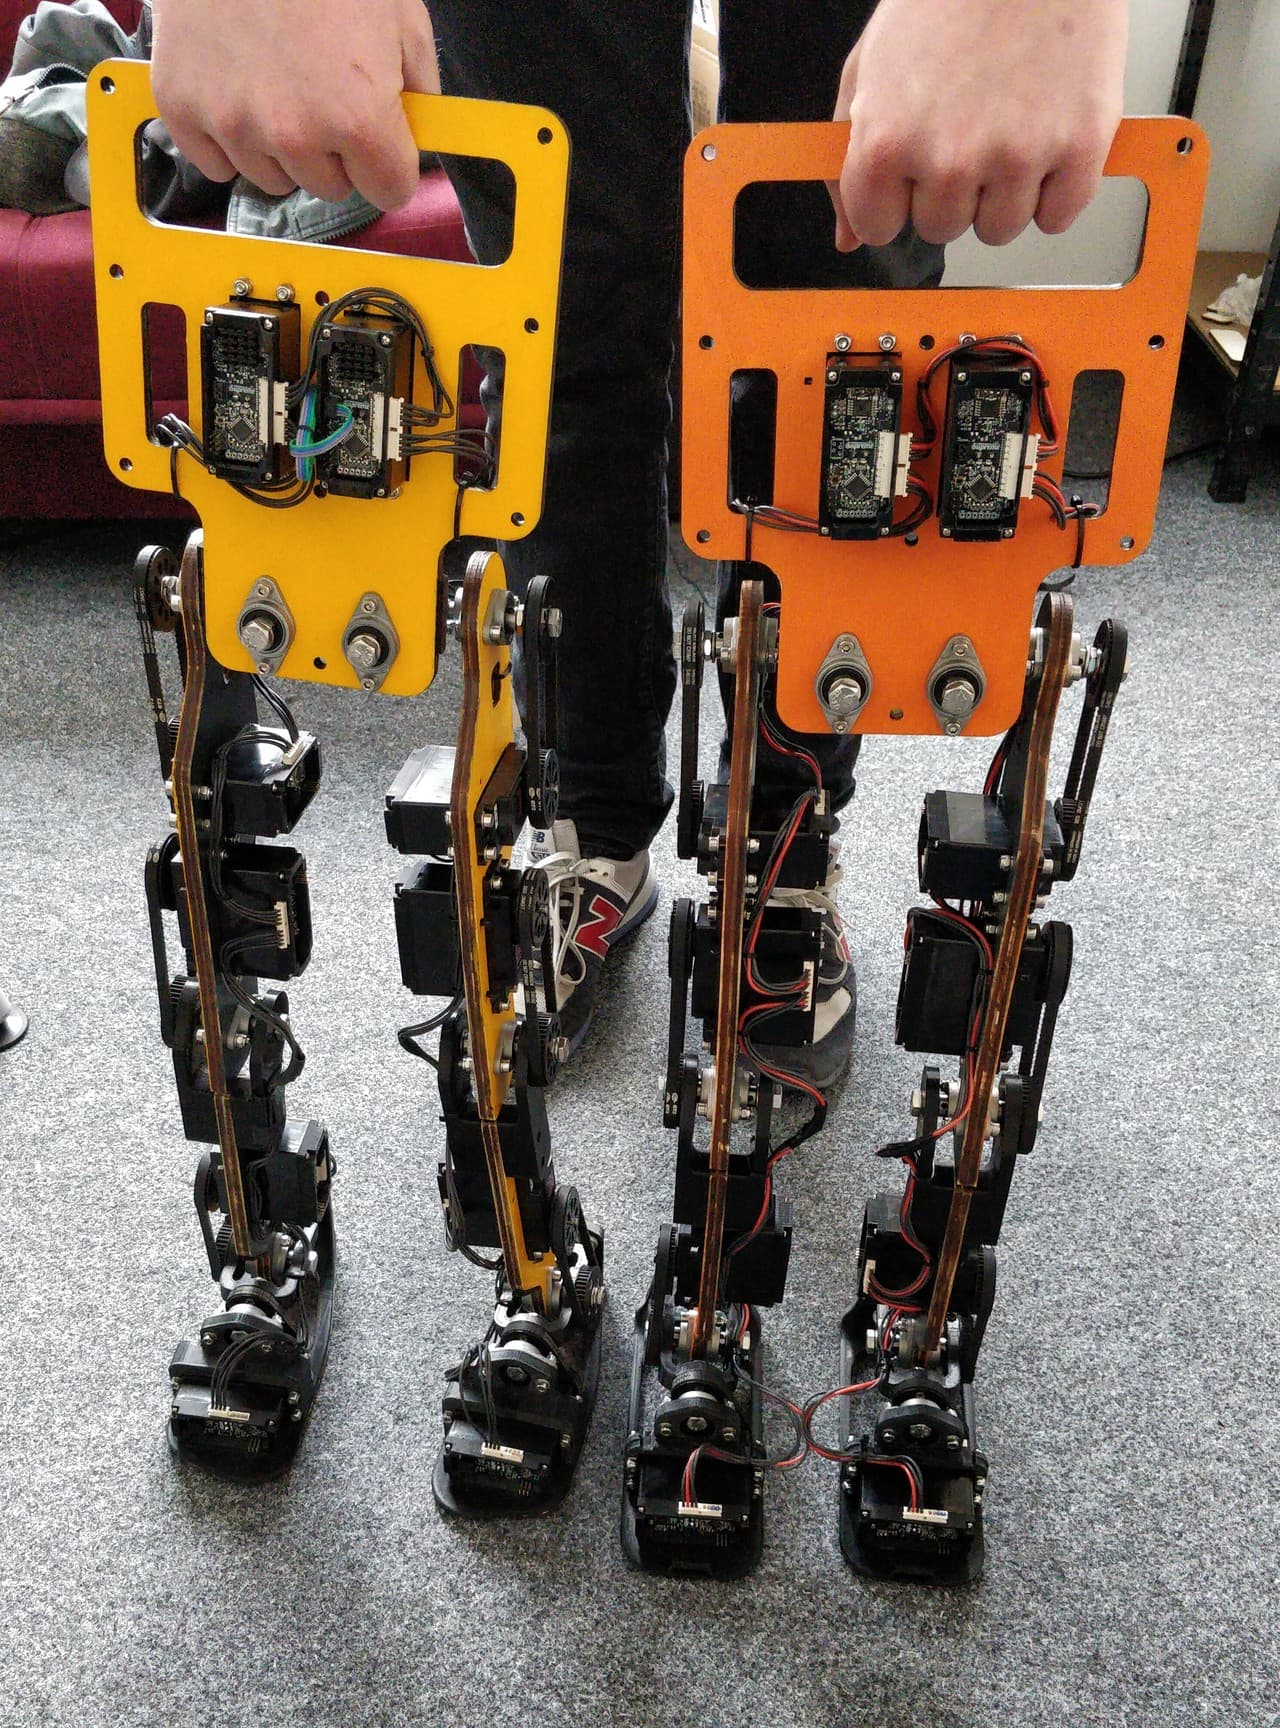
Gretchen is an open-source humanoid robot development platform.
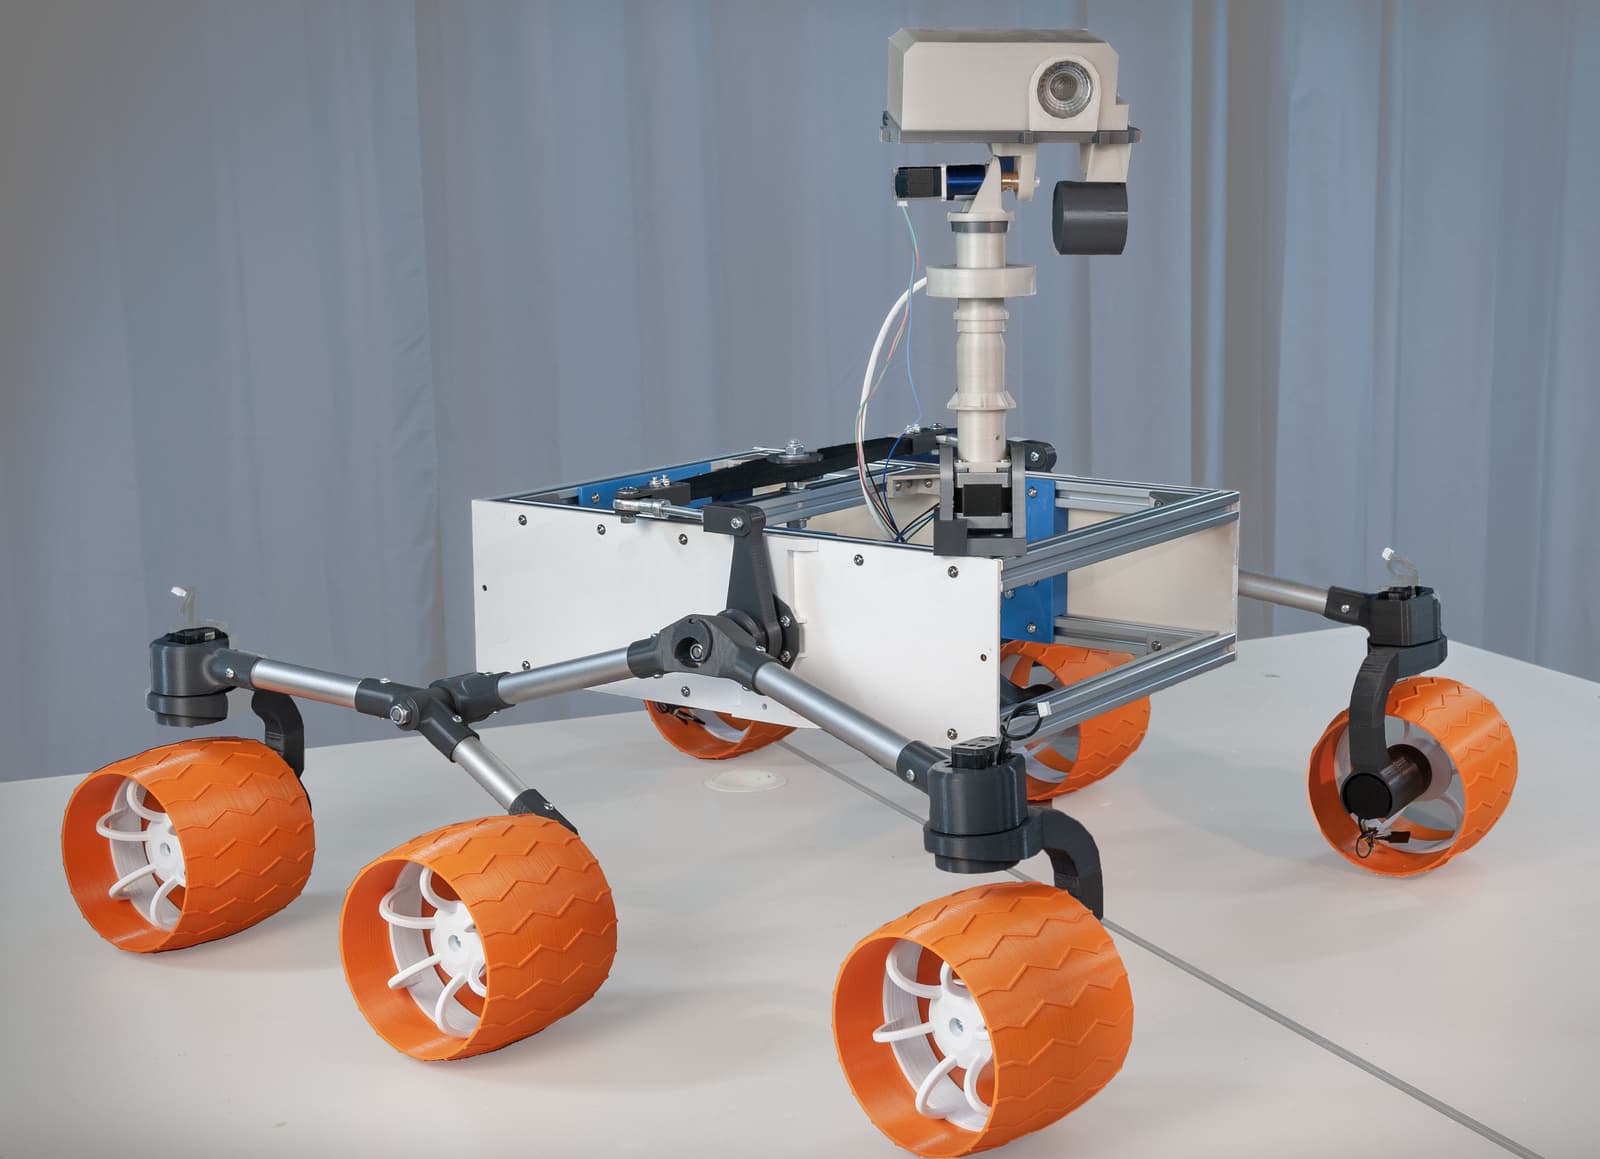
A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.
An open-source single-arm mobile robot that adds a 7-degree-of-freedom arm to a mobile chassis for grasping and carrying tasks in complex environments.
An independent hobbyist recreation of the MicroDuck 3D model, provided as SolidWorks source files and a STEP export for a small robot.
An open-source 8-DOF desktop quadruped robot platform with force control capabilities.
A compact aerial robot with omnidirectional visual perception for autonomous navigation and mapping.

A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.
A wheel-legged balancing robot with leg-joint motors and hub-wheel motors, controlled by a custom STM32H723 board using LQR and VMC.
A jumping reaction wheel unicycle robot that balances on a single wheel and can jump.
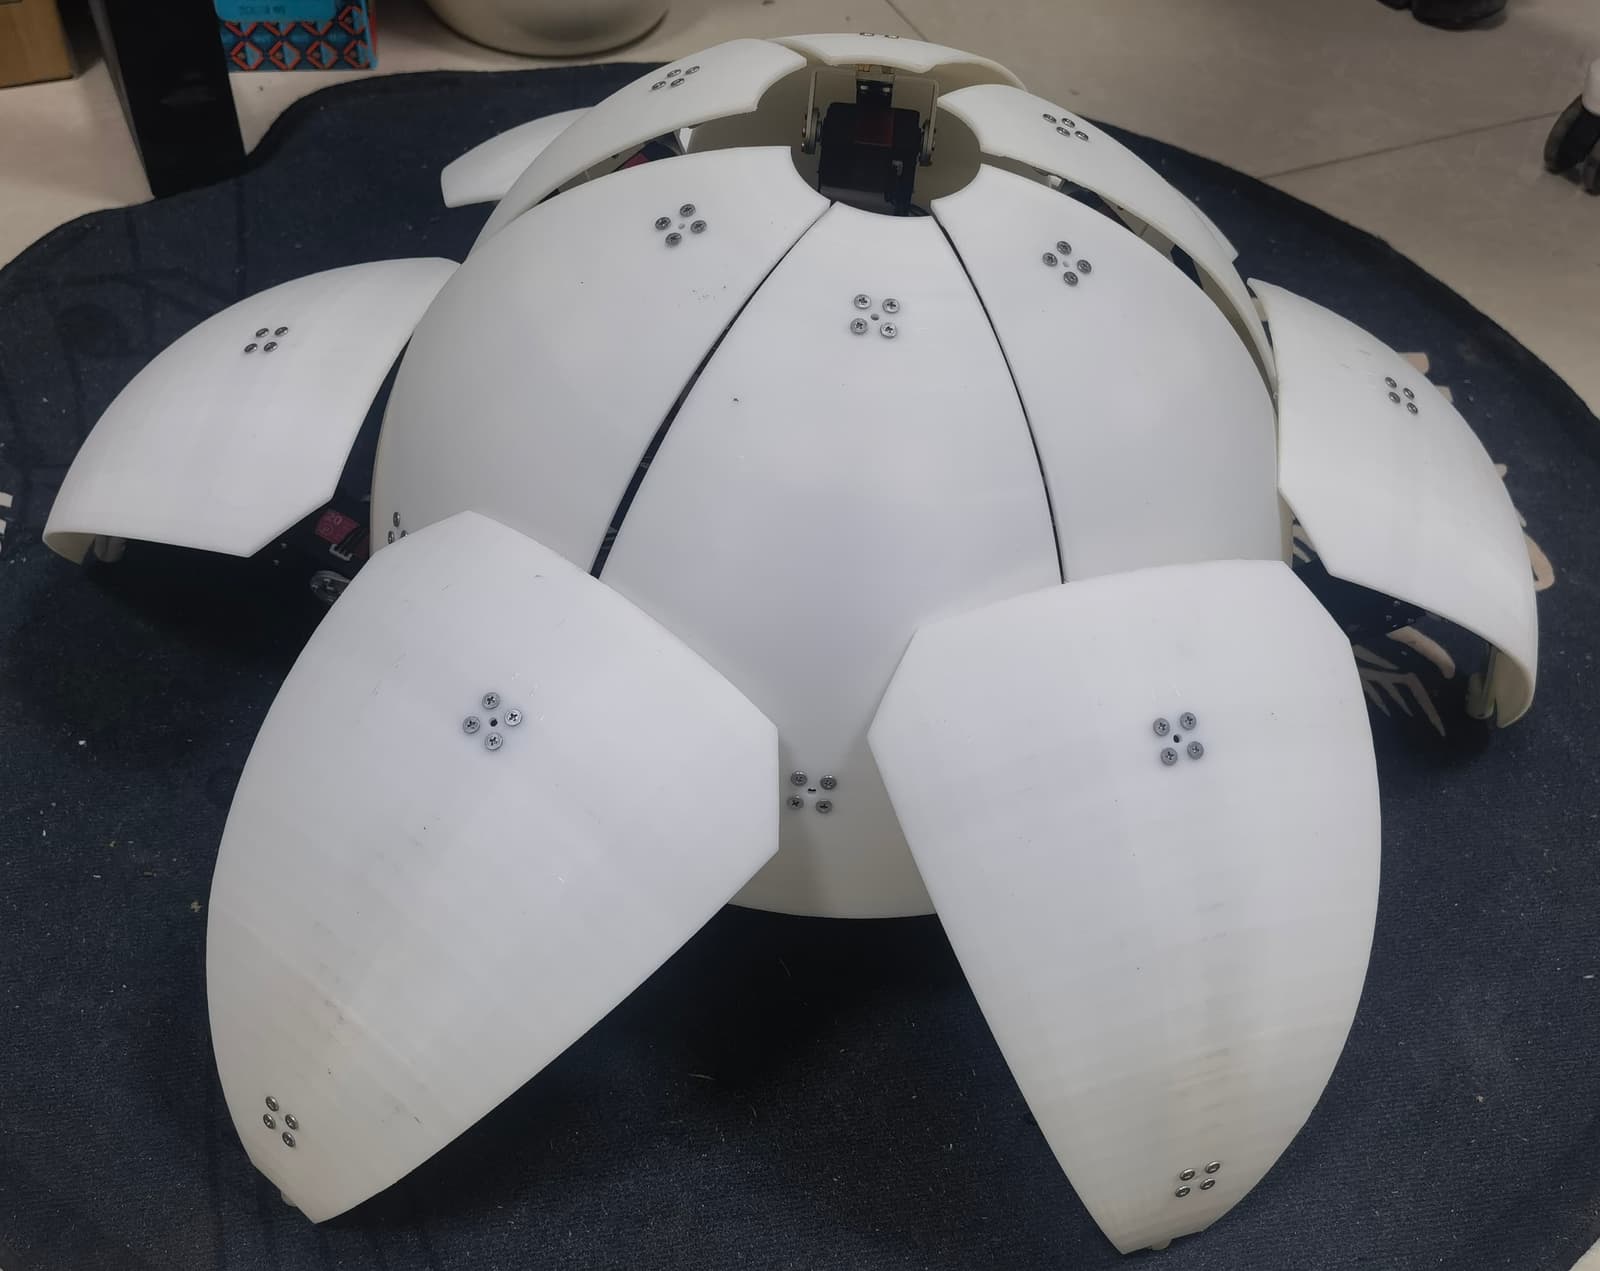
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
An open-source 6-DOF anthropomorphic robotic hand with linkage-based fingers and worm-and-rack transmissions, intended as a low-cost platform for research and education.
Robots 49–72 of 95