Barkour Robot
An agile quadruped robot platform developed by Google DeepMind for research, with CAD, electronics, firmware and assembly guides.
- Quadruped
- Open source
- 3D printable
Suggested by Robotheca, created by @google-deepmind (opens in a new tab), from github.com/google-deepmind/barkour_robot (opens in a new tab). Pinned to commit e7c0f6f (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo and 3D model
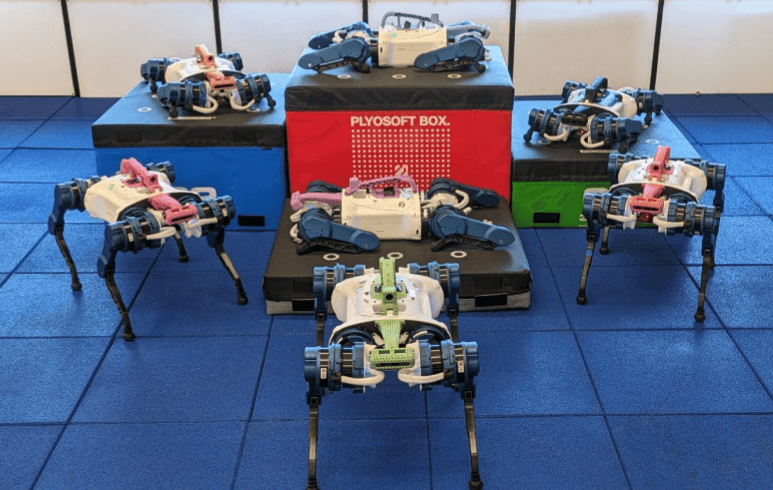
3D preview converted from github.com/google-deepmind/barkour_robot at e7c0f6f, under Apache-2.0. View the original files from GitHub (77.0 MB) (opens in a new tab)
1 of the 11 STEP files is not in the 3D view: 1 beyond what one preview can hold.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Robot getting started and basic usage
- 2Actuator assembly and setup
- 3Leg linkage assembly
- 4Hip cover assembly
- 5Wireless E-stop (STO) assembly
- 6IMU configuration
- 7Actuated head assembly
- 8Barkour robot assembly
The guide appears here as you scroll.
Guide by @google-deepmind (README.md), under Apache-2.0.
More guides
Wiring and electronics
Schematics, boards and diagrams
- docs/images/robot_assembly/body_assembly/hind_left_wiring1.jpgDiagram
- docs/images/robot_assembly/body_assembly/hind_left_wiring2.jpgDiagram
- docs/images/robot_assembly/body_assembly/wiring_front_trimotors.jpgDiagram
- docs/images/wsto_assembly/e_stop_wiring.pngDiagram
- hardware/electronics/ada/Ada.PcbDocAltium
- hardware/electronics/ada/Ada.SchDocAltium
- hardware/electronics/ada/Project Outputs for Ada/GerberGerber (PCB manufacturing)
- hardware/electronics/ada/Project Outputs for Ada/PDF/Schematic Print/Schematic Prints.PDFDiagram
- hardware/electronics/cortes/1-Top.SchDocAltium
- hardware/electronics/cortes/Accelerometer.SchDocAltium
- hardware/electronics/cortes/Cortes.PcbDocAltium
- hardware/electronics/cortes/EtherCATConnectors.SchDocAltium
- hardware/electronics/cortes/MezzanineConnectors.SchDocAltium
- hardware/electronics/cortes/Microphone.SchDocAltium
- hardware/electronics/cortes/Power.SchDocAltium
- hardware/electronics/cortes/Processor.SchDocAltium
- hardware/electronics/cortes/ProcessorSupport.SchDocAltium
- hardware/electronics/cortes/Project Outputs for Cortes/GerberGerber (PCB manufacturing)
- hardware/electronics/cortes/Project Outputs for Cortes/PDF/Schematic Print/Schematic Prints.PDFDiagram
- hardware/electronics/cortes/Temperature.SchDocAltium
- hardware/electronics/cortes/Trinamic.SchDocAltium
- hardware/electronics/feifei/Fei-Fei.PcbDocAltium
- hardware/electronics/feifei/Fei-Fei.SchDocAltium
- hardware/electronics/feifei/Project Outputs for Power_Distro/GerberGerber (PCB manufacturing)
- hardware/electronics/feifei/Project Outputs for Power_Distro/PDF/Schematic Print/Schematic Prints.PDFDiagram
- hardware/electronics/gebru/1-Top.SchDocAltium
- hardware/electronics/gebru/Drive.SchDocAltium
- hardware/electronics/gebru/Feedback.SchDocAltium
- hardware/electronics/gebru/Gebru.PcbDocAltium
- hardware/electronics/gebru/HBridge.SchDocAltium
- hardware/electronics/gebru/MezzanineConnectors.SchDocAltium
- hardware/electronics/gebru/Project Outputs for Gebru/GerberGerber (PCB manufacturing)
- hardware/electronics/gebru/Project Outputs for Gebru/PDF/Schematic Print/Schematic Prints.PDFDiagram
- hardware/electronics/gebru/STO.SchDocAltium
- hardware/electronics/grace/Grace.PcbDocAltium
- hardware/electronics/grace/Grace.SchDocAltium
- hardware/electronics/grace/Project Outputs for Grace/GerberGerber (PCB manufacturing)
- hardware/electronics/grace/Project Outputs for Grace/PDF/Schematic Print/Schematic Prints.PDFDiagram
- hardware/electronics/hamilton/Hamilton.PcbDocAltium
- hardware/electronics/hamilton/Hamilton.SchDocAltium


