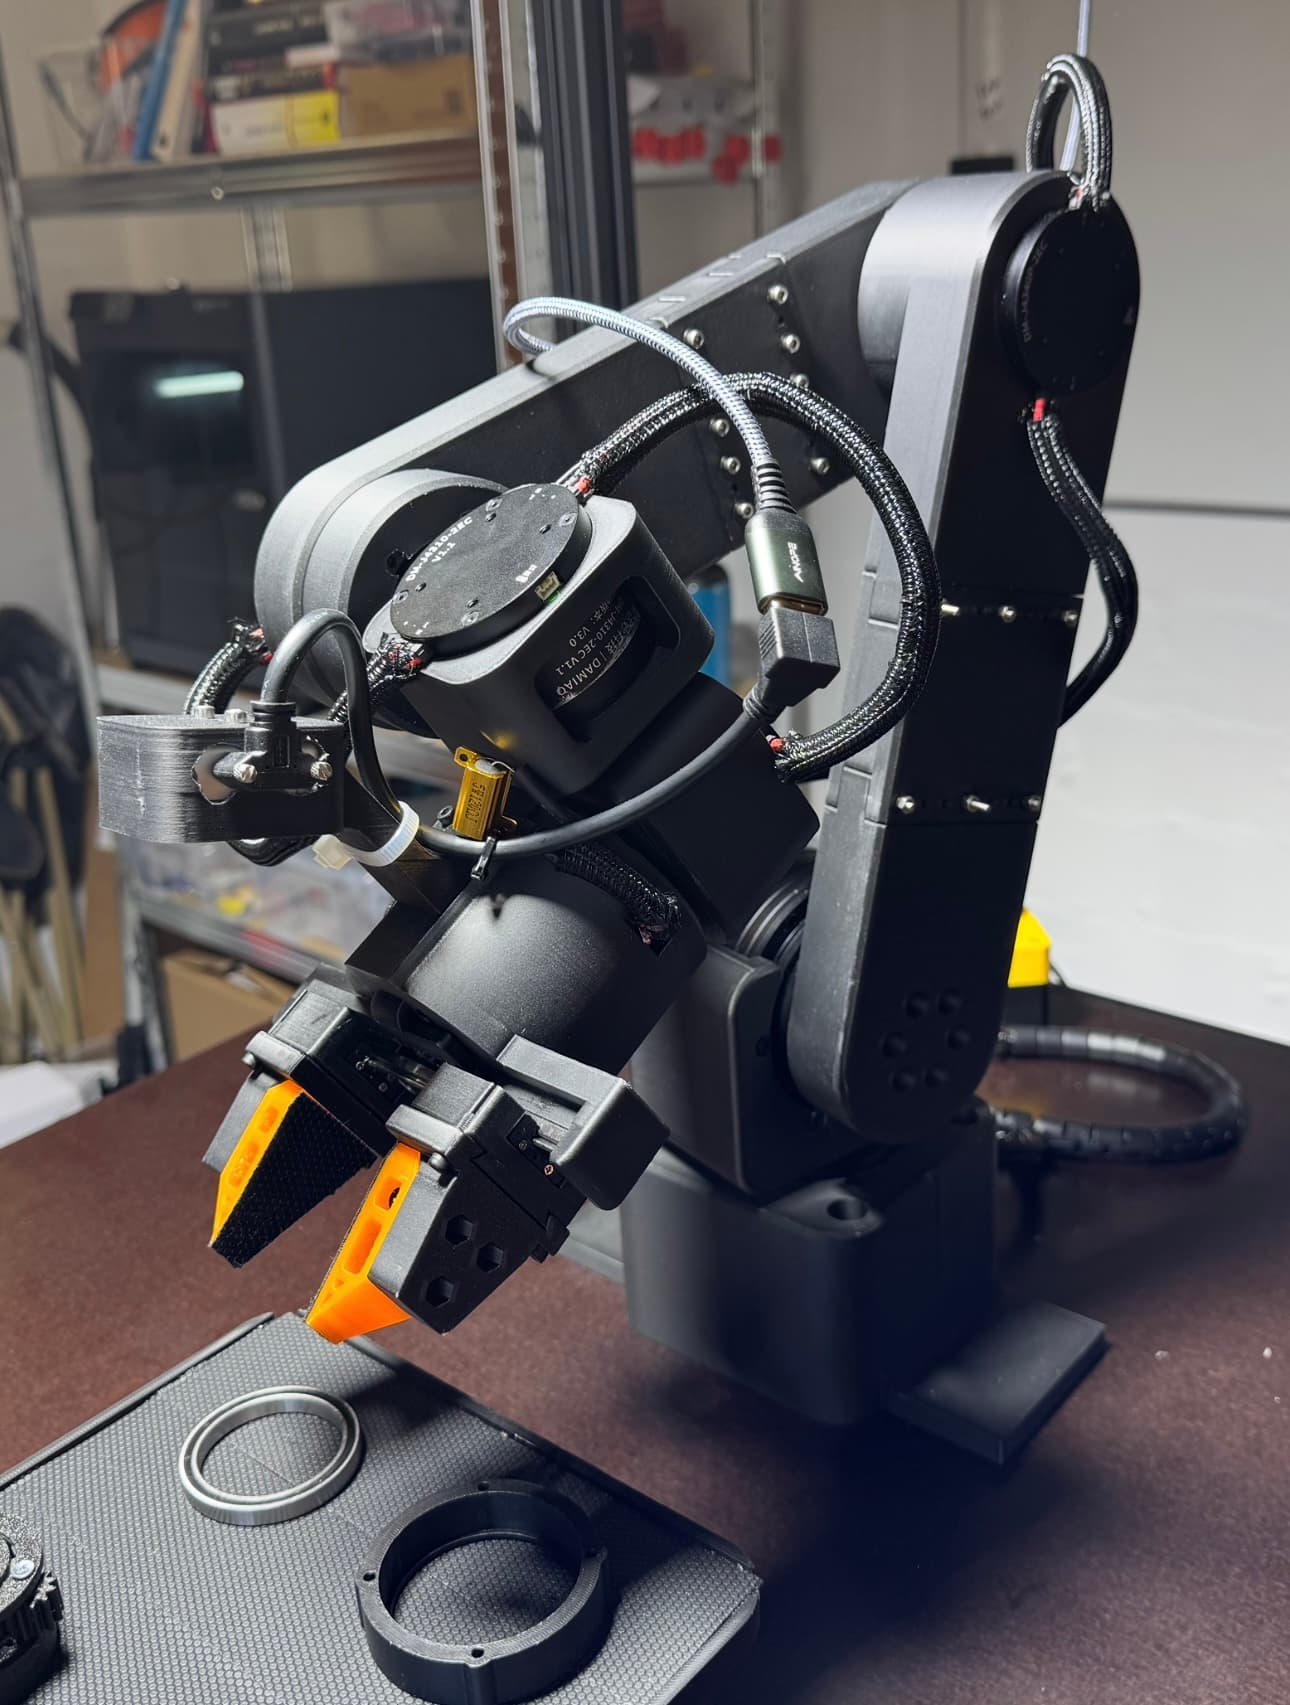
reBot DevArm B601-DM
A 6-axis desktop robot arm with a gripper, made of CNC aluminium and 3D-printed parts and driven by CAN bus motors, for robot learning and research.
- Works with AI
Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.
Page 1 of 1 · Ready to build first, then by buildability
A 6-axis desktop robot arm with a gripper, made of CNC aluminium and 3D-printed parts and driven by CAN bus motors, for robot learning and research.
A 3D-printed collaborative robot arm for research, education and rapid prototyping in physical AI.
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
A 6-axis 3D-printed desktop robot arm with stepper motors, gearboxes and belts, modelled on industrial arms, with its own control firmware.
A 7-DOF dual-arm bimanual robot platform derived from the SO-101 design, with matching leader arms for teleoperation.
A 7-DOF personal robotic arm with ROS-based simulation and control.
An open-source 6-DOF collaborative robotic arm system with mechanical structure, electronics, and software.
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
A 3D-printable 7-DoF robotic arm with native LeRobot integration for teleoperation, demonstration recording, and policy training.
A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.
An open source six degree of freedom industrial robot arm that can hold 2kg at 80cm.
A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
An open-source single-arm mobile robot that adds a 7-degree-of-freedom arm to a mobile chassis for grasping and carrying tasks in complex environments.
A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.
The Ruishi modular exoskeleton: joint and slip-ring modules, the hardware and joint-motor lists, and installation examples.
Mechanical model and parts list of HighTorque's Panthera-HT robot arm: SolidWorks 2024 sources, STEP files and a BOM spreadsheet.