Delta Robot ACT vs. Diffusion Policy
A 3-DOF delta robot with an electromagnet gripper that picks up a bolt and drops it in a cup, used to compare ACT and Diffusion imitation-learning policies.
- Robot arm
- Open source
- Works with AI
- LeRobot
- 3D printable
Suggested by Robotheca, created by @KirkEHaskell (opens in a new tab), from github.com/KirkEHaskell/delta-robot-act-vs-diffusion (opens in a new tab). Pinned to commit ec84726 (opens in a new tab).
- Hardware license
- CC-BY-4.0 (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
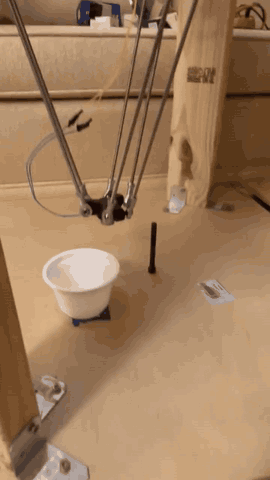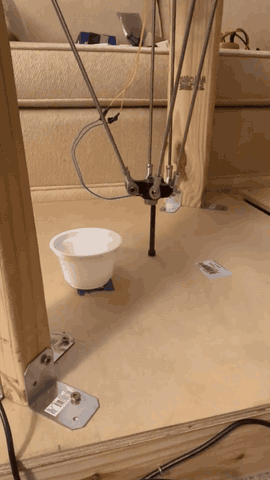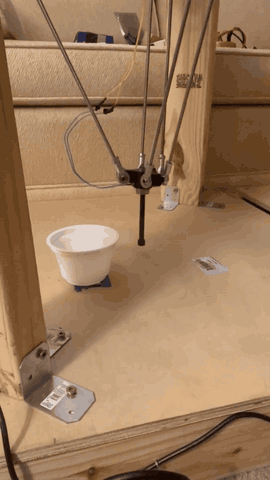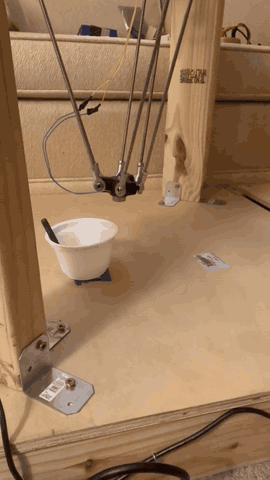
3D preview converted from github.com/KirkEHaskell/delta-robot-act-vs-diffusion at ec84726, under CC-BY-4.0. View the original files from GitHub (1.5 MB) (opens in a new tab)
- Degrees of freedom
- 3
What it can do
Written by Robotheca from the project's documents.
- Picks up a steel bolt from the table with an electromagnet gripper and drops it into a cup, fully autonomously.
- Learned policies (ACT and Diffusion Policy) output joint angles and a magnet on/off command at 30 Hz from three cameras.
- Leader-follower teleoperation: a hand-moved leader arm with magnetic encoders is mirrored by the follower to record demonstrations.
- Serial command protocol supports record/teleop mode, autonomous mode, move commands, stop, and debug dump.
- Joint angles are clamped to 30 to 110 degrees.
Works with AI
Found by Robotheca in the project's files at commit ec84726, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Runs LeRobot
Stated in robot.yamlHas LeRobot code
In the project files: training/lerobot_train_fixed.py“Install Python dependencies from requirements.txt after installing PyTorch for your machine.”
Robotheca's notes: How to run it
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @KirkEHaskell (README.md), under CC-BY-4.0 (hardware) and MIT (software).
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Teensy 4.1 microcontroller running the delta_teleop firmware.
- Three Feetech STS3215 12 V serial-bus servos driving the follower arm.
- Three AS5600 magnetic encoders on the leader arm.
- Electromagnet end effector driven through an H-bridge.
- Push button for magnet control during teleoperation.
- Three Innomaker U20CAM-720P USB cameras on a USB hub, captured as MJPG 320x240 at 30 fps.
Connections
- Servos connect to Teensy Serial1 (TX pin 1, RX pin 0) on a 1 Mbit/s bus with IDs 2, 3 and 1.
- Leader-arm AS5600 encoders use two hardware I2C buses (Wire, Wire2) plus one bit-banged bus on pins 20 and 21.
- Electromagnet H-bridge inputs IN1 and IN2 are on pins 30 and 32.
- Push button sits between pins 4 and 5.
- Teensy communicates with the host over USB at 115200 baud.
- All three cameras share one USB hub.