RAVEN
A 3-DOF robotic manipulator arm built on quasi-direct-drive actuators, with CAD, URDF and 3D-printable parts.
- Robot arm
- Open source
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @jaebin401 (opens in a new tab), from github.com/jaebin401/RAVEN_hardware (opens in a new tab). Pinned to commit 8716886 (opens in a new tab).
- Hardware license
- CERN-OHL-S-2.0 (opens in a new tab)
- Software license
- CC-BY-4.0 (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
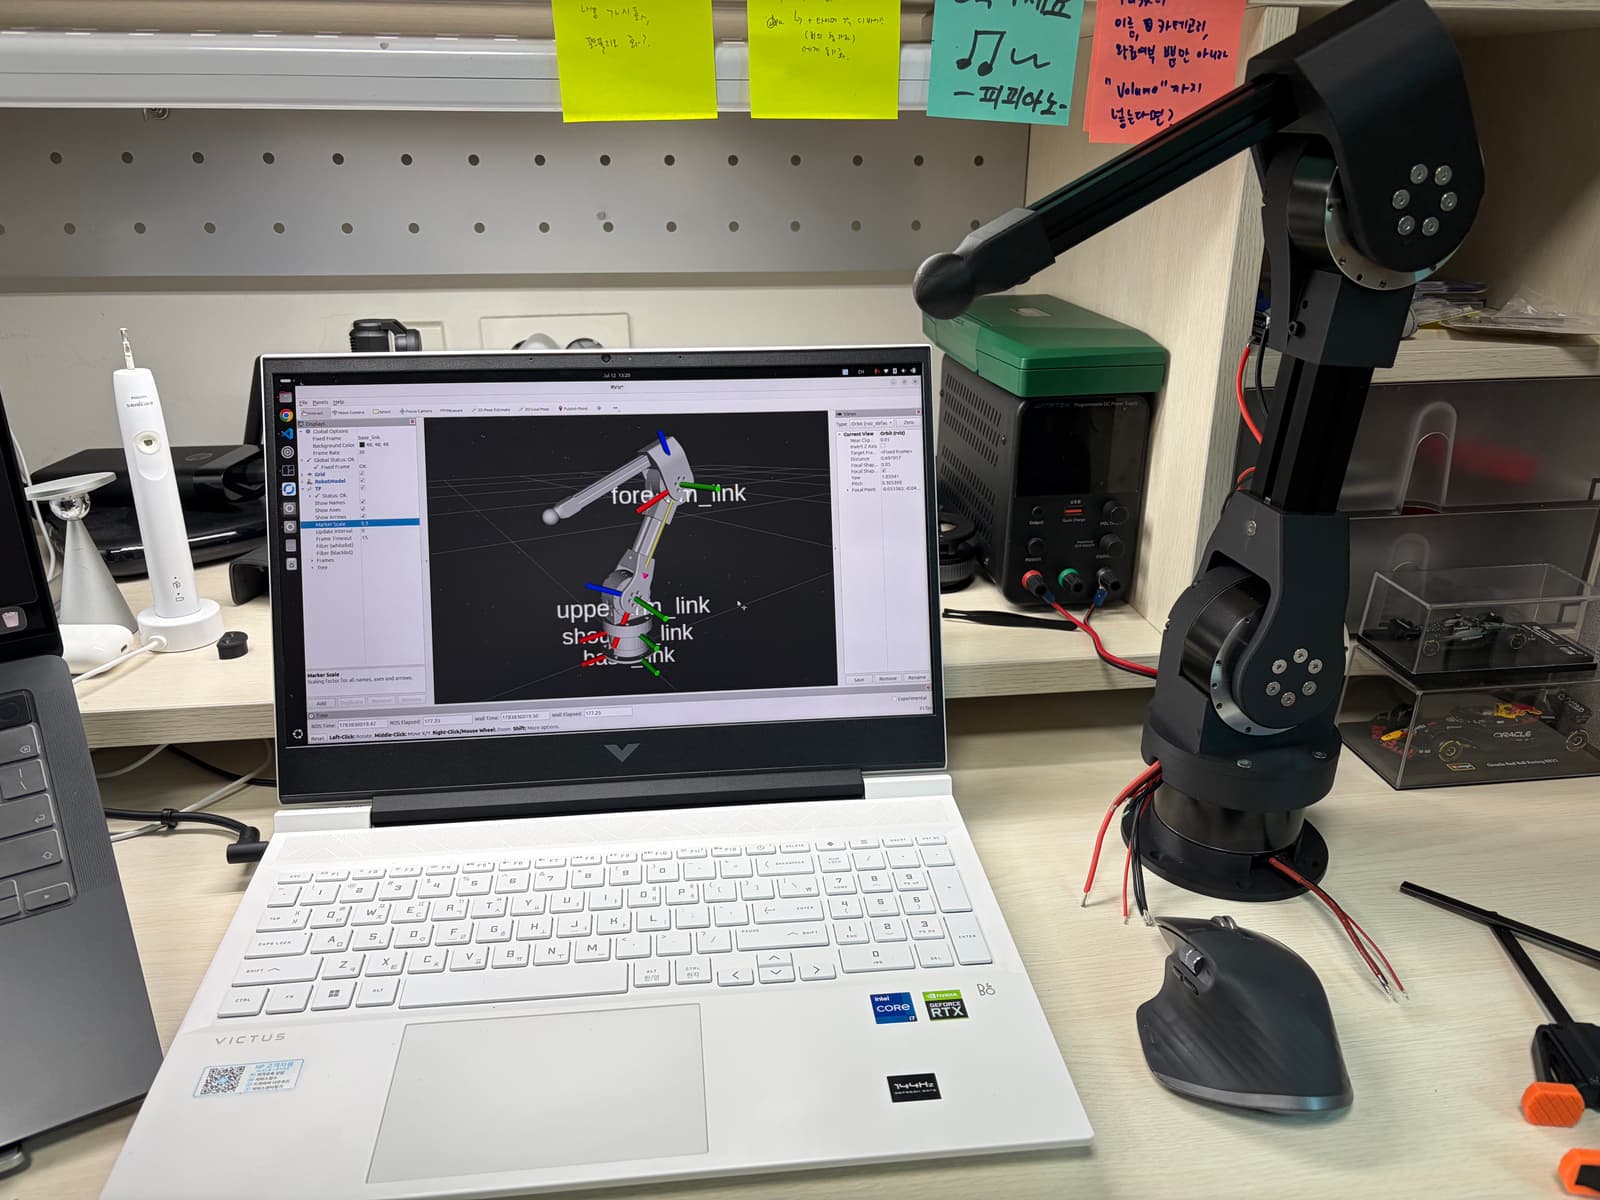
Try it in the browser
3D preview converted from github.com/jaebin401/RAVEN_hardware at 8716886, under CERN-OHL-S-2.0. View the original files from GitHub (2.4 MB) (opens in a new tab)
- Degrees of freedom
- 3
- Reach
- 250 mm
What it can do
Written by Robotheca from the project's documents.
- RAVEN is a 3-DOF robotic manipulator arm with three revolute joints: base yaw, shoulder pitch, and elbow pitch.
- Joint ranges are about -3.14 to 3.14 rad for base yaw and 0 to 3.14 rad for shoulder and elbow pitch.
- The arm is intended for simulation and control, with a URDF describing its kinematic structure.
- The documents state that effort and velocity limits are not yet filled in and are to be taken from actuator specs.
- The design is planned for eventual integration into the humanoid robot QUB.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @jaebin401 (README.md), under CERN-OHL-S-2.0 (hardware) and CC-BY-4.0 (software).
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Three Robstride RS02 quasi-direct-drive actuators, rated 6 N·m with a 17 N·m peak at 48 V.
- Control and firmware are handled in a separate software repository, using SocketCAN and RS02 MIT mode.
Connections
- The documents describe the actuators as driven over SocketCAN, but do not specify detailed wiring or pin connections.