SCARA RRP Welding Robot
A 3-DOF SCARA robot with two rotary joints and one prismatic joint, designed as an automation solution for TIG welding tasks.
- Robot arm
- Open source
- micropython
- 3D printable
Suggested by Robotheca, created by @Clip2004 (opens in a new tab), from github.com/Clip2004/scara-robot-rrp (opens in a new tab). Pinned to commit e7176e0 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
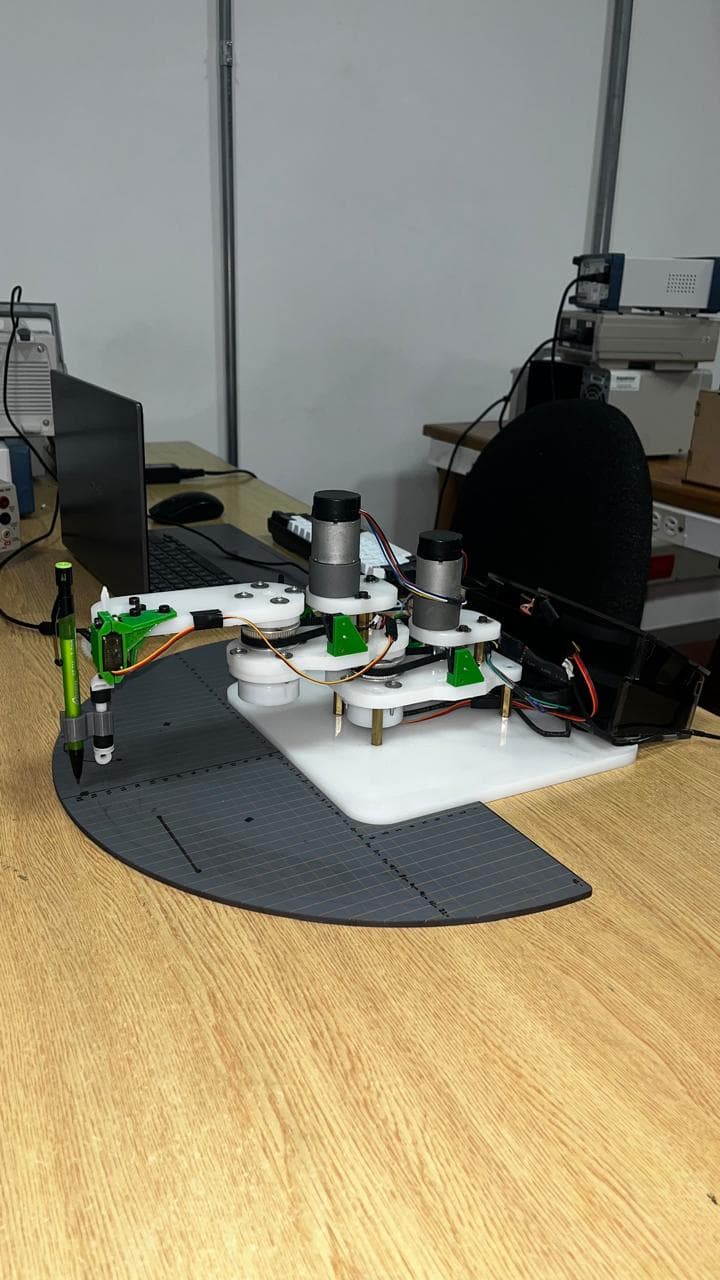
3D preview converted from github.com/Clip2004/scara-robot-rrp at e7176e0, under MIT. View the original files from GitHub (2.2 MB) (opens in a new tab)
- Degrees of freedom
- 3
- Power
- 12 V
What it can do
Written by Robotheca from the project's documents.
- Executes a homing routine using limit switches
- Moves to arbitrary points (x, y, z) within its workspace via the P command
- Follows linear trajectories via the L command
- Follows semicircular trajectories via the C command
- Computes joint angles and linear displacement with analytical inverse kinematics
- Controlled through a serial terminal command interface
- Designed as a 3-DOF SCARA robot (RRP) with a TIG torch tool holder for welding tasks
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Clip2004 (README.md), under MIT.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi Pico microcontroller (RP2040)
- 2x Pololu 12V DC motors, 200 RPM, with quadrature encoders
- MG90S servo motor driving the Z axis via rack and pinion
- L298N H-bridge motor driver
- Limit switches for travel limits and homing
- Custom PCB designed in KiCad
- Motor supply set to 12V
Connections
- Custom KiCad PCB integrates all power and signal components
- A wiring diagram is provided in docs/wiring_diagram.pdf