Skip to content

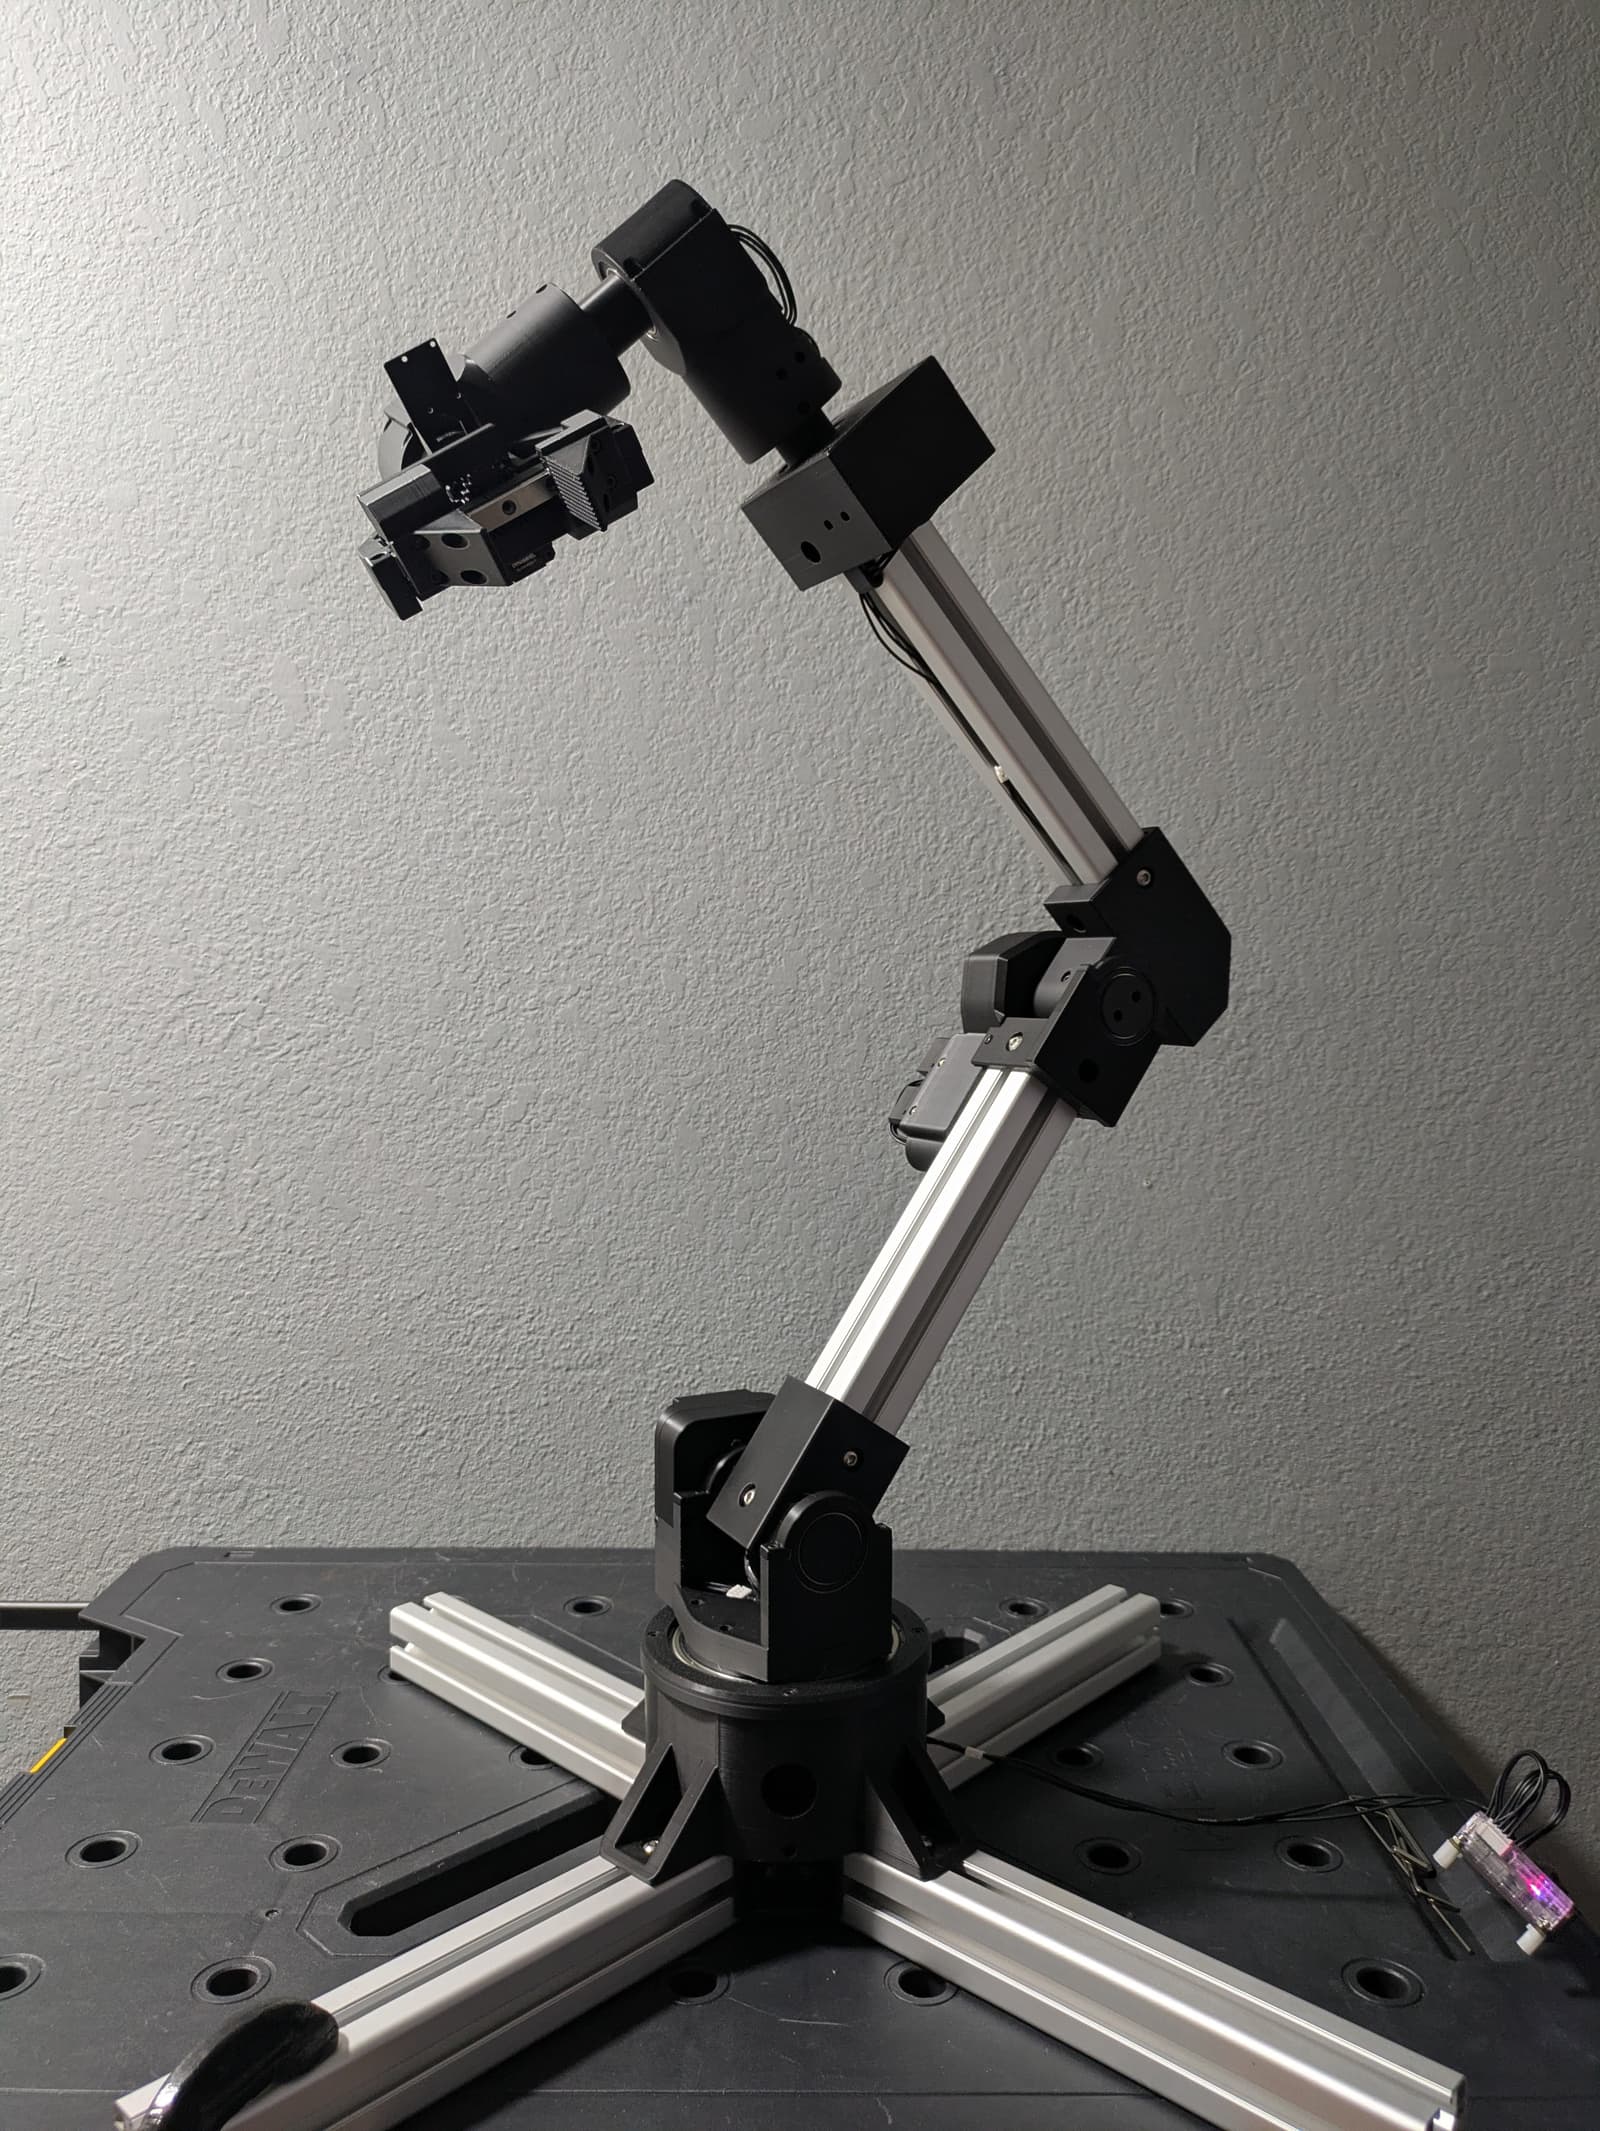
Photo and 3D model

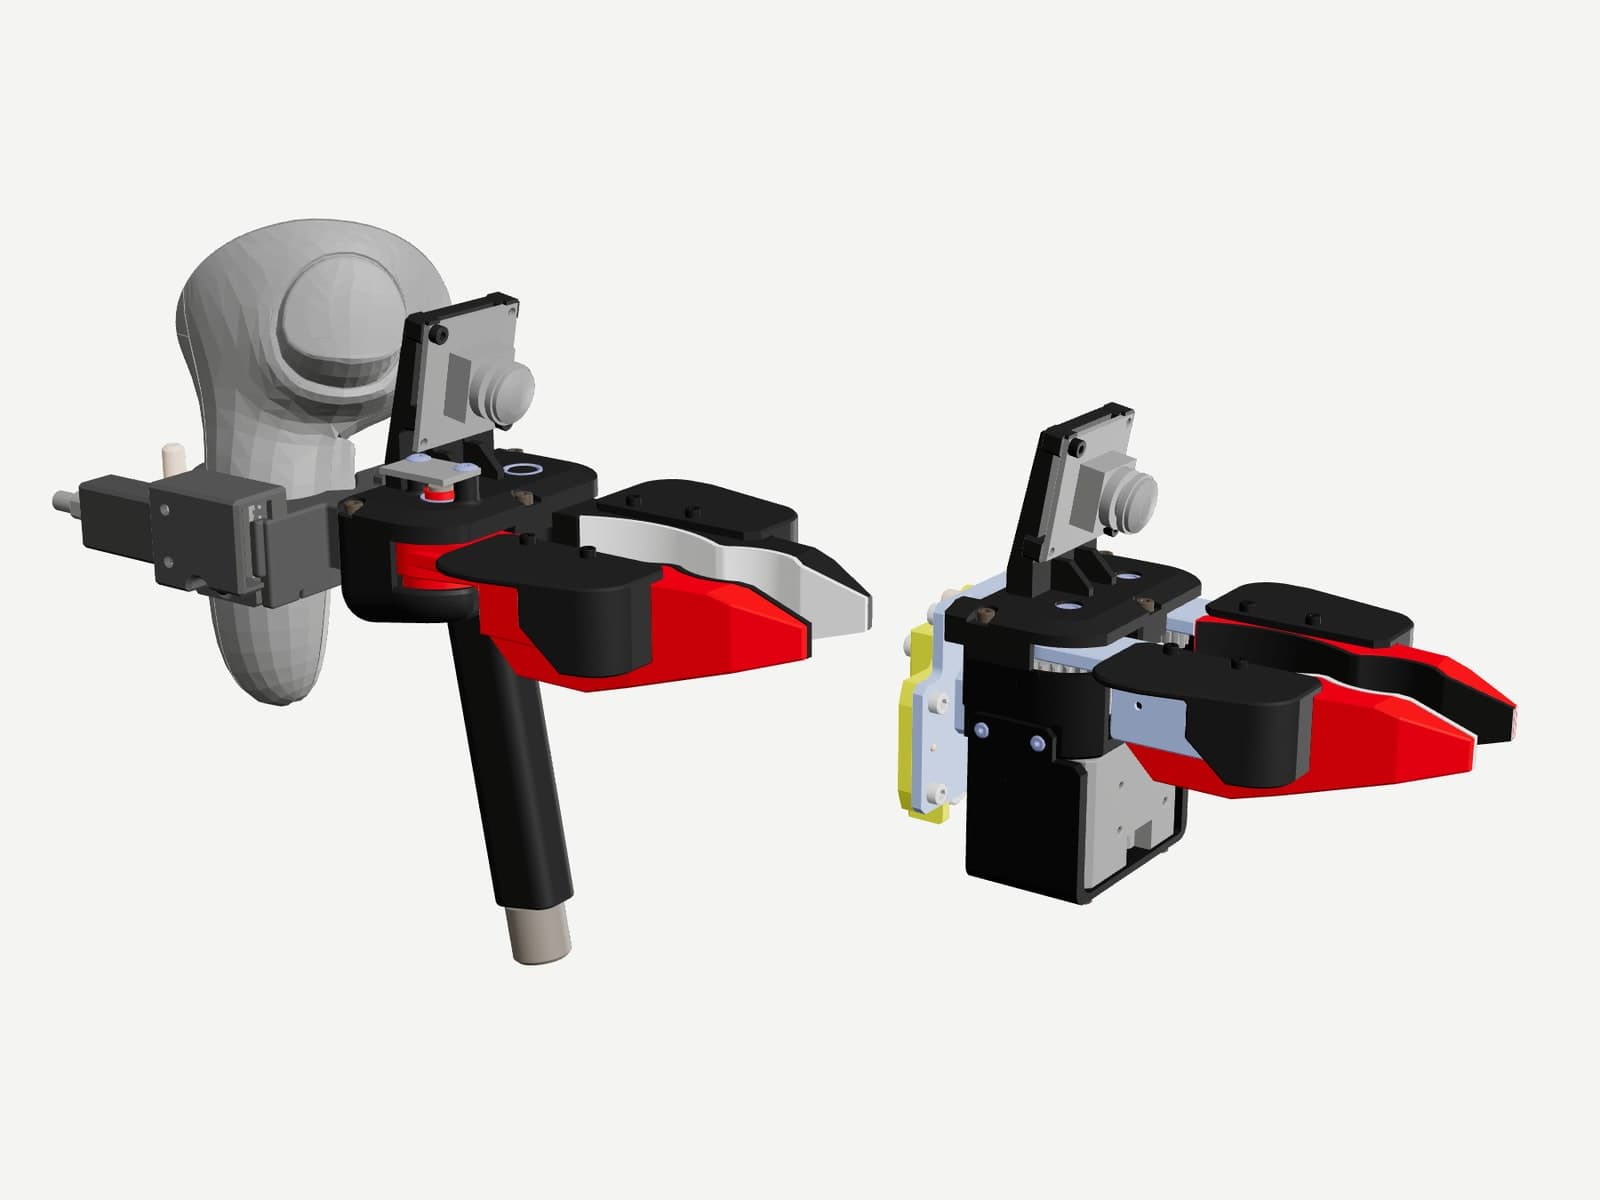
YUBI, a 3D render from Toyota's CAD files: the glove, left, and the gripper, right3D render
3D render by Robotheca from Toyota's CAD files (CERN-OHL-W-2.0) CAD files (opens in a new tab)

3D preview converted from github.com/Toyota/yubi-hw at dd8bd13, under CERN-OHL-W-2.0. View the original files from GitHub (16.7 MB) (opens in a new tab)

Open source · free files

YUBI

Robot arm

An open-source finger-driven teleoperation glove and DYNAMIXEL-actuated robot gripper for dexterous manipulation.

Before you build

Total cost
UnknownNot stated by the creator, and the parts list has no complete total.
Parts still sold
UnknownNo parts list Robotheca can read.
Tools
3D printer
Level
Advanced
Time
UnknownThe creator does not state it.

Read from the repository at commit dd8bd13. Something out of date? Tell us

Project information

Buildability
66/100Buildable with some effort
Parts
Not listed

Suggested by Robotheca, created by @Toyota (opens in a new tab), from github.com/Toyota/yubi-hw (opens in a new tab), pinned to commit dd8bd13 (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots. Last checked on GitHub on 10 November 2026; its last change there was on 21 September 2026.

Build it

The creator's 3 steps, each linked to its instructions
  1. Source components from the Bill of Materials
  2. 3D print parts from the STL files
  3. Follow the assembly instructions to build the hardware

The guide appears here as you scroll.

Guide by @Toyota (README.md), under CERN-OHL-W-2.0 (hardware) and Apache-2.0 (software).

What to buy

This repository has no parts list Robotheca can read yet.

Why it scores 66

It measures the published files, not the robot · How we score

66/100

Buildable with some effort

How complete the published files are for rebuilding this robot, measured by Robotheca at commit dd8bd13. It isn't a rating of the robot. Counted out of 80 points and scaled to 100: the parts that don't apply to this robot are left out.

  1. 13D and CAD files45 printable parts (STL, 3MF), 48 CAD source files.20/20
  2. –Robot descriptionNo URDF. Not counted: the score is made of the parts that apply.Optional: add a URDF, and the robot can be seen in 3D and tried in the browser.Not counted
  3. 2Parts listNo parts list in the repository or linked.Most points to gain: Link to your parts list, or add it to the repository (a CSV or a Markdown table) with quantities, prices and where to buy each part.0/20
  4. 3SoftwareCode linked in another repository (not checked by Robotheca), instructions to install or run it.Say which software framework it uses (ROS 2, LeRobot, Arduino…).8/15
  5. 4DocumentationREADME of 3,898 characters with 5 pictures; 3 build steps.15/15
  6. –SimulationNo simulation files. Not counted: the score is made of the parts that apply.Optional: add a simulation model (MuJoCo, Gazebo, Webots or Isaac).Not counted
  7. 5LicensesHardware: CERN-OHL-W-2.0; software: Apache-2.0.10/10

Wiring and electronics

Notes written by Robotheca from the project's documents, not by its creator

Main parts: Robotheca's summary

  • DYNAMIXEL servos actuate the YUBI Gripper.

What it can do: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator
  • YUBI is a finger-driven dexterous manipulation system for teleoperation and data collection.
  • The YUBI Glove collects finger motion data during teleoperation of a robot.
  • The YUBI Gripper is a robot-mounted gripper for dexterous manipulation.
  • Supports mounting on Franka, OpenArm and Unitree G1 arms via listed flanges.
  • Includes stationary and portable data collection rigs.

Software

Framework
Not stated
License
Apache-2.0

Robotheca doesn't review code. Read it before running it.

How to run it: Robotheca's summary

Written by Robotheca from the project's documents, not by its creator.

  1. 1Source the components listed in the Bill of Materials.
  2. 23D print parts using the STL files.
  3. 3Build the hardware following the assembly instructions.
  4. 4Software for control and teleoperation is provided in the separate yubi-sw repository.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robotheca.yaml, its dependency files read as text, or Robotheca's editors.

Free files

Every file of the project, at commit dd8bd13.

Elsewhere

Listed in robotheca.yaml, outside the repository.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/yubi/badge.svg)](https://robotheca.org/robots/yubi)
[![Robotheca buildability](https://robotheca.org/robots/yubi/score.svg)](https://robotheca.org/robots/yubi)

Licence and credits

Commercial use
Allowed

Other robot arms

All 85 robot arms
  • Ready to build

    Open source · free files

    Giraffe

    Robot arm · Intermediate

    Score
    Buildability 100 out of 100
    Cost
    ₹14,585.71≈ €139
  • Ready to build

    Open source · free files

    Hand Exoskeleton

    Robot arm · Intermediate

    Score
    Buildability 100 out of 100
    Cost
    ¥500≈ €67
  • Ready to build

    Open source · free files

    SO-101

    Robot arm · Beginner

    Score
    Buildability 98 out of 100
    Cost
    €226.30
  • Ready to build

    Open source · free files

    Koch v1.1

    Robot arm · Beginner

    Score
    Buildability 91 out of 100
    Cost
    €673

≈ € values are approximate, converted at the ECB euro reference rate of 9 Nov 2026. The creator's original price always comes first.