Faze4 Robotic Arm
A small, fully 3D printable open-source 6-axis robotic arm with cycloidal gearboxes, built for research, education and hobby use.
- Robot arm
- Open source
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @Source-Robotics (opens in a new tab), from github.com/Source-Robotics/Faze4-Robotic-arm (opens in a new tab). Pinned to commit 674f46c (opens in a new tab).
- Hardware license
- CERN-OHL-S-2.0 (opens in a new tab)
- Software license
- CERN-OHL-S-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 script)
Photo and 3D model
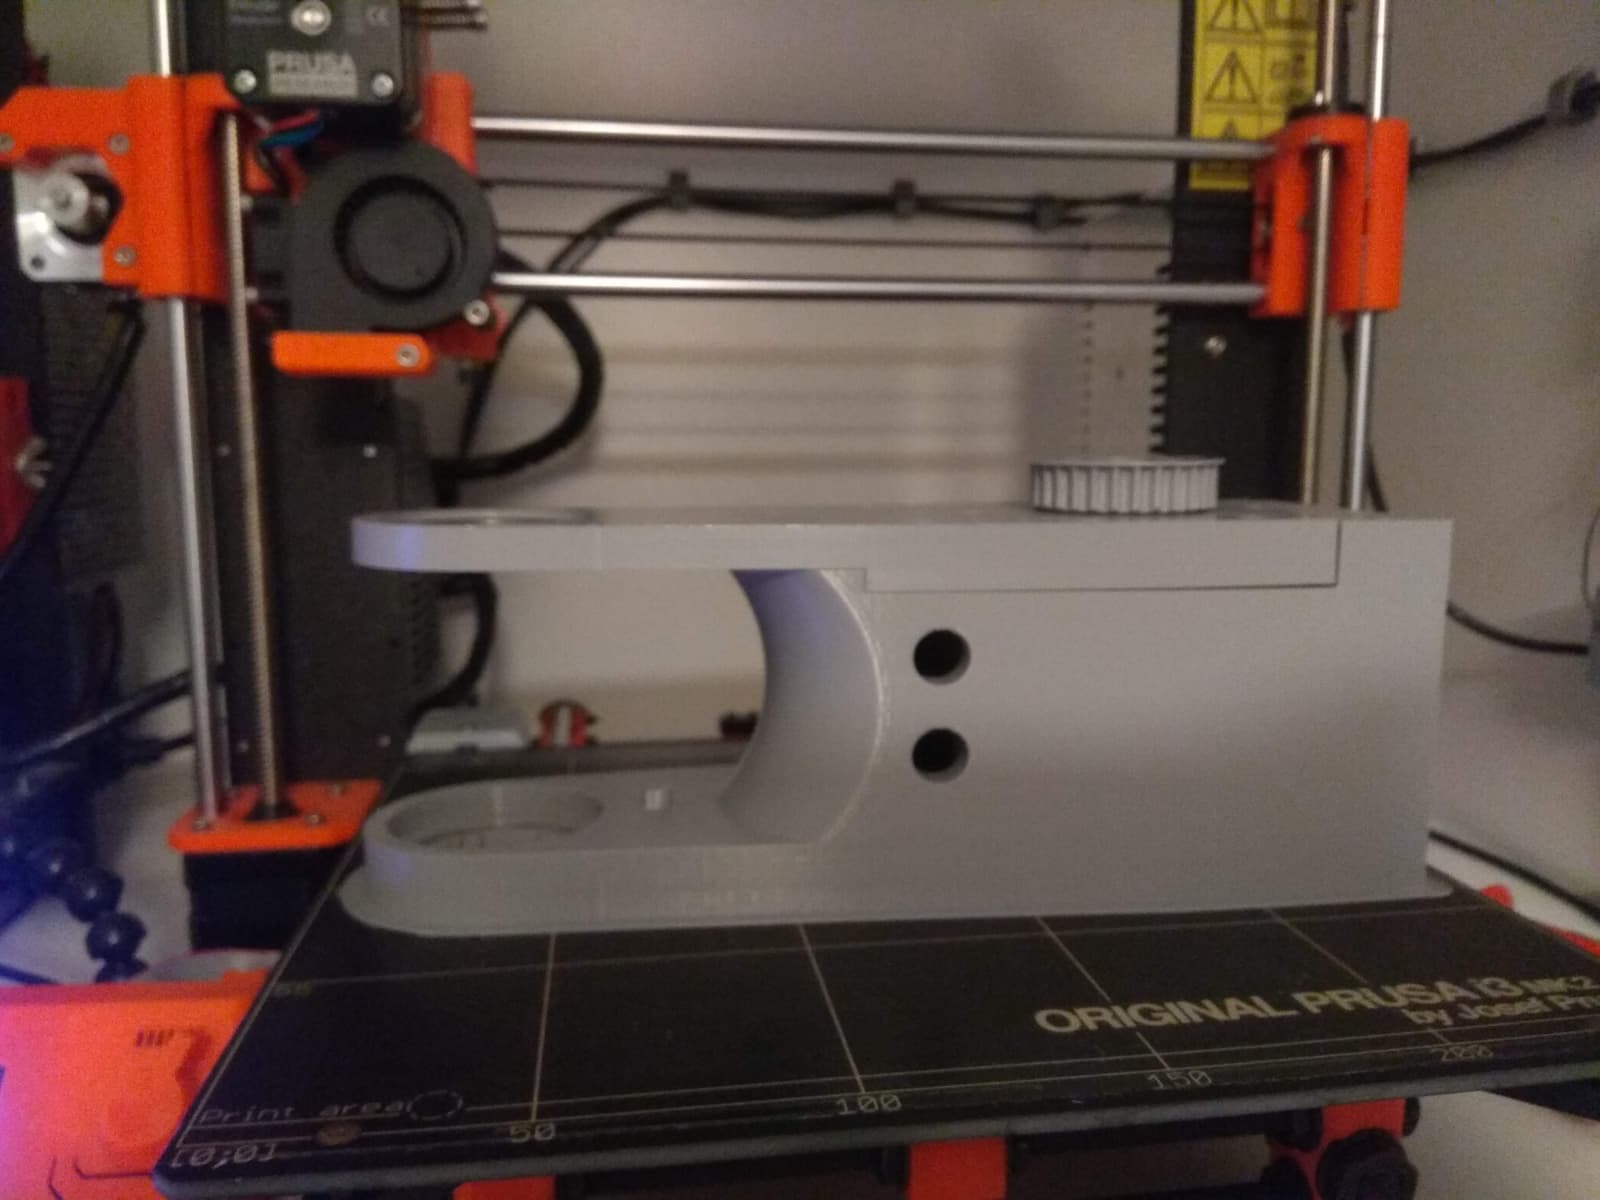
3D preview converted from github.com/Source-Robotics/Faze4-Robotic-arm at 674f46c, under CERN-OHL-S-2.0. View the original files from GitHub (14.1 MB) (opens in a new tab)
- Degrees of freedom
- 6
- Weight
- 15 kg
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Source-Robotics (README.md), under CERN-OHL-S-2.0.
