Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 15 Oct 2026. Robots without a known cost are hidden unless you include them.

270 robots

Page 6 of 12 · Ready to build first, then by buildability

  • Photo on GitHub
    Robot arm

    VEILINK Arm

    A 6-DOF robotic arm built with 3D-printed parts and Feetech STS3215 bus servos, controlled via LeRobot.

    • Work in progress
    • Works with AI
    • No license
    Level
    Intermediate
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    WhaleBot

    An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.

    • Work in progress
    • Works with AI
    Level
    Beginner
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    ZeroBug

    A 3D-printed micro-servo hexapod robot controlled by a Raspberry Pi Zero, with an STM32F103 handling leg locomotion and inverse kinematics for its 18 servos.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

    12-DOF Quadruped Robot

    A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    6-DOF Articulated Robot Arm V1

    A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    ALTO 3D Printed 6 Axis Robotic Arm

    A 3D printed desktop high precision 6 axis robotic arm controlled over USB with a Python API.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    $400≈ €357 (ECB rate, 15 Oct 2026)
  • No photo yet
    Wheeled

    Creative Mini Car Modification

    A series of open-source remote-controlled mini car modification projects with multiple chassis sizes and control schemes.

    • Work in progress
    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    DengFOC Balance Bot

    A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

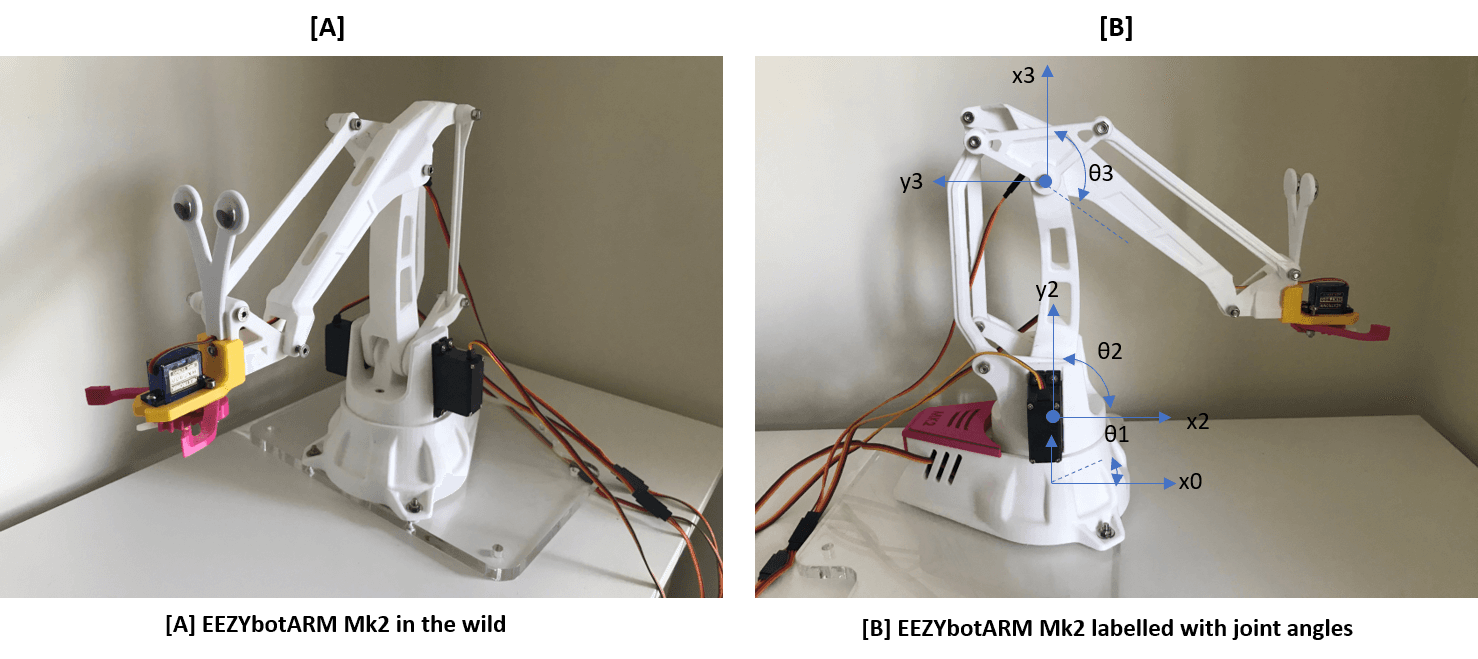
    EEZYbotARM

    A four-axis, 3D-printable hobby robot arm controlled from Python and Arduino, with 3-D forward and inverse kinematics.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

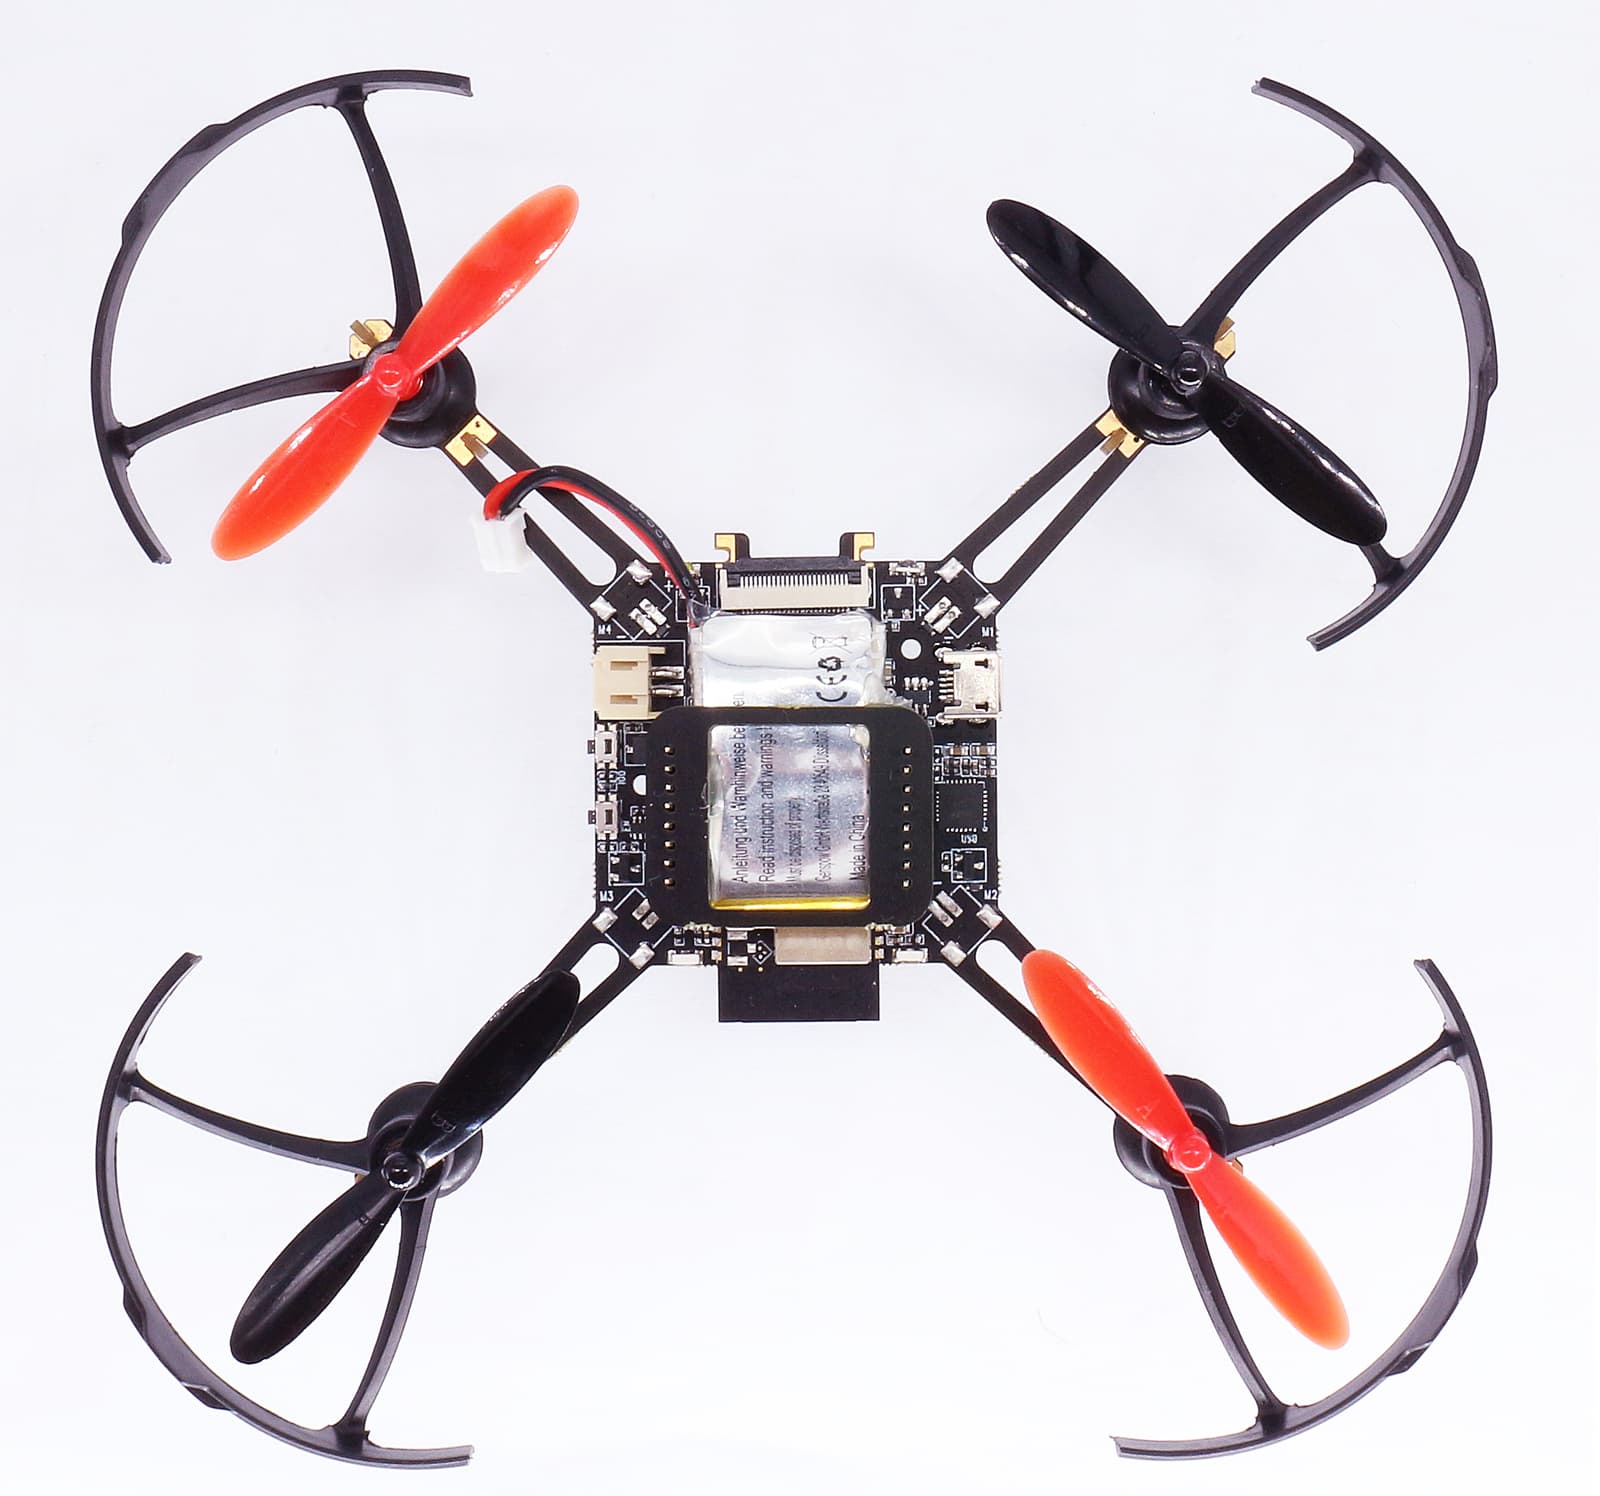
    ESP-Drone

    A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

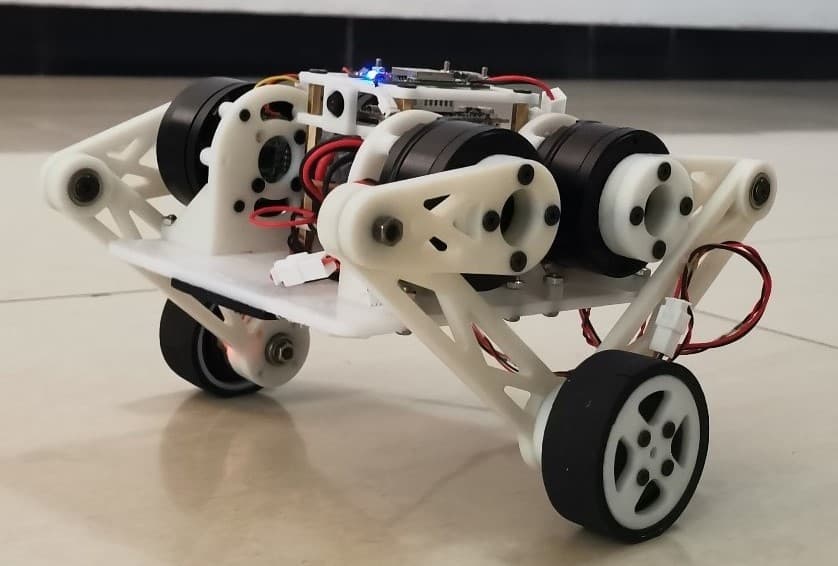
    FOC Dual-Wheel-Legged Robot

    An open-source wheeled-legged robot featuring mechanical design, electronics, embedded software, and FPV remote control.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Humanoid

    Head-Neck Control

    A biomimetic robot head with tendon-driven neck controlled via Raspberry Pi and PCA9685 servos.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

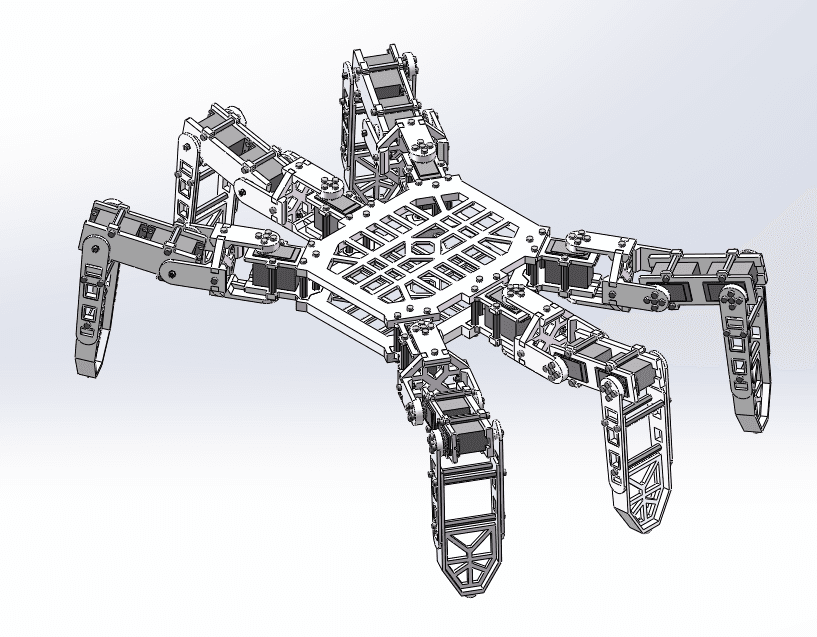
    Hexapod Robot

    A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Robot arm

    Jyker Arm

    An open-source 3D-printed robotic arm with 5 degrees of freedom and a gripper.

    • Works with AI
    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Robot arm

    Linco Robot Arm

    A desktop robotic arm designed for easy 3D printing with minimal parts, featuring a 3D-printed structure and basic electronic components.

    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Wheeled

    Mars Rover

    A 3D printed, driveable rover inspired by NASA's Curiosity and Perseverance, controlled over LoRa, WiFi websocket, or an RC transmitter.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Other

    Mech Butterfly

    A biomimetic butterfly robot controlled via ESP32C3 using ESP-NOW wireless communication.

    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

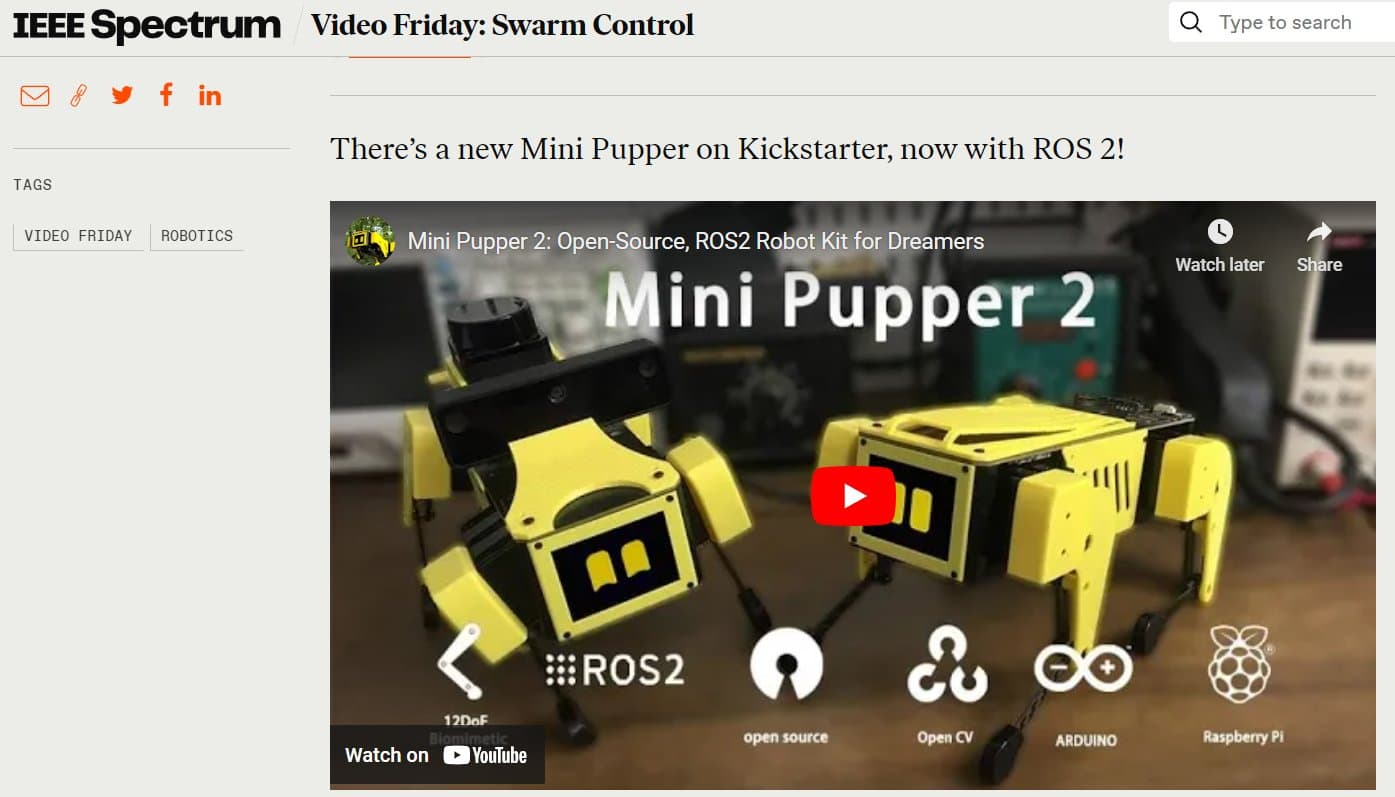
    Mini Pupper

    An open-source, ROS-based quadruped robot dog designed for education and research, supporting SLAM, navigation, and OpenCV AI features.

    • Works with AI
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    $500≈ €446 (ECB rate, 15 Oct 2026)
  • Photo on GitHub
    Quadruped

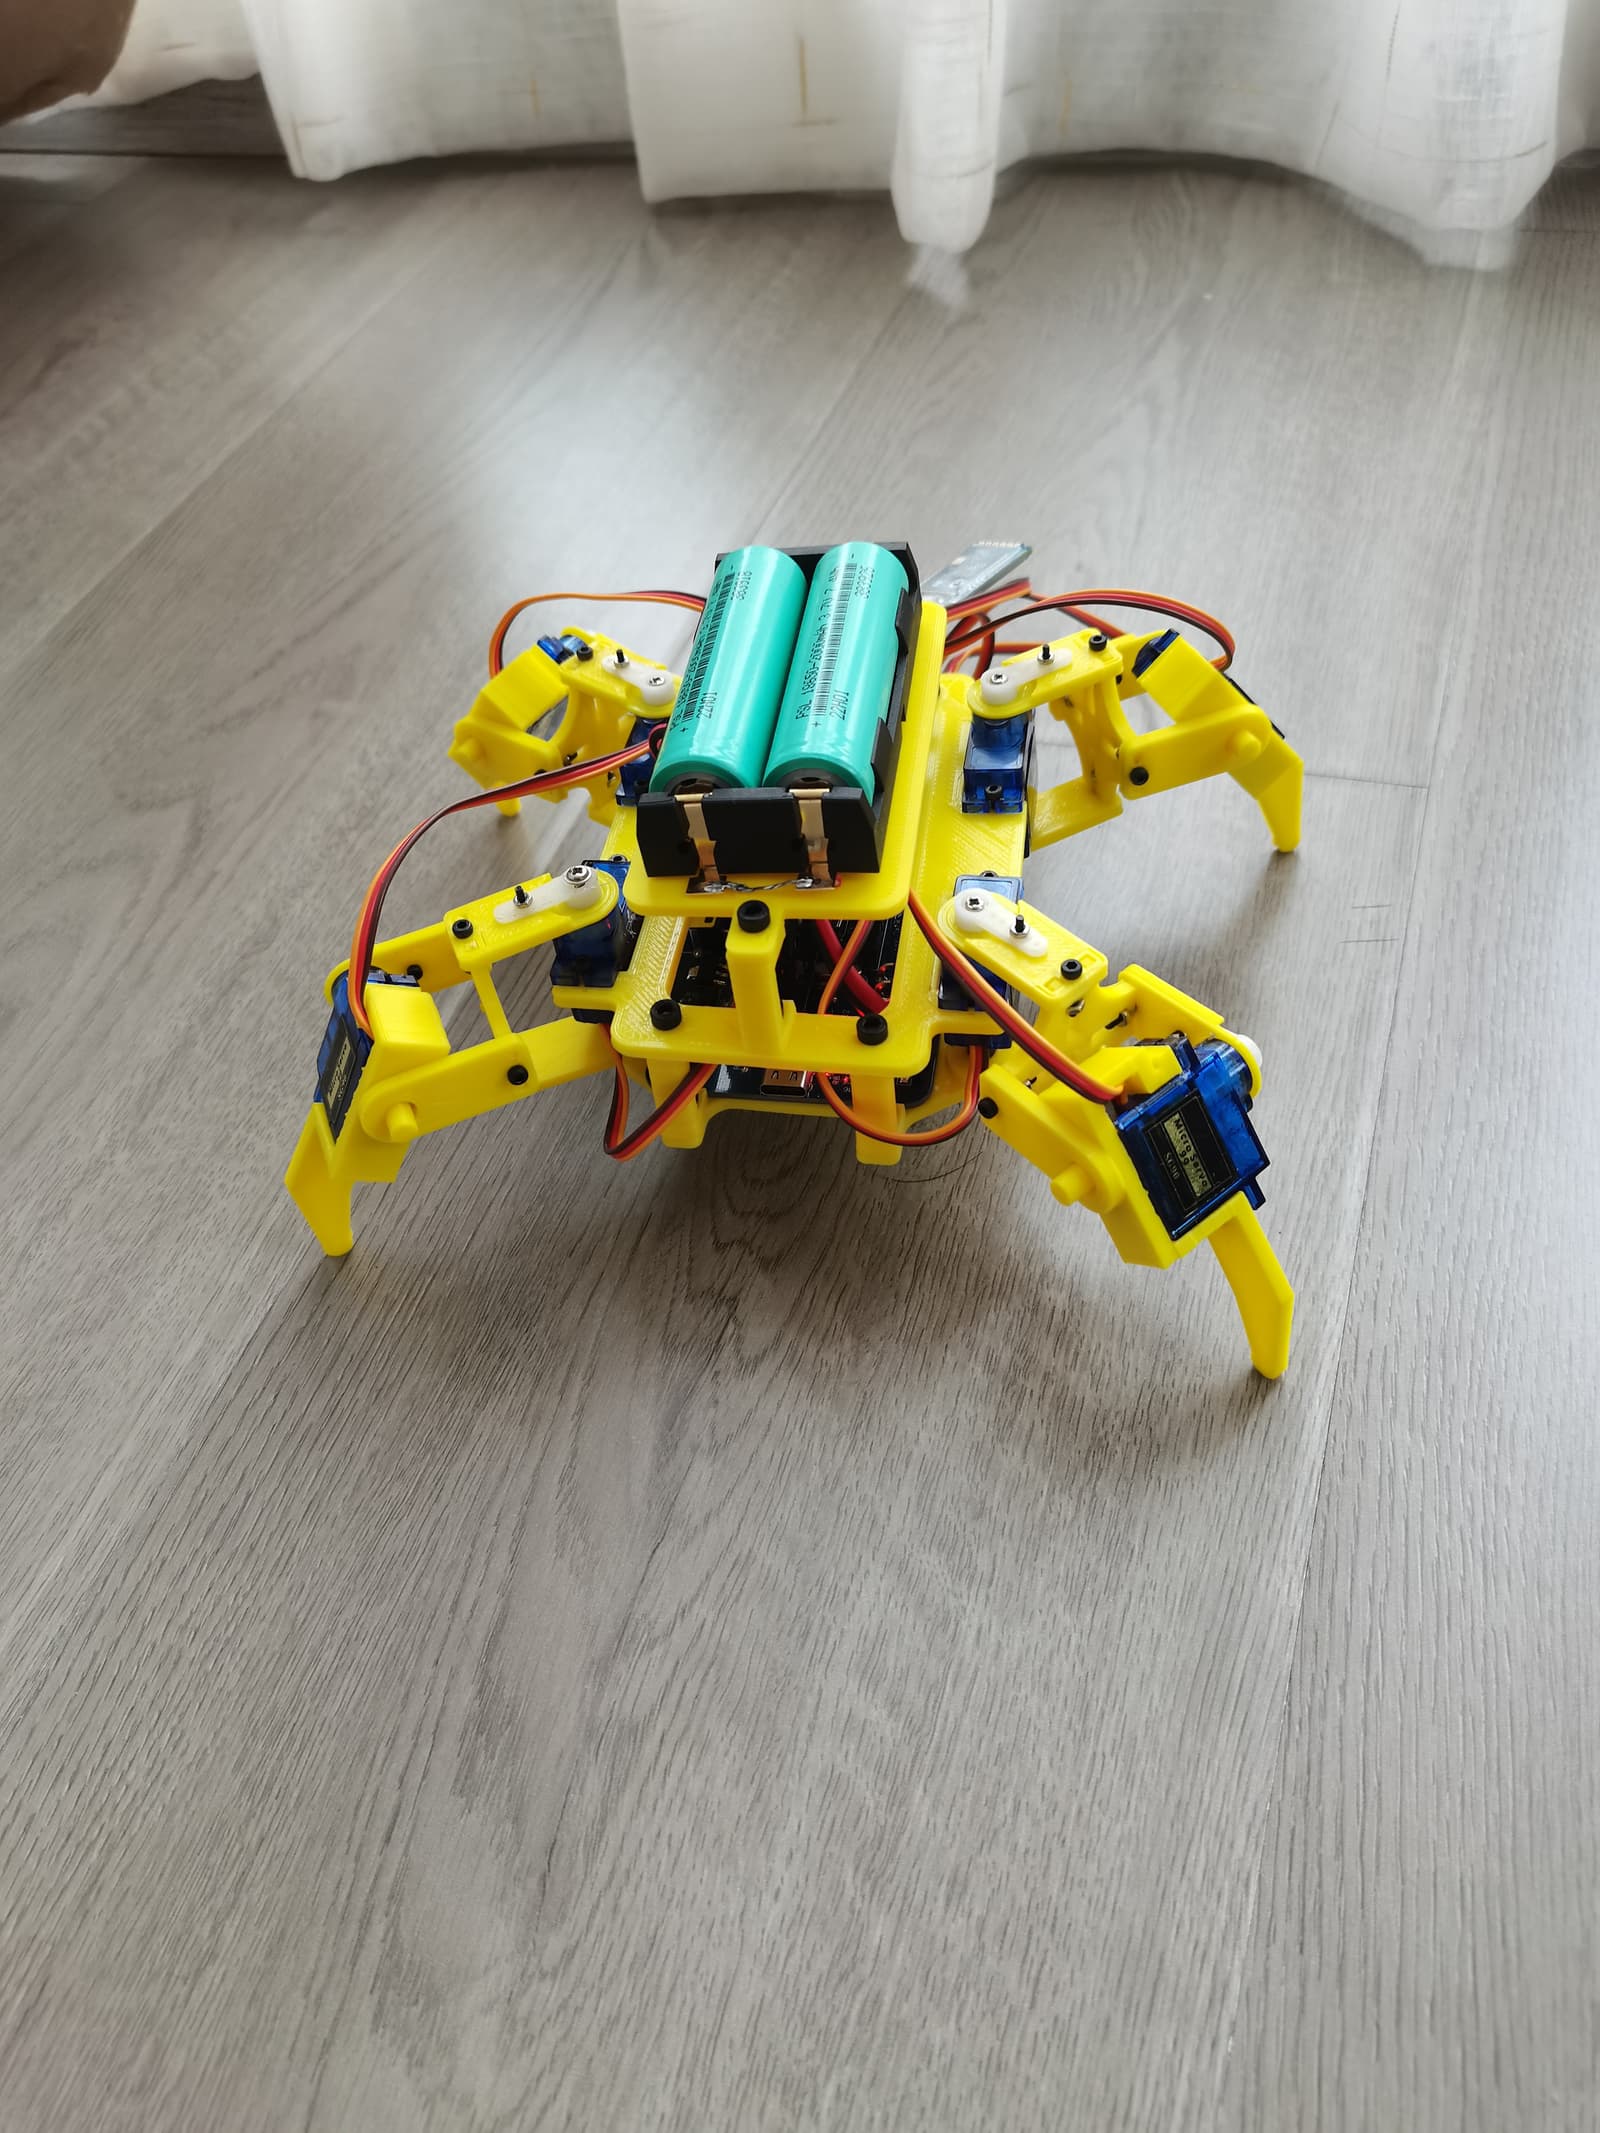
    NodeHexa

    An open-source ESP32-based six-legged robot with Web control, calibration, performance motions, motion sequences and optional voice interaction.

    • Works with AI
    • No license
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Quadruped

    openDog V3

    A quadruped robot dog built from 3D-printed PLA parts, driven by ODrive-controlled motors with AS5047 absolute encoders and a remote-controlled walking mode.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

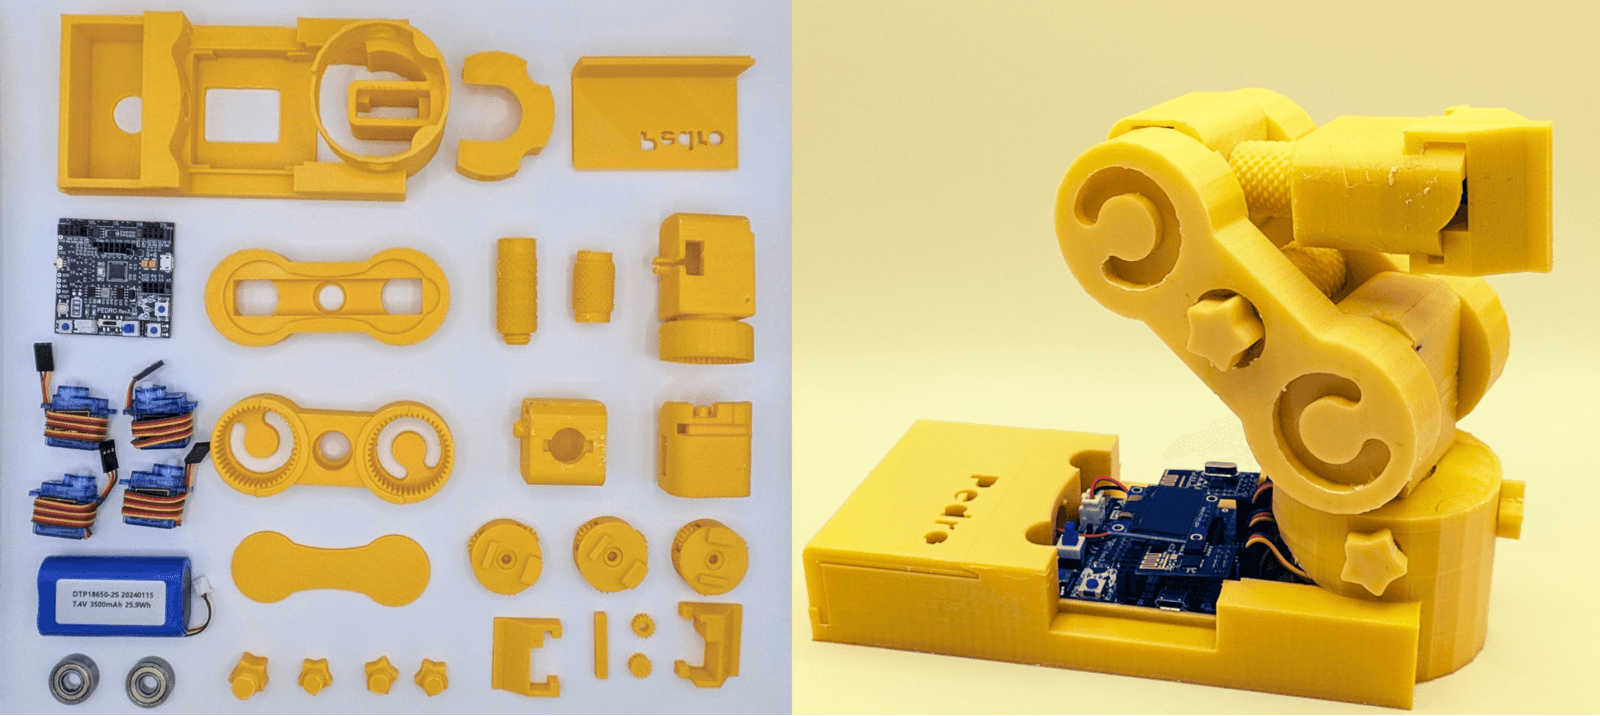
    Pedro

    Pedro is an open-source STEM robot whose 3D-printable parts (arm, gear, servo holder and base) are provided as STL files.

    Level
    Beginner
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

    Quadruped Robot

    A four-legged robot designed for research and education in legged locomotion.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

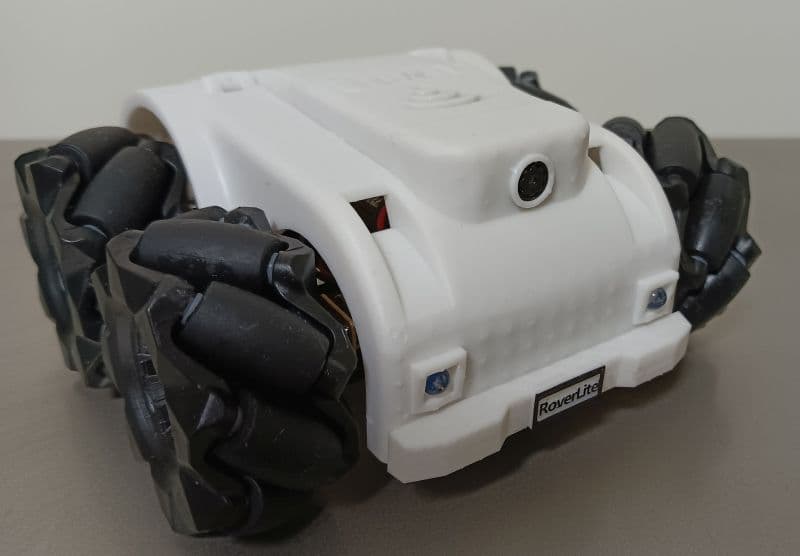
    RoverLite32

    A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    SCARA Parallel

    A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated

Robots 121–144 of 270

More to explore