4T-POM-X4
An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
- Quadruped
- Open source
- 3D printable
Suggested by Robotheca, created by @4T-tech (opens in a new tab), from github.com/4T-tech/4T_POM_X4_robot (opens in a new tab). Pinned to commit 98cb955 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 script, 1 program or installer, 11 firmware images)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/bootloader/bootloader.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/bootloader/bootloader.elf (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/bootloader/CMakeFiles/3.30.2/CMakeDetermineCompilerABI_C.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/bootloader/CMakeFiles/3.30.2/CMakeDetermineCompilerABI_CXX.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/CMakeFiles/3.30.2/CMakeDetermineCompilerABI_C.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/CMakeFiles/3.30.2/CMakeDetermineCompilerABI_CXX.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/esp-idf/esp_system/CMakeFiles/sections.ld-d65dc84.bat (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/partition_table/partition-table.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/project-name.bin (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_C6/build/project-name.elf (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_G4/MDK-ARM/IO_Test/IO_Test.hex (opens in a new tab)
- [1]控制算法与固件/Robot_Contorl_SDK_RP/mdk/pico/rp2040_example.uf2 (opens in a new tab)
- [4]蓝牙app/4T-POM-X4_Ctrl_app.apk (opens in a new tab)
Photo and 3D model
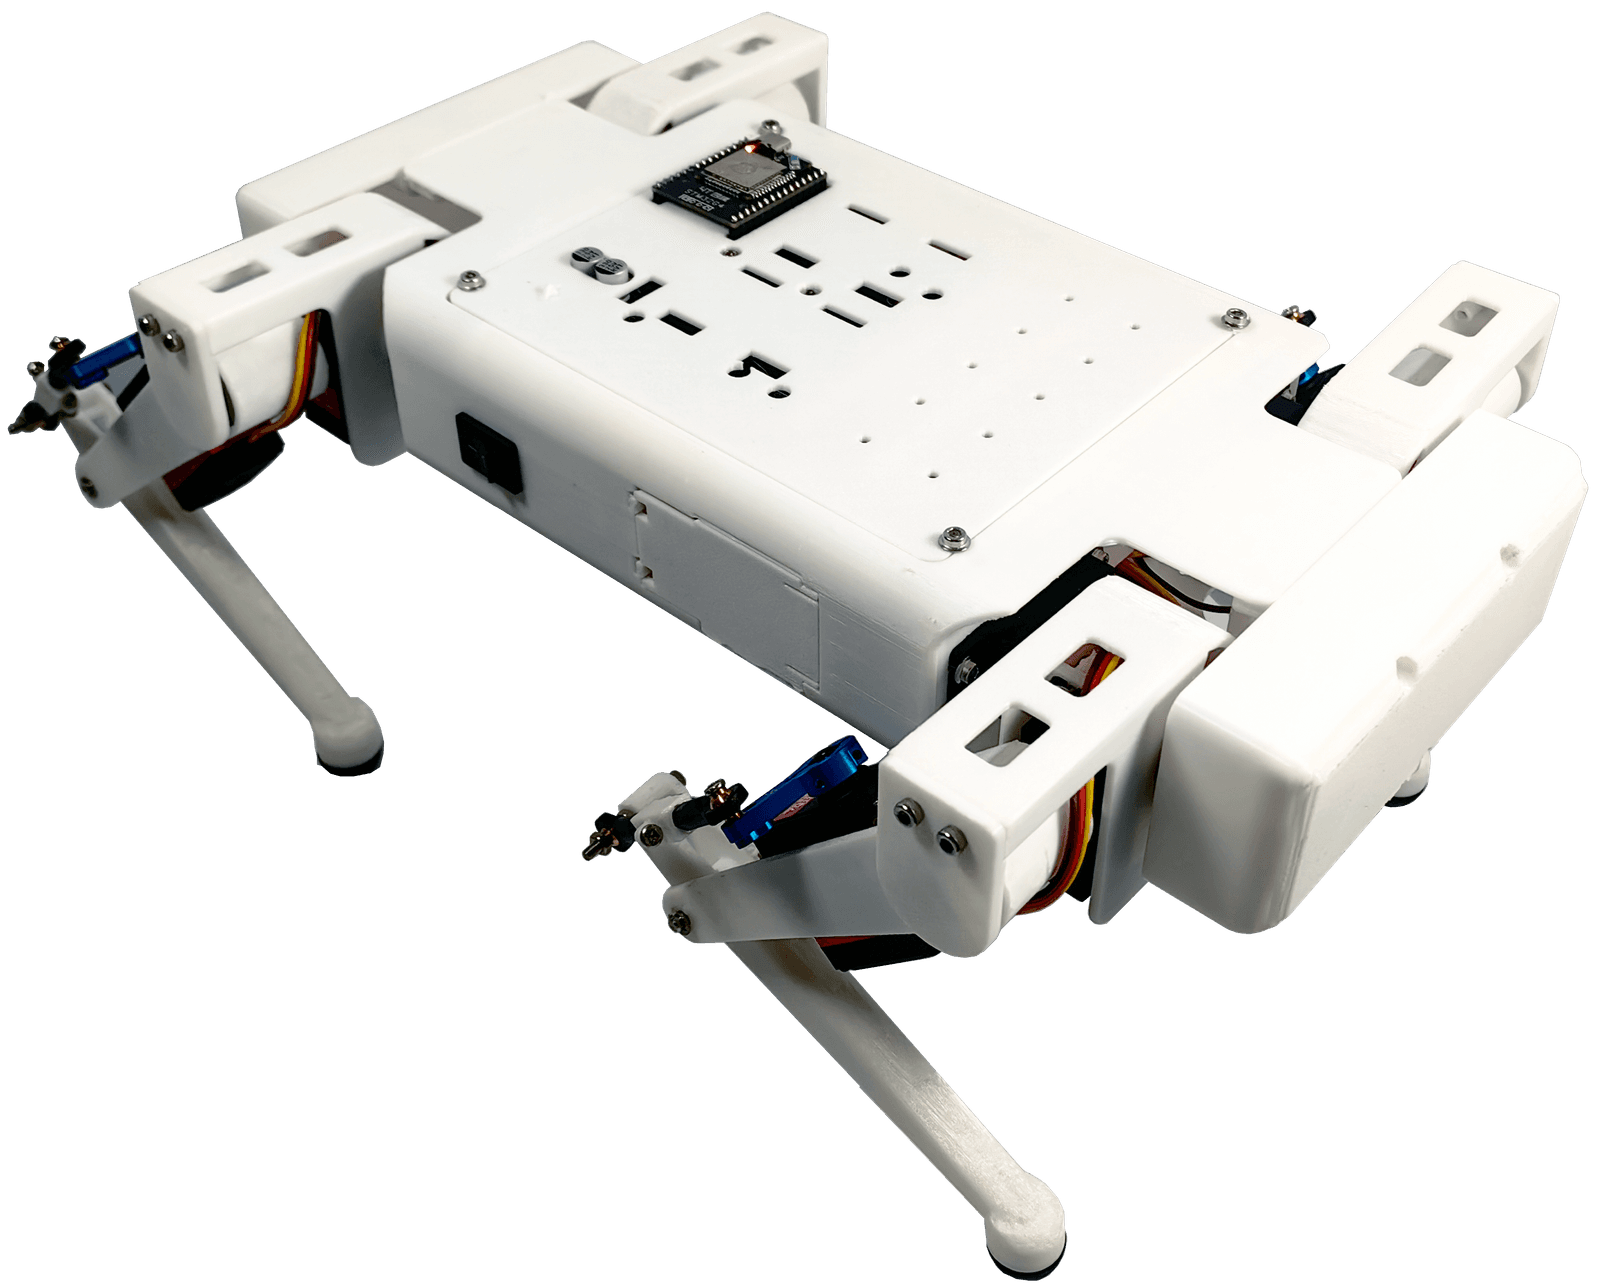
3D preview converted from github.com/4T-tech/4T_POM_X4_robot at 98cb955, under GPL-3.0-only. View the original files from GitHub (2.6 MB) (opens in a new tab)
- Degrees of freedom
- 12
What it can do
Written by Robotheca from the project's documents.
- Walks with slow and trot gaits
- Adjusts standing posture
- Moves forward, backward, sideways and turns
- Controlled via Bluetooth app or PC upper computer
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Prepare 3D printed parts
- 2Assemble mechanical components
- 3Install control modules and servo drivers
- 4Upload firmware
- 5Connect and test with Bluetooth app
The guide appears here as you scroll.
Guide by @4T-tech (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- POM_Nano_G4, POM_Nano_C6 or POM_Nano_RP control module
- 32-channel servo driver board (POM_SC32)
- Twelve high-speed hollow-cup servos
- Bluetooth module for app control
Connections
- Servo driver board connected to control module via TTL serial
- Servo driver board powered from 3S/4S/5S Li-ion battery