Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 15 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

95 robots of 270

Page 2 of 4 · Ready to build first, then by buildability

  • Other

    Balance Ball

    A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    ¥1,000≈ €133 (ECB rate, 15 Oct 2026)
  • No photo yet
    Humanoid

    CocoNuts

    An open-source humanoid robotics research platform that minimizes leg inertia by concentrating mass near the limb roots using timing belts and parallel linkages.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

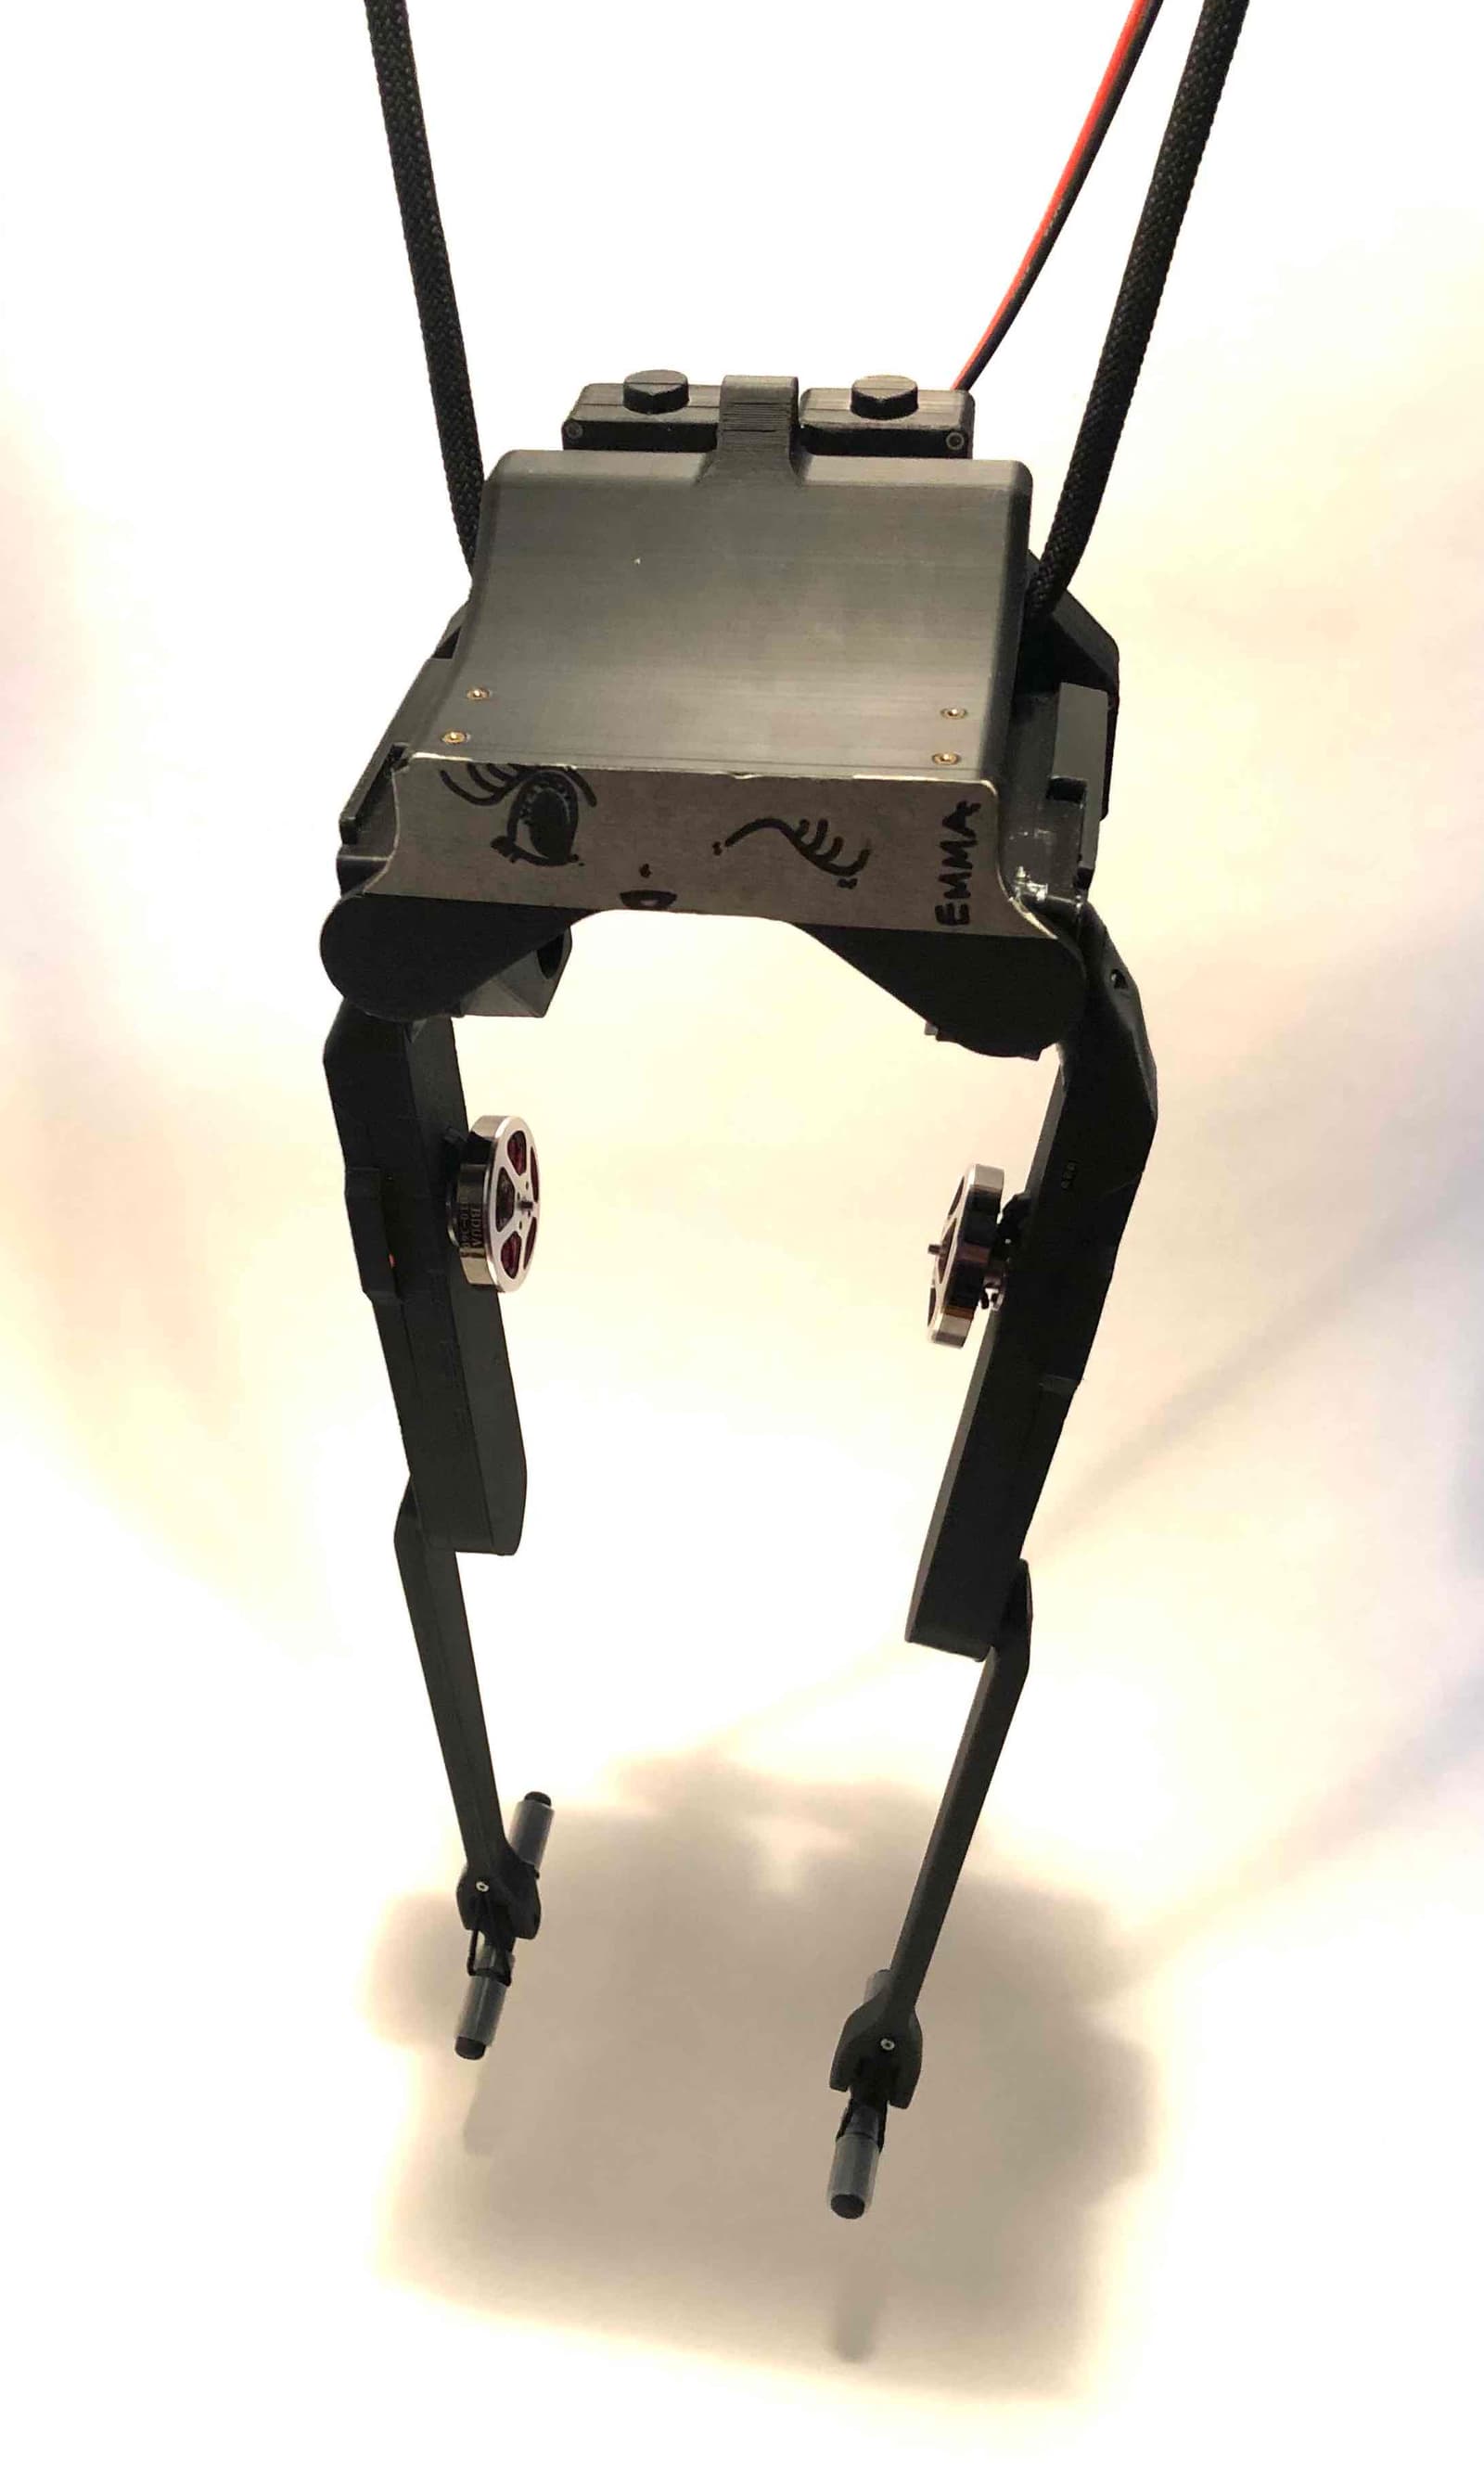
    Dagor Biped

    A low-cost, easy-to-print biped robot hardware design remixed from the Open Robot Dynamic Initiative Bolt robot, controlled by the Dagor brushless motor control module.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Humanoid

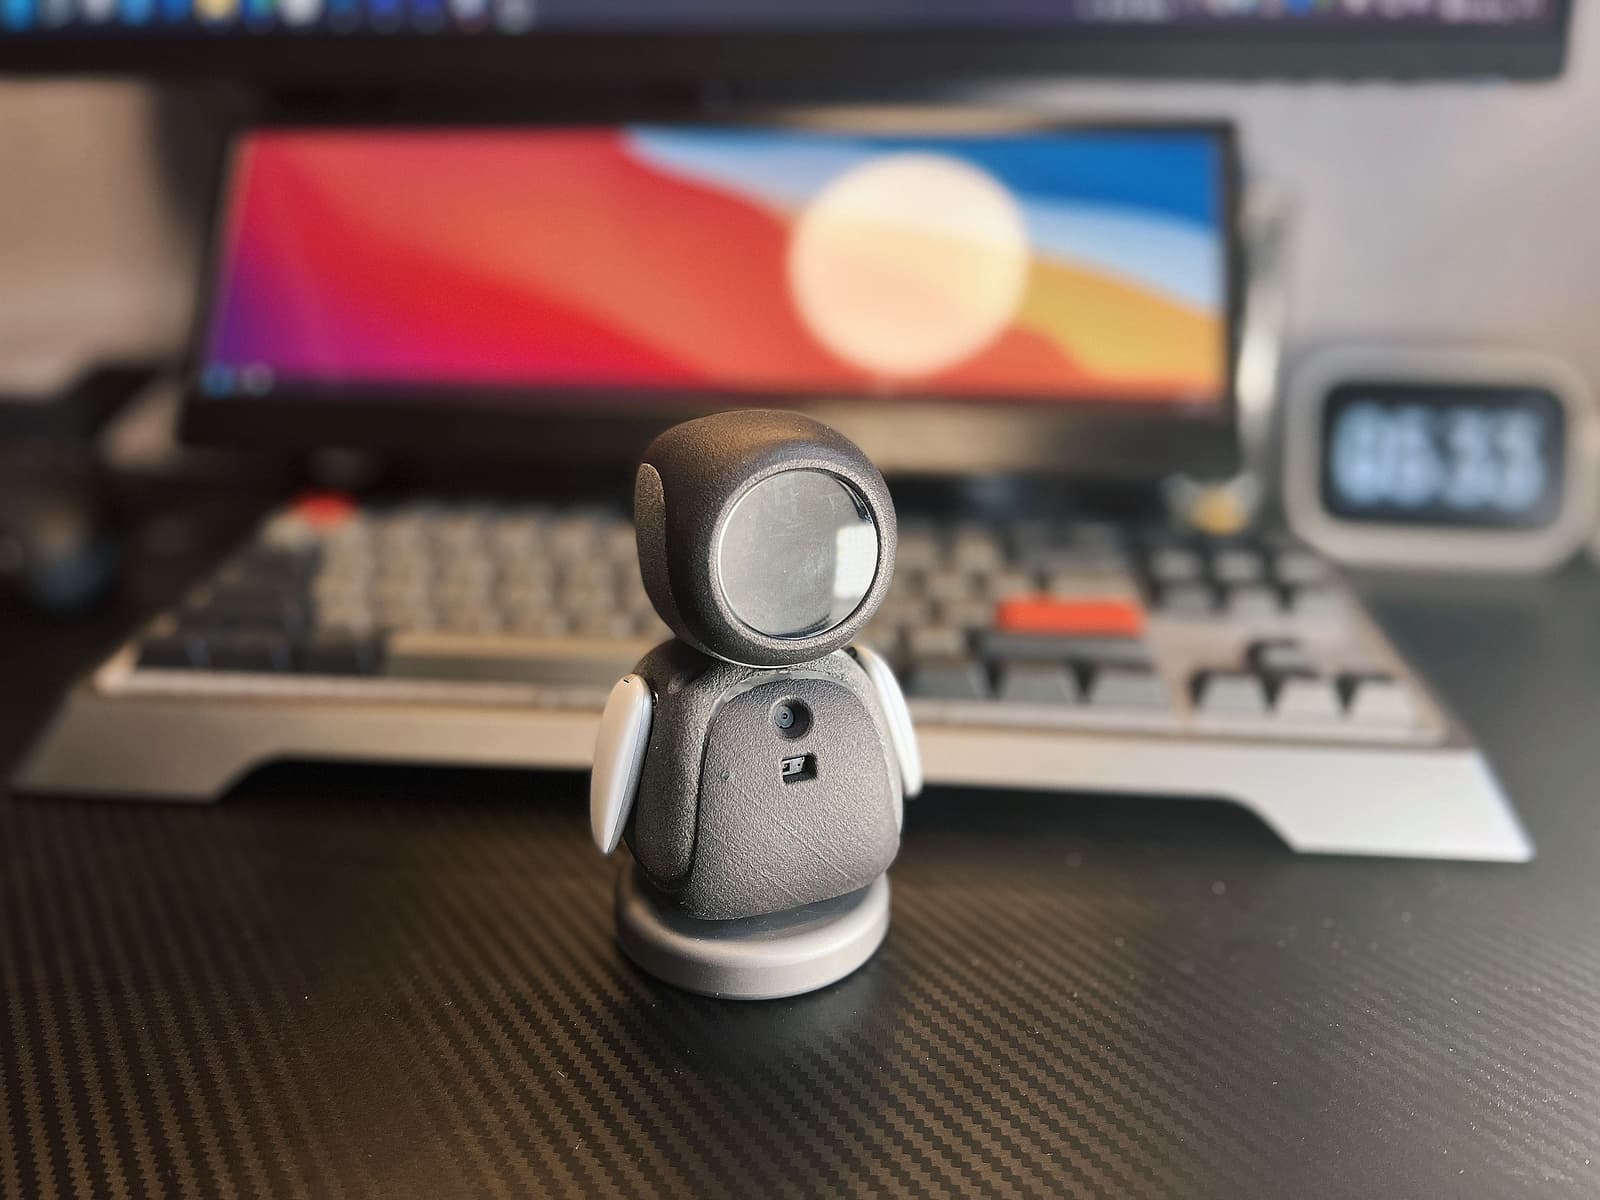
    ElectronBot

    A mini desktop robot with 6 degrees of freedom, USB communication, and a display screen, inspired by WALL-E's EVE.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Self-driving 1:10

    EquiCycle

    An autonomous self-balancing bicycle robot designed for outdoor track racing, featuring lane detection, obstacle recognition, and balance control algorithms.

    • Works with AI
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

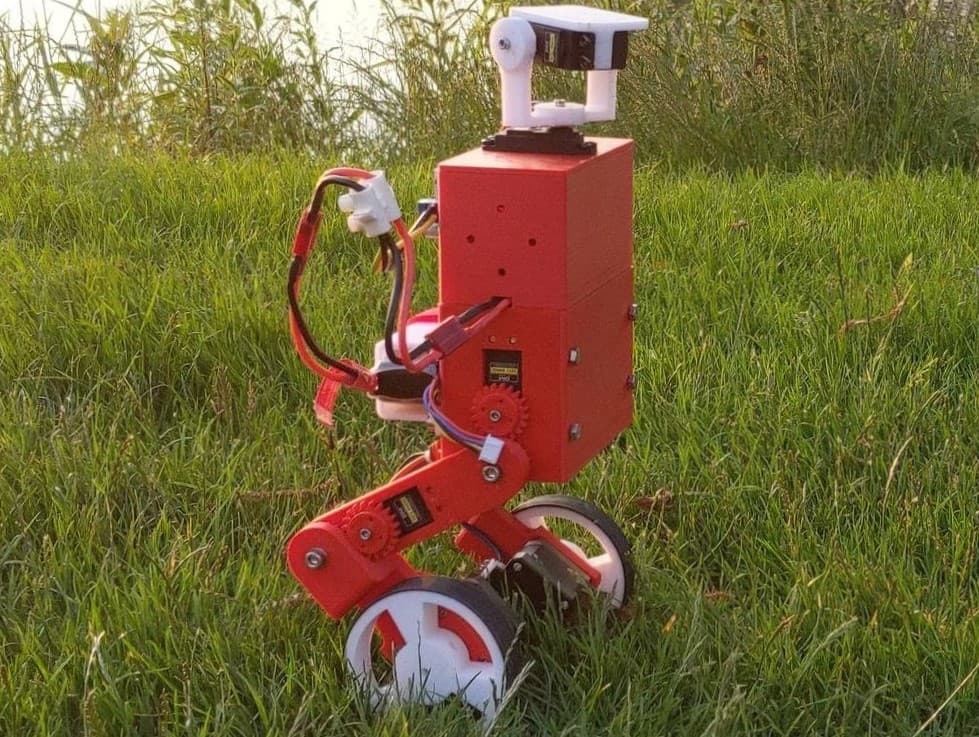
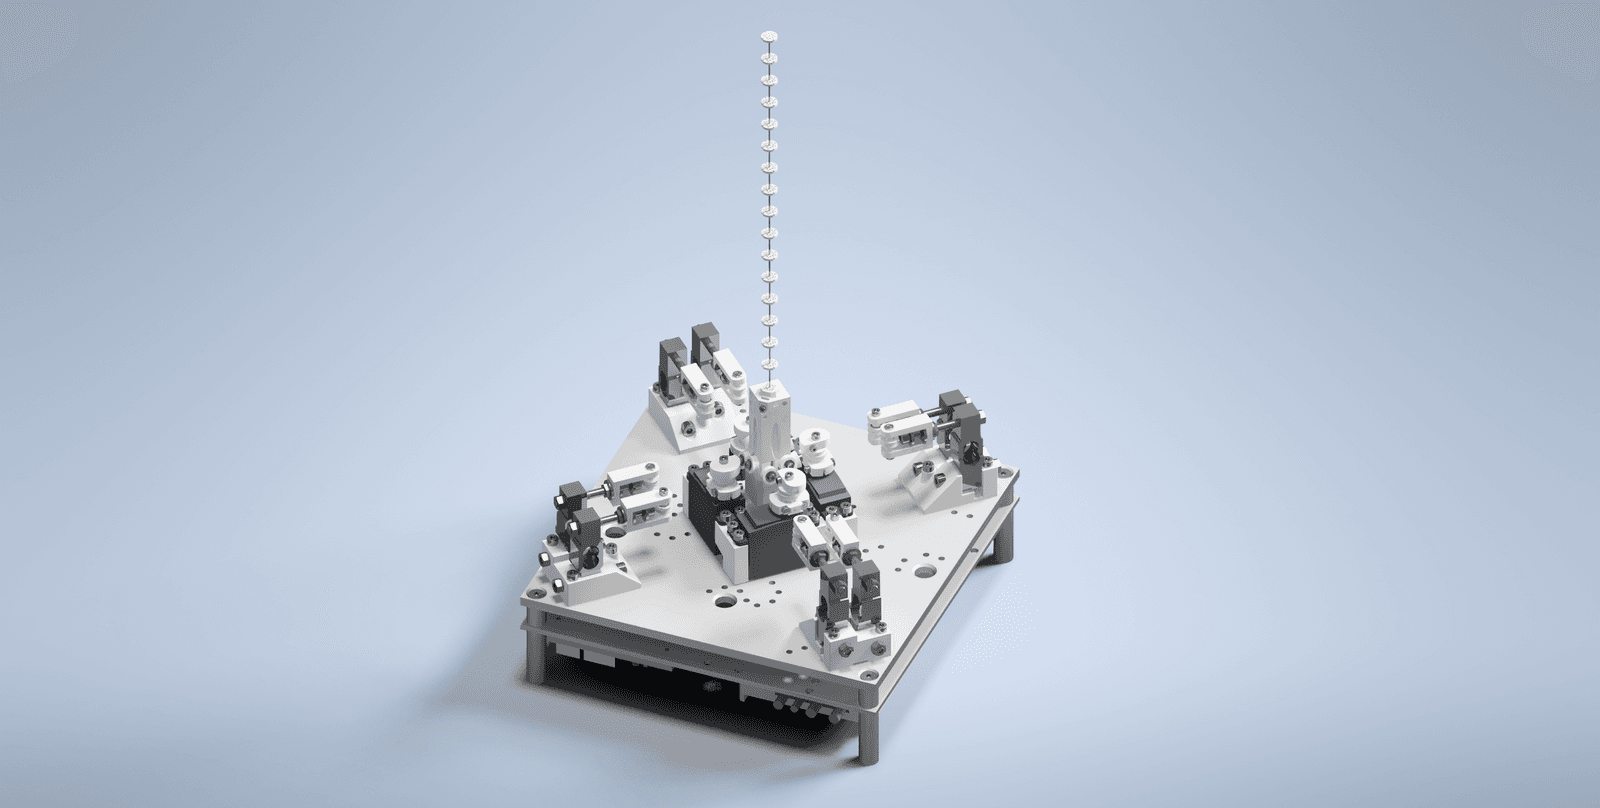
    MABEL

    MABEL is an open-source legged balancing robot based on the Boston Dynamics Handle, with articulated legs that can adjust height and balance in multiple axes.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

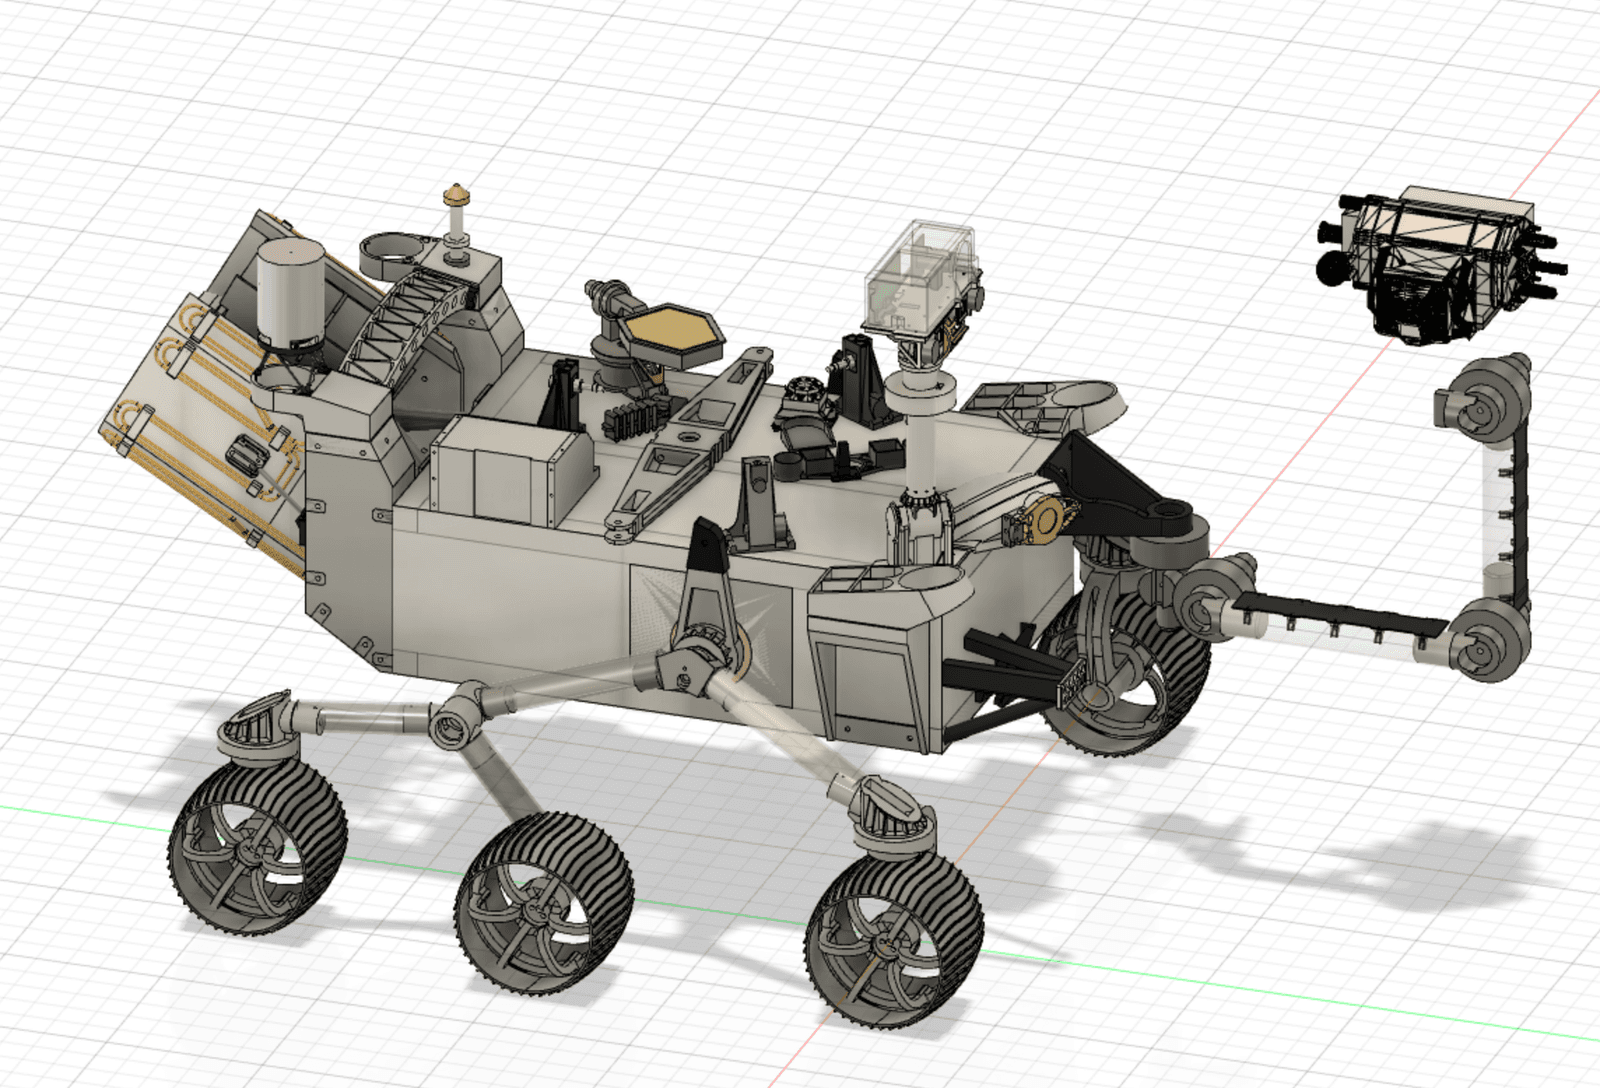
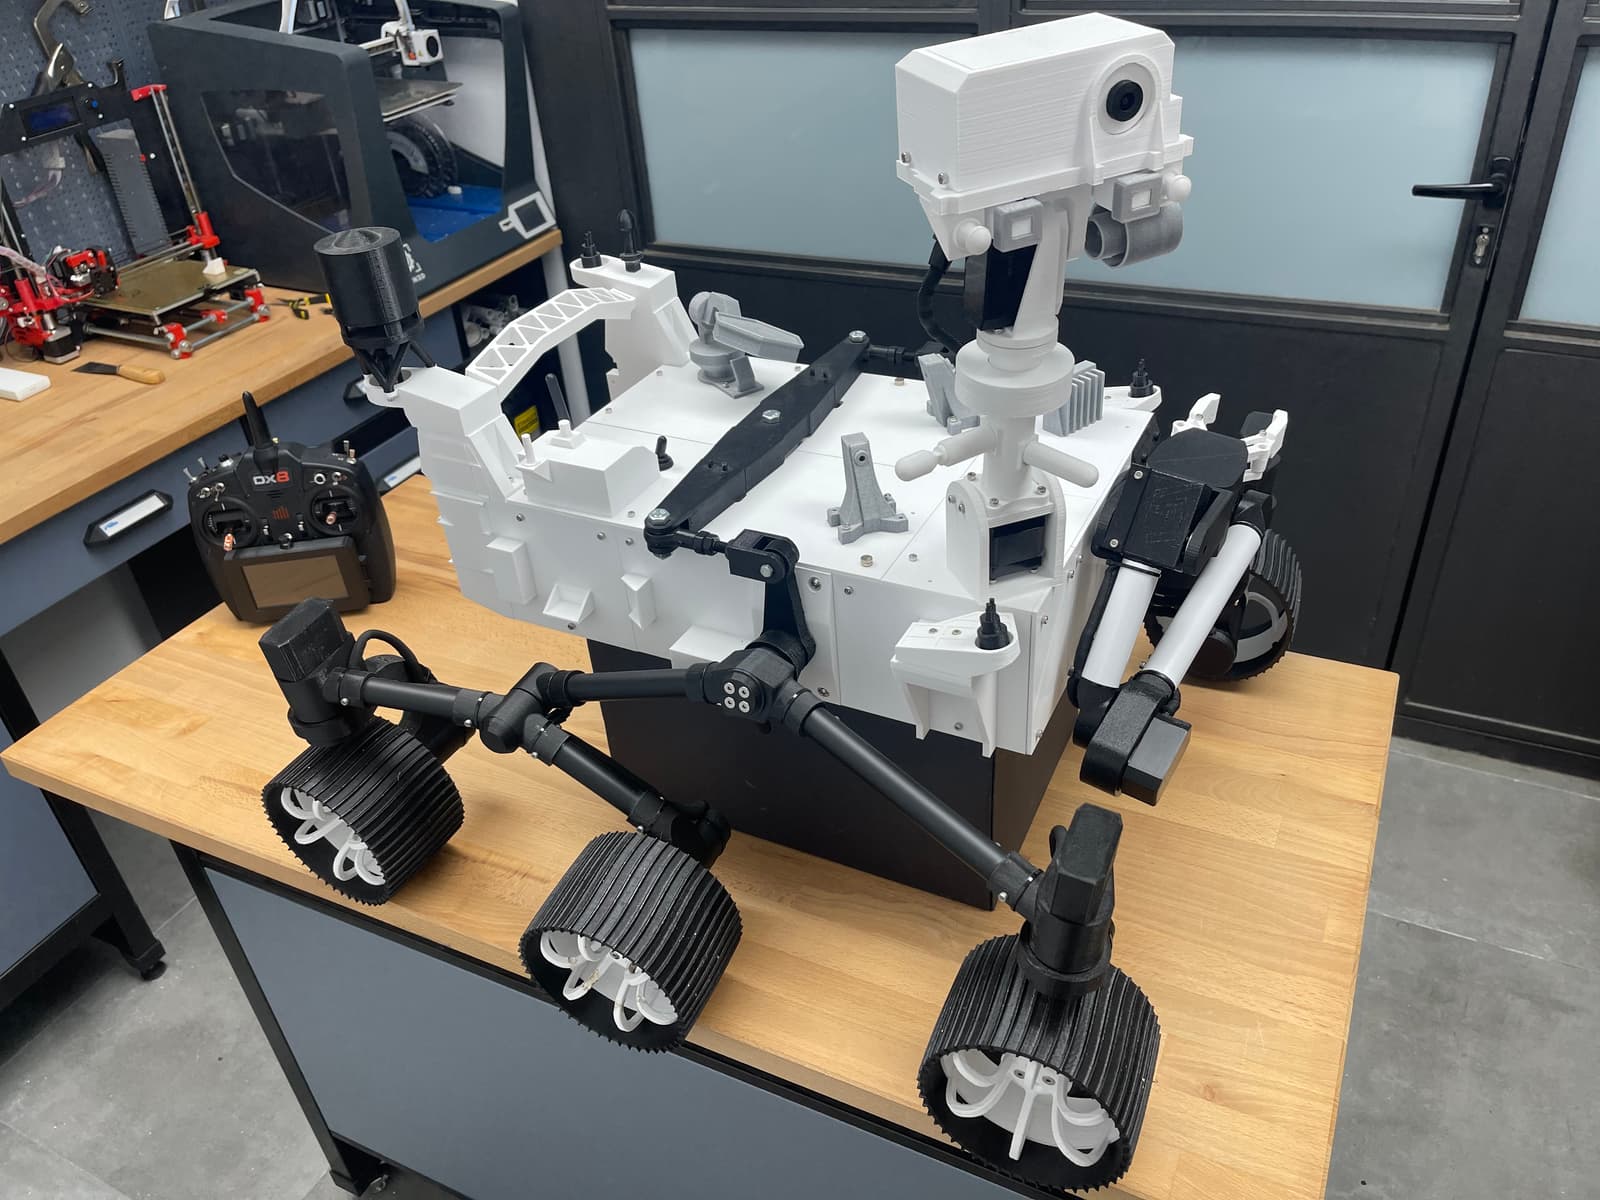
    OpenPerseverance

    A 3D printed, remote controlled rover modeled on NASA's Perseverance Mars rover, built from open-source printable parts.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    SoftRobotETF

    A low-cost, modular open-source soft robotics platform with tendon-driven continuum robots controlled by force-feedback actuators over serial and I2C.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • Quadruped

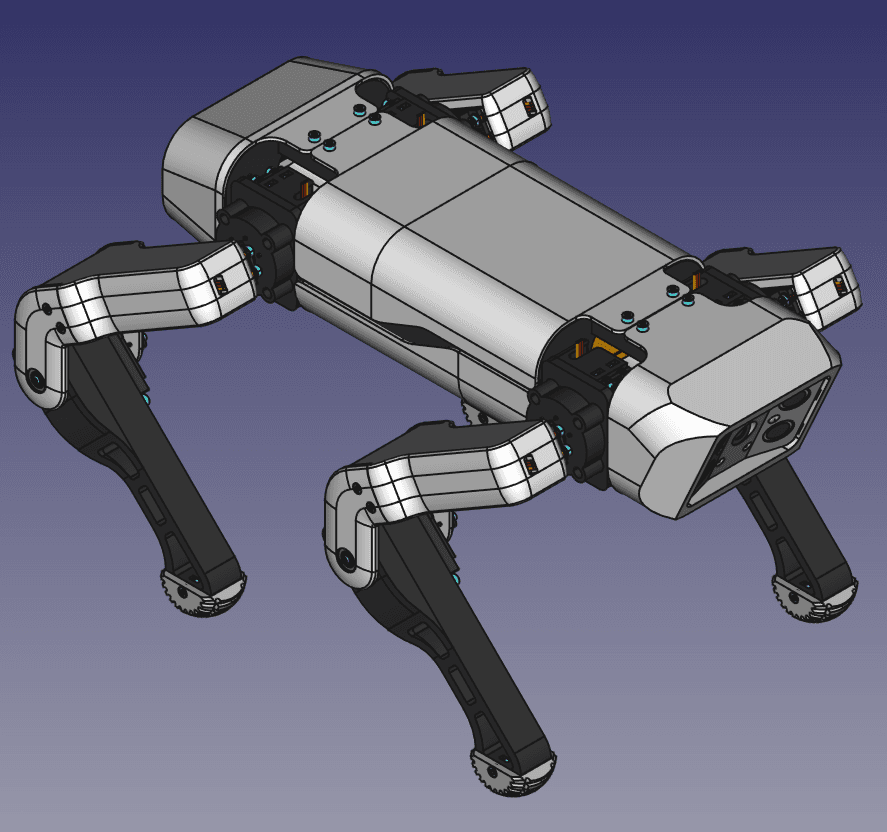
    SpotMicro ESP32

    A 3D-printable quadruped robot dog with support-free printed parts, controlled by an ESP32-DevKitC with heavy computation offloaded to external devices.

    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    Not stated
  • No photo yet
    Quadruped

    Yertle

    A 3D printed quadrupedal robot with 4 limbs of 3 degrees of freedom each, built for locomotion research and reinforcement-learned walking.

    • Works with AI
    Level
    Advanced
    Buildability
    55/100
    Buildable with some effort
    Cost
    £250≈ €295 (ECB rate, 15 Oct 2026)
  • Drone

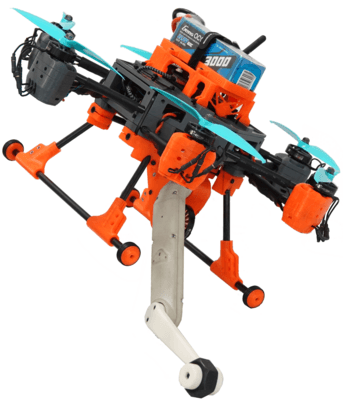
    Borinot

    An open-source, torque-controlled aerial loco-manipulator whose extremity can be reconfigured as a tail for flight, a hand for manipulation, or a leg for hybrid aerial-contact locomotion.

    Level
    Advanced
    Buildability
    51/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    AcroMonk

    A minimalist underactuated brachiating robot that swings along a horizontal ladder bar using one quasi-direct drive actuator and passive grippers.

    • Works with AI
    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Other

    Antagonistic Tendon Driven Continuum Robot

    A research continuum robot with 4 degrees of freedom that drives two tendons per antagonistic pair with a single servo and measures tendon force with load cells.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

    OpenRover

    A 3D-printed Mars Perseverance-style rover replica with a 6-wheel drive, 4-axis robotic arm, and remote control with touchscreen and web dashboard.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Photo on GitHub
    Drone

    REAL Drone 400

    An open-source autonomous quadrotor drone built by the NEU REAL Lab, with a high-load, stable-localization design for autonomous obstacle avoidance flight.

    • No license
    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Wheeled

    Venus-1 Four-link Wheel-legged Robot

    A four-link wheel-legged robot designed for adaptive center of gravity, obstacle crossing, and jumping, controlled via STM32H723 with FreeRTOS.

    Level
    Advanced
    Buildability
    50/100
    Buildable with some effort
    Cost
    Not stated
  • Robot arm

    DIY Delta robot

    A DIY delta-type parallel robot controlled from a Python application with live kinematics visualization and Bluetooth connection.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Drone

    Fast-Drone-250

    An open-source 250mm autonomous quadrotor drone that flies in unknown environments and avoids obstacles using VINS visual-inertial odometry and EGO-Planner.

    • No license
    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    HeRoSwarm v2

    A fully-capable miniature swarm robot with multiple sensors, Wi-Fi and Bluetooth communication, Raspberry Pi Zero computing, and wheel odometry, designed for multi-robot research.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Hexapod v2 (Linkit 7697)

    A six-legged hexapod robot with 18 servo joints, controlled from a mobile phone over Bluetooth Low Energy by a Linkit 7697 board.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Other

    LZU Ascento

    A two-wheeled, four-bar-linkage wheel-leg balancing robot modeled on the ASCENTO, controlled with LQR on an STM32H723 board.

    • No license
    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • Photo on GitHub
    Drone

    OLDX-FC Open-source Multicopter Flight Controller

    An open-source flight controller platform for multicopters with dual-processor redundancy, supporting GPS, optical flow, UWB, and vision-based navigation.

    • No license
    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Quadruped

    openDog

    An open-source quadruped dog robot built episode by episode, with CAD files and Arduino code.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated
  • No photo yet
    Robot arm

    Sixi 2 Robot Arm

    An open source six degree of freedom industrial robot arm that can hold 2kg at 80cm.

    Level
    Advanced
    Buildability
    45/100
    Incomplete documentation
    Cost
    Not stated

Robots 25–48 of 95

More to explore