Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

28 robots of 270

Page 1 of 2 · Ready to build first, then by buildability

  • Hexapod-ROS

    An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
    QuadrupedAdvancedBuildability 75/100 · Buildable with some effort
    • Work in progress
    Cost not stated
  • Open Quadruped

    An open-source 3D-printed quadrupedal robot that performs gait generation with Bezier curves and full 6-axis body pose control.
    QuadrupedAdvancedBuildability 70/100 · Buildable with some effort
    Cost not stated
  • POPI

    POPI is an open-source quadruped robot designed as a student project, meant to be accessible for education and research and rebuildable by anyone.
    QuadrupedAdvancedBuildability 70/100 · Buildable with some effort
    Cost not stated
  • Spot Micro - Leika

    An open-source ESP32-based quadruped robot with a web-based controller and a MuJoCo simulator.
    QuadrupedAdvancedBuildability 70/100 · Buildable with some effort
    Cost not stated
  • Quadruped Bai Servo v1

    A low-cost 12-DOF quadruped robot actuated by hobby servos, with optional feet sensors and a trot gait firmware.
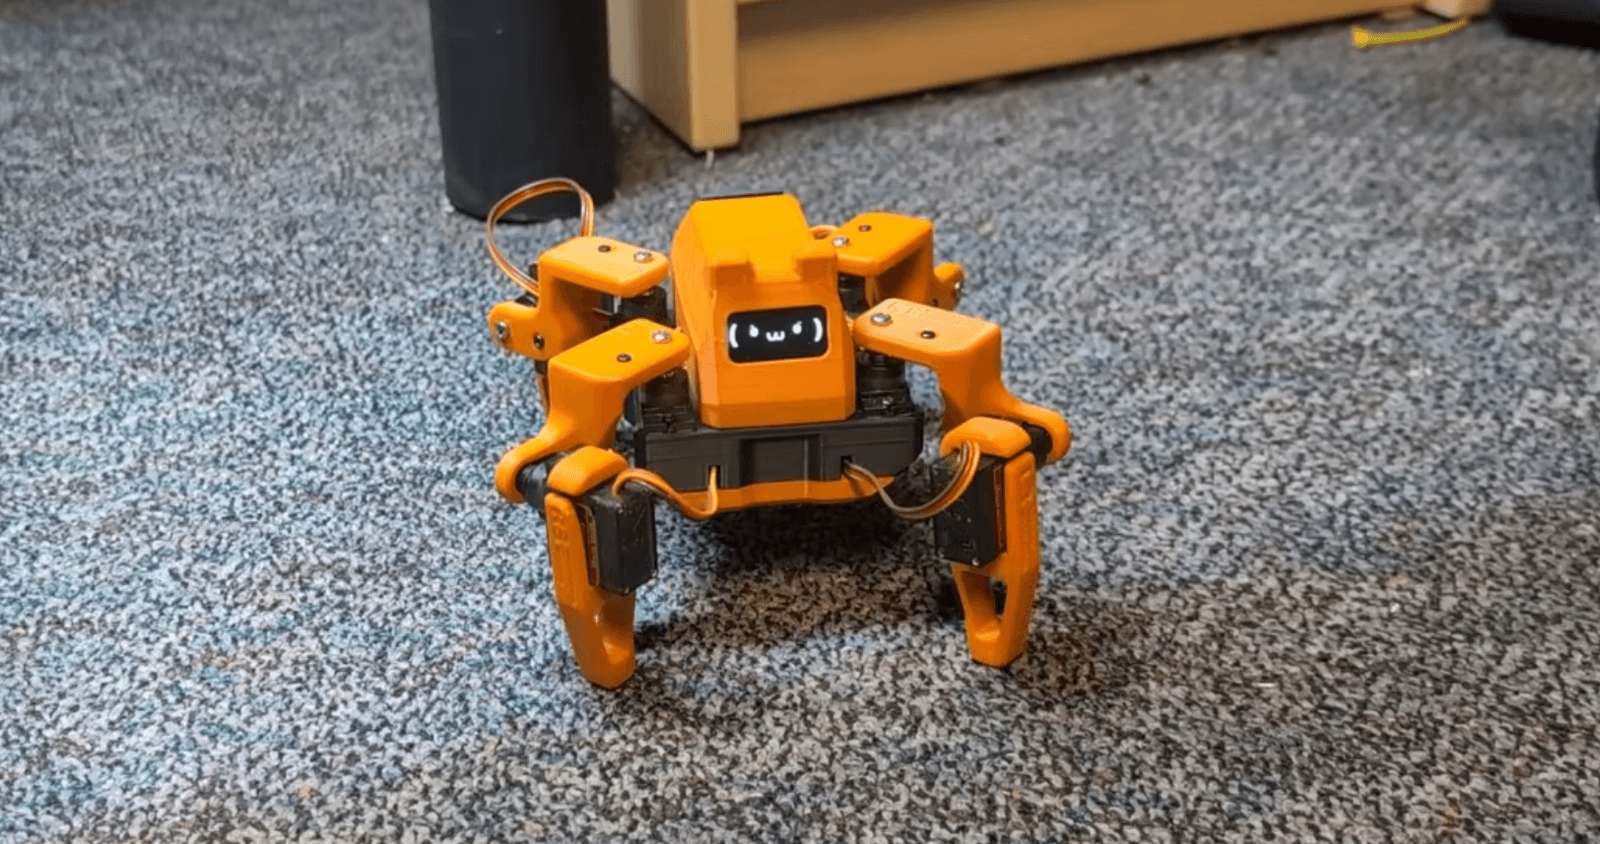
    QuadrupedIntermediateBuildability 65/100 · Buildable with some effort
    Cost not stated
  • Sesame Robot

    An open and affordable ESP32-based mini quadruped robot with an OLED face that walks, waves and dances.
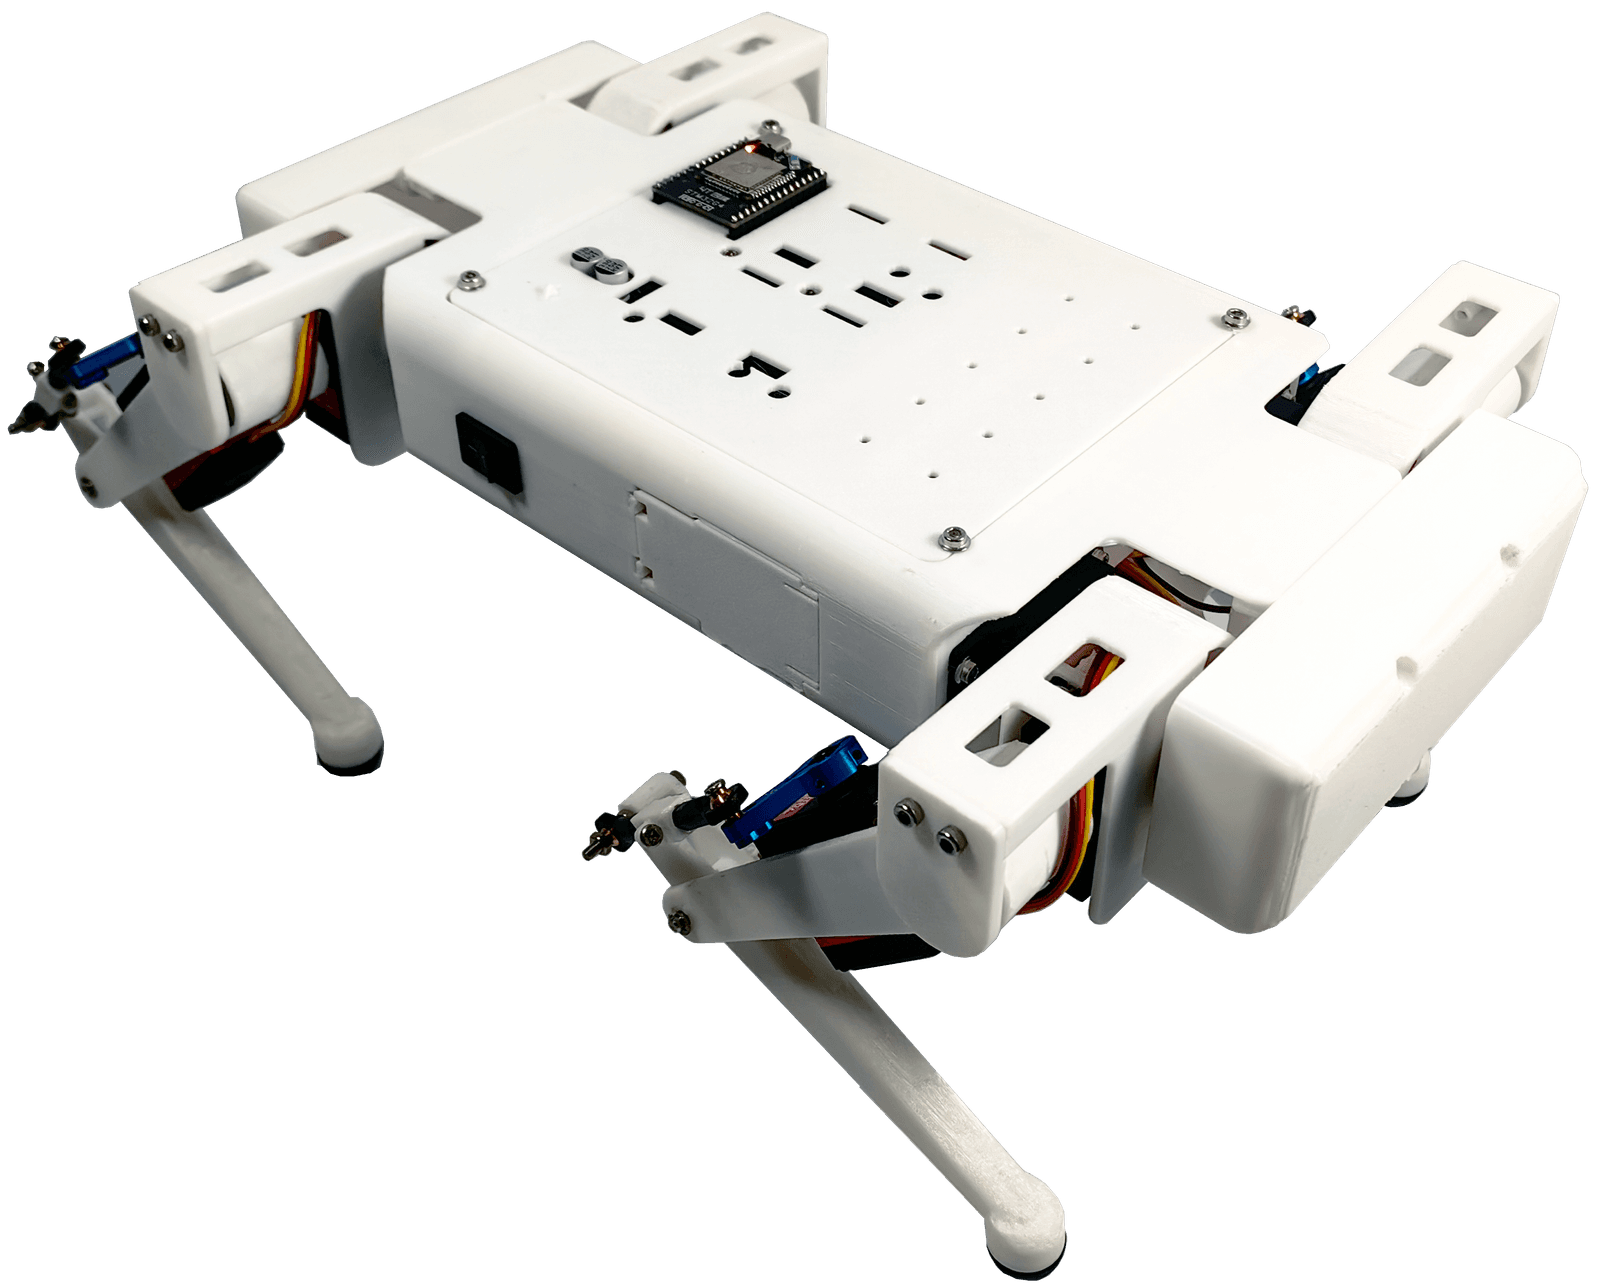
    QuadrupedBeginnerBuildability 65/100 · Buildable with some effort
    Cost not stated
  • 4T-POM-X4

    An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
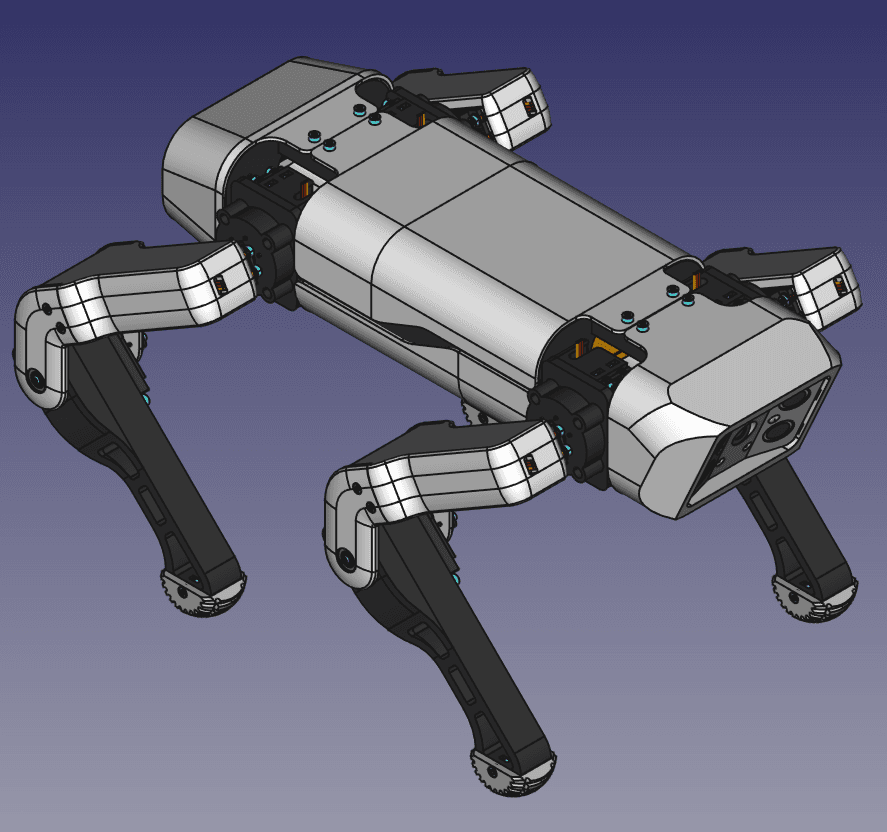
    QuadrupedIntermediateBuildability 55/100 · Buildable with some effort
    Cost not stated
  • SpotMicro ESP32

    A 3D-printable quadruped robot dog with support-free printed parts, controlled by an ESP32-DevKitC with heavy computation offloaded to external devices.

    QuadrupedAdvancedBuildability 55/100 · Buildable with some effort
    Cost not stated
  • Yertle

    A 3D printed quadrupedal robot with 4 limbs of 3 degrees of freedom each, built for locomotion research and reinforcement-learned walking.
    QuadrupedAdvancedBuildability 55/100 · Buildable with some effort
    • Works with AI
    £250≈ €296 (ECB rate, 14 Oct 2026)
  • MindPaw

    A desktop quadruped robot based on ESP8266 with voice control, gesture recognition, web remote, and AI conversation.

    QuadrupedIntermediateBuildability 50/100 · Buildable with some effort
    • Works with AI
    ¥50≈ €7 (ECB rate, 14 Oct 2026)
  • Hexapod Robot

    A six-legged robot powered by a Raspberry Pi Pico, featuring 18 digital servos, IMU auto-leveling, and multiple control inputs.
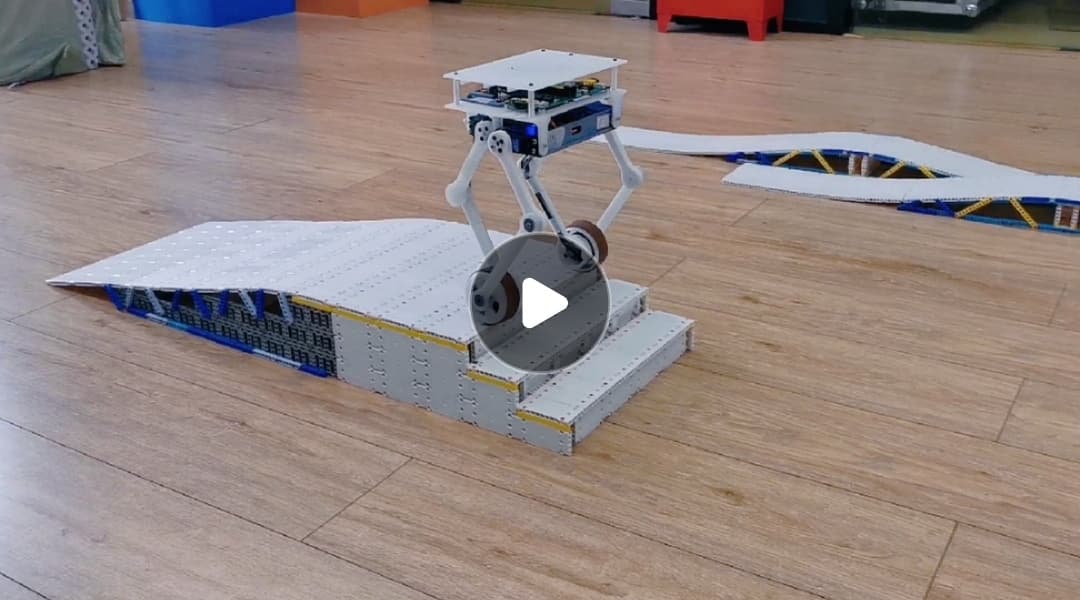
    QuadrupedIntermediateBuildability 49/100 · Incomplete documentation
    • Work in progress
    Cost not stated
  • Hyun

    A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.

    QuadrupedIntermediateBuildability 45/100 · Incomplete documentation
    Cost not stated
  • openDog

    An open-source quadruped dog robot built episode by episode, with CAD files and Arduino code.

    QuadrupedAdvancedBuildability 45/100 · Incomplete documentation
    Cost not stated
  • Spot Micro Quadruped Robot

    A beginner-friendly open-source quadruped robot with 3D-printable parts and ROS-based control software.
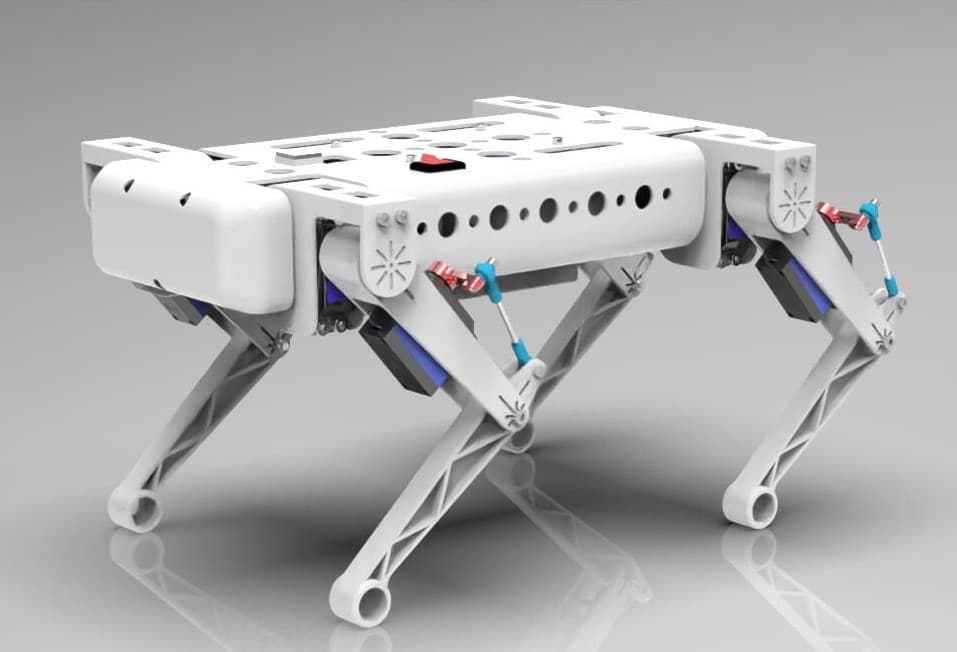
    QuadrupedBeginnerBuildability 45/100 · Incomplete documentation
    Cost not stated
  • 12-DOF Quadruped Robot

    A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.
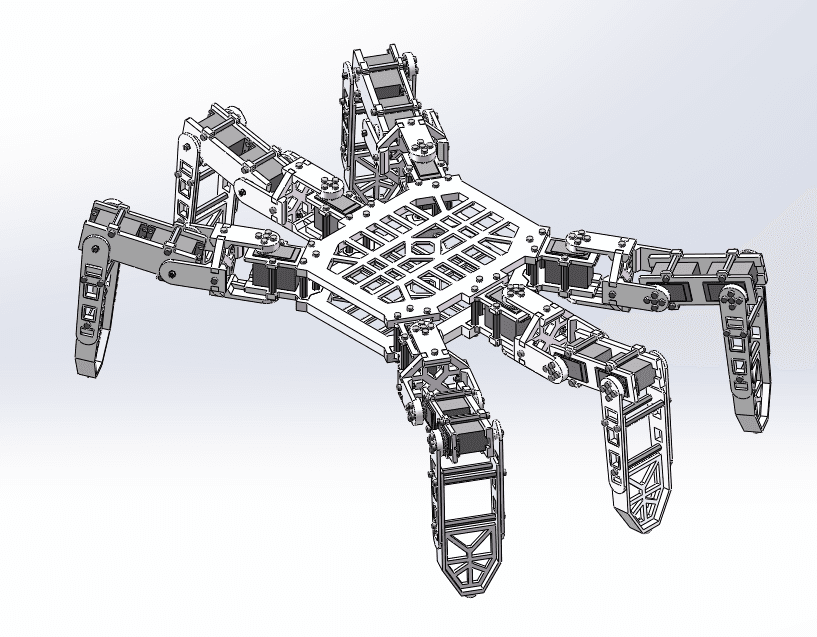
    QuadrupedIntermediateBuildability 40/100 · Incomplete documentation
    Cost not stated
  • Hexapod Robot

    A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
    QuadrupedIntermediateBuildability 40/100 · Incomplete documentation
    Cost not stated
  • Mini Pupper

    An open-source, ROS-based quadruped robot dog designed for education and research, supporting SLAM, navigation, and OpenCV AI features.

    QuadrupedIntermediateBuildability 40/100 · Incomplete documentation
    • Works with AI
    $500≈ €447 (ECB rate, 14 Oct 2026)
  • openDog V3

    A quadruped robot dog built from 3D-printed PLA parts, driven by ODrive-controlled motors with AS5047 absolute encoders and a remote-controlled walking mode.
    QuadrupedAdvancedBuildability 40/100 · Incomplete documentation
    Cost not stated
  • Quadruped Robot

    A four-legged robot designed for research and education in legged locomotion.

    QuadrupedIntermediateBuildability 40/100 · Incomplete documentation
    Cost not stated
  • Easy Quadruped Robot

    A simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.

    QuadrupedIntermediateBuildability 35/100 · Incomplete documentation
    Cost not stated
  • Py-Apple BLDC Quadruped Robot

    An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
    QuadrupedIntermediateBuildability 35/100 · Incomplete documentation
    • Work in progress
    Cost not stated
  • Py-Apple Dog

    An open-source quadruped robot designed for easy DIY with low-cost hardware and software.

    QuadrupedIntermediateBuildability 35/100 · Incomplete documentation
    Cost not stated
  • Py-Apple Structure Quadruped

    An open-source quadruped robot mechanical structure designed to support the Py-Apple Controller and Py-Apple Dynamics software.

    QuadrupedIntermediateBuildability 35/100 · Incomplete documentation
    Cost not stated
  • STM32 Quadruped Robot

    A quadruped robot controlled by an STM32F103C8T6 microcontroller, capable of walking forward, backward, and lifting its legs.

    QuadrupedIntermediateBuildability 35/100 · Incomplete documentation
    Cost not stated

Robots 1–24 of 28

More to explore