Skip to content

Photo

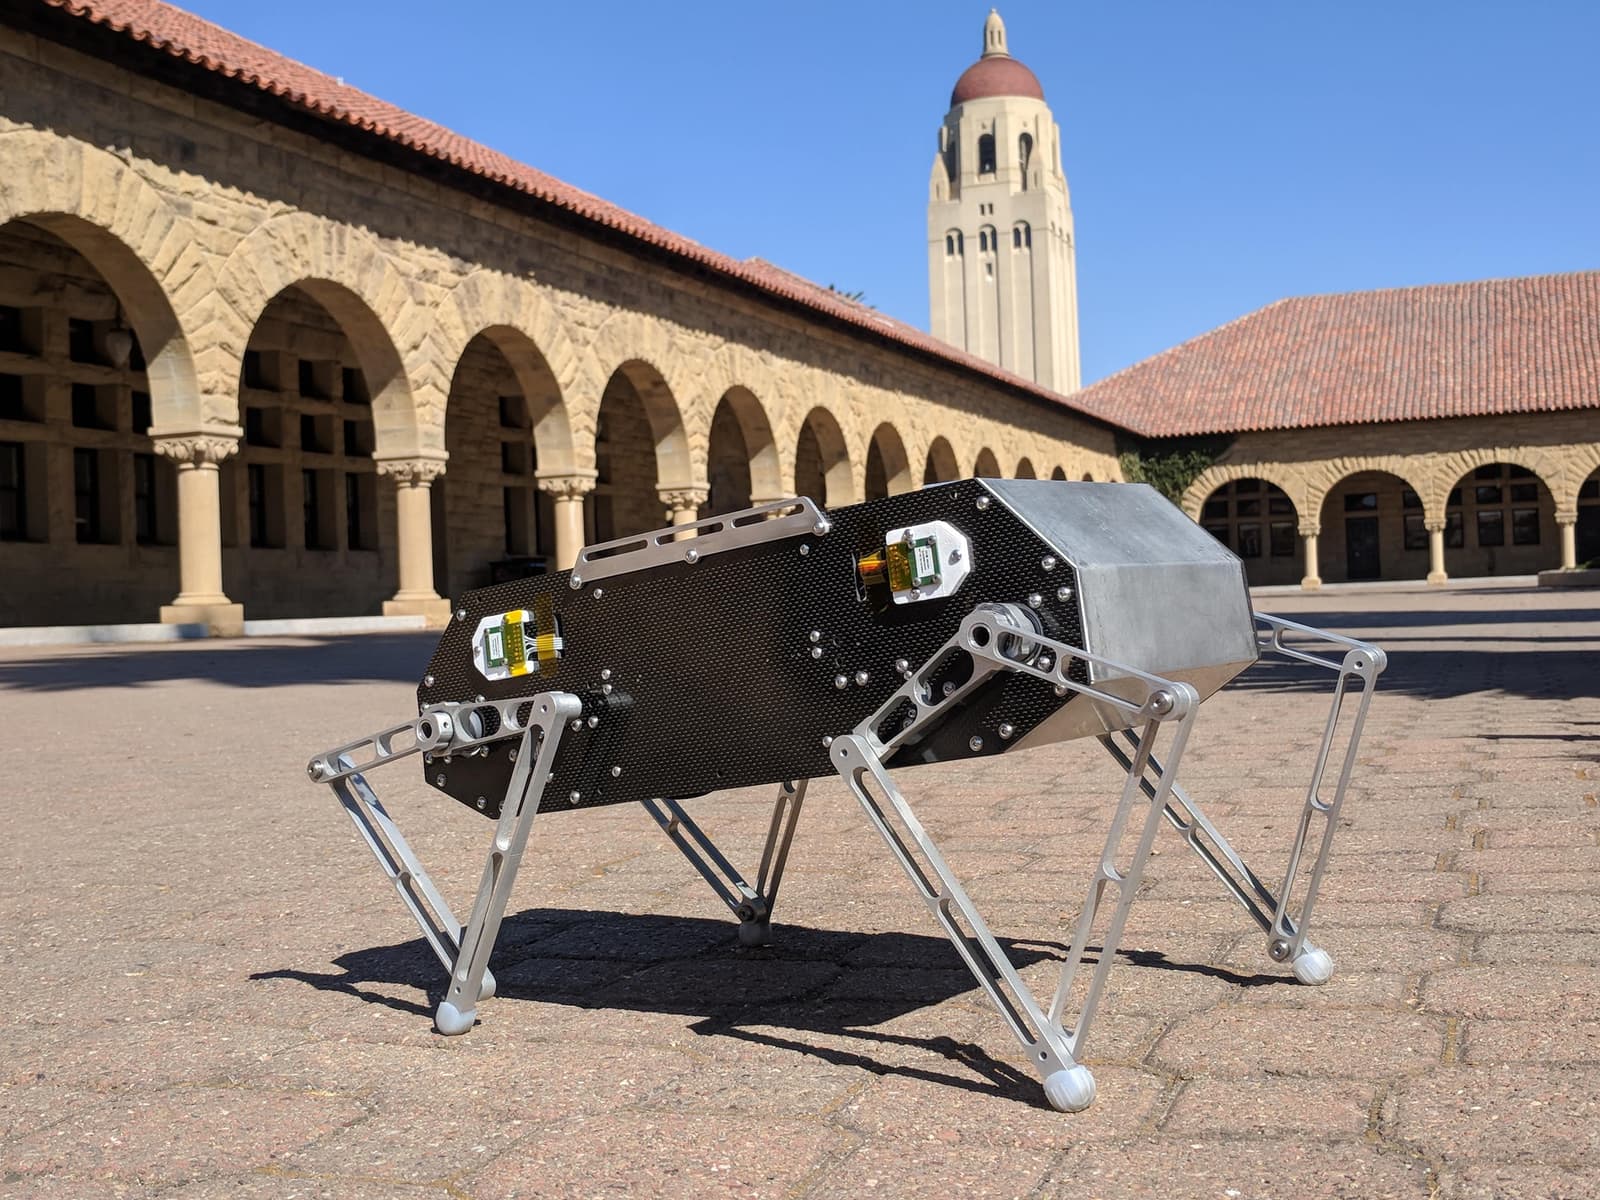
Stanford Doggo, photo from its repository
Photo@Nate711 (opens in a new tab)MITsource file (opens in a new tab)
Open source · free files

Stanford Doggo

Quadruped

Stanford Doggo is an open-source quadruped robot that jumps, flips, and trots, built as an accessible platform for legged robot research.

Project information

Buildability
38/100Incomplete documentation
Estimated cost
Not stated
Level
Advanced
Parts
Not listed
Tools
3D printer, waterjet cutting service, drill and tap set, soldering iron
Licenses
MIT (opens in a new tab), hardware and software
Commercial use
Allowed
Works with
arduino
Degrees of freedom
2
Power
48 V
Weight
5 kg

Suggested by Robotheca, created by @Nate711 (opens in a new tab), from github.com/Nate711/StanfordDoggoProject (opens in a new tab), pinned to commit ce5716b (opens in a new tab). You buy the parts yourself; Robotheca doesn't sell robots.

What to buy

This repository has no parts list Robotheca can read yet.

Why it scores 38

It measures the published files, not the robot · How we score

38/100

Incomplete documentation

How complete the published files are for rebuilding this robot, measured by Robotheca at commit ce5716b. It isn't a rating of the robot. Counted out of 80 points and scaled to 100: the parts that don't apply to this robot are left out.

  1. 13D and CAD filesNo printable parts or CAD files.Most points to gain: Add the parts to print (STL or 3MF files). Add the CAD source (STEP, or the CAD program's own files) so people can change the design.0/20
  2. –Robot descriptionNo URDF. Not counted: the score is made of the parts that apply.Optional: add a URDF, and the robot can be seen in 3D and tried in the browser.Not counted
  3. 2Parts listNo parts list in the repository or linked.Link to your parts list, or add it to the repository (a CSV or a Markdown table) with quantities, prices and where to buy each part.0/20
  4. 3SoftwareInstructions to install or run it, built on arduino.Link to your code, or add it to this repository.10/15
  5. 4DocumentationREADME of 14,500 characters with 11 pictures; 0 build steps.Split the build into at least 3 steps.10/15
  6. –SimulationNo simulation files. Not counted: the score is made of the parts that apply.Optional: add a simulation model (MuJoCo, Gazebo, Webots or Isaac).Not counted
  7. 5LicensesHardware: MIT; software: MIT.10/10

Build it

The guide appears here as you scroll.

Guide by @Nate711 (README.md), under MIT.

Wiring and electronics

Notes written by Robotheca from the project's documents

Main parts

  • Four v3.5 48V ODrive motor controllers, two per leg, mounted on the carbon fiber side panels.
  • Teensy 3.5 central microcontroller.
  • 5mW Xbee radio for wireless serial commands.
  • Two 1000mAh 6S Tattu LiPo batteries.
  • Power distribution board and a Gigavac P105 Mini-Tactor relay for offboard ESTOP power cutoff.
  • AS5047P incremental encoders on each motor for angle tracking.
  • TMotor MN5212 motors drive each leg coaxially through GT2 belts.

Connections

  • Teensy communicates with each ODrive over a separate UART serial line at 500,000 baud, using Teensy RX to ODrive TX and Teensy TX to ODrive RX.
  • Teensy serial ports Serial1 through Serial4 connect to ODrives 0 through 3.
  • Xbee connects to the Teensy over serial on Serial5.
  • The offboard ESTOP switch drives a solid-state relay whose output sits in series with the main power.
  • Encoders use the incremental interface; the absolute and index pin functions were not used.

Schematics, boards and diagrams

What it can do

Written by Robotheca from the project's documents
  • Walks, trots, bounds and pronks by commanding sinusoidal open-loop leg trajectories to the four ODrives.
  • Holds the record for vertical jumping agility and can jump higher than other quadrupeds, per the documents.
  • Runs a state machine that switches between behaviors such as trot and jump.
  • Controlled by serial commands sent over a wireless Xbee network once in idle mode.
  • Turns very slowly using the 'Y' command, with the turning speed set by a step difference parameter.
  • Legs calibrate on power-up, rotating the motors about 120 degrees to one side and back.

Software

Framework
arduino
License
MIT

Robotheca doesn't review code. Read it before running it.

How to run it

Written by Robotheca from the project's documents.

  1. 1Clone the repository with submodules initialized and updated recursively to populate the sub-folders.
  2. 2Flash the custom ODrive firmware onto the four motor controllers.
  3. 3Configure the ODrives using the doggo_setup.py script, updating the gear_ratio parameter if the mechanical design differs.
  4. 4Upload the Doggo Arduino code to the central Teensy microcontroller.
  5. 5Power on the robot so the legs run their calibration routine, then the robot enters idle mode.
  6. 6Send serial commands over the Xbee network to command behaviors such as trot or jump.

Software that runs on this robot

No software from Robotheca's catalogue found in this robot's files yet. Links come from its robot.yaml, its dependency files read as text, or Robotheca's editors.

Free files

Every file of the project, at commit ce5716b.

Community

Questions and improvements go to the creator's repository.

Add a badge to your README

For the creator: two badges that link back here. The second always shows this page's current label and score.

Listed on RobothecaRobotheca buildability

Markdown (one click selects it)

[![Listed on Robotheca](https://robotheca.org/robots/stanford-doggo/badge.svg)](https://robotheca.org/robots/stanford-doggo)
[![Robotheca buildability](https://robotheca.org/robots/stanford-doggo/score.svg)](https://robotheca.org/robots/stanford-doggo)

Other quadrupeds

All 59 quadrupeds
  • Ready to build

    Open source · free files

    Physical Ant

    Quadruped · Intermediate

    Score
    Buildability 94 out of 100
    Cost
    $2,230.61≈ €1,995
  • Ready to build

    Open source · free files

    Sesame Robot

    Quadruped · Beginner

    Score
    Buildability 88 out of 100
    Cost
    $50–$60≈ up to €54
  • Open source · free files

    Zuko

    Quadruped · Advanced

    Score
    Buildability 84 out of 100
    Cost
    Not stated
  • Open source · free files

    Quadruped Bai Servo v1

    Quadruped · Intermediate

    Score
    Buildability 81 out of 100
    Cost
    Not stated

≈ € values are approximate, converted at the ECB euro reference rate of 3 Nov 2026. The creator's original price always comes first.