Puguette
A fully open-source 12 DOF quadruped robot that uses BLDC motors with planetary gearboxes for high-torque legged locomotion.
- Quadruped
- Open source
- Works with AI
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @haruto89610 (opens in a new tab), from github.com/haruto89610/puguette (opens in a new tab). Pinned to commit 2694b12 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
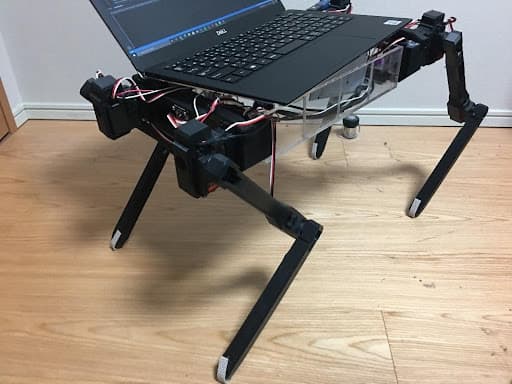
3D preview converted from github.com/haruto89610/puguette at 2694b12, under MIT. View the original files from GitHub (821 KB) (opens in a new tab)
- Degrees of freedom
- 12
- Height
- 40 cm
What it can do
Written by Robotheca from the project's documents.
- Puguette is a 12 DOF quadruped robot, 80cm x 40cm x 60cm when legs are straight.
- Uses BLDC motors with planetary gearboxes for high torque, approximately 55Nm total torque per actuator.
- Gear ratio can be changed by printing ring, planet and sun gears with different tooth counts.
- Current software versions use only Python on the Jetson Nano, which controls the ODrives directly over USB.
- A PyBullet simulation with a simplified model was made to help test the robot.
Works with AI
Found by Robotheca in the project's files at commit 2694b12, its robot.yaml and Robotheca's notes on its documents. Never guessed; Robotheca doesn't run the code.
Ships a trained model: frozen_inference_graph_coco.pb
In the project files: src/old/JetsonNano/python/frozen_inference_graph_coco.pb
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Mount encoder onto encoder holder using M2 screws
- 2Mount the encoder magnet on the motor via the magnet holder
- 3Insert M4 hex nuts into the sides of motor holder
- 4Screw encoder holder onto the motor holder via the holes
- 5Place bearings onto the ring gear and planet gear
- 6Push the planet gear onto the planet gear holder
- 7Mount the sun gear onto the motor via the opening on the motor holder
- 8Push the sun gear into the center of the planet gear and planet gear holder
- 9Push the ring gear on top of the planet gear holder
- 10Mount motor holder onto ring gear
The guide appears here as you scroll.
Guide by @haruto89610 (README.md), under MIT.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Jetson Nano as the central computer.
- Teensy 3.6 microcontroller, used in the older architecture to control the ODrives via UART.
- 6 ODrive motor drivers.
- 4 X8318s motors for upper leg actuators and 8 8308 motors for lower and hip abductor actuators.
- 12 AS5048a encoders measuring angle.
- 3 LiPo batteries as the power supply.
Connections
- The Jetson Nano communicates with the Teensy 3.6 via USB in the older architecture.
- The Teensy communicated with all 6 ODrives using UART in the older architecture.
- In the newer design the Teensy was removed and the Jetson Nano talks to the ODrives directly over USB.