NovaQ Quadruped Robot
A four-legged robot with eight MG996R servos, controlled from a web app, with camera feedback, OpenCV ball tracking and hand-gesture control.
- Quadruped
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @xJosephMorganx (opens in a new tab), from github.com/xJosephMorganx/NovaQ-Quadruped-Robot (opens in a new tab). Pinned to commit 2ef8b03 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
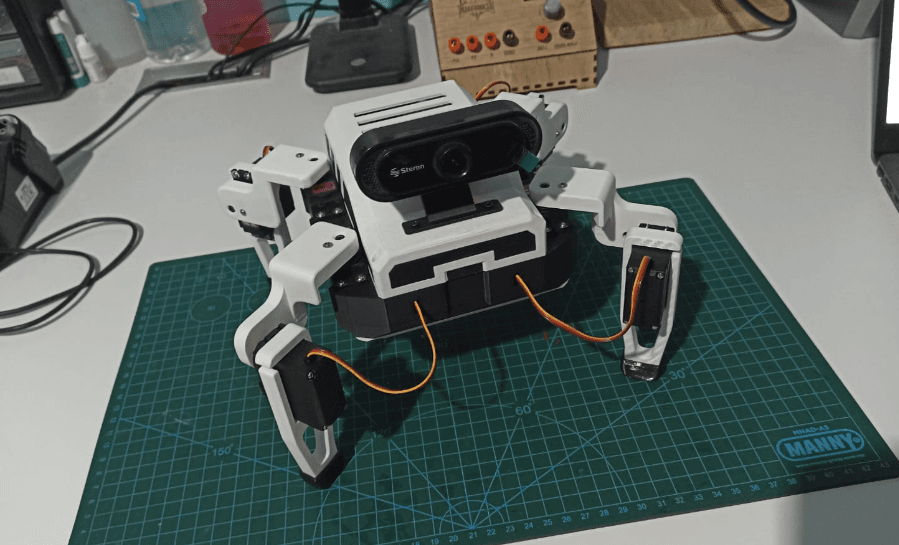
3D preview converted from github.com/xJosephMorganx/NovaQ-Quadruped-Robot at 2ef8b03, under GPL-3.0-only. View the original files from GitHub (4.0 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Walks, turns, returns to a calibrated initial pose, stands, and performs a greeting motion.
- Manual control from a browser web app over Wi-Fi, including keyboard and touch input.
- Streams live USB camera video to the operator.
- OpenCV mode tracks a blue ball using color masking and shape filtering.
- Edge Impulse mode recognizes hand gestures and maps them to movement commands.
- Four legs with two degrees of freedom each, eight servos in total.
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @xJosephMorganx (README.md), under GPL-3.0-only.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino UNO Q as the main controller with a Linux side and a microcontroller side.
- PCA9685 16-channel 12-bit PWM controller module.
- Eight MG996R high-torque servomotors.
- 12 V Li-ion battery feeding the servos through an adjustable buck converter.
- 5 V power bank supplying the logic and peripheral stage.
- Steren COM-122 USB webcam, connected through an Anker USB-C hub.
Connections
- The UNO Q talks to the PCA9685 over I2C.
- The PCA9685 drives the eight servos on channels 0-7.
- Servos are powered from the 12 V battery through the buck converter, not from the UNO Q.
- Logic and actuator power paths are separate, with a common ground shared by the UNO Q, PCA9685 and servo supply.
- The camera connects over USB through the USB hub.