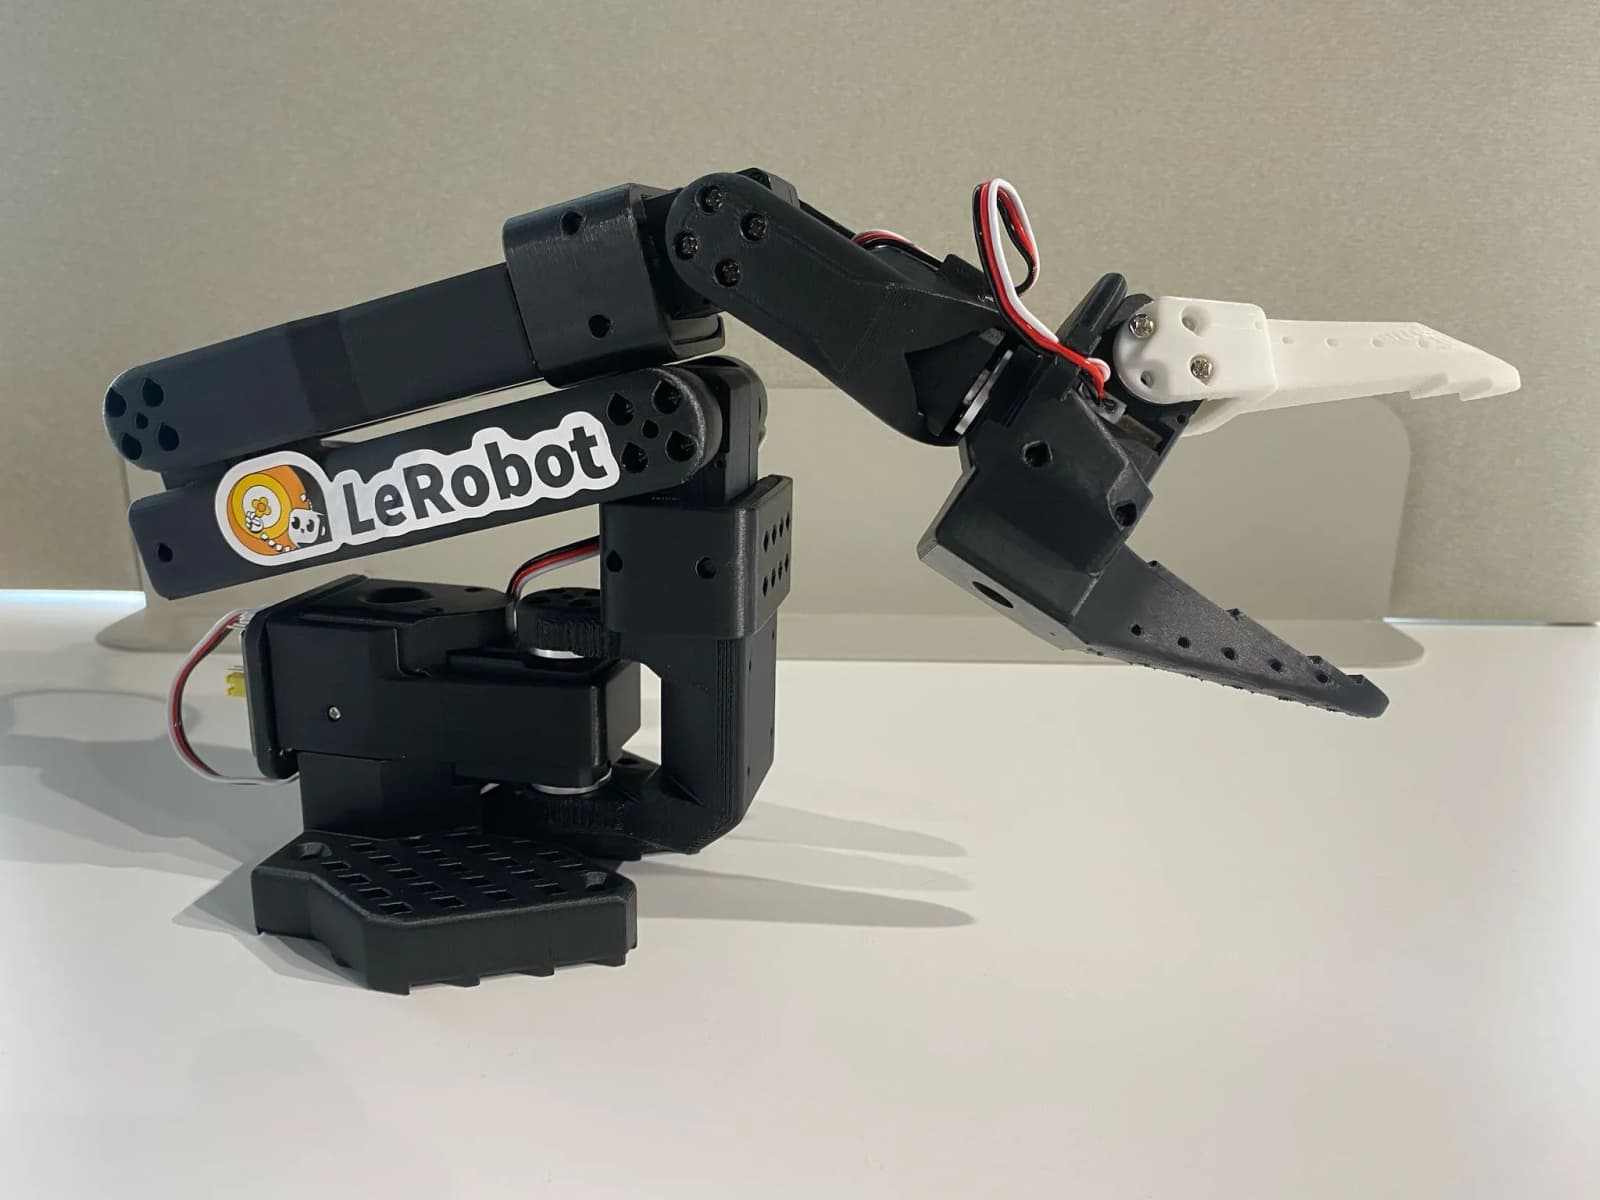
SO-101
A low-cost 3D-printed robot arm built as a leader and follower pair, for teleoperation and for teaching tasks by demonstration with LeRobot.
Robot armBeginnerBuildability 98/100 · Ready to build
- Works with AI
€226.30
Robots whose licenses allow commercial use. 182 robots on Robotheca, each with its licenses and its source on GitHub.
Page 1 of 8 · Ready to build first, then by buildability
A low-cost 3D-printed robot arm built as a leader and follower pair, for teleoperation and for teaching tasks by demonstration with LeRobot.
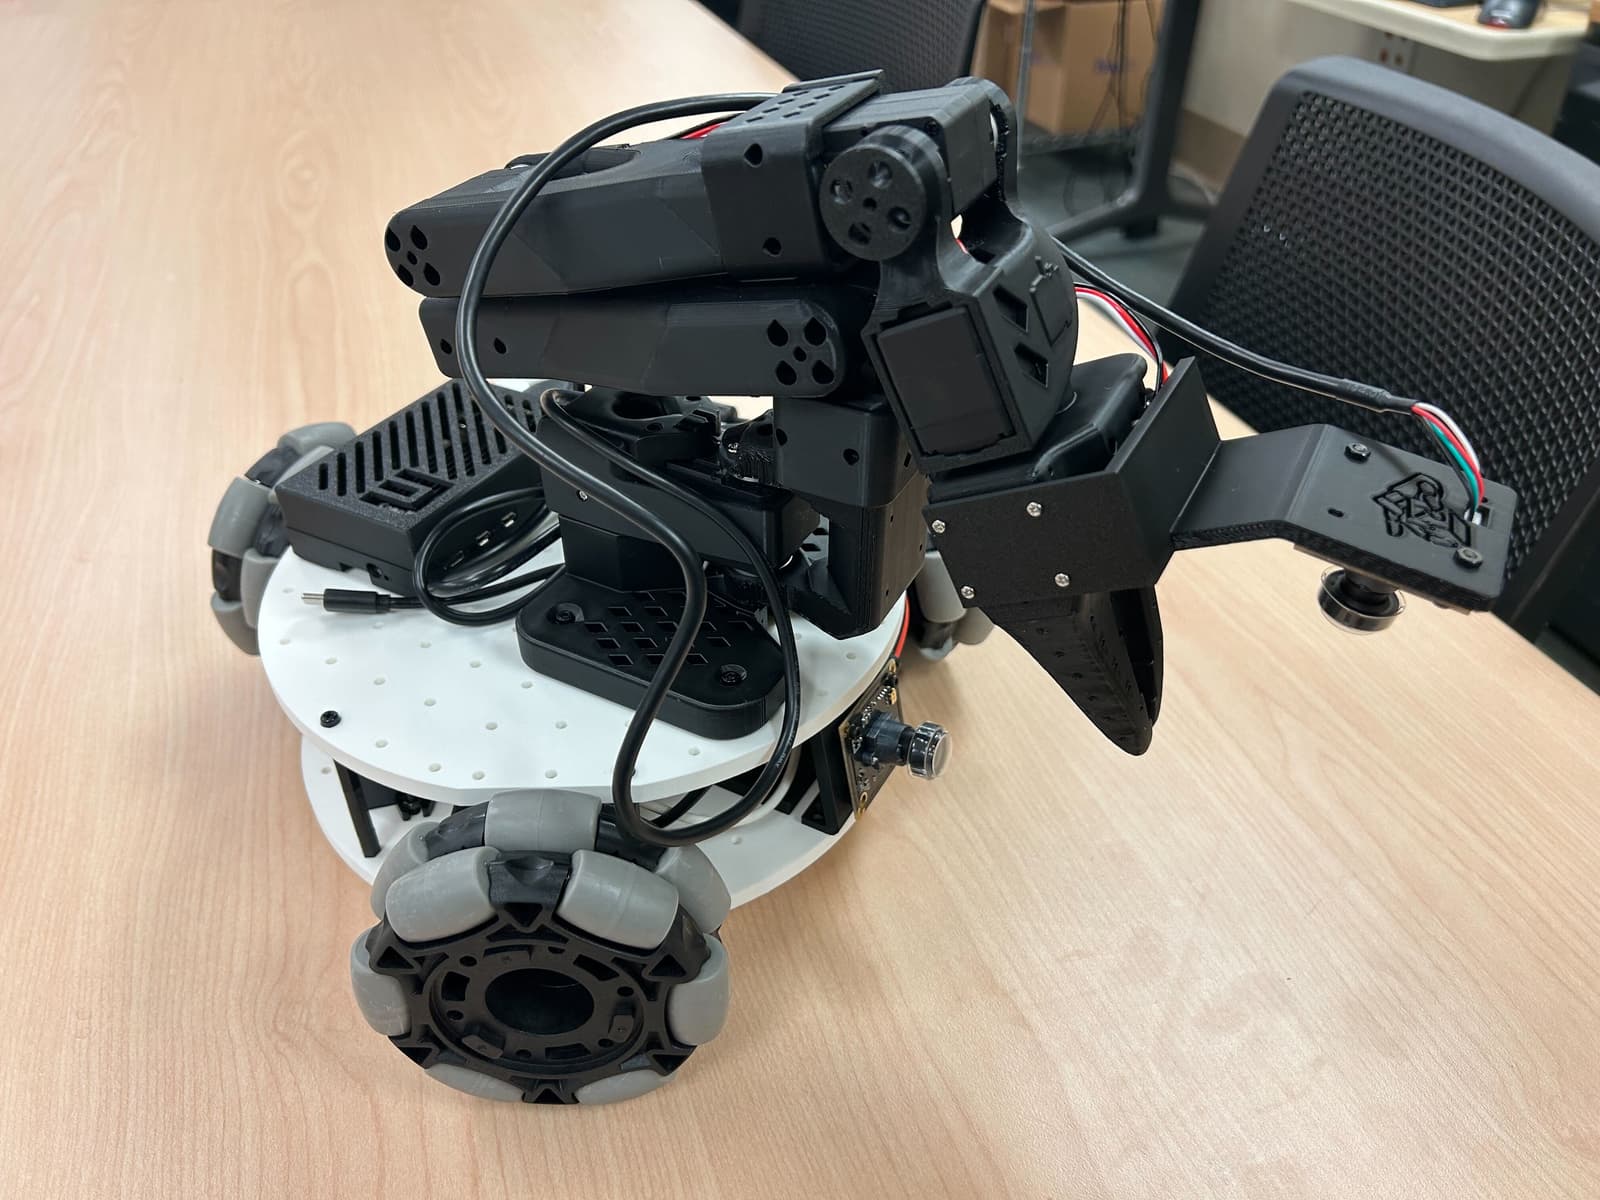
A low-cost mobile manipulator, a 3D-printed omnidirectional base carrying an SO-101 arm, a Raspberry Pi 5 and cameras, for LeRobot teleoperation.
AlohaMini2 is an open-source dual-arm mobile robot with a motorized vertical lift, built for embodied AI research and real-world manipulation.
A 3D-printed bipedal robot about 42 cm tall, inspired by Disney's BDX droids, that walks with reinforcement-learning policies trained in MuJoCo.
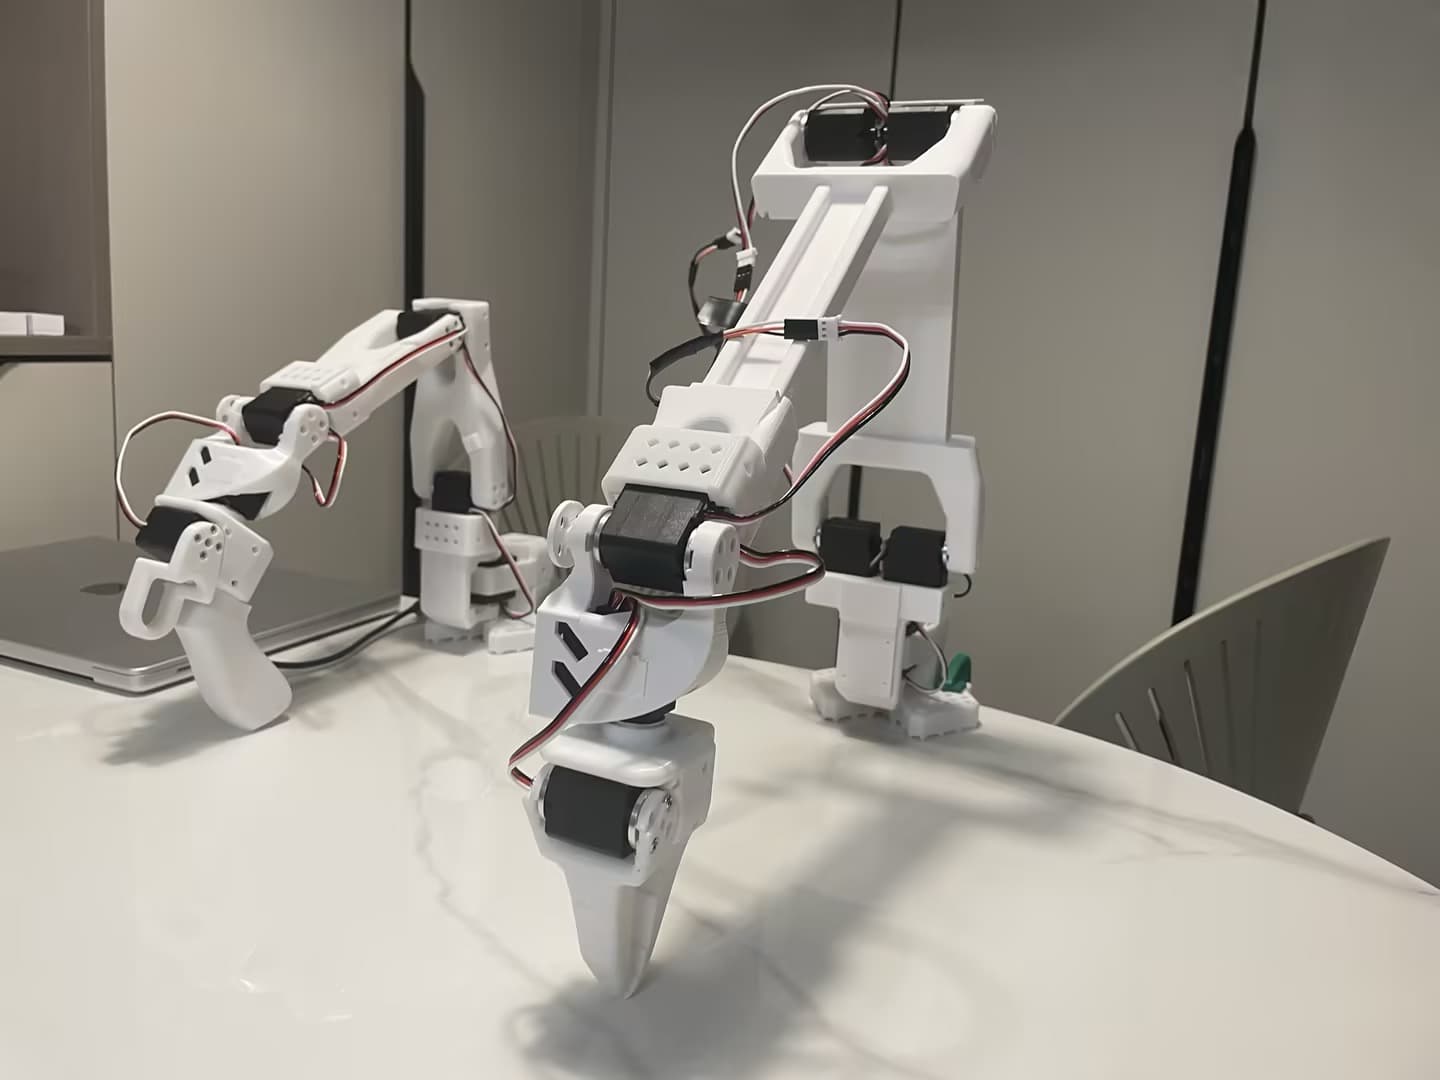
A low-cost, human-arm-scale open-source robotic arm compatible with Lerobot, based on the SO-100 arm, with a 600mm span and up to 500g payload.
A cost-effective, ROS2-compatible 5-DoF robotic manipulator with a leader-follower teleoperation setup, designed to lower the barrier to entry for Embodied AI.
An open-source leader and follower robot arm kit with 5 degrees of freedom plus a gripper, for teleoperation and imitation learning.

A fully open-source DIY humanoid robot designed for walking, running, and customizable motion control.
A toolkit for cable-driven robots that move objects through the air, built from 3D-printed cable drums on industrial servo motors, made for art installations.
A 3D-printed collaborative robot arm for research, education and rapid prototyping in physical AI.
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.

An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
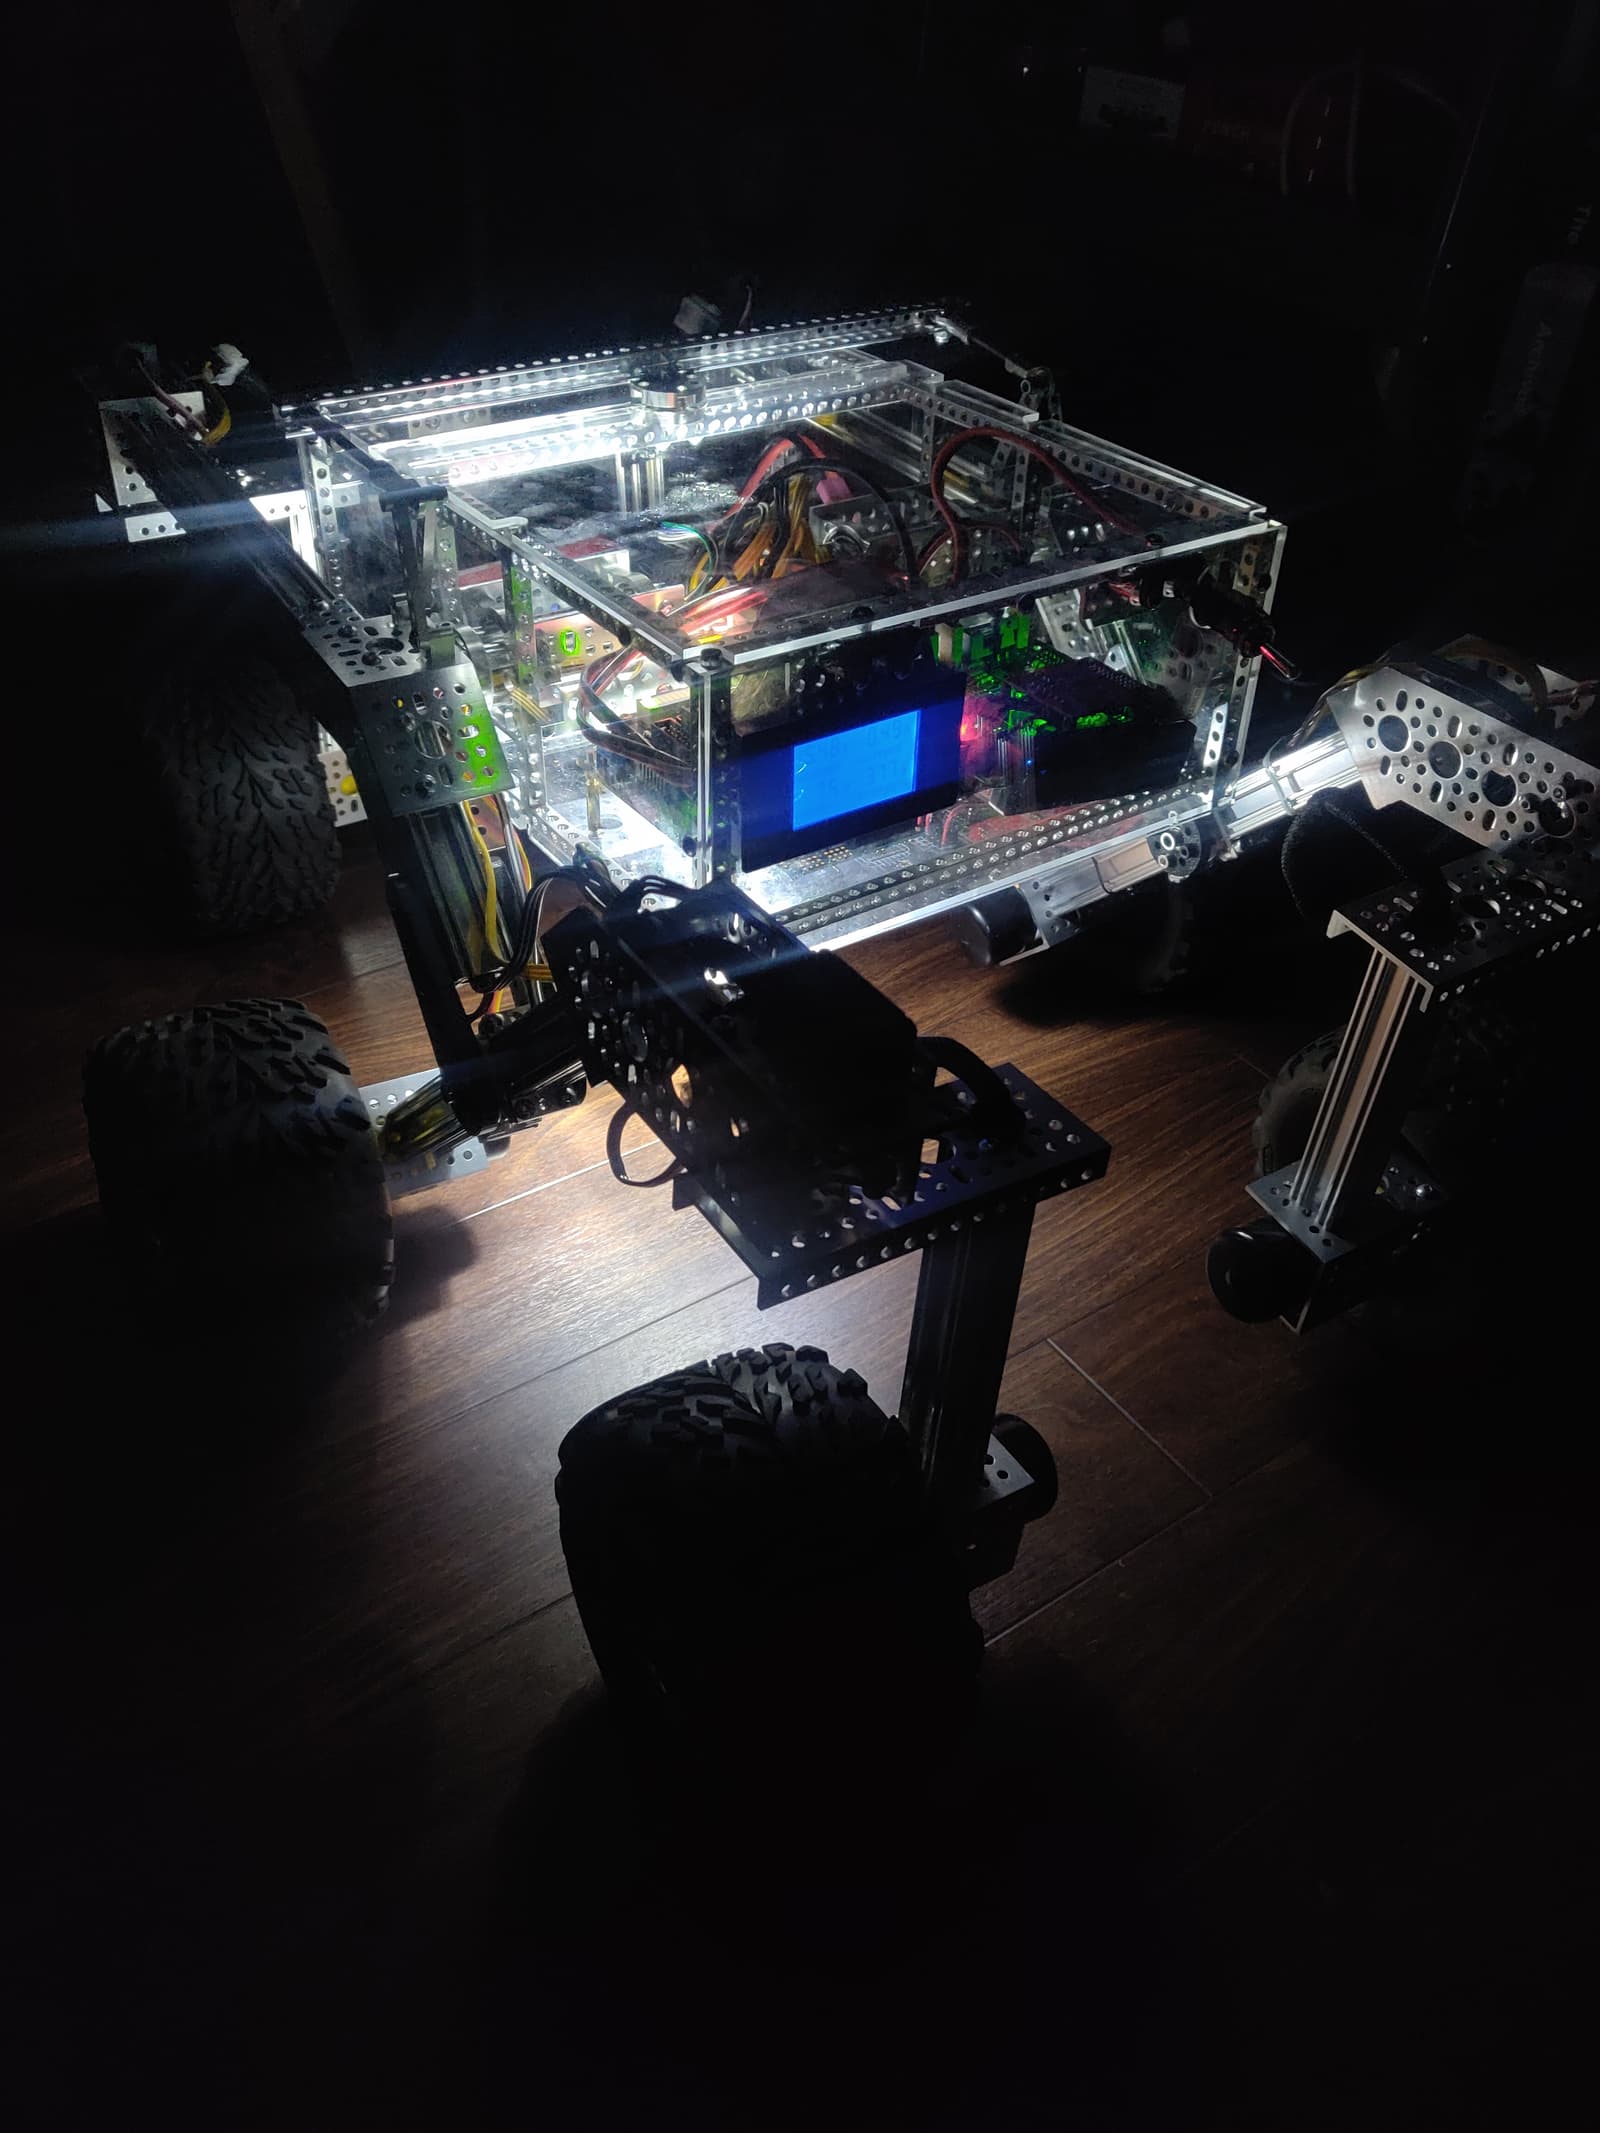
A build-it-yourself, six-wheeled rover scaled down from the JPL Mars rover design, made from consumer off-the-shelf parts.
An open-source robotic arm controlled by an ESP32-C3 via a PCA9685 servo driver and an Xbox-compatible gamepad.
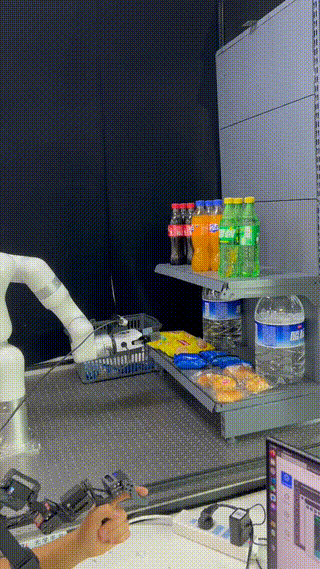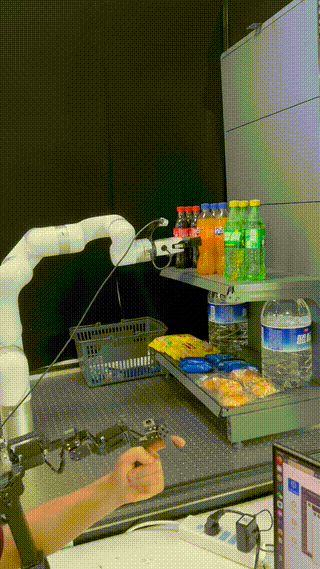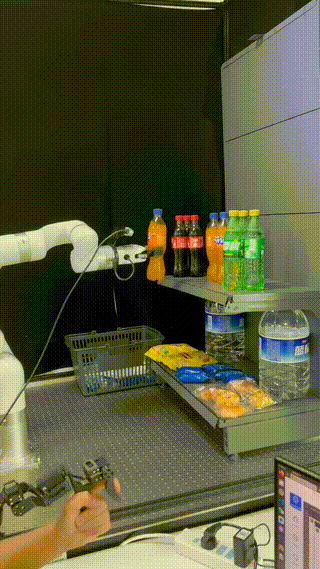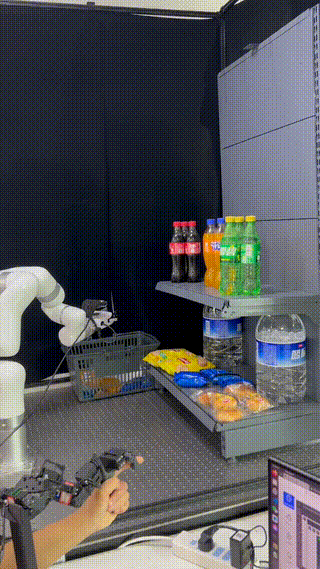
A low-cost, universal leader-follower teleoperation system for commercial robot arms with plug-and-play hardware configurations.
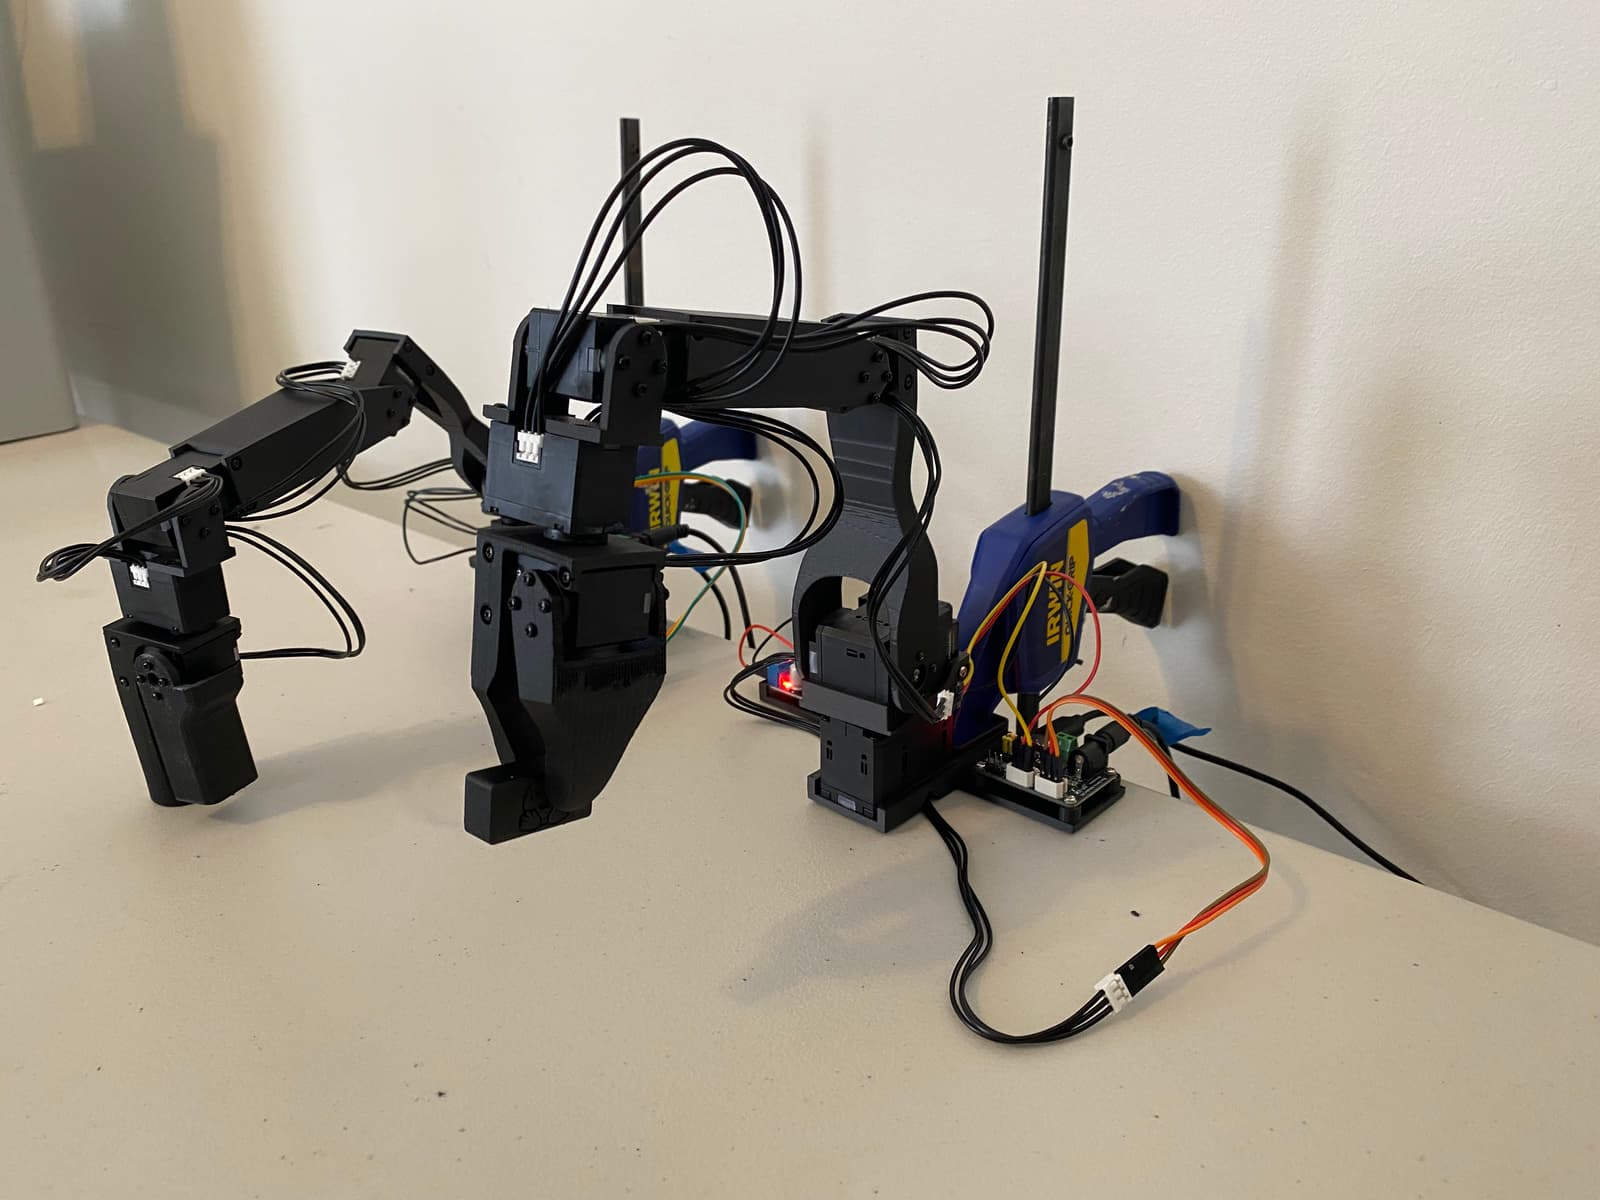
An improved version of Alexander Koch's low-cost robot arm, a leader and follower pair with Dynamixel servos for LeRobot. The price includes both arms.
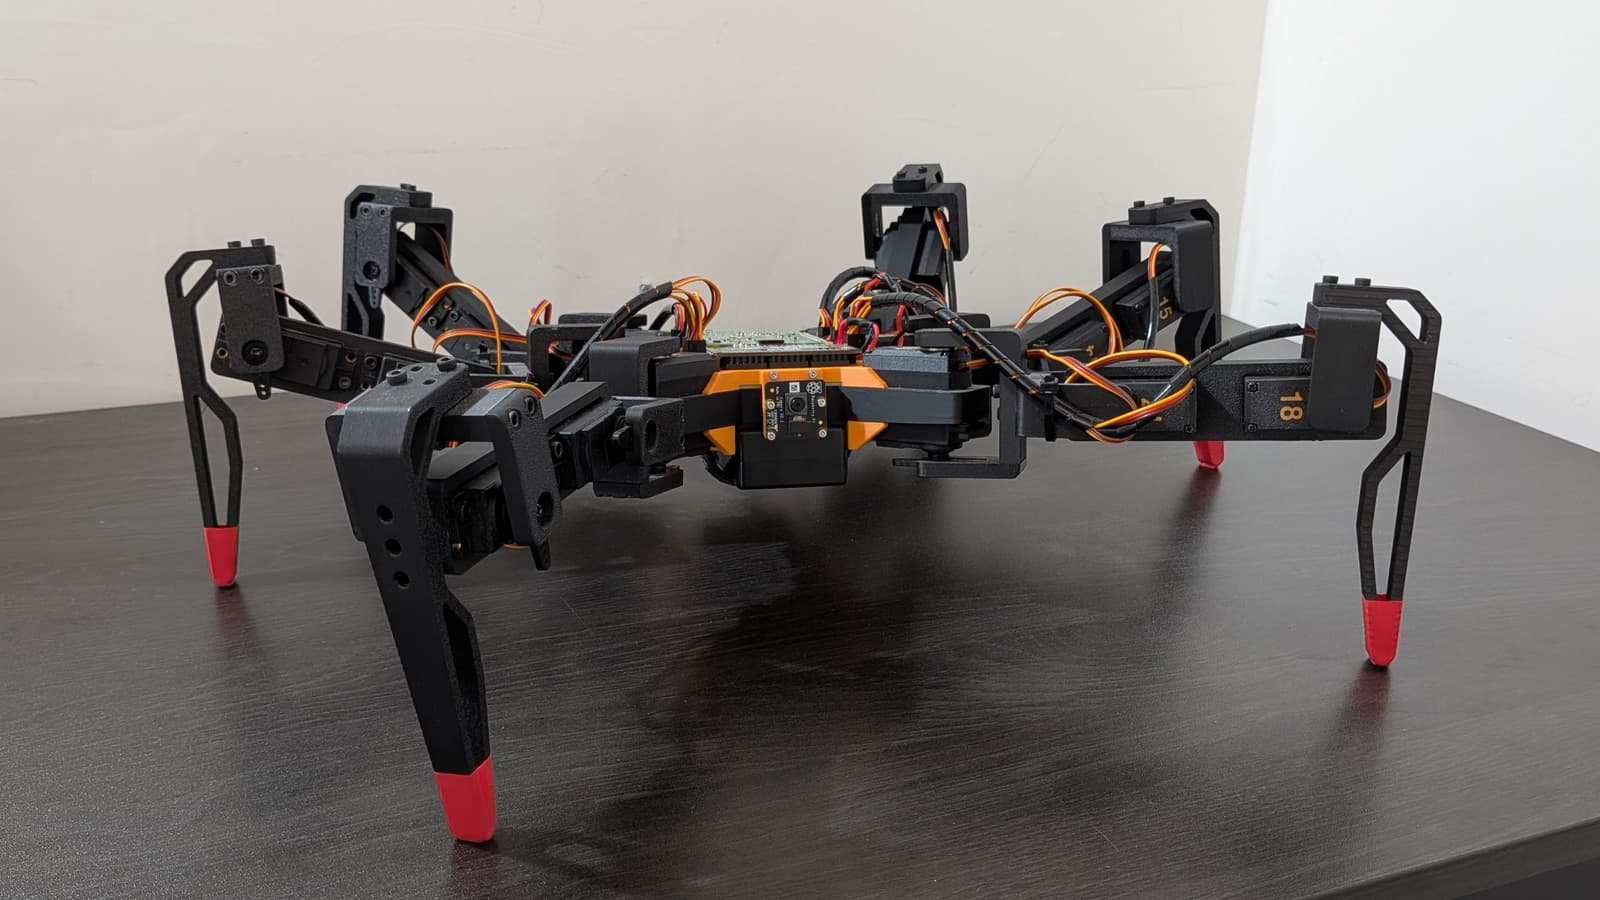
A six-legged hexapod robot built from 3D-printed parts, driven by 18 MG996 servos and controlled by a Raspberry Pi 5 with a Servo2040 board.
A lightweight home robot with modular architecture, supporting remote control, voice interaction, and human following.
A small 22-degree-of-freedom humanoid robot designed for reinforcement learning and imitation learning, featuring a rotatable waist, head, and upper limbs.
A 60 cm tall bipedal robot combining Pixar-style and Disney BDX designs, using brushless motors and reinforcement learning.
An open-source 3D-printed quadrupedal robot that performs gait generation with Bezier curves and full 6-axis body pose control.
POPI is an open-source quadruped robot designed as a student project, meant to be accessible for education and research and rebuildable by anyone.
An open-source ESP32-based quadruped robot with a web-based controller and a MuJoCo simulator.
An autonomous AI racecar built on the NVIDIA Jetson Nano that moves at high speeds and follows roads using neural networks.
Robots 1–24 of 182