 Robot arm
Dolphin Robot Arm
A 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
- Level
- Intermediate
- Buildability
- 45/100
- Incomplete documentation
- Cost
- Not stated
Robots whose guide was written in Chinese, machine-translated into English by Robotheca, with a link to the original in Chinese on each robot page. 68 robots on Robotheca, each with its licenses and its source on GitHub.
Page 2 of 3 · Ready to build first, then by buildability
Robot armA 3-degree-of-freedom desktop dolphin robot arm controlled via an STM32 microcontroller and a PS2 gamepad.
 Drone
FinsROV is a low-cost, open-source underwater robot platform designed for underwater tasks and research in robotics and AI.
 Robot arm
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
 Quadruped
A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.
 Humanoid
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
 Wheeled
An open-source AGV chassis based on ROS for learning and practical applications.
An OTTO robot enhanced with ESP32 for Bluetooth remote control and a screen.
 Other
An open-source adaptive two-finger gripper designed for low-cost, high-performance robotic applications.
A beginner-friendly open-source quadruped robot with 3D-printable parts and ROS-based control software.
 Wheeled
An ESP32-S3-based omnidirectional AI robot car with voice interaction, powered by Coze and Baidu speech technology.
 Quadruped
A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.
 Robot arm
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
A self-balancing robot based on DengFOC motor driver and SimpleFOC, featuring Bluetooth control via a WeChat mini-program.
 Drone
A small drone platform based on Espressif ESP32/ESP32-S2/S3 microcontrollers with Wi-Fi control and multiple flight modes.
A biomimetic robot head with tendon-driven neck controlled via Raspberry Pi and PCA9685 servos.
 Quadruped
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
 Wheeled
A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.
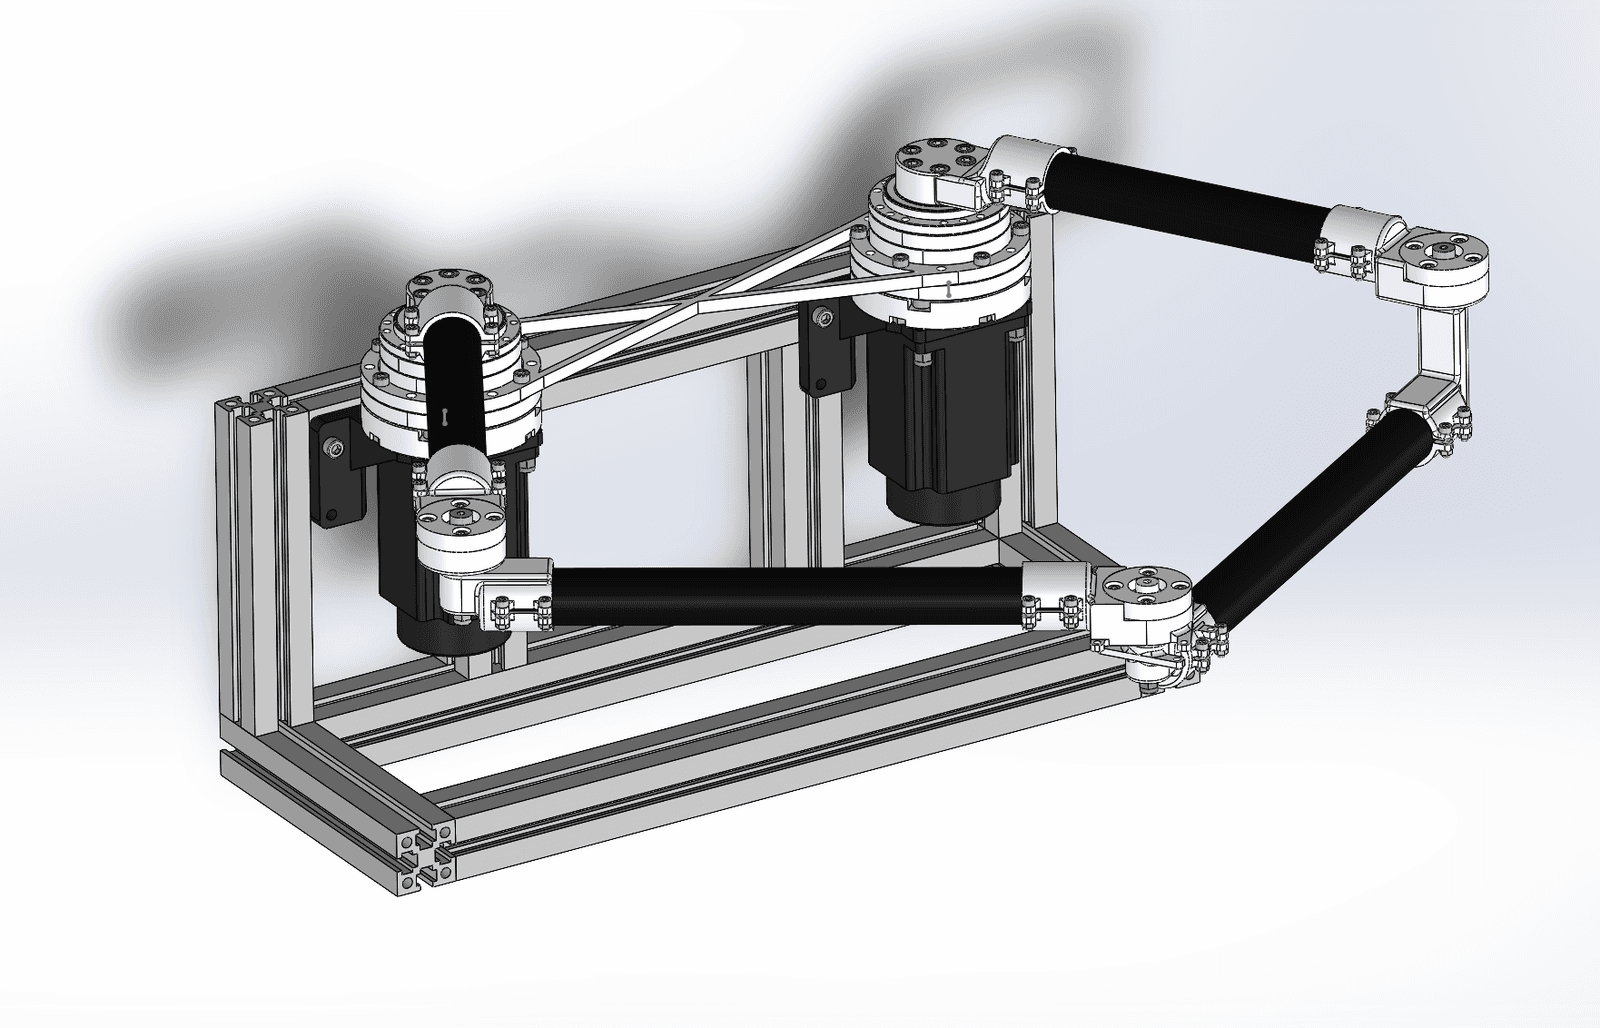 Robot arm
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
A writing robot with a 2040 aluminum frame and Core-XY structure that automates handwriting tasks.
 Quadruped
A simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.
 Humanoid
A desktop-sized open-source robot with 6 degrees of freedom, enhanced with AI capabilities via ESP32, designed for education and maker projects.
An open-source 6-DOF desktop robotic arm powered by NEMA 17 stepper motors.
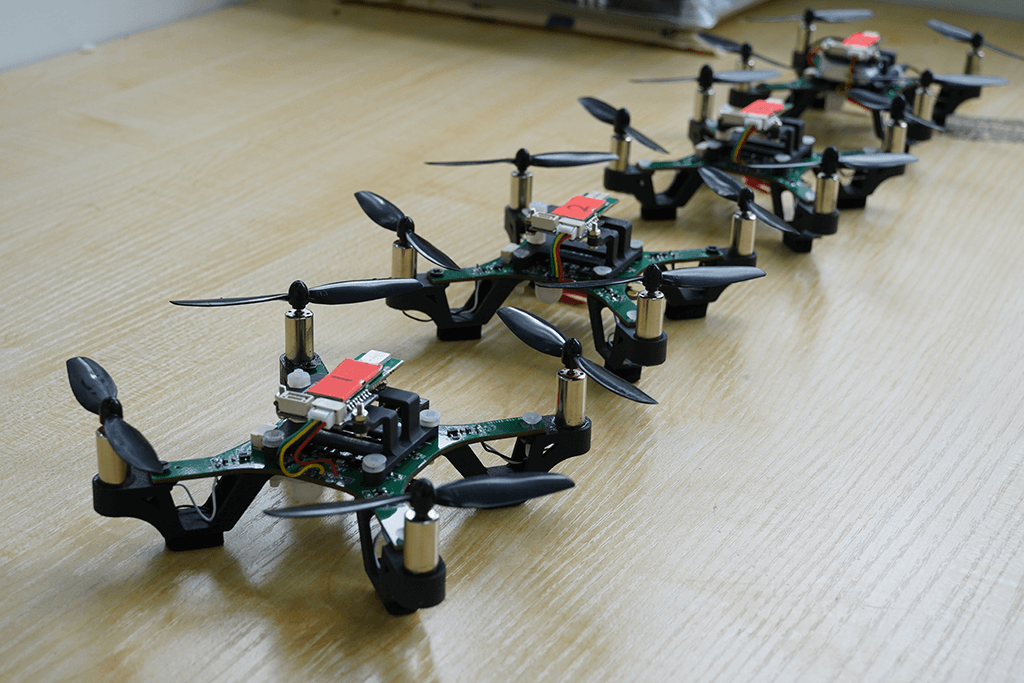 Drone
A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.
An independent hobbyist recreation of the MicroDuck 3D model, provided as SolidWorks source files and a STEP export for a small robot.
Robots 25–48 of 68