No photo yet
QuadrupedPy-Apple BLDC Quadruped Robot
An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
- Work in progress
- Level
- Intermediate
- Buildability
- 35/100
- Incomplete documentation
- Cost
- Not stated
Robots whose guide was written in Chinese, machine-translated into English by Robotheca, with a link to the original in Chinese on each robot page. 68 robots on Robotheca, each with its licenses and its source on GitHub.
Page 3 of 3 · Ready to build first, then by buildability
An open-source quadruped robot using BLDC motors with FOC control for dynamic movement.
 Quadruped
An open-source quadruped robot designed for easy DIY with low-cost hardware and software.
An open-source quadruped robot mechanical structure designed to support the Py-Apple Controller and Py-Apple Dynamics software.
A quadruped robot controlled by an STM32F103C8T6 microcontroller, capable of walking forward, backward, and lifting its legs.
 Wheeled
A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.
 Other
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
An open-source quadcopter framework providing schematics and flight control source code.
 Other
A 3.5 kg wheeled combat robot with STM32 and Raspberry Pi, designed for robot fighting competitions.
A compact quadruped robot designed as a desk pet, featuring FreeRTOS-based control, tomato timer, expression display, and interactive motions like walking, turning, waving, and bowing.
An open-source parallel four-legged robot with eight motors designed to achieve four gaits from slow to fast.
An open-source hardware solution for the 20th National University Intelligent Vehicle Competition unicycle category Q-car model, featuring integrated PCB and 3D-printed parts.
 Wheeled
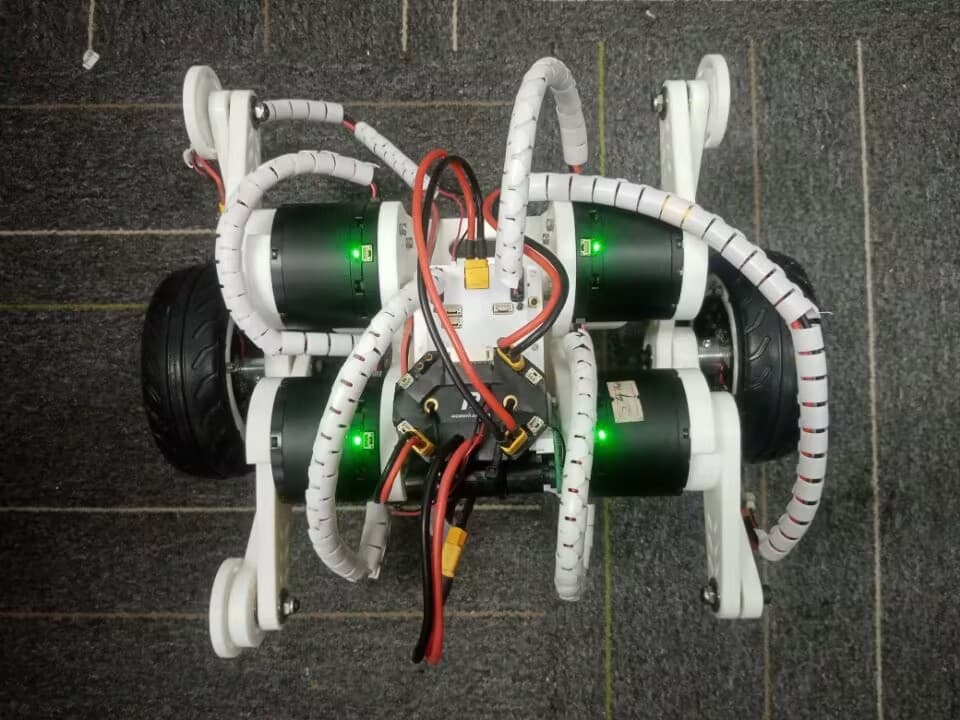
A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.
A 400mm wheelbase quadcopter drone with full protection, designed for university electronic design competitions.
A voice-enabled desktop robot based on the ElectronBot platform, featuring audio input and output capabilities.
An open-source omnidirectional smart car designed for the 16th National Intelligent Vehicle Competition, featuring embedded control and PID algorithms.
A low-cost ROS2 robot designed for students and hobbyists to learn robotics and ROS2 development through hands-on assembly and programming.
 Humanoid
An open-source humanoid robot designed for learning and AI integration, featuring assembly guides and firmware documentation.
An open-source quadruped robot controller based on ESP32, designed to support the Py-Apple Dynamics software suite for controlling quadruped robots.
Mechanical model and parts list of HighTorque's Panthera-HT robot arm: SolidWorks 2024 sources, STEP files and a BOM spreadsheet.
Open-source electronics hardware for a kart entry in the 21st Intelligent Car Competition provincial round, designed in LCEDA Pro.
Robots 49–68 of 68