Py-Apple Dog
An open-source quadruped robot designed for easy DIY with low-cost hardware and software.
- Quadruped
- Open source
- 3D printable
Suggested by Robotheca, created by @ToanTech (opens in a new tab), from github.com/ToanTech/py-apple-quadruped-robot (opens in a new tab). Pinned to commit d2bb34f (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (2 programs or installers, 1 firmware image)
Photo
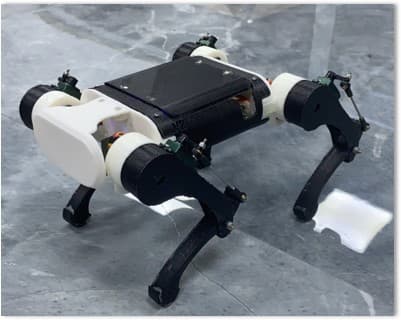
- Degrees of freedom
- 8
What it can do
Written by Robotheca from the project's documents.
- Walks with static and dynamic gaits
- Performs 8DOF inverse kinematics
- Uses VMC algorithm for motion
- Adjusts leg angles for spatial compensation
- Controls pitch, roll, and height of the body
- Recovers from falls automatically
- Supports RC transmitter control
- Provides web-based remote control and tuning
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Learn the basics from provided video tutorials
- 2Download and print mechanical structure parts
- 3Assemble the mechanical structure and hardware
- 4Build the controller board
- 5Download and flash the control software
- 6Configure and operate the robot
- 7Join the project discussion group for support
The guide appears here as you scroll.
Guide by @ToanTech (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Py-Apple Controller V4.0 main control board
- Servo motors for 8 degrees of freedom
- Battery power supply