Wheel-legged Robot
A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.
- Wheeled
- Open source
- 3D printable
Suggested by Robotheca, created by @Kevin16437 (opens in a new tab), from github.com/Kevin16437/wheel_legged_robot (opens in a new tab). Pinned to commit edc4bff (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo and 3D model
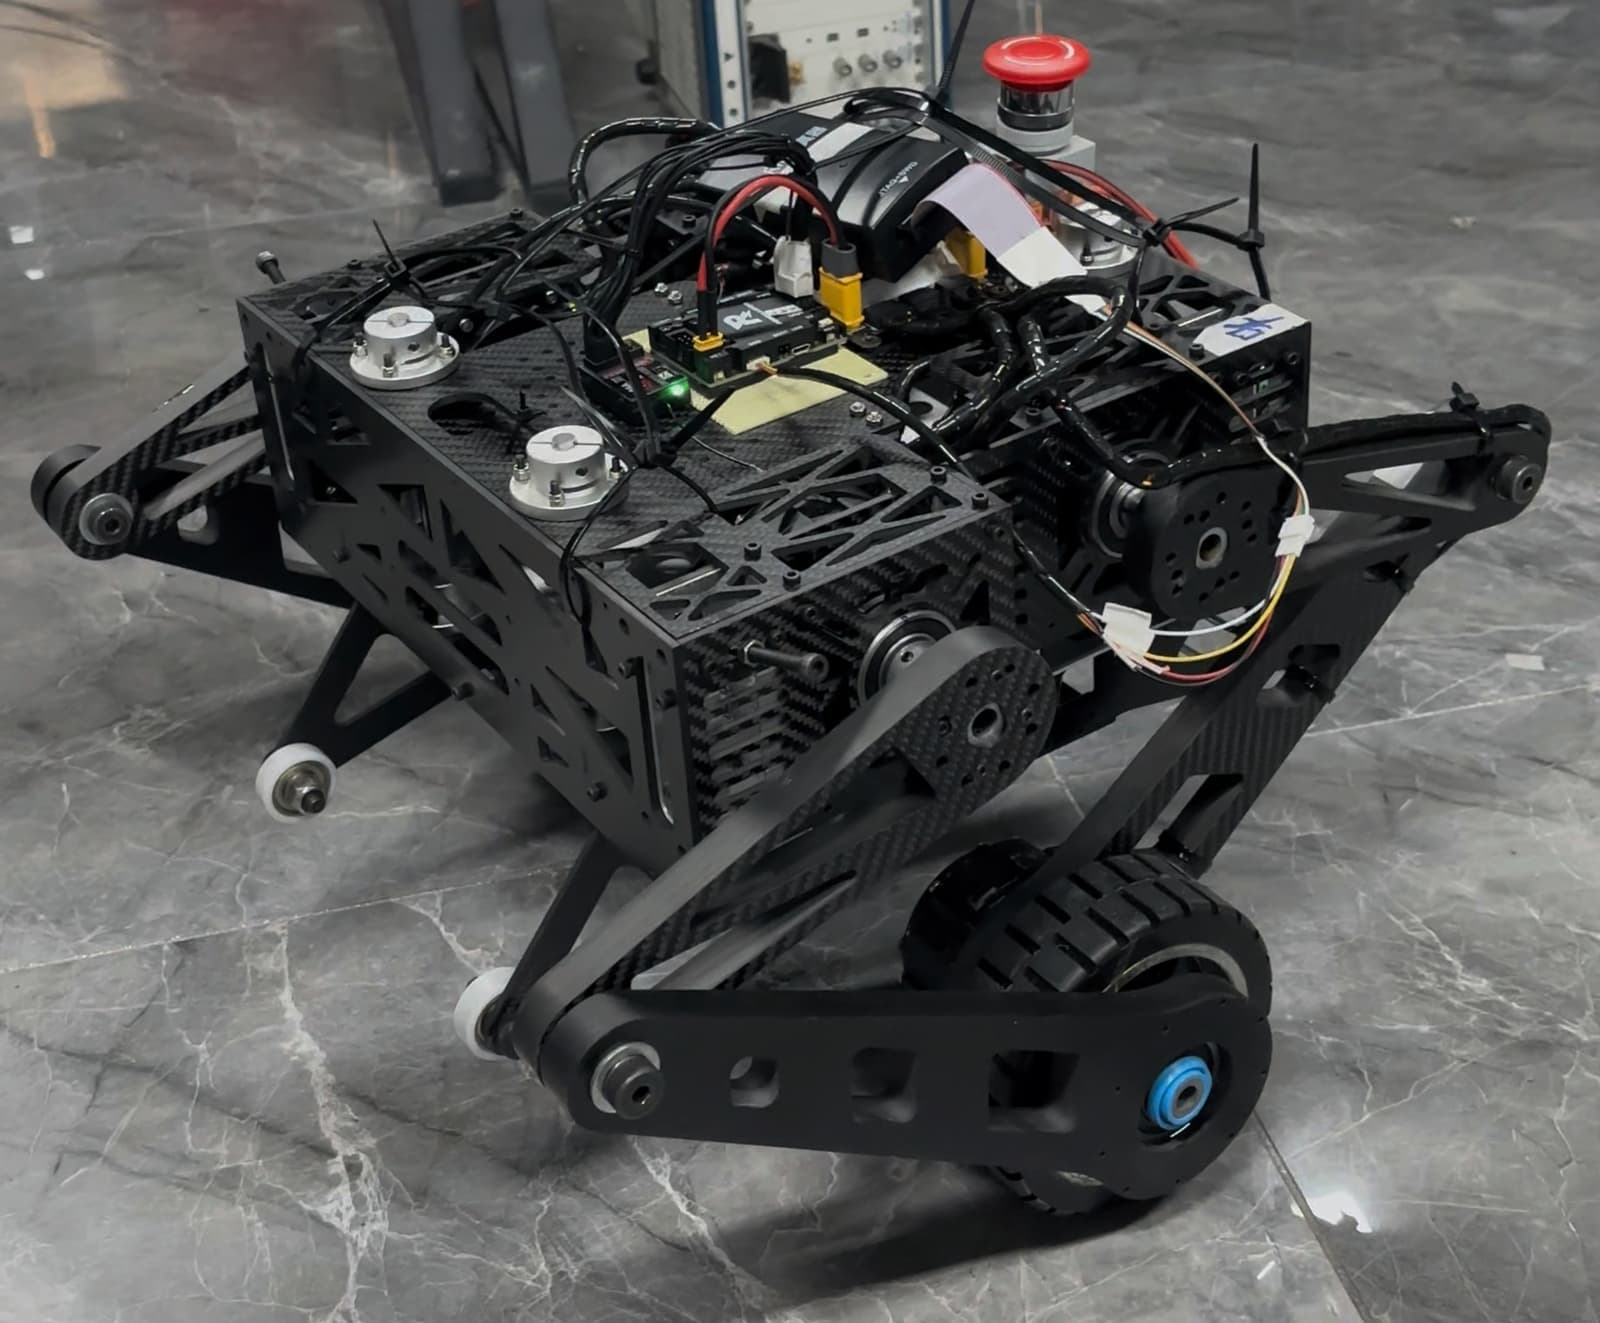
3D preview converted from github.com/Kevin16437/wheel_legged_robot at edc4bff, under GPL-3.0-only. View the original files from GitHub (35.4 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Walks using six legs with four joint motors and two wheel-hub motors
- Uses virtual model control and LQR for balance
- Controlled via HOT-RC HT-6A remote controller
- Runs real-time control on ESP32 with FreeRTOS
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Kevin16437 (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- DJI RoboMaster Development Board Type C as main controller
- Six SG6010 single-encoder motors (four joints, two wheel hubs)
- Power distribution board with XT60 battery input and XT30PW connectors
- CAN bus for motor communication
- 24V lithium battery (3000mAh, 75C)
- HOT-RC HT-6A remote controller
Connections
- Motors connected through power distribution board to a single CAN bus
- Power distribution board receives 24V from XT60 battery input
- XT30PW connectors carry power and CAN signals to motors
- CAN lines from power board connect to main controller for motor control and debugging