Project files
- hardware21 files
- matlab113 files
- readme_img1 file
- software89 files
- solidworks199 files
- LICENSE35 KB
- README.md2 KB
README.md
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
Wheeled-legged Robot
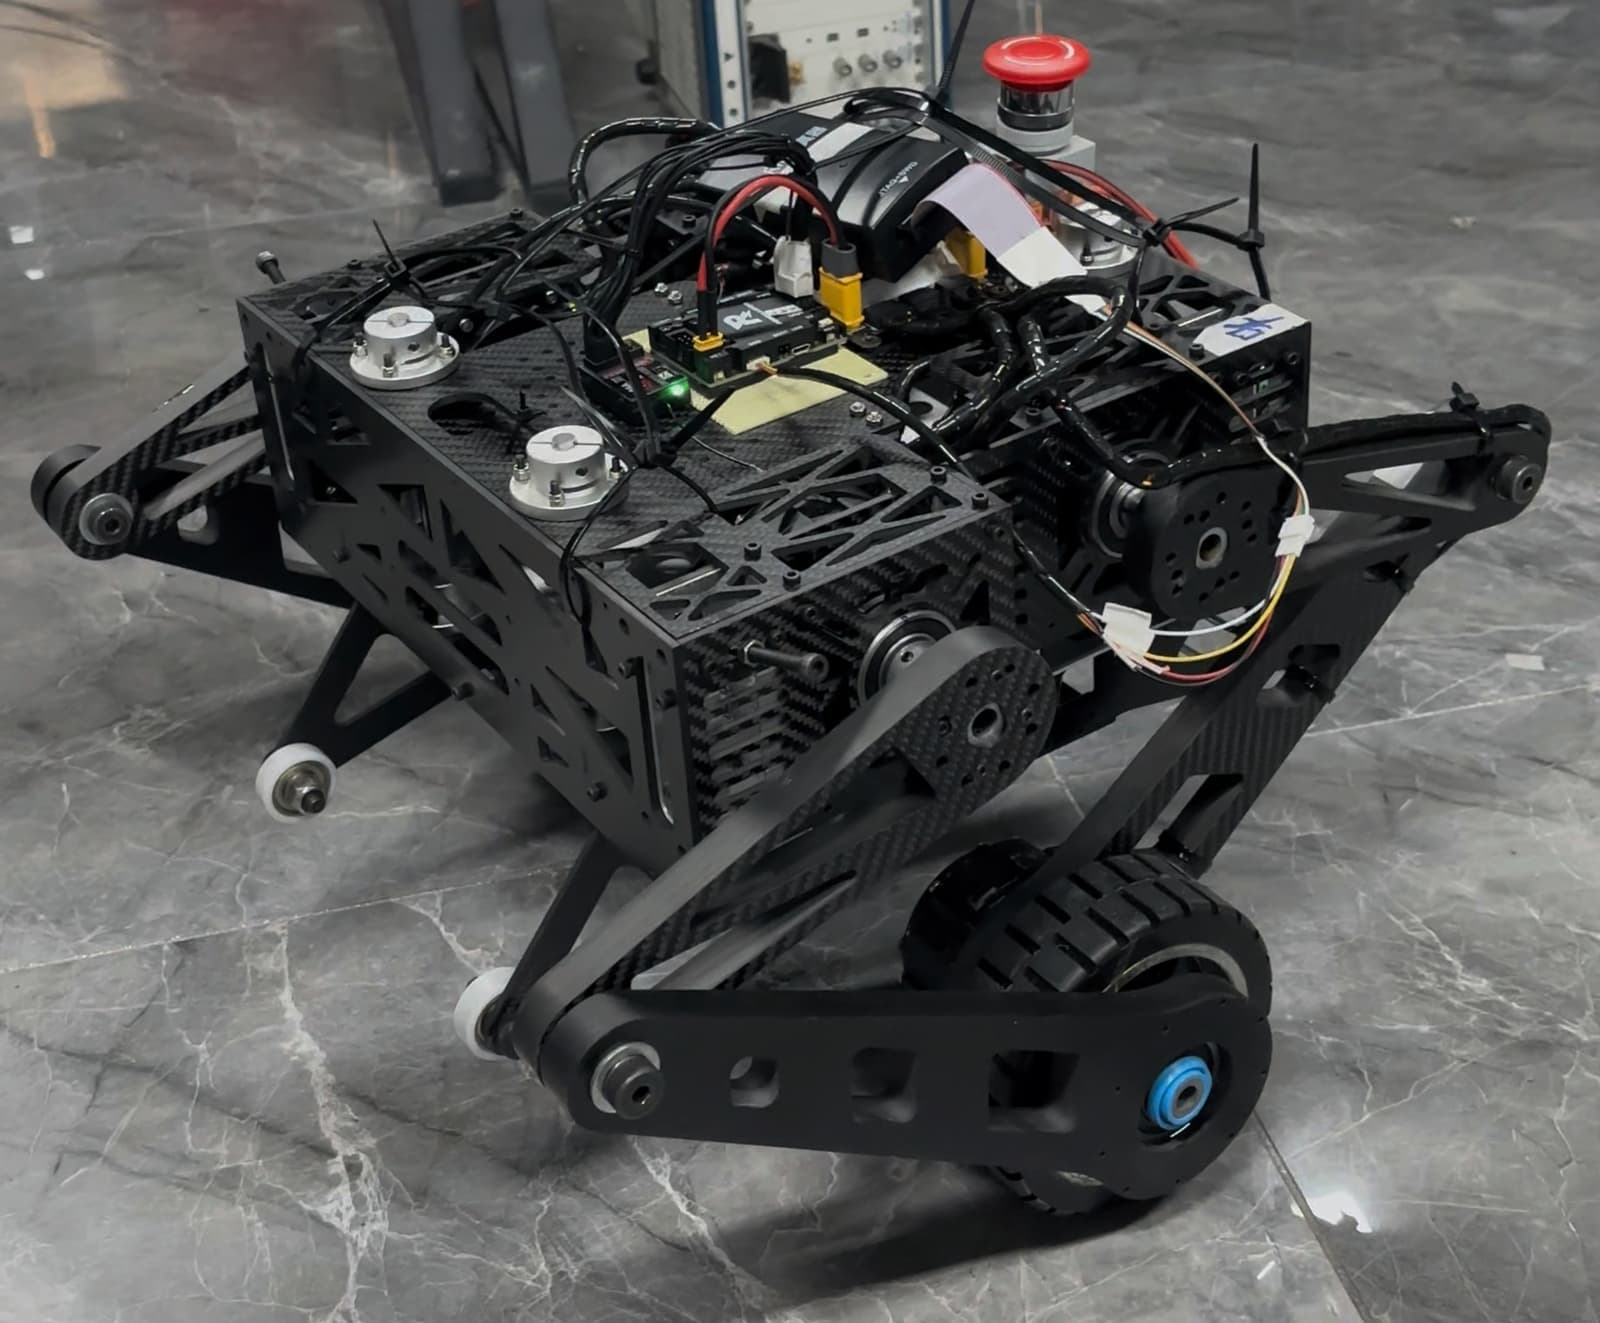 Still being updated and improved. The code part is yet to be supplemented with explanations.
Introduction
This legged-wheeled robot project uses six motors: four joint motors and two hub motors, all equipped with SG6010 encoders. The battery compartment and main control mounting holes are located on the bottom of the body. The main control board is a DJI RoboMaster Type C development board.
The main control code includes another open-source repository: Motor SDK (opens in a new tab).
Table of Contents
The entire robot project is divided into multiple parts, each stored in a different directory of the repository. Each part has more detailed instructions, and readers can refer to them as needed:
hardware: Power distribution board PCB files, exported by JLCPCB Pro version, including Gerber and AD files.matlab: Algorithm simulation, including model establishment, algorithm design, and simulation files.software: Main control program, including STM32 code project.solidworks: Mechanical structure design, including all part and assembly model files.
About Us
Beijing CyberBeast Technology Co., Ltd. is a company dedicated to motor drive technology, focusing on the research and development of servo motor driver boards. This open-source project embodies our commitment to technical sharing and community building. We welcome your suggestions to jointly improve and develop legged robot technology.
For technical support or cooperation, please contact: luoyongheng@cyberbeast.cn (opens in a new tab)
Special Thanks
We would like to express our heartfelt gratitude to Siggear Transmission for their strong support of this project.
Open Source License
This project is released under the GNU General Public License v3.0 (GPL-3.0). You are free to use, modify, and distribute the source code of this project, but you must comply with the following terms:
- If you modify the code of this project and release it, you must include the original author's information in the released code.
- Derivative works released must be published under the same GPL-3.0 license.
- When using this project, if you distribute it together with other code, you must make all source code public.
For the detailed license content, please refer to LICENSE.
DRIVE THE WORLD WITH CYBERBEAST
Files by @Kevin16437, at commit edc4bff, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.