← Wheel-legged Robot
Project files
1 KB
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
Power Distribution Board
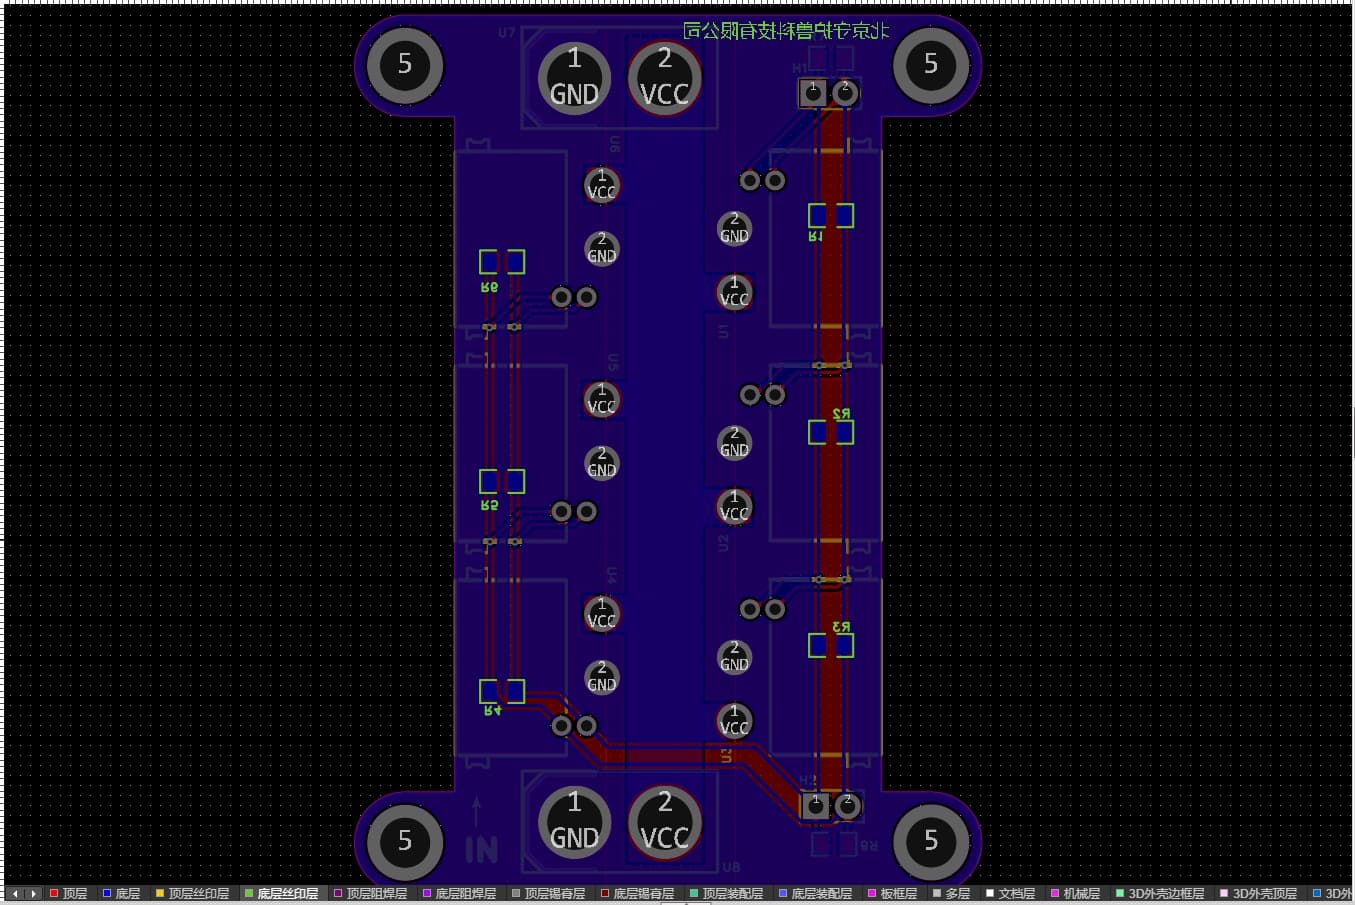
This power distribution board uses an XT60 connector to input 24 V from the battery and provides power to six motors and the main control board. The XT30PW includes a CAN interface, and each XT30PW CAN interface can have a 120 Ω resistor (located on the back of the PCB) connected in parallel. Two CAN interface lines are provided externally (one for debugging and one for connecting to the main control board).


Files by @Kevin16437, at commit edc4bff, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.