Project files
1 KB
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
Wheel-Leg Controller Section
This code is developed based on Esp32WheelLeg (opens in a new tab), and we would like to express our gratitude to open-source contributor Skythinker616 (opens in a new tab) for their work.
Description
This project uses the DJI RoboMaster Development Board C as the main control board, develops using the FreeRTOS real-time system, and employs the onboard BMI088 gyroscope. The remote controller is the HOT-RC HT-6A.
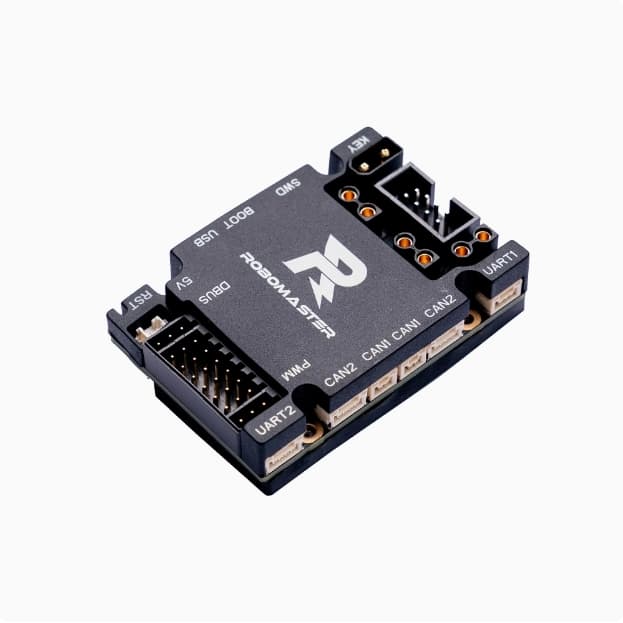

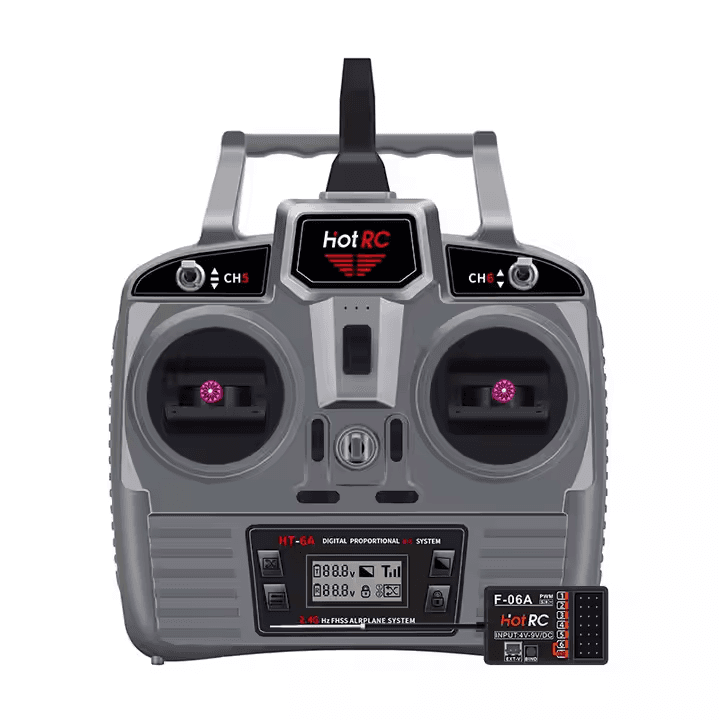
Hardware Connection
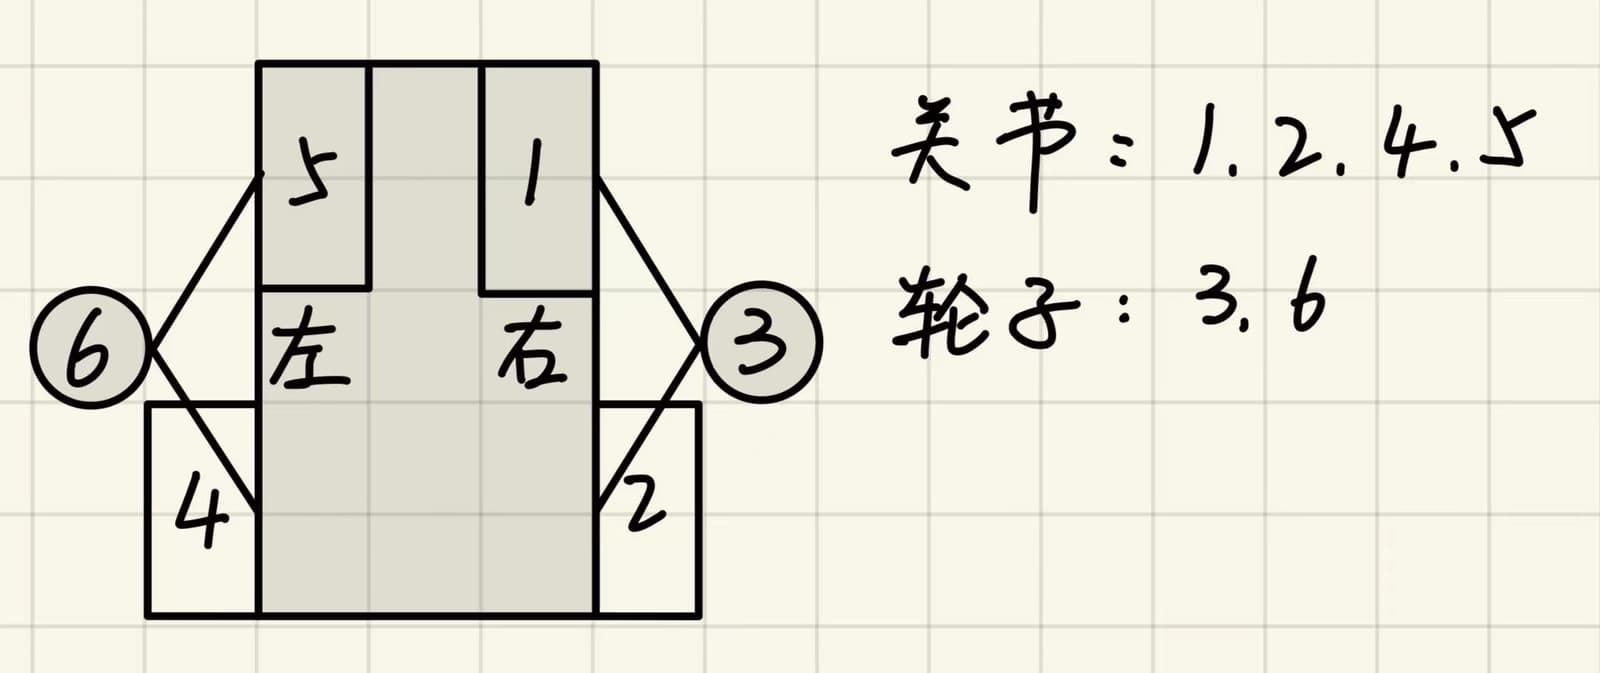
Six motors are connected to a single bus via a distribution board, which in turn connects to the main control board. The CAN IDs of the motors are assigned as follows:
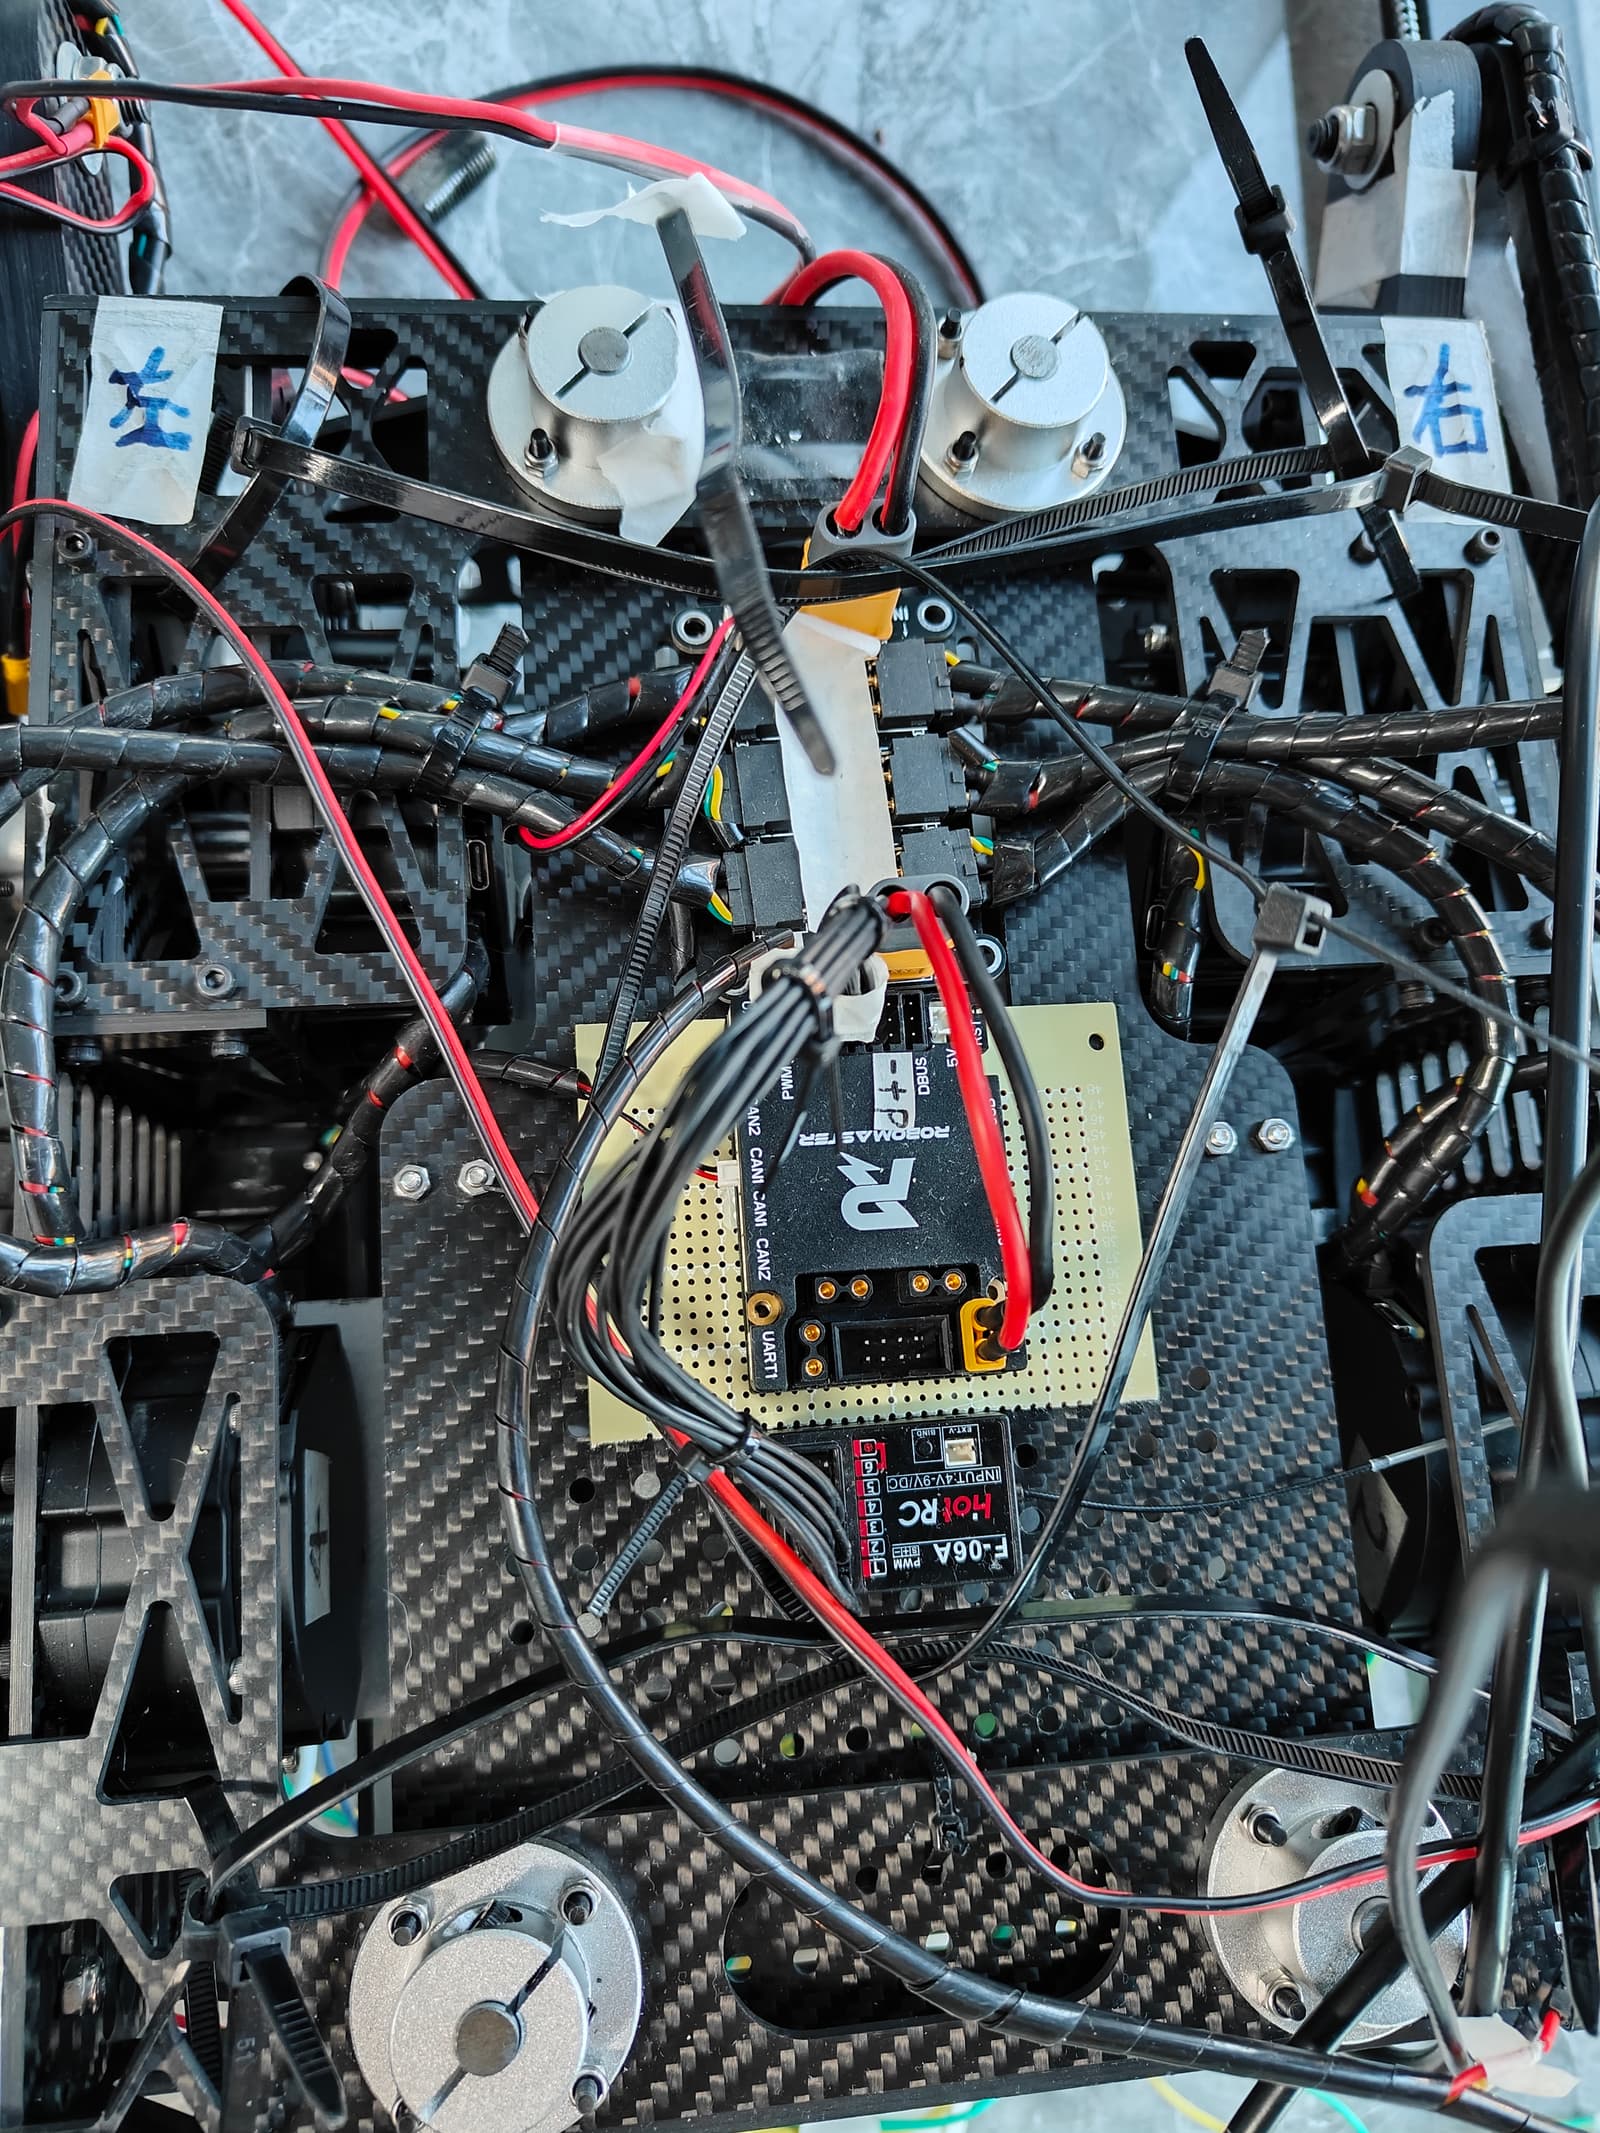
Gyroscope Installation Method
The installation position of the gyroscope in this program differs from the mechanical reserved mounting holes. The specific installation position is as follows (the lines are a bit messy -_-||):
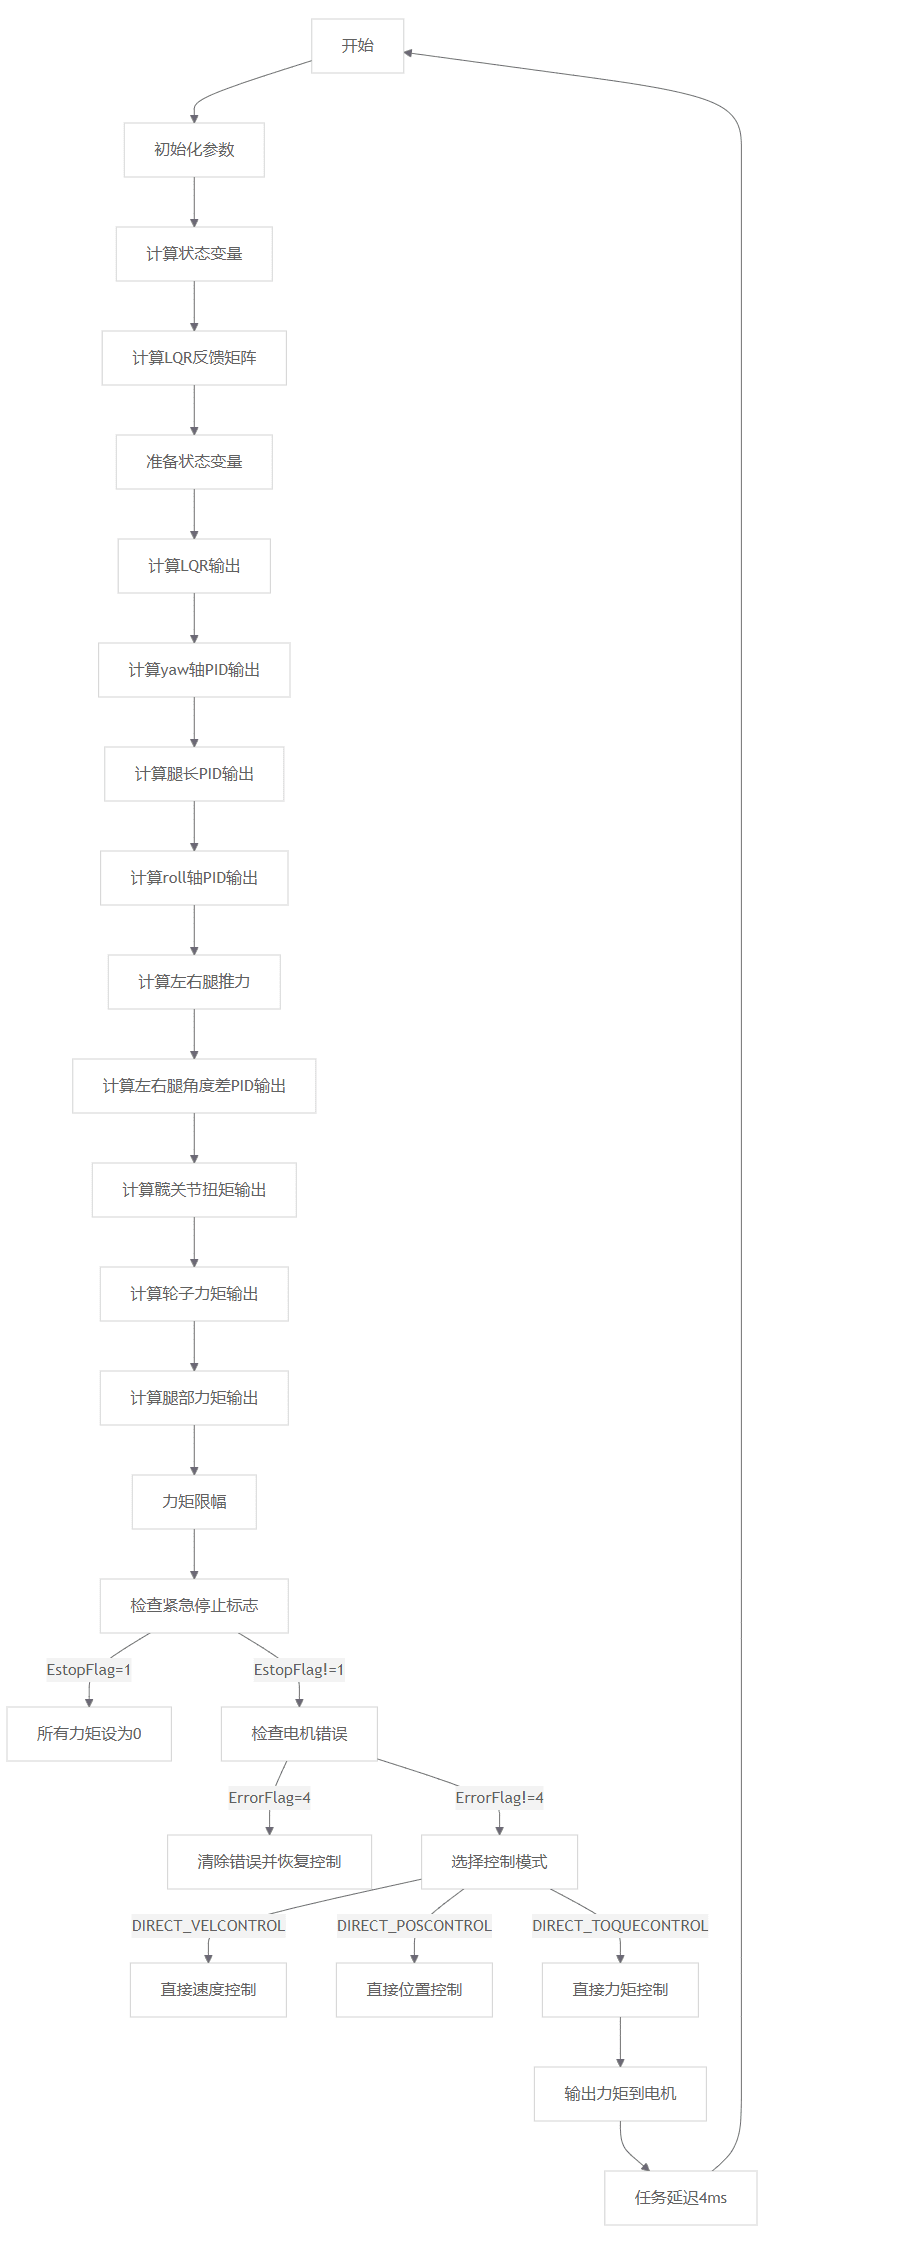
Program Block Diagram
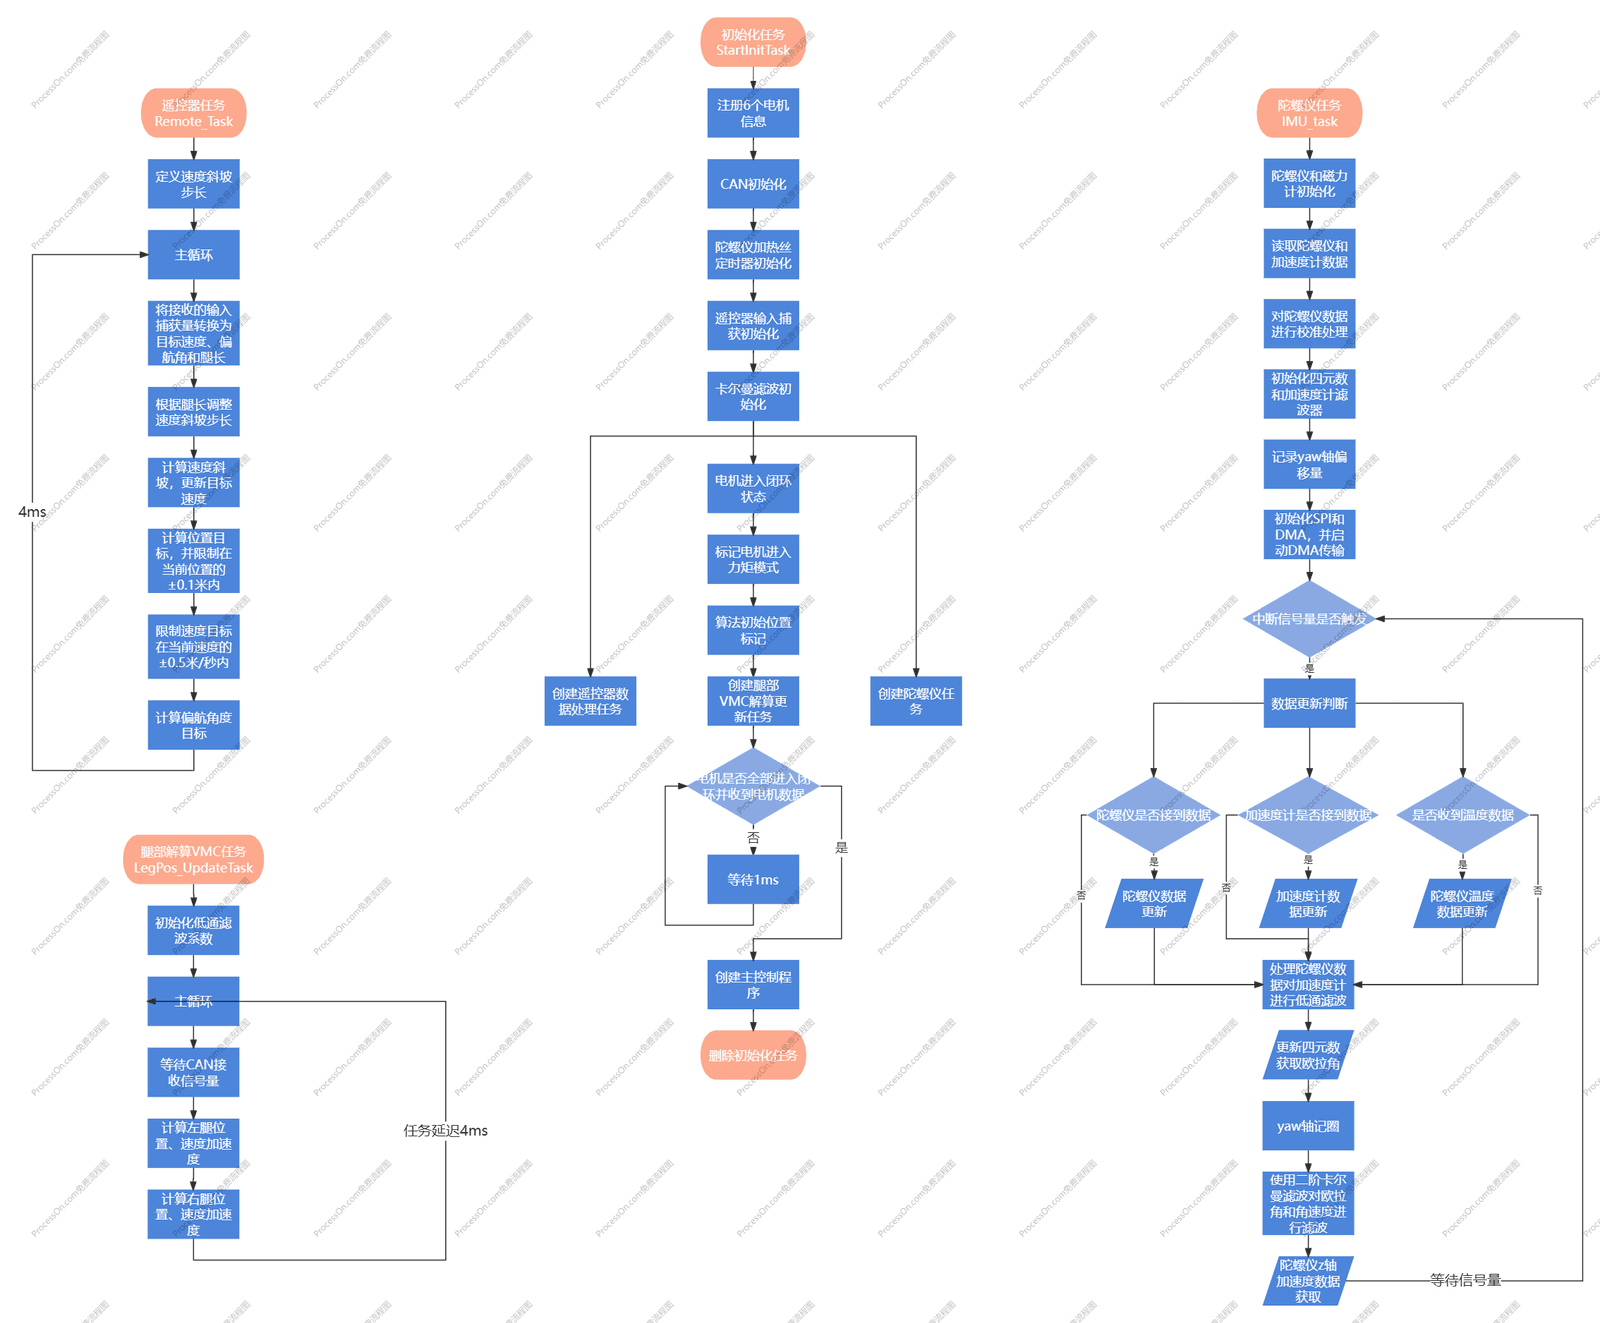 Main program block diagram
Files by @Kevin16437, at commit edc4bff, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.