SCARA Parallel
A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio
- Robot arm
- Open source
- 3D printable
Suggested by Robotheca, created by @Yangtao123droid (opens in a new tab), from github.com/Yangtao123droid/SCARA_Parallel (opens in a new tab). Pinned to commit e250202 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 script, 1 firmware image)
Photo
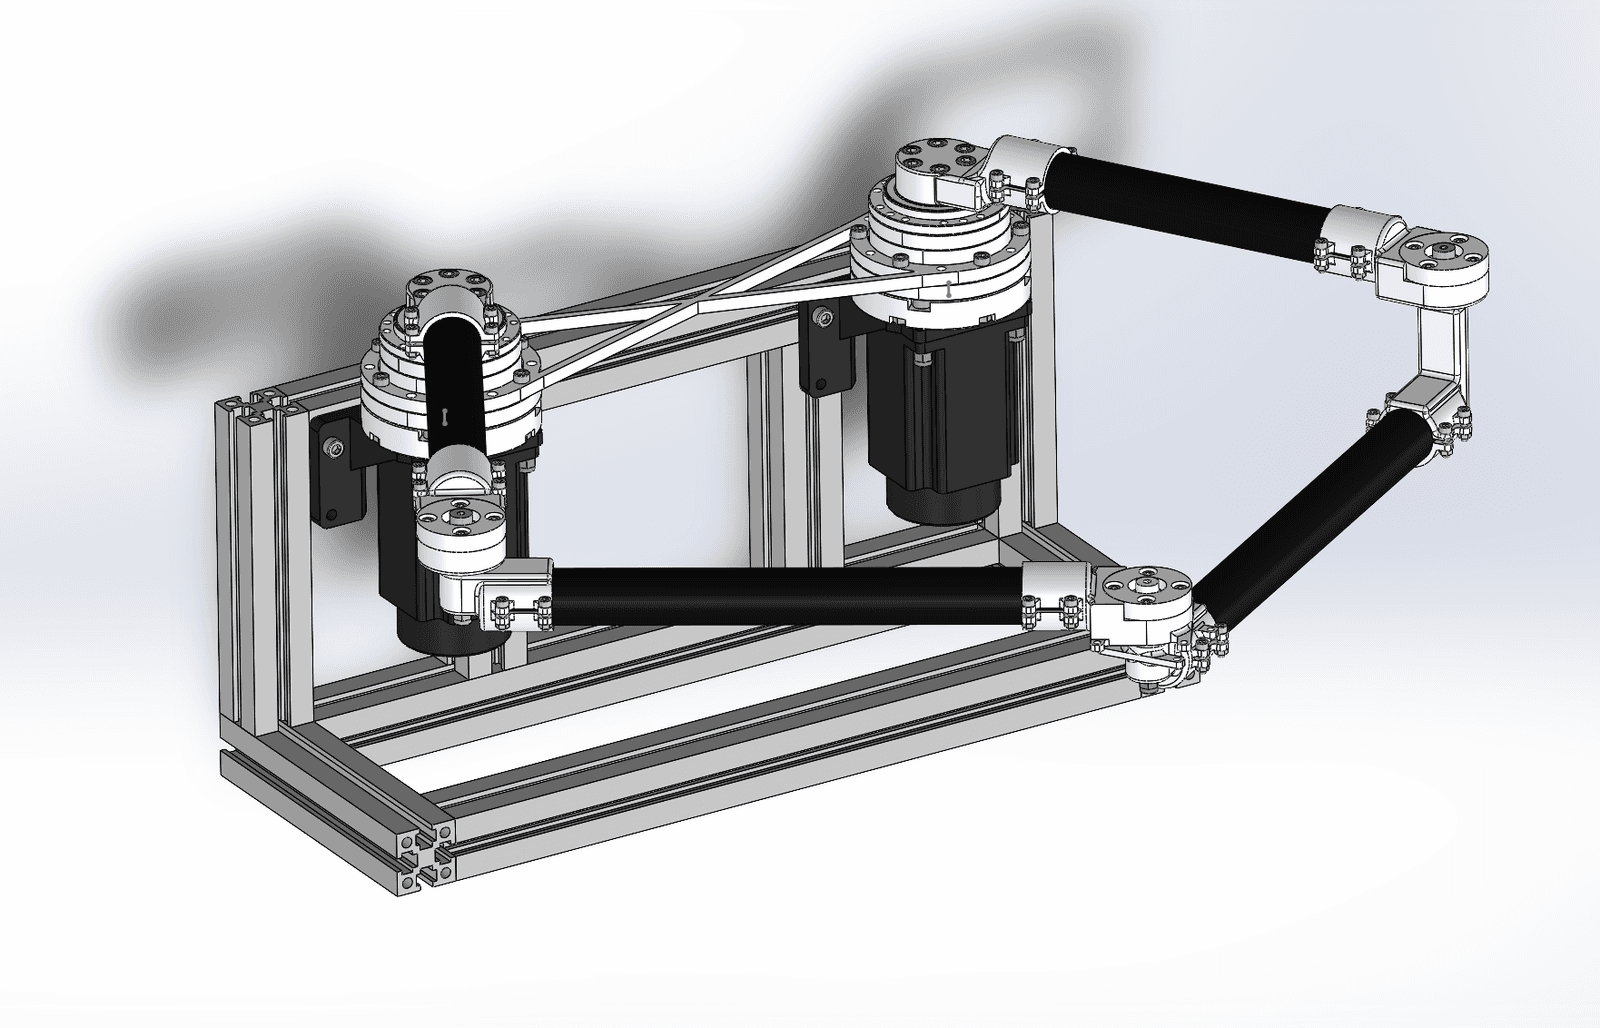
What it can do
Written by Robotheca from the project's documents.
- Moves joints with closed-loop stepper motors
- Uses harmonic reducers for high-precision positioning
- Performs linear interpolation for smooth motion
- Controlled by STM32F407 microcontroller
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Hardware Selection and Structural Design
- 2Motor Selection
- 3Reducer Selection
- 4Joint Rotary Axis Design
- 5Rod Selection
The guide appears here as you scroll.
Guide by @Yangtao123droid (README.md), under Apache-2.0. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- STM32F407 microcontroller board
- Jiemekang 57J1880 closed-loop stepper motors
- 2HSS57 closed-loop stepper motor drivers
- Leaderdrive LSCG series harmonic reducers (17-50, ratio 50)
- Flange-mounted bearings for joint rotation axes
Connections
- Motor drivers connected to STM32F407 via pulse signals for stepper control
- Harmonic reducers mounted on motor shafts with key pins and set screws
- Carbon fiber rods used as structural links between joints