RoverLite32
A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.
- Wheeled
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @ViolinLee (opens in a new tab), from github.com/ViolinLee/RoverLite32-CPP (opens in a new tab). Pinned to commit 435780c (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (8 scripts)
- roverlite/lib/ArduinoJson/extras/ci/particle.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/build-arduino-package.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/build-single-header.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/get-release-body.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/get-release-page.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/publish-particle-library.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/publish.sh (opens in a new tab)
- roverlite/lib/ArduinoJson/extras/scripts/wandbox/publish.sh (opens in a new tab)
Photo and 3D model
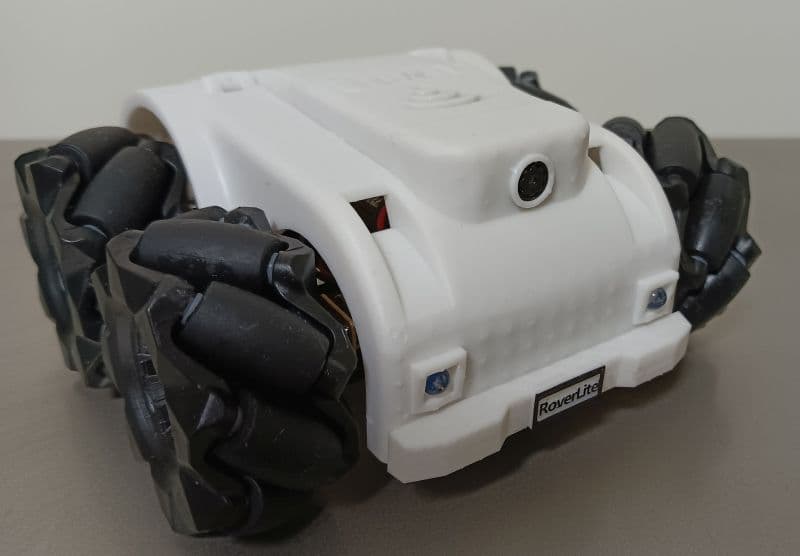
3D preview converted from github.com/ViolinLee/RoverLite32-CPP at 435780c, under MIT. View the original files from GitHub (4.1 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Moves with four mecanum wheels
- Controlled by remote control or autonomous navigation
- Supports video transmission from an onboard camera
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Mechanism
- 2Electronics
The guide appears here as you scroll.
Guide by @ViolinLee (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32 microcontroller
- Four mecanum wheel motors with drivers
- Camera module for video transmission
- Battery power supply
Connections
- ESP32 connected to motor drivers via GPIO pins
- Camera module connected to ESP32 via I2C or UART
- Power distribution from battery to motors and ESP32