Hyun
A wheeled-legged robot controlled by an ESP32, featuring an MPU6050 gyroscope, PM3510 brushless motors, and SimpleFOC drivers.
- Quadruped
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @HuGuoXuang (opens in a new tab), from github.com/HuGuoXuang/Hyun (opens in a new tab). Pinned to commit c9ce1d1 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
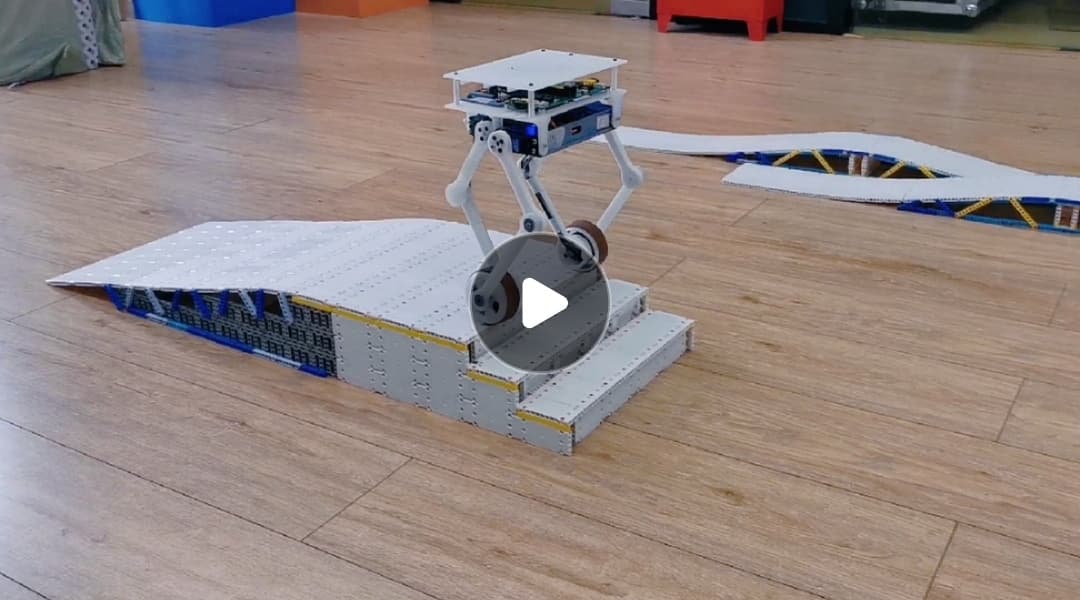
3D preview converted from github.com/HuGuoXuang/Hyun at c9ce1d1, under MIT. View the original files from GitHub (1.7 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Walks on four legs with twelve degrees of freedom
- Stands and balances using gyroscope feedback
- Moves legs in coordinated gaits for forward, backward and turning motions
- Controlled via serial commands over USB or Bluetooth
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Assemble the main PCB board
- 2Assemble the FOC driver PCB
- 3Assemble the magnetic encoder PCB
- 43D print the robot structure
- 5Install motors and encoders
- 6Connect and configure the ESP32 and MPU6050
- 7Upload the FOC driver firmware
- 8Upload the main controller firmware
- 9Calibrate the gyroscope and motor parameters
- 10Test and tune the robot's movement
The guide appears here as you scroll.
Guide by @HuGuoXuang (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- 12V Li-ion battery pack
- HC-05 Bluetooth module for wireless control