← Hyun
Project files
README.md
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: MIT (opens in a new tab).
Wheeled-Legged Robot — Hyun
Issues:
- The hardware engineering files have been re-uploaded. Previously, due to the file size exceeding 25 MB, some parts were missing and could not be opened normally.
- It is not recommended to use the magnets that come with the motor, as the noise received by the encoder IC will be very high.
- If the gyroscope is soldered onto the mainboard, the roll and pitch angles in the program need to be modified.
- For the first build, it is not recommended to add code to the program, as it will affect the refresh rate of the algorithm, causing Hyun to jitter.
Demo Video
Assembly Tutorial
Building the Development Environment Tutorial
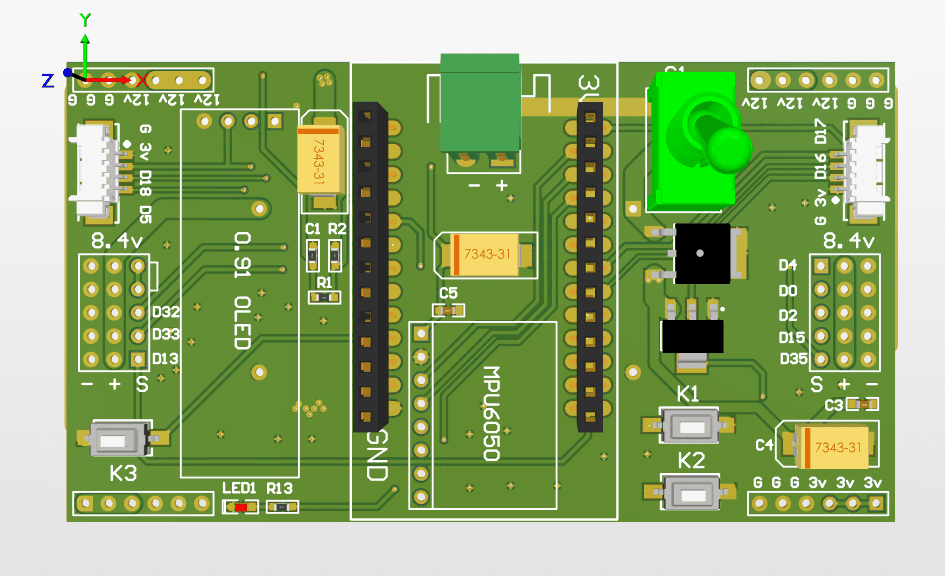
1. Mainboard PCB
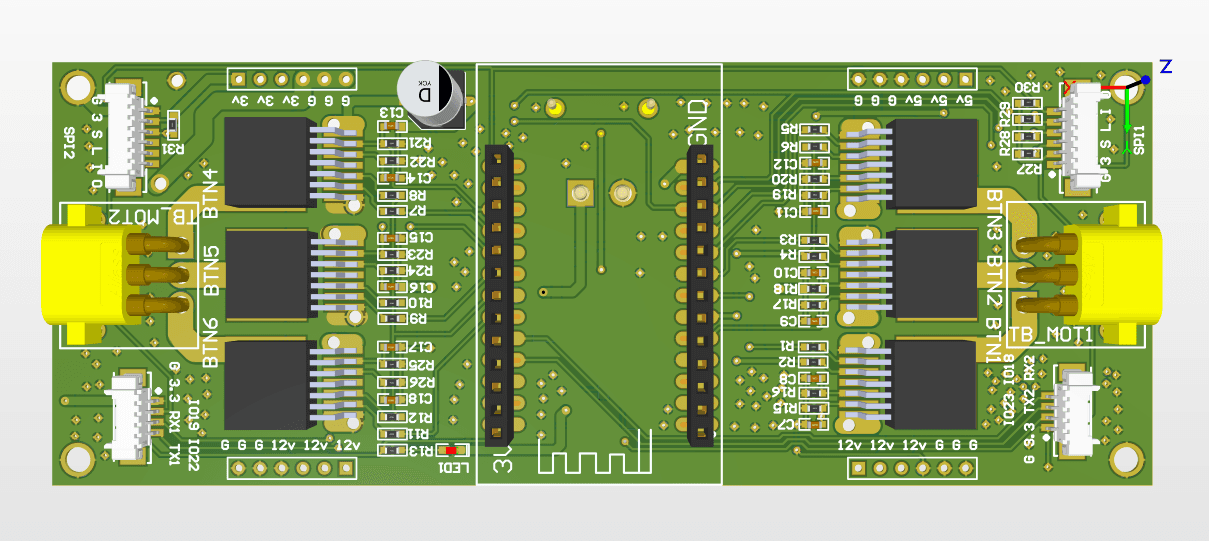
2. FOC Driver PCB
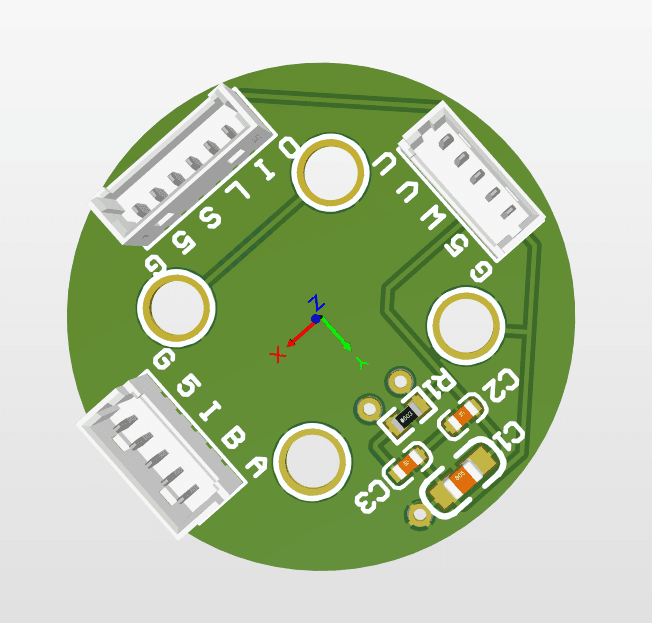
3. Magnetic Encoder PCB
Files by @HuGuoXuang, at commit c9ce1d1, read from GitHub in your browser. Hardware license: MIT; software license: MIT. Robotheca doesn't review code: read it before running it.