ZGPS-01
A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.
- Other
- Open source
- 3D printable
Suggested by Robotheca, created by @ZGPS-666 (opens in a new tab), from github.com/ZGPS-666/ZGPS_01 (opens in a new tab). Pinned to commit 2970e95 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
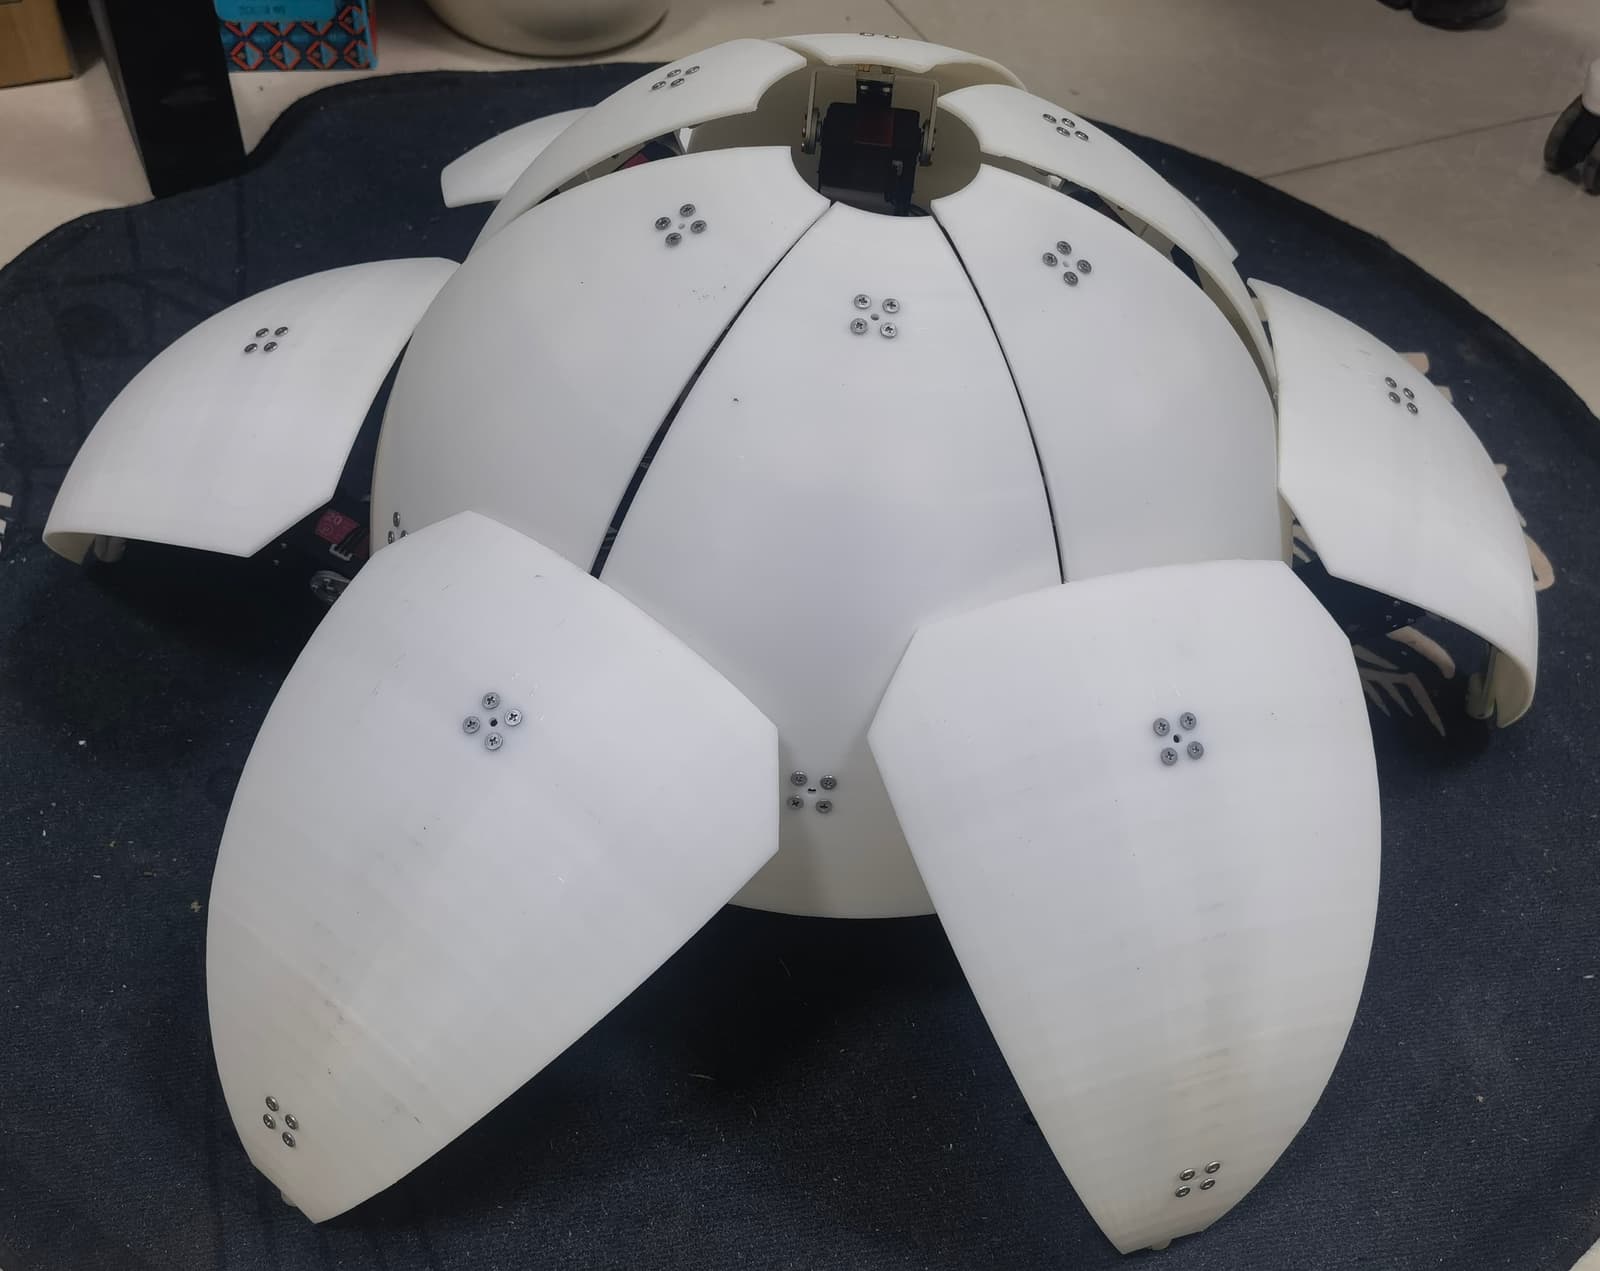
3D preview converted from github.com/ZGPS-666/ZGPS_01 at 2970e95, under GPL-3.0-only. View the original files from GitHub (905 KB) (opens in a new tab)
- Power
- 7.4 V
- Payload
- 0.2 m
- Cable length
- 0.5 m
What it can do
Written by Robotheca from the project's documents.
- Switches between spherical and hexapod modes
- Walks in hexapod mode with straight, sideways and turning gaits
- Rolls in spherical mode with forward, backward and turning motions
- Performs autonomous shape transformation between modes in under 30 seconds
- Can be controlled via 2.4 GHz remote control
- Supports offline voice recognition control
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @ZGPS-666 (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- STM32F407ZGT6 microcontroller running at 168 MHz with 1 M Flash and 192 K SRAM
- 30 ZX20D serial bus servos rated 20 kg·cm for leg and slice control
- 1 S80 digital servo rated 70 kg·cm for shape transformation
- AIP74HC126TA.TB quad three-state buffer for UART signal level shifting
- Microzone 6C-MINI remote control system with MC7RB-V2 2.4 GHz receiver
- ASRPRO offline voice recognition module
- 7.4 V / 9000 mAh / 10 C high-discharge LiPo battery
Connections
- UART signals from STM32 to 30 ZX20D servos via AIP74HC126TA.TB buffers
- SBUS signal from MC7RB-V2 receiver through hardware level-inversion circuit to STM32
- ASRPRO voice module connected to STM32 via UART
- All servos and modules powered from 7.4 V battery through PCB power management