Wheel-legged
A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.
- Wheeled
- Open source
- ROS
- 3D printable
Suggested by Robotheca, created by @Kevin16437 (opens in a new tab), from github.com/Kevin16437/my-roscar-WHEEL-LEGGED (opens in a new tab). Pinned to commit 96bada7 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (2 scripts, 2 programs or installers, 3 firmware images)
- 打印件版/代码/DM-balance打印件版本(群友)/DM-balance打印件版本群友/MDK-ARM/CtrlBoard-H7_IMU/CtrlBoard-H7_IMU.hex (opens in a new tab)
- 打印件版/代码/DM-balance打印件版本/DM-balanceV1/MDK-ARM/CtrlBoard-H7_IMU/CtrlBoard-H7_IMU.hex (opens in a new tab)
- 打印件版/仿真/simulation/slprj/raccel/wheel_leg/tbb.dll (opens in a new tab)
- 打印件版/仿真/simulation/slprj/raccel/wheel_leg/wheel_leg.bat (opens in a new tab)
- 打印件版/仿真/simulation/slprj/raccel/wheel_leg/wheel_leg.exe (opens in a new tab)
- 打印件版/仿真/simulation/slprj/raccel/wheel_leg/winCmd.bat (opens in a new tab)
- 机加版/代码/DM-balance机加工版本/MDK-ARM/CtrlBoard-H7_IMU/CtrlBoard-H7_IMU.hex (opens in a new tab)
Photo and 3D model
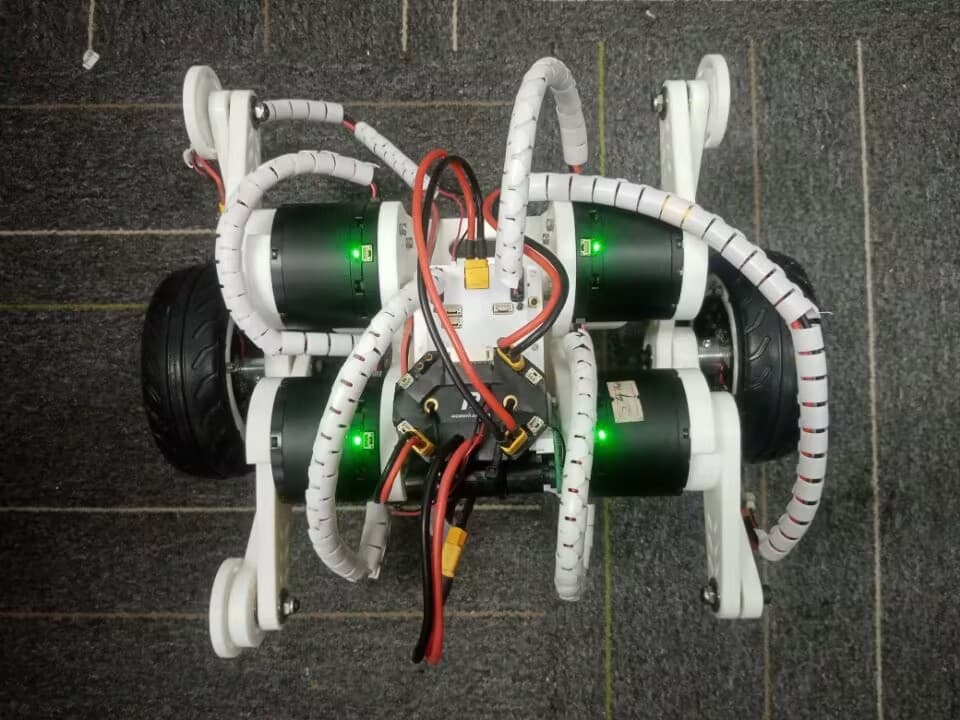
3D preview converted from github.com/Kevin16437/my-roscar-WHEEL-LEGGED at 96bada7, under MIT. View the original files from GitHub (995 KB) (opens in a new tab)
1 of the 14 STEP files is not in the 3D view: 1 too large.
What it can do
Written by Robotheca from the project's documents.
- Moves on four wheel-legs using hybrid wheel and leg motion
- Controlled via DM-MC02 development board
- Supports both 3D-printed and machined mechanical parts
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Kevin16437 (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- DM4310 motors (four units)
- DM60 hub motors (two units)
- DM-MC02 development board
Connections
- DM4310 motors connected to DM-MC02 via motor drivers
- DM60 hub motors connected to DM-MC02 via motor drivers
- Power distribution shown in hardware wiring diagrams for both 3D-printed and machined versions

