OpenFigure
An open-source full-size humanoid robot designed for low-cost manufacturing and customization by enthusiasts.
- Humanoid
- Open source
- Work in progress
- 3D model (URDF)
- 3D printable
Suggested by Robotheca, created by @rexchen80 (opens in a new tab), from github.com/rexchen80/OpenFigure (opens in a new tab). Pinned to commit 0e8671c (opens in a new tab).
- Hardware license
- BSD-3-Clause (opens in a new tab)
- Software license
- BSD-3-Clause (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Photo and 3D model
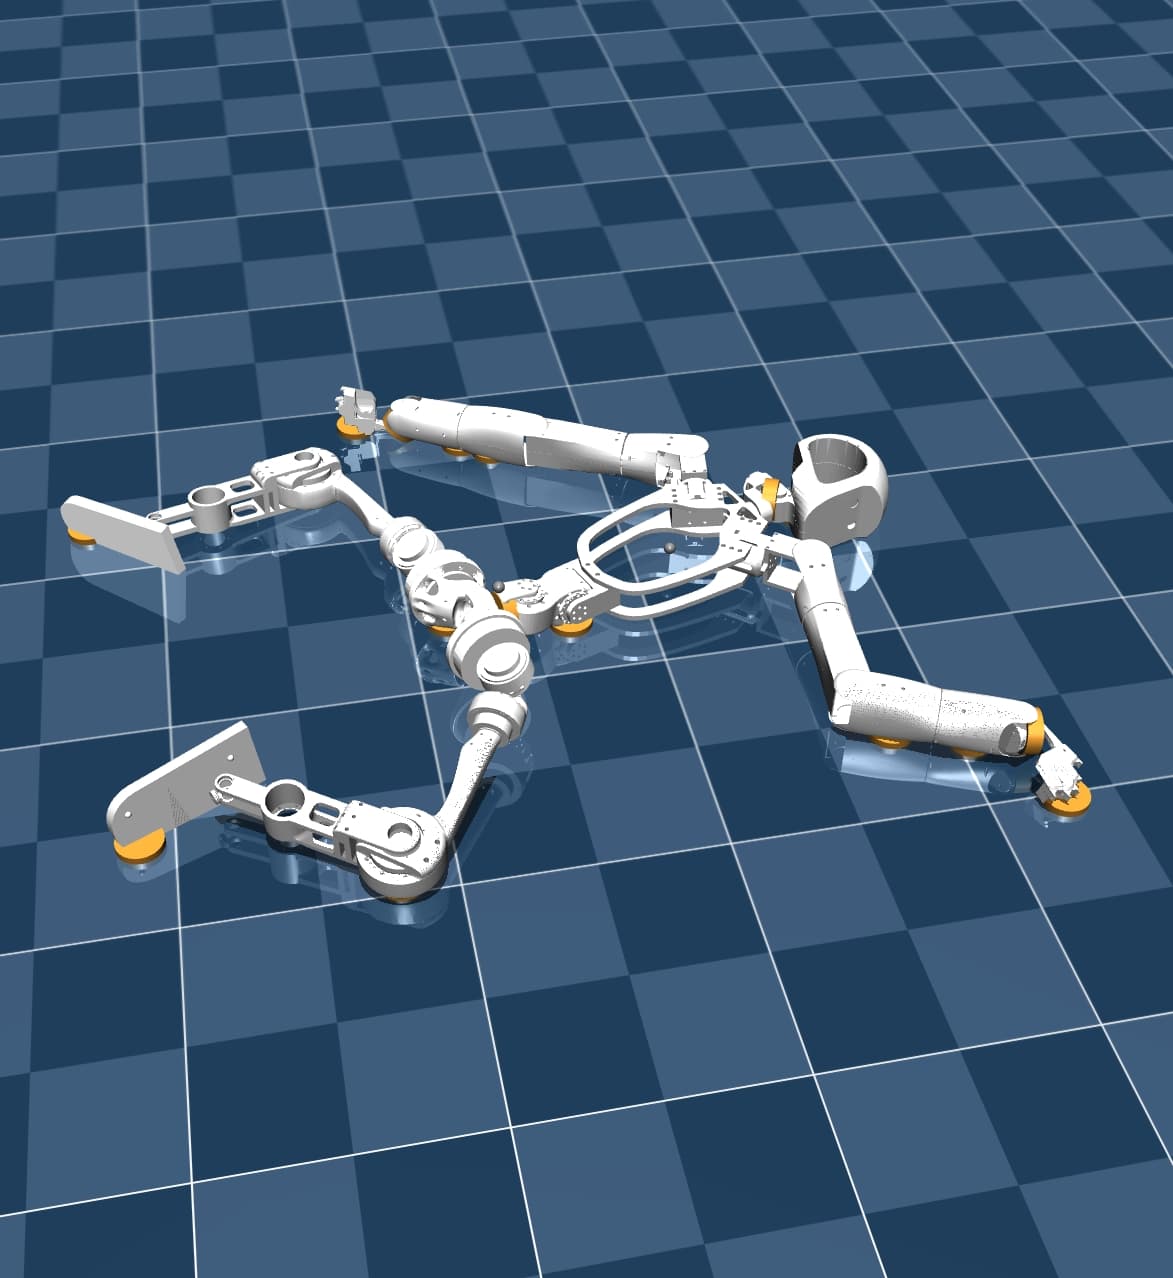
3D preview converted from github.com/rexchen80/OpenFigure at 0e8671c, under BSD-3-Clause. View the original files from GitHub (14.3 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Stands up and moves as a full-size humanoid robot
- Controlled in real time via Meta Quest 3 VR headset
- Supports inverse kinematics for arm and head tracking
- Records and replays motions
- Adjusts gripper opening percentage with trigger
- Calibrates base height and orientation with long press
- Resets target pose with double-tap
- Supports torque adjustment with joystick
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @rexchen80 (README.md), under BSD-3-Clause. The English translation is by Robotheca, shared under the same license.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Raspberry Pi or NVIDIA Jetson as main controller
- Meta Quest 3 VR headset for remote operation
- Servo motors for joints and arms
- Gripper with controllable opening percentage
- UDP network interface for VR data streaming
Connections
- UDP network connection between Meta Quest 3 and main controller over local Wi-Fi or wired LAN
- Servo motors connected to main controller via standard servo interfaces