GEARdrones
A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.
- Drone
- Open source
- 3D printable
Suggested by Robotheca, created by @Excitablecell (opens in a new tab), from github.com/Excitablecell/GEARdrones (opens in a new tab). Pinned to commit 4890019 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 program or installer)
Photo and 3D model
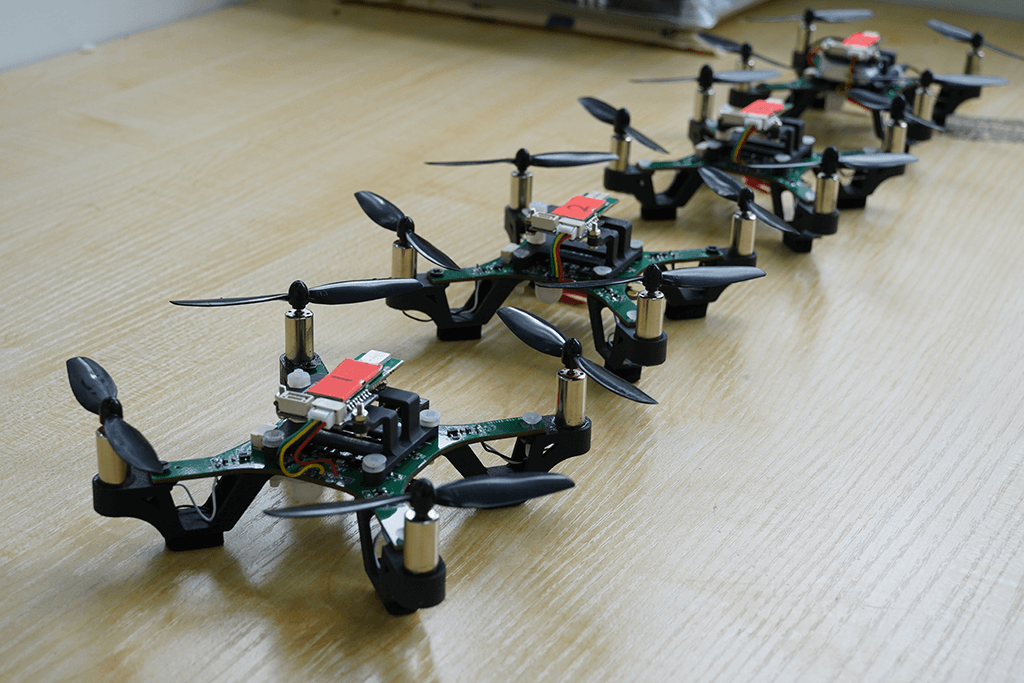
3D preview converted from github.com/Excitablecell/GEARdrones at 4890019, under GPL-3.0-only. View the original files from GitHub (8.9 MB) (opens in a new tab)
What it can do
Written by Robotheca from the project's documents.
- Flying a quadrotor in formation using relative localization
- Performing cooperative relative localization with four UWB base stations
- Hovering using optical flow sensor when UWB base stations are unavailable
- Broadcasting take-off commands to multiple drones via remote controller
- Running embedded flight control software on STM32F1 or STM32F4
- Running UWB-based relative localization algorithm on embedded hardware
- Simulating relative localization algorithms in MATLAB
- Running a PC-based ground control station with Python and PyQt5
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @Excitablecell (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- STM32F103 flight controller
- STM32F411 flight controller
- STM32F1-based remote controller
- UWB modules for relative localization
- Optical flow sensor for hovering
- MQTT server for communication
- PC running Python 3.8 and PyQt5 for ground control station
Connections
- Flight controllers wired to UWB modules via unspecified buses
- Remote controller connected to drones via serial transparent transmission modules
- MQTT server connected to ground control station over network