Project files
- GEARdrone_Lite253 files
- GEARdrone-F41179 files
- GEARremote186 files
- F4_workflow.png525 KB
- GEARremote.jpg27 KB
- README.md2 KB


README.md
Machine-translated by Robotheca from the original in Chinese (opens in a new tab). License: GPL-3.0-only (opens in a new tab).
GEARDRONE_LITE
GEARdrone for STM32F103
The GEARdrone_Lite includes a complete flight controller and onboard UWB relative positioning algorithm, which can achieve relative positioning in 4 base station mode or directly use the optical flow sensor for positioning and hovering.
For specific functions, please refer to the software engineering code.
GEARDRONE_F4
GEARdrone for STM32F411
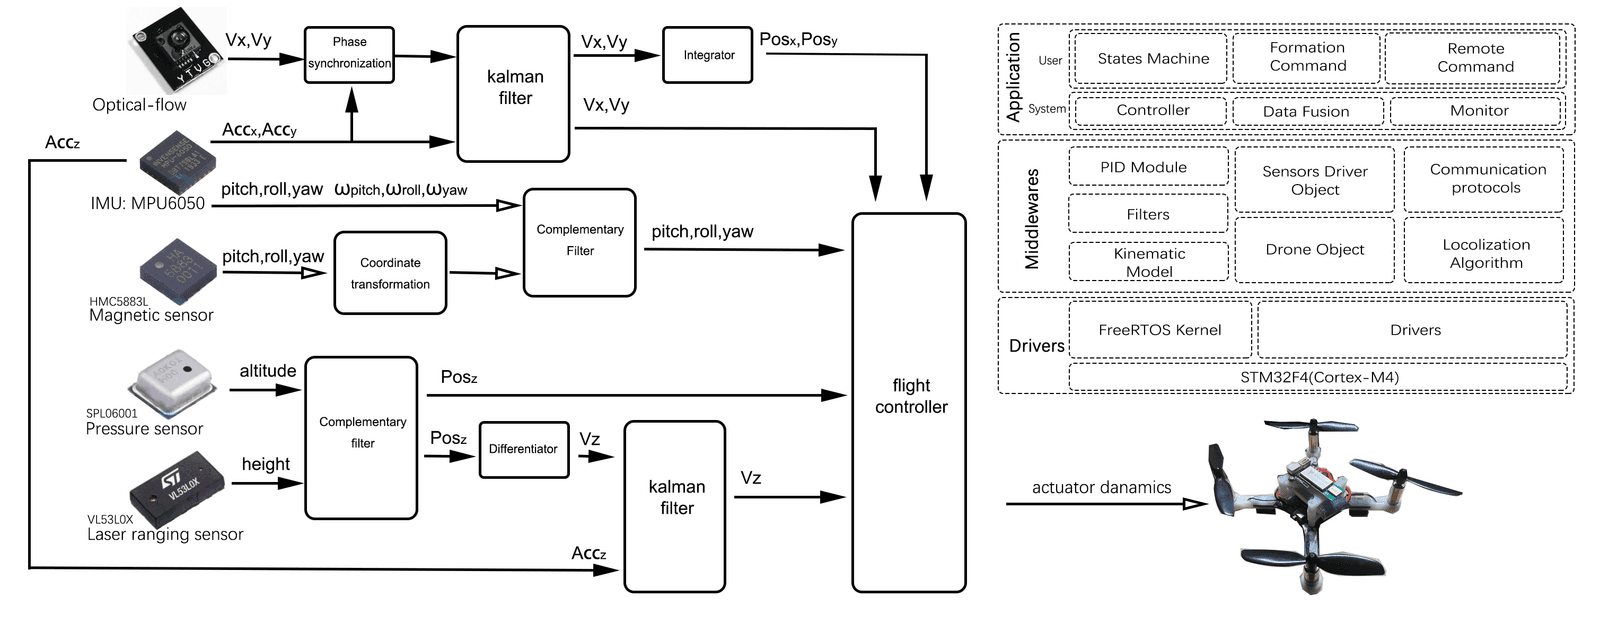
Due to limited personal time, development of the F4 flight controller has been suspended after multiple prototype failures caused by layout issues.
Worth referencing is the NLR_localization file located in the GEARdrone-F4\GearLL\Middlewares\Algorithm directory.
NLR_localization implements nonlinear regression on the microcontroller, replicating the first part of the drone relative position initialization described in reference [1].
The complete paper replication with MATLAB simulation can be found in the software folder.
GEARREMOTE
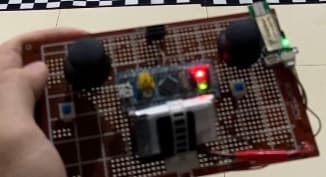
The GEARremote remote control was originally designed to control a single drone using a serial transparent transmission module. However, during later formation development, the remote control abandoned its original design to support drone formation development in a breadboard format, providing broadcast takeoff commands without a dedicated PCB project.
References:
[1] Guo K, Xie L. INFRASTRUCTURE-FREE COOPERATIVE RELATIVE LOCALIZATION FOR UAVS IN GPS-DENIED ENVIRONMENTS[J]. International Journal of Robotics and Automation, 2021, 36(6).
[2] Nguyen T M, Zaini A H, Guo K, et al. An ultra-wideband-based multi-UAV localization system in GPS-denied environments[C]//2016 International Micro Air Vehicles Conference. 2016, 6: 1-15.
[3] Guo K, Qiu Z, Miao C, et al. Ultra-wideband-based localization for quadcopter navigation[J]. Unmanned Systems, 2016, 4(01): 23-34.
[4] Guo K, Li X, Xie L. Ultra-wideband and odometry-based cooperative relative localization with application to multi-UAV formation control[J]. IEEE transactions on cybernetics, 2019, 50(6): 2590-2603.
Files by @Excitablecell, at commit 4890019, read from GitHub in your browser. Hardware license: GPL-3.0-only; software license: GPL-3.0-only. Robotheca doesn't review code: read it before running it.