12-DOF Quadruped Robot
A 12-DOF quadruped robot driven by servos, featuring open-loop gait control and IMU stabilization.
- Quadruped
- Open source
- 3D printable
Suggested by Robotheca, created by @lshil00 (opens in a new tab), from github.com/lshil00/Quadruped_robot (opens in a new tab). Pinned to commit 645aca7 (opens in a new tab).
- Hardware license
- Apache-2.0 (opens in a new tab)
- Software license
- Apache-2.0 (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (1 program or installer, 2 firmware images)
Photo and 3D model
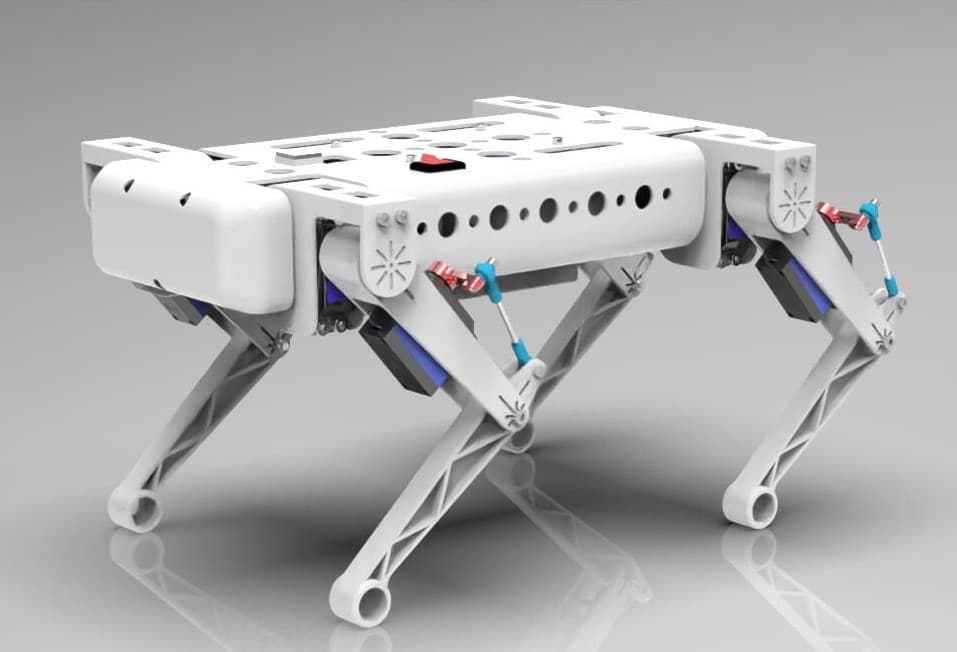
3D preview converted from github.com/lshil00/Quadruped_robot at 645aca7, under Apache-2.0. View the original files from GitHub (22.9 MB) (opens in a new tab)
- Degrees of freedom
- 12
- Height
- 180 mm
- Weight
- 2 kg
What it can do
Written by Robotheca from the project's documents.
- Walks using open-loop inverse kinematics gaits
- Stands upright on four legs
- Moves forward, backward, left, right, and rotates in place
- Performs body twisting and tilting motions
- Avoids obstacles with ultrasonic sensor
- Self-stabilizes using IMU
- Communicates via Bluetooth for remote control
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Structural Design and 3D Printing
- 2Hardware Assembly
- 3Software Development and Testing
The guide appears here as you scroll.
Guide by @lshil00 (README.md), under Apache-2.0. The English translation is by Robotheca, shared under the same license.
More guides
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- STM32F103 microcontroller
- 12 servo motors (SPT5425 version)
- HC-05 Bluetooth module
- HC-SR04 ultrasonic sensor
- 3300 mAh lithium battery
- UBEC voltage regulator for servos
- LM2596 buck converter for microcontroller
Connections
- Servos powered by UBEC module from battery
- STM32F103 powered by LM2596 buck converter from battery
- IMU connected to STM32F103 via I2C
- Bluetooth module connected to STM32F103 via UART
- Ultrasonic sensor connected to STM32F103 via GPIO