Hexapod Robot
A six-legged walking robot with inverse kinematics control and a PC-based interface for movement and posture adjustments.
- Quadruped
- Open source
- 3D printable
Suggested by Robotheca, created by @AlexanderJFDR (opens in a new tab), from github.com/AlexanderJFDR/hexapod_robot (opens in a new tab). Pinned to commit 33877a3 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
This repository contains executable files that Robotheca doesn't check. Only run them if you trust the creator.
Which files (148 programs or installers, 1 firmware image)
- 硬件系统/YH-24路舵机控制板学习资料/03.外接控制板例程/stm32例程/FlyMcu.exe (opens in a new tab)
- 硬件系统/YH-24路舵机控制板学习资料/03.外接控制板例程/stm32例程/OUT/32_duoji.hex (opens in a new tab)
- 硬件系统/YH-24路舵机控制板学习资料/04.相关工具/1.上位机软件/Yeahbot V1.13.exe (opens in a new tab)
- 软件控制/打包程序/build/run/run.exe (opens in a new tab)
- 软件控制/打包程序/build/run/run.pkg (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-console-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-datetime-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-debug-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-errorhandling-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-file-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-file-l1-2-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-file-l2-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-handle-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-heap-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-interlocked-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-libraryloader-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-localization-l1-2-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-memory-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-namedpipe-l1-1-0.dll (opens in a new tab)
- 软件控制/打包程序/dist/_internal/api-ms-win-core-processenvironment-l1-1-0.dll (opens in a new tab)
- and 129 more
Photo
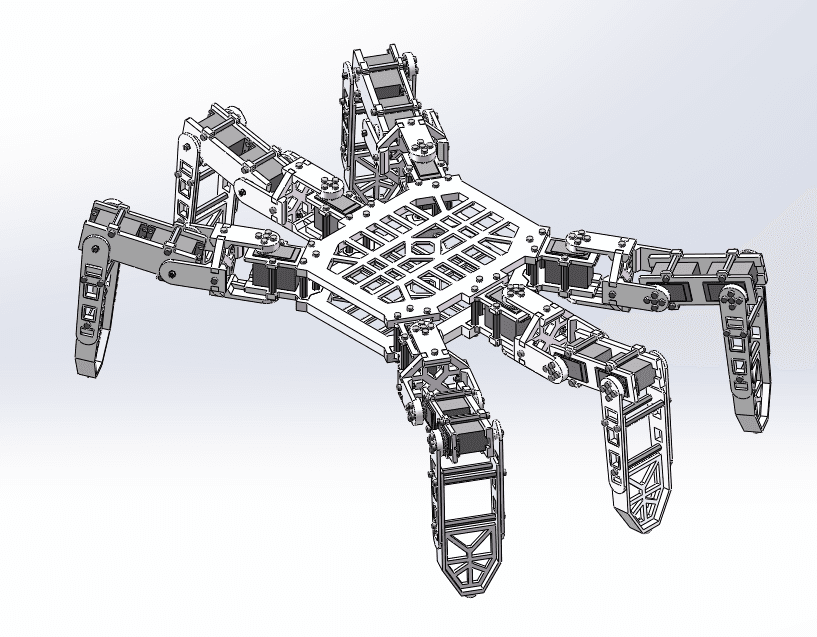
What it can do
Written by Robotheca from the project's documents.
- Moves with six legs each driven by three MG996R servos
- Walks forward, backward, and turns using triangle or ripple gaits
- Changes posture when stationary via keyboard or input fields
- Allows custom control of each servo angle in real time
- Supports serial and Bluetooth communication with the servo controller
- Runs a graphical user interface for control and configuration
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Mechanical Design and 3D Printing
- 2Hardware Assembly
- 3Software Development and Testing
The guide appears here as you scroll.
Guide by @AlexanderJFDR (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Yeahbot 24-channel servo controller board
- ATK-USB-UART-V1.2 USB-to-serial converter module
- 18650 12 V 5600 mAh lithium battery pack
- LM2596S DC-DC adjustable buck converter module for 5 V supply
Connections
- Servo controller board receives power from the LM2596S 5 V output
- Servo controller board connects to ATK-USB-UART-V1.2 for USB-to-serial communication
- MG996R servos are wired to the 24-channel servo controller board