H1 6-Axis 3D-Printed Manipulator
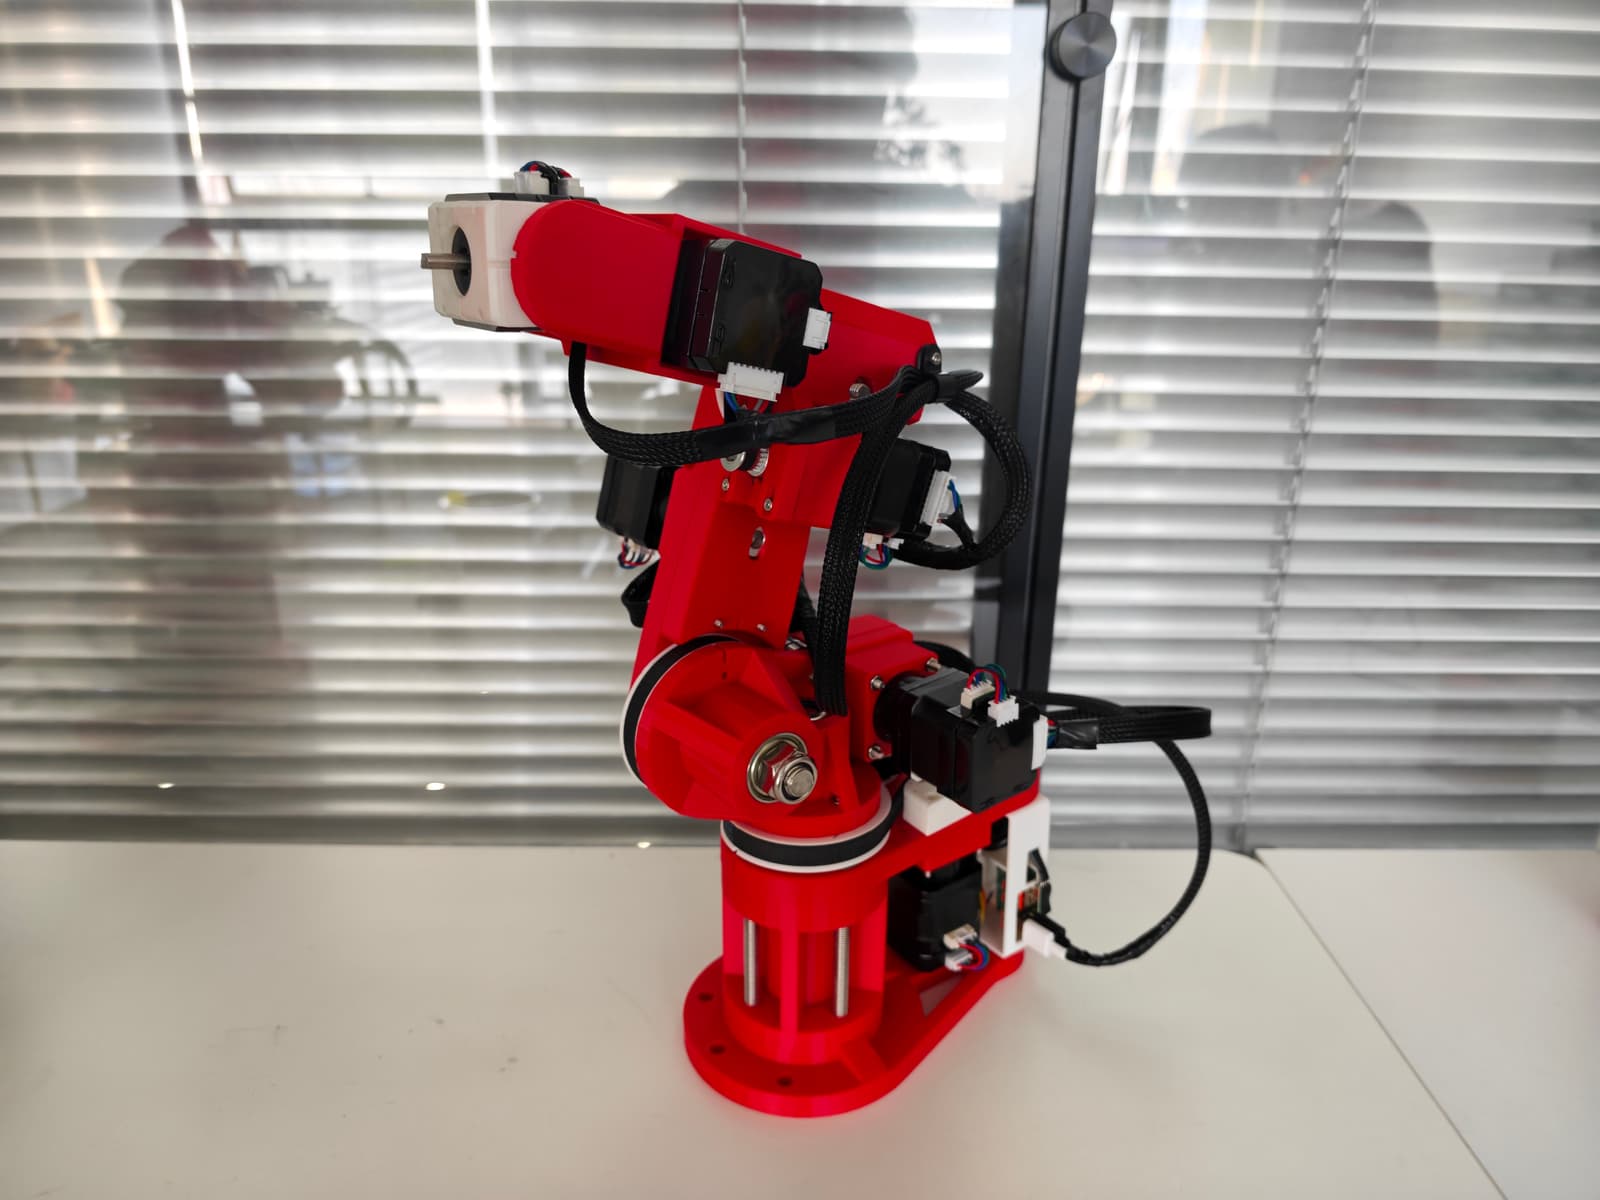
A 6-axis 3D-printed robotic arm capable of understanding human commands and performing tasks.
- Robot arm
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @xaio6 (opens in a new tab), from github.com/xaio6/6-axis-manipulator (opens in a new tab). Pinned to commit d3b5670 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo
- Degrees of freedom
- 6
What it can do
Written by Robotheca from the project's documents.
- Moves six joints with servos for arm manipulation
- Controlled via Arduino firmware
- Performs basic pick-and-place tasks
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The creator's steps, each with its instructions.
- 1Read the assembly guide
- 23D print all parts
- 3Assemble the mechanical structure
- 4Upload the firmware
- 5Test and calibrate
The guide appears here as you scroll.
Guide by @xaio6 (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino controller board
- Six servo motors for the six axes
- Power supply for servos and Arduino
Connections
- Servos connected to Arduino PWM pins
- Common power bus for servos and Arduino