Skip to content

Explore robots

Open-source robots with their licenses, parts and source files. Every page is pinned to a commit on GitHub.

Filters

Type
Level
Buildability

Ready to build: a score of 80 or more, a license and a finished design.

Options
Labels
Origin

Where the project was published, known for 29 of 270 robots. Never guessed.

Guide translated from

Guides machine-translated into English by Robotheca, with a link to the original on each robot page.

37 of 270 robots state a cost. Costs in other currencies are compared using the ECB reference rate of 14 Oct 2026. Robots without a known cost are hidden unless you include them.

Clear filters

120 robots of 270

Page 5 of 5 · Ready to build first, then by buildability

  • Quadruped

    Mini Pupper

    An open-source, ROS-based quadruped robot dog designed for education and research, supporting SLAM, navigation, and OpenCV AI features.

    • Works with AI
    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    $500≈ €447 (ECB rate, 14 Oct 2026)
  • Robot arm

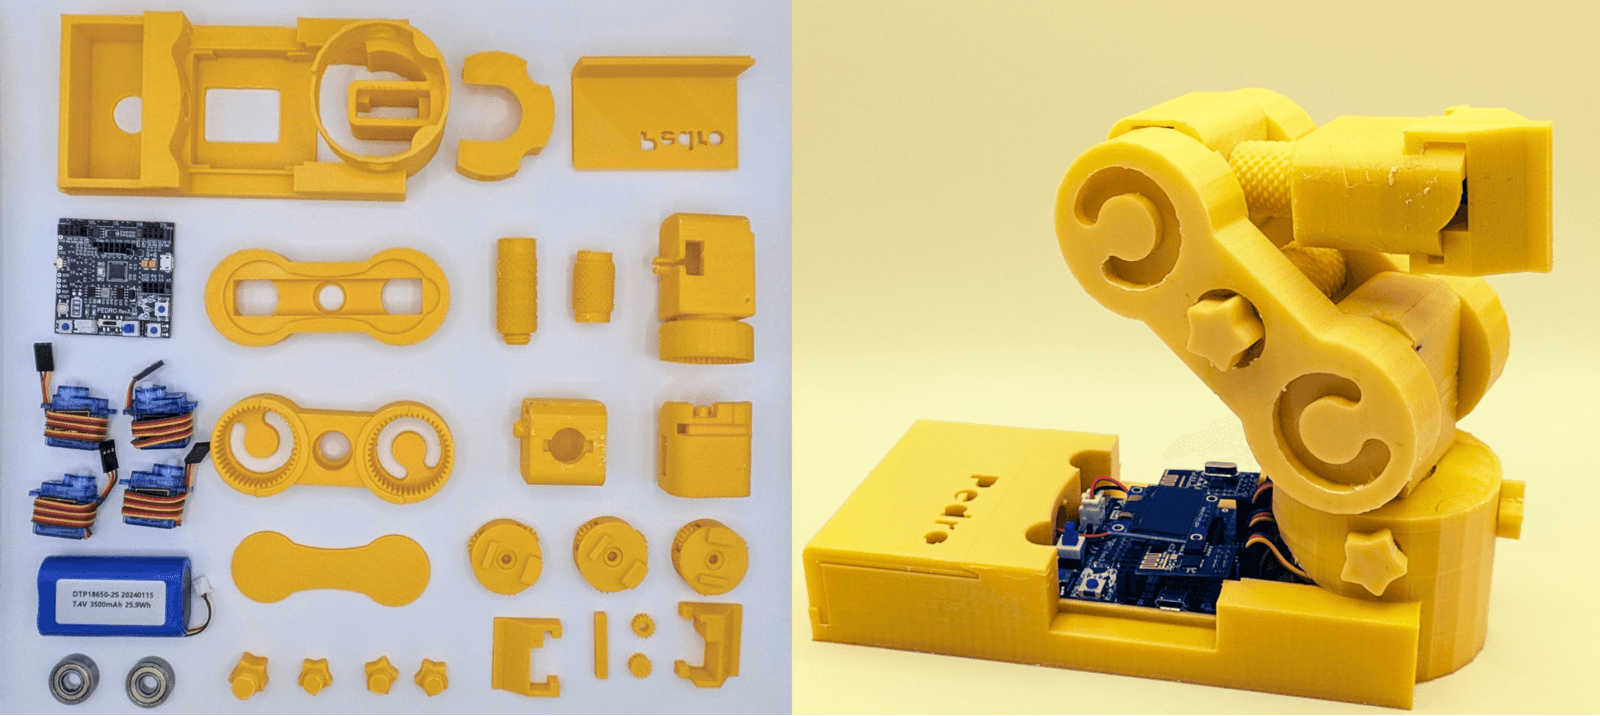
    Pedro

    Pedro is an open-source STEM robot whose 3D-printable parts (arm, gear, servo holder and base) are provided as STL files.

    Level
    Beginner
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

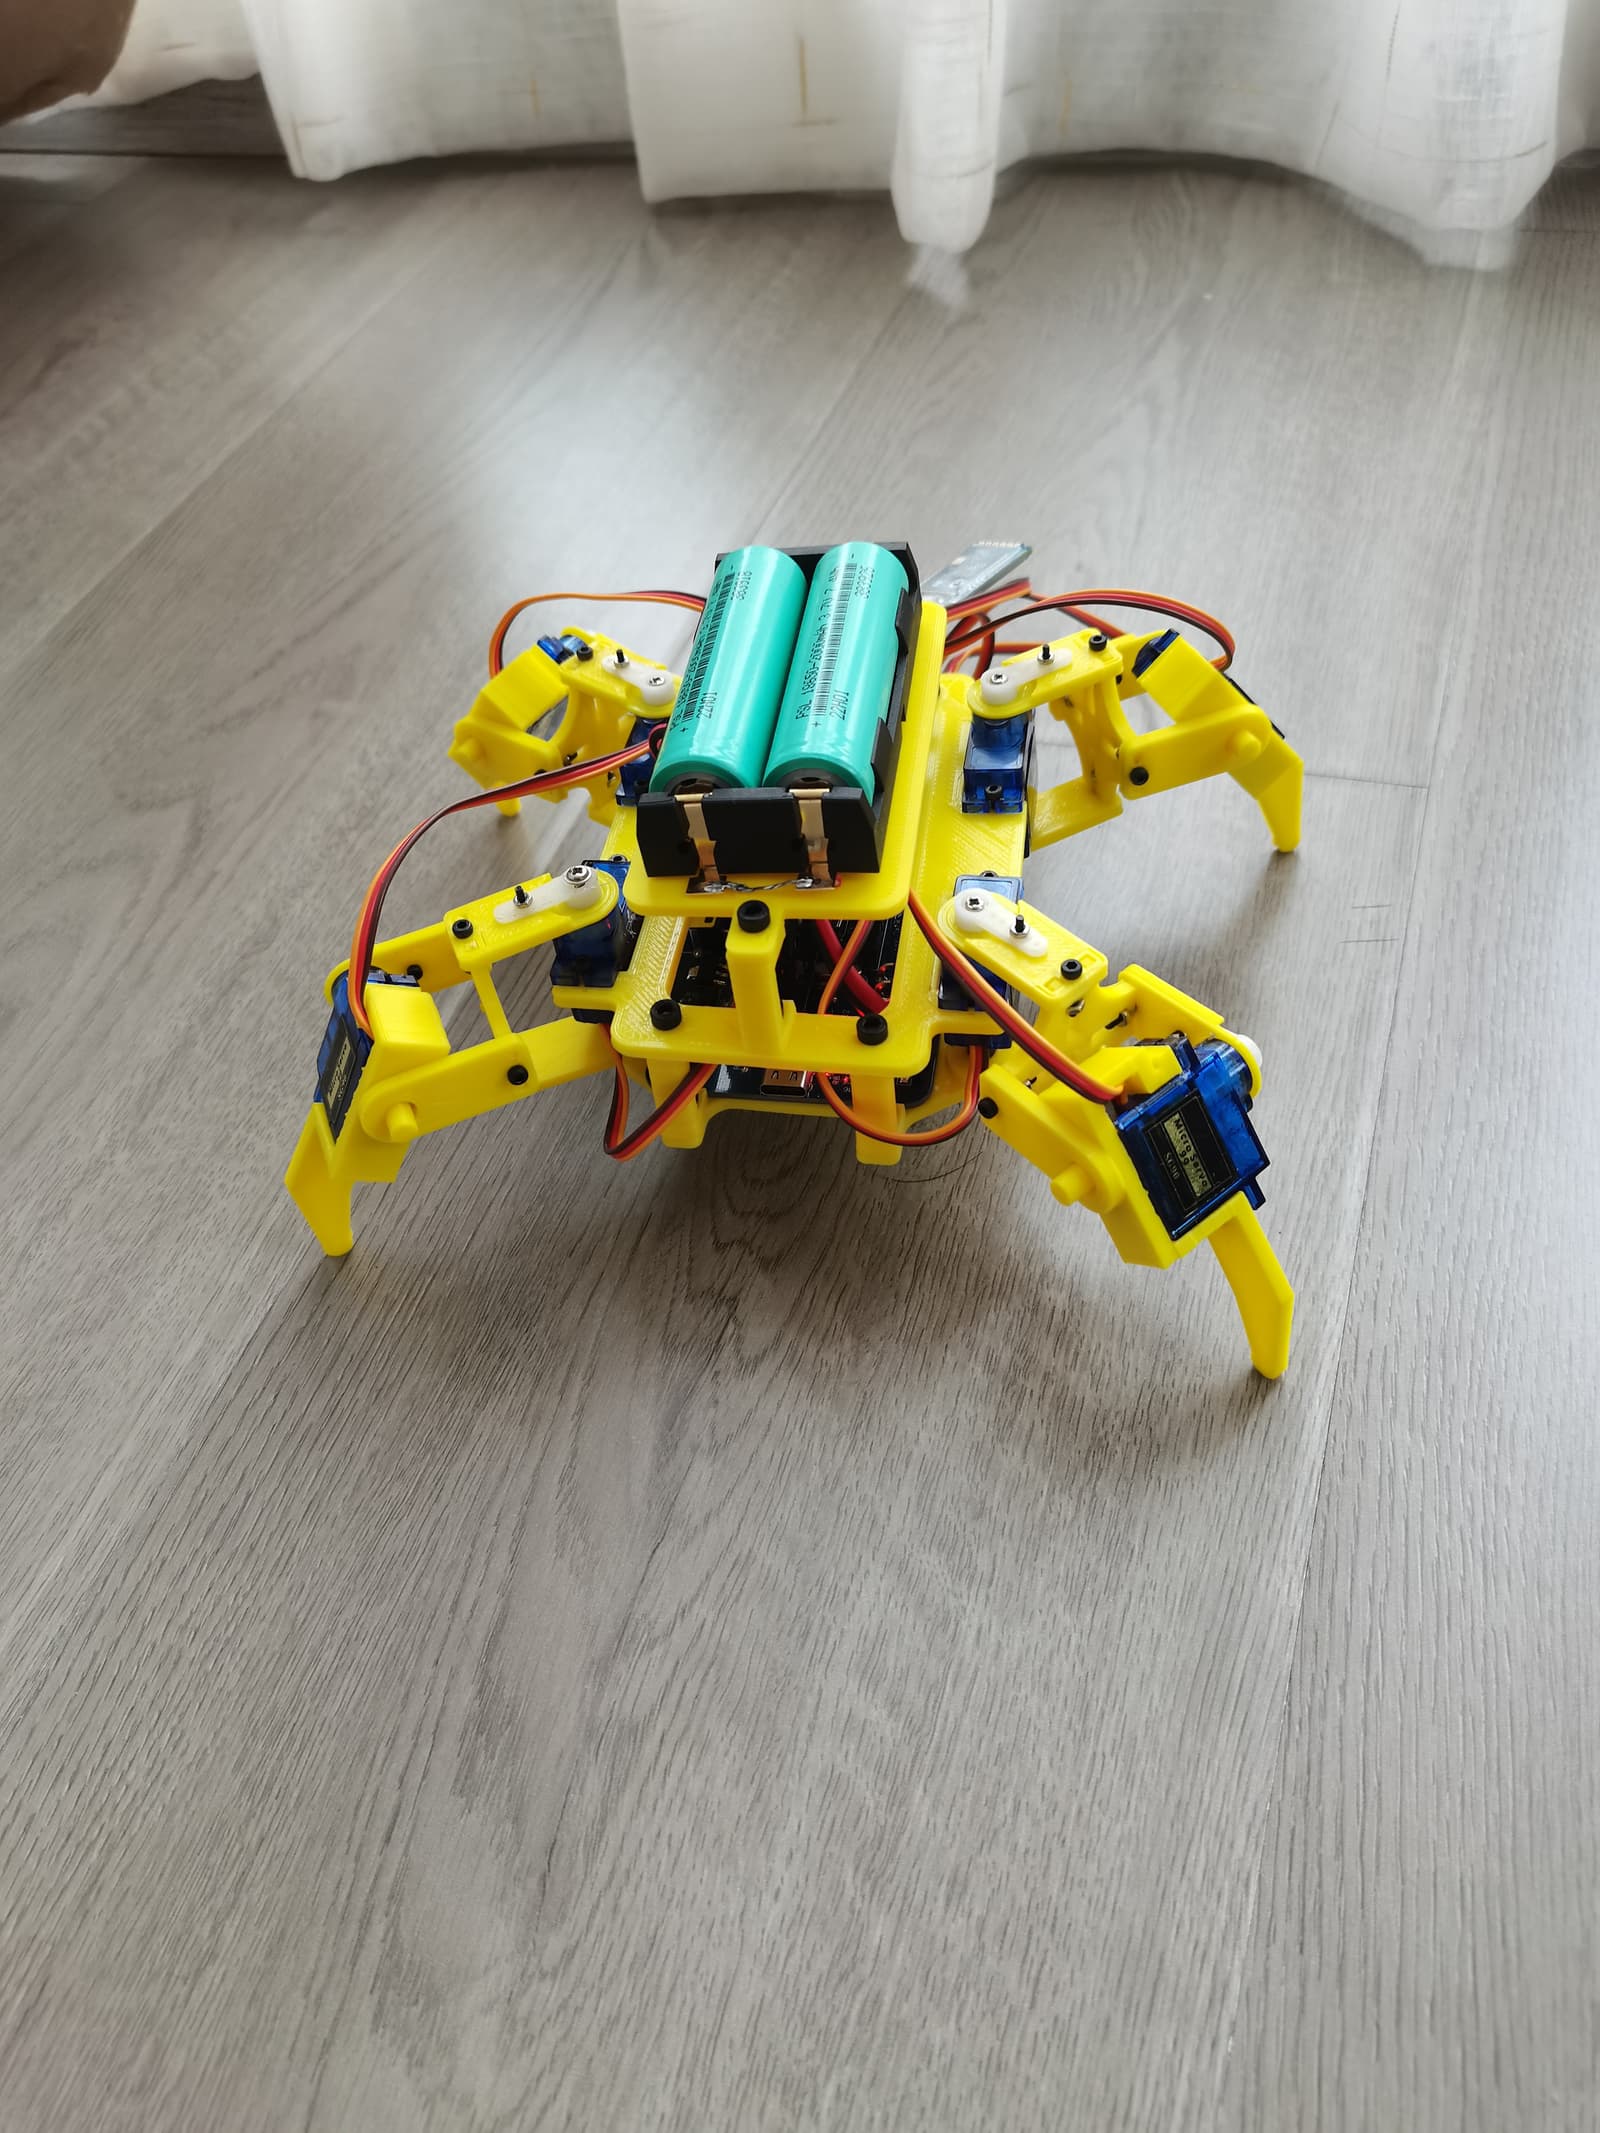
    Quadruped Robot

    A four-legged robot designed for research and education in legged locomotion.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

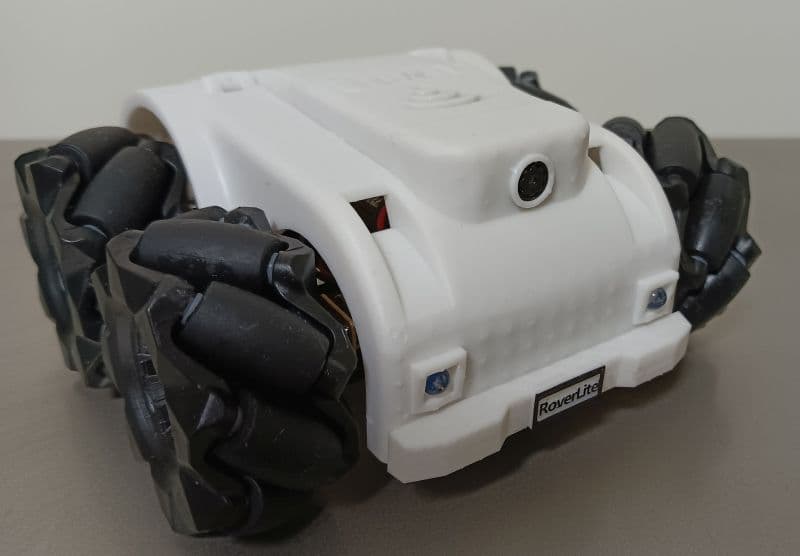
    RoverLite32

    A mini Mecanum-wheel rover driven by an ESP32-Pico-D4 development board with OV2640 camera, dual DRV8833 motor drivers, Type-C interface, and PSRAM.

    Level
    Intermediate
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

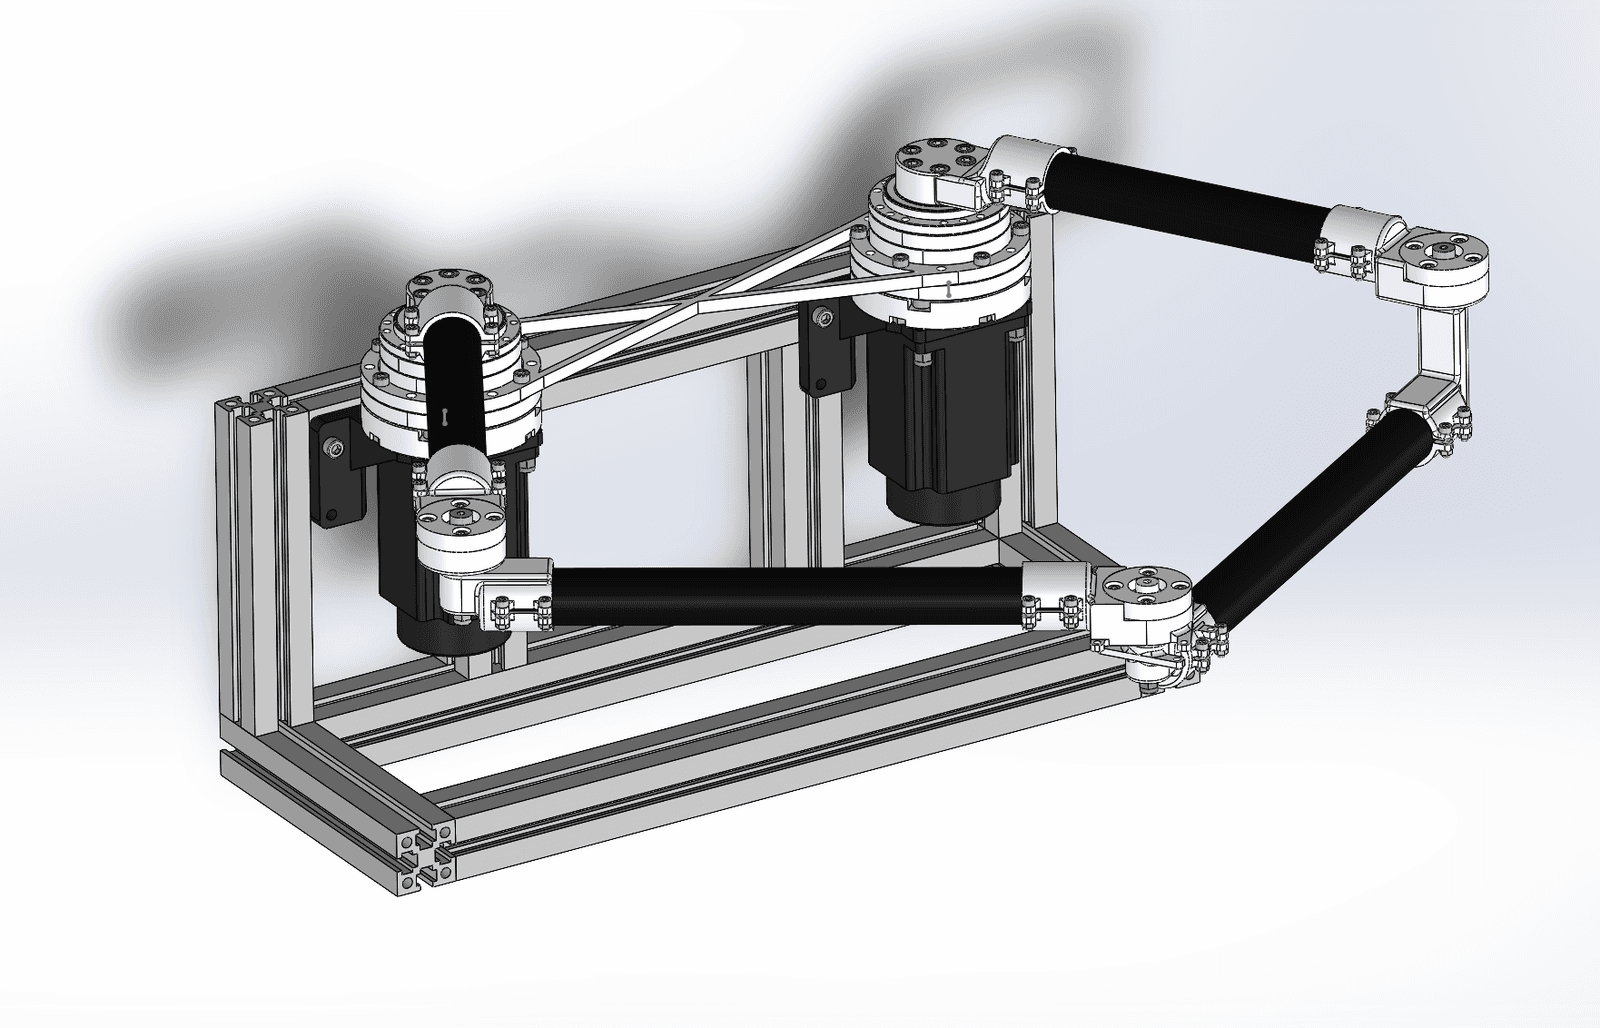
    SCARA Parallel

    A parallel SCARA robotic arm designed for graduation project, featuring closed-loop stepper motors, harmonic reducers, carbon fiber rods, 3D-printed joints, and motion control with linear interpolatio

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Other

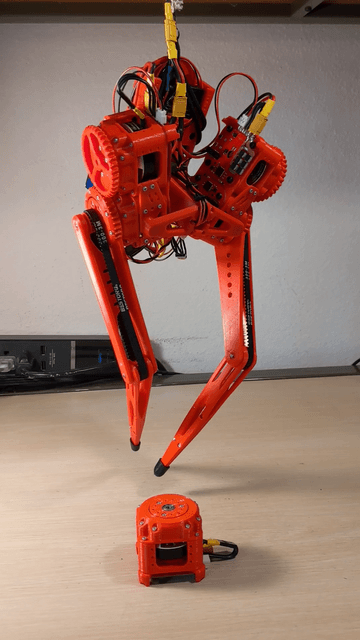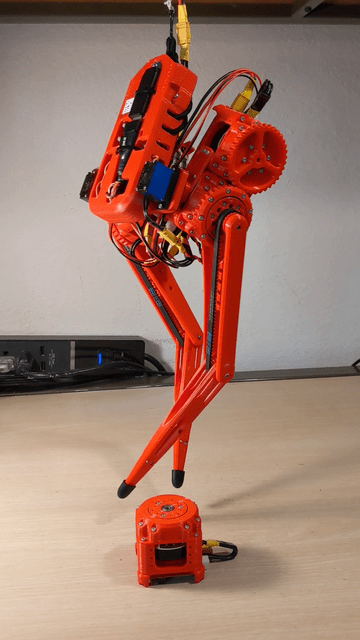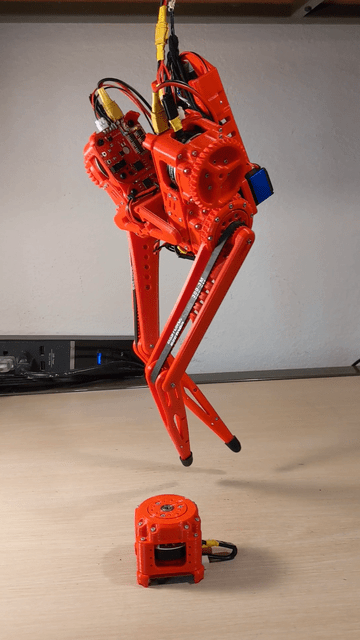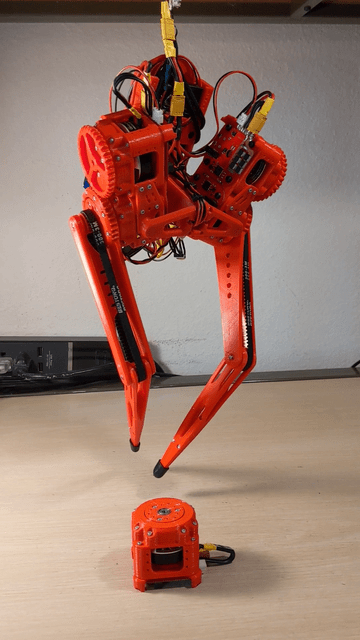
    TipTap

    A 3D-printed bipedal robot built as a low-cost desktop platform for semi-direct drive walking research.

    Level
    Advanced
    Buildability
    40/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

    Easy Quadruped Robot

    A simple quadruped robot controlled by Arduino and optionally ESP32-CAM for vision.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Humanoid

    electronBot

    A desktop-sized open-source robot with 6 degrees of freedom, enhanced with AI capabilities via ESP32, designed for education and maker projects.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    ESP-Drone

    An open-source mini drone/quadcopter firmware for ESP32 and ESP32-S series SoCs, controllable via Wi-Fi or gamepad.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    GEARdrones

    A lightweight drone control and multi-agent localization system combining flight controller, UWB relative localization algorithm, and software monitor.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Humanoid

    Gretchen

    Gretchen is an open-source humanoid robot development platform.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Mars Rover 2020

    A reproduction of the Mars 2020 Perseverance rover, a mars rover replica built as an open-source project.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Quadruped

    Py-Apple Dog

    An open-source quadruped robot designed for easy DIY with low-cost hardware and software.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    RR1: Real Robot One

    A DIY 3D-printable 6-axis desktop robotic arm with closed-loop encoders on each joint, driven by Nema 23 and Nema 17 stepper motors and custom planetary gearboxes.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    Tiny-Drone

    An open-source micro drone based on ESP32-S3, controllable via smartphone app, browser, or remote controller with Wi-Fi video transmission and RID broadcasting.

    • Work in progress
    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Wheel-legged Robot

    A six-legged wheel-legged robot with four joint motors and two hub motors, controlled by a DJI RoboMaster C-type development board.

    Level
    Intermediate
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Other

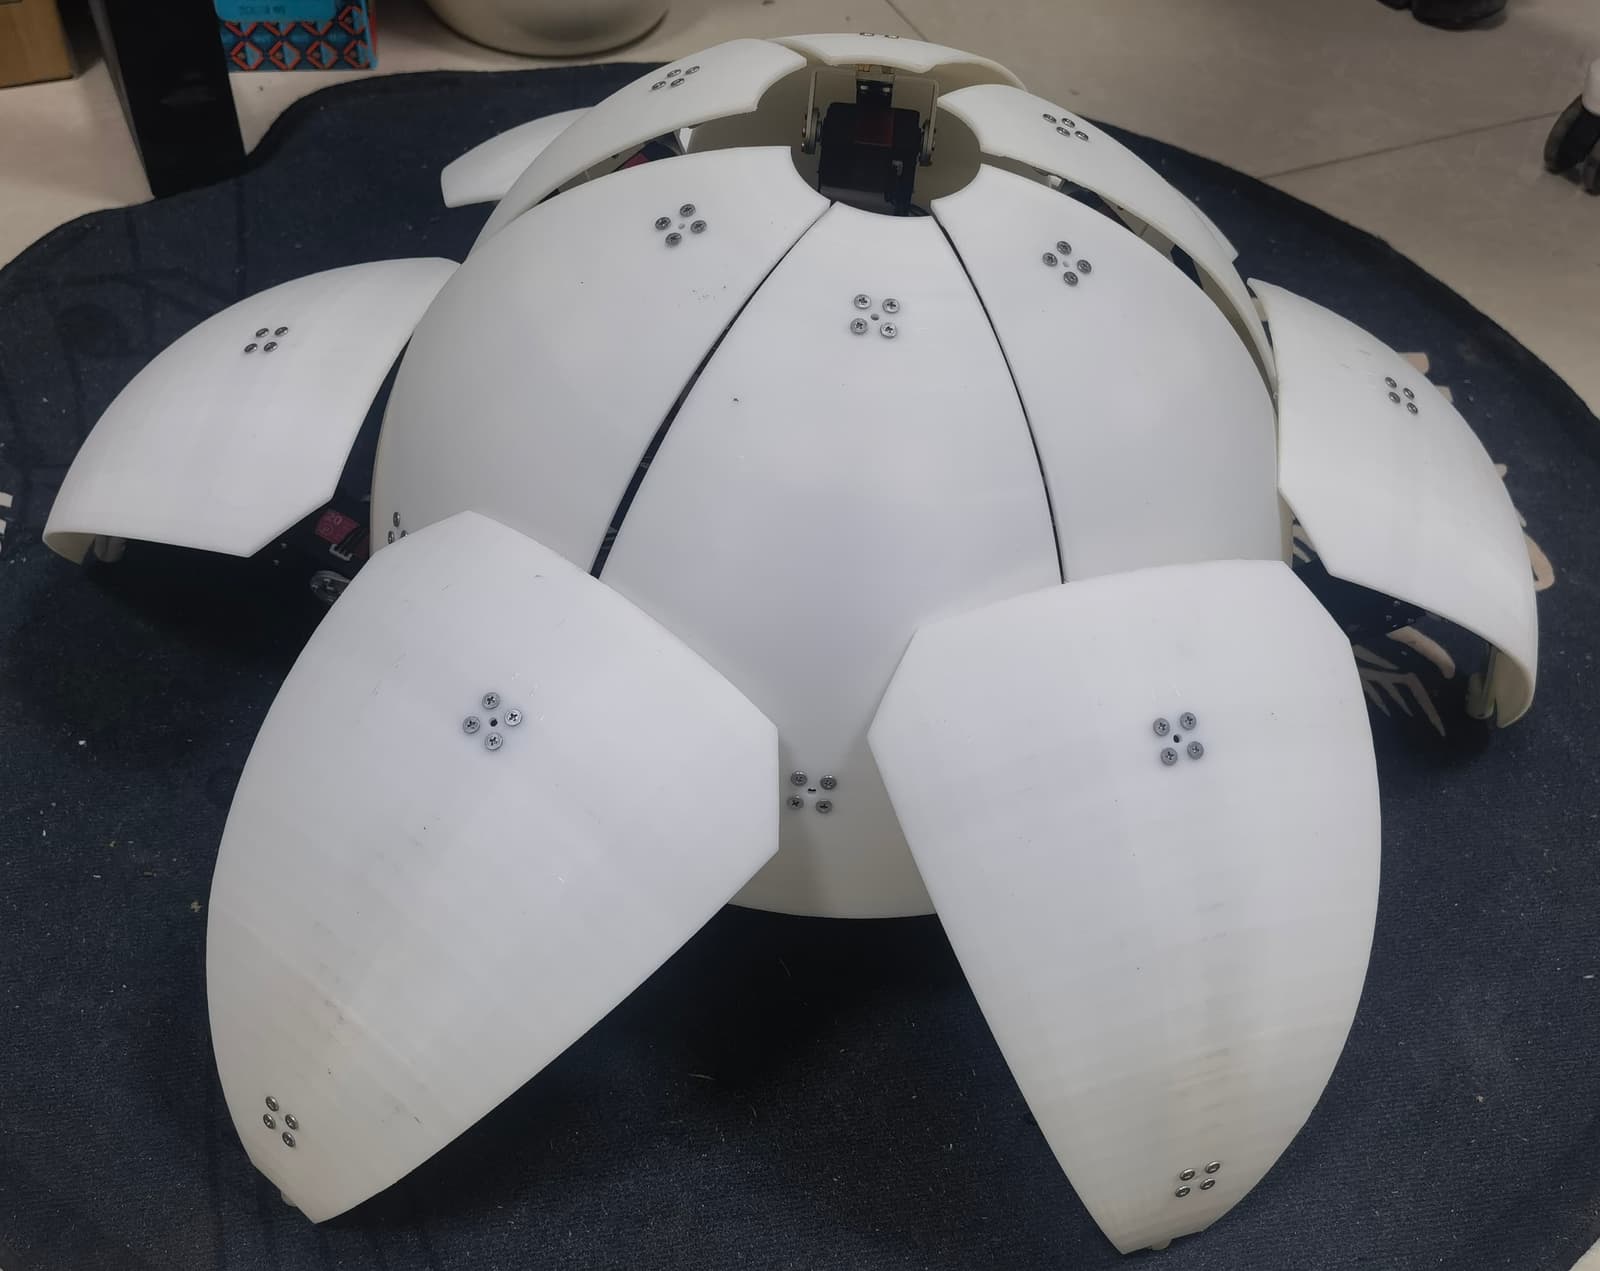
    ZGPS-01

    A transformable robot that switches between a spherical rolling mode and a hexapod walking mode.

    Level
    Advanced
    Buildability
    35/100
    Incomplete documentation
    Cost
    Not stated
  • Drone

    Avem

    A lightweight drone flight controller using STM32, PID control, and BLDC motors.

    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Combat Robot

    A 3.5 kg wheeled combat robot with STM32 and Raspberry Pi, designed for robot fighting competitions.

    • Competition robot
    Level
    Intermediate
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Wheeled

    Wheel-legged

    A wheel-legged robot using four DM4310 motors, two DM60 hub motors, and a DM-MC02 development board, with 3D-printed or machined structural parts.

    Level
    Advanced
    Buildability
    30/100
    Incomplete documentation
    Cost
    Not stated
  • Humanoid

    Otto DIY Humanoid Robot

    An open-source humanoid robot designed for learning and AI integration, featuring assembly guides and firmware documentation.

    • Works with AI
    Level
    Intermediate
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • Other

    Stepping Balancer

    A two-wheeled inverted pendulum robot controlled by a Nucleo board and driven by stepper motors.

    Level
    Advanced
    Buildability
    25/100
    Incomplete documentation
    Cost
    Not stated
  • Robot arm

    OmniT-Hand

    A minimalist underactuated robotic hand with one motor per finger, achieving adaptive grasping for humanoid robots.

    Level
    Intermediate
    Buildability
    15/100
    Incomplete documentation
    Cost
    ¥1,230≈ €164 (ECB rate, 14 Oct 2026)
  • Drone

    TABV-Platform

    A customized terrestrial-aerial bimodal vehicle platform for autonomous navigation on land and in the air.

    Level
    Advanced
    Buildability
    15/100
    Incomplete documentation
    Cost
    Not stated

Robots 97–120 of 120

More to explore