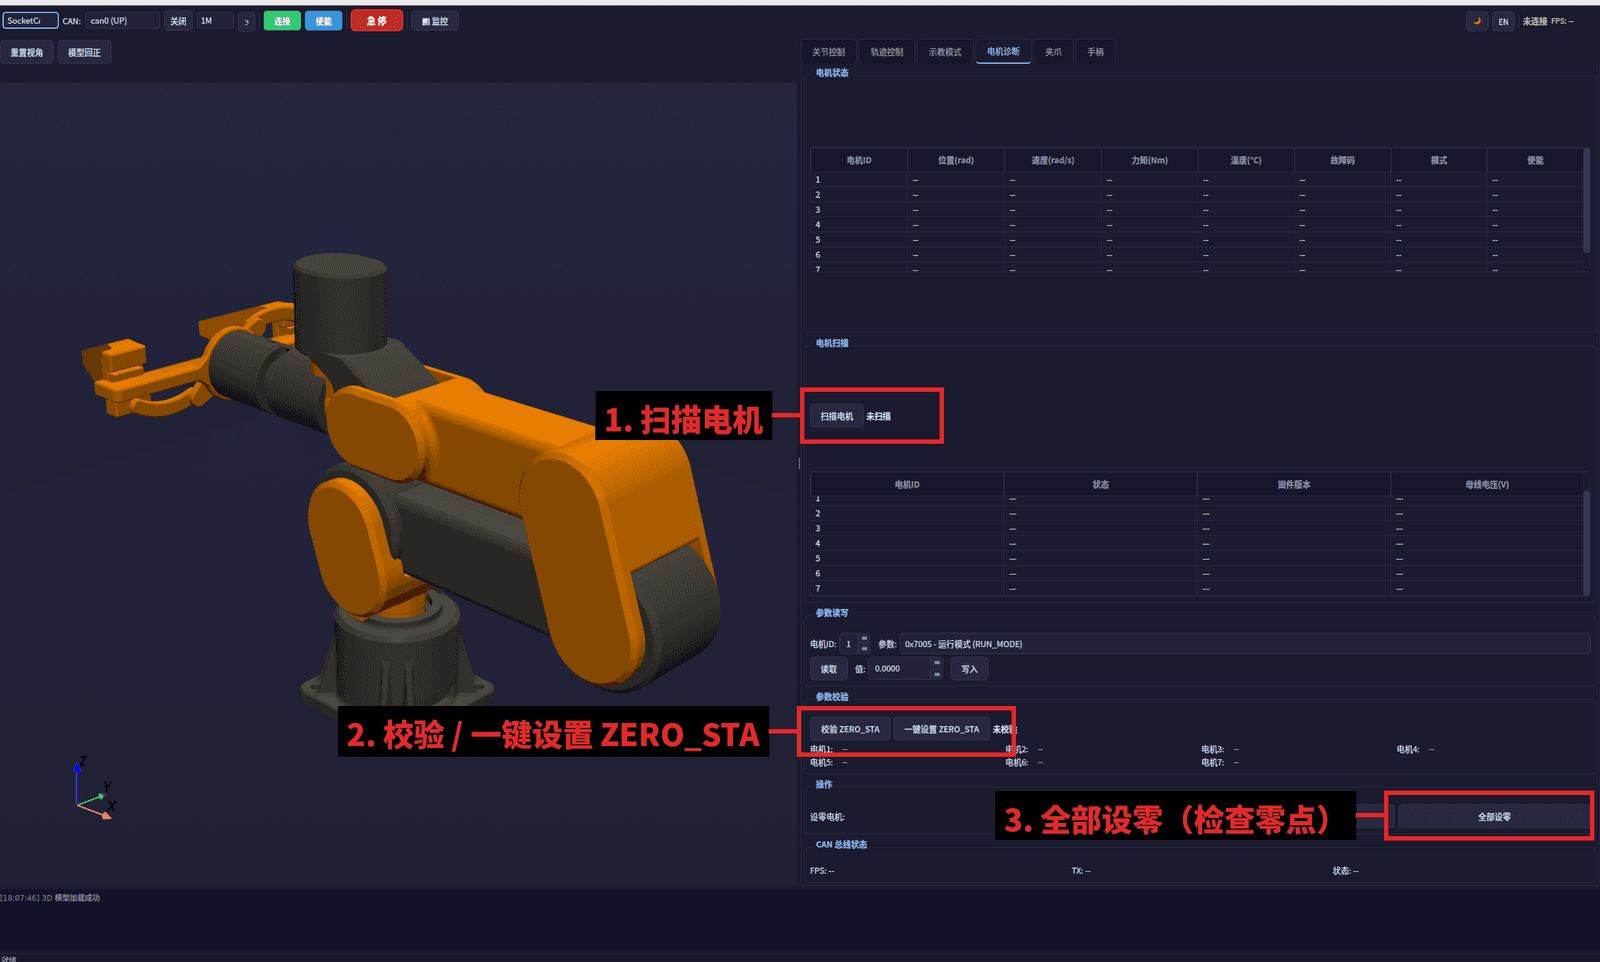
EL-A3
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.
Robot armAdvancedBuildability 75/100 · Buildable with some effort
Cost not stated
Robots whose guide was written in Chinese, machine-translated into English by Robotheca, with a link to the original in Chinese on each robot page. 68 robots on Robotheca, each with its licenses and its source on GitHub.
Page 1 of 3 · Ready to build first, then by buildability
A 7-DOF desktop robotic arm with a Python SDK and ROS2 control system for research and education.

An open-source hexapod robot platform based on ROS2, featuring real-time gait control and laser navigation.
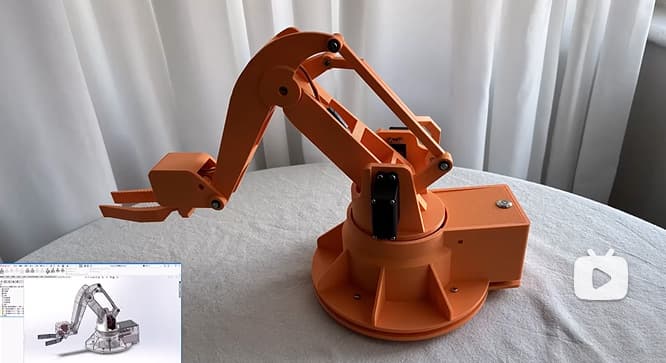
An open-source robotic arm controlled by an ESP32-C3 via a PCA9685 servo driver and an Xbox-compatible gamepad.
A lightweight home robot with modular architecture, supporting remote control, voice interaction, and human following.
A low-cost six-axis robotic arm using DAMIAO motors and sheet metal structural parts, designed for students and hobbyists.
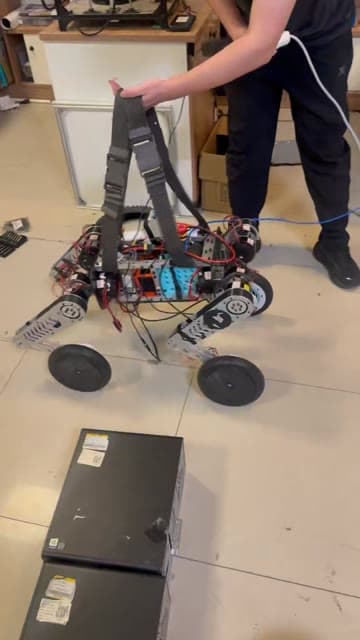
A 16-degree-of-freedom wheeled-legged robot designed for Robocon obstacle courses, combining reinforcement learning, MuJoCo simulation, and real-world deployment.

A 7-DOF personal robotic arm with ROS-based simulation and control.
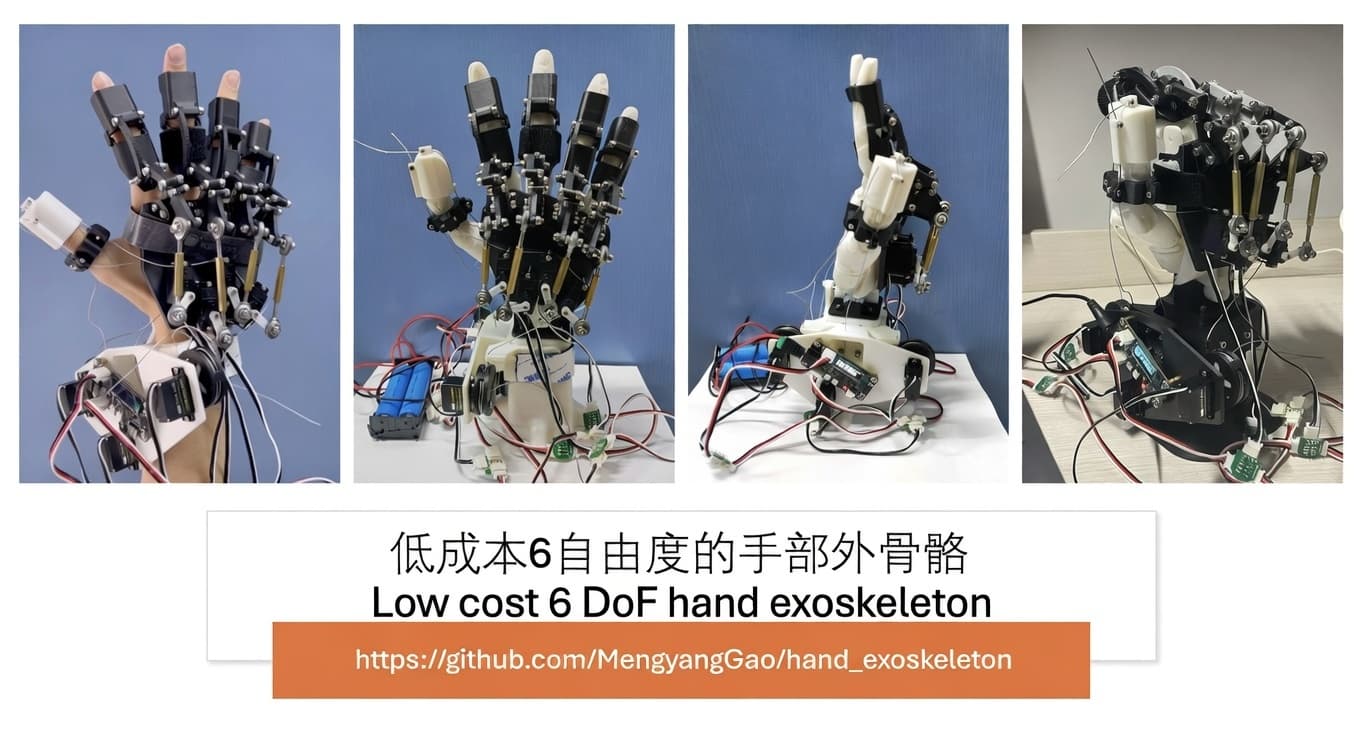
A low-cost 6DoF hand exoskeleton using linkage and tendon mechanisms, controlled by an ESP32 and seven SC09 bus servos.
A self-balancing robot car driven by two BLDC motors using the SimpleFOC library and ESP32 microcontroller.
A four-bar linkage wheel-leg robot designed for a full-stack robotics development challenge using ROS 2, CAD, and embedded systems.
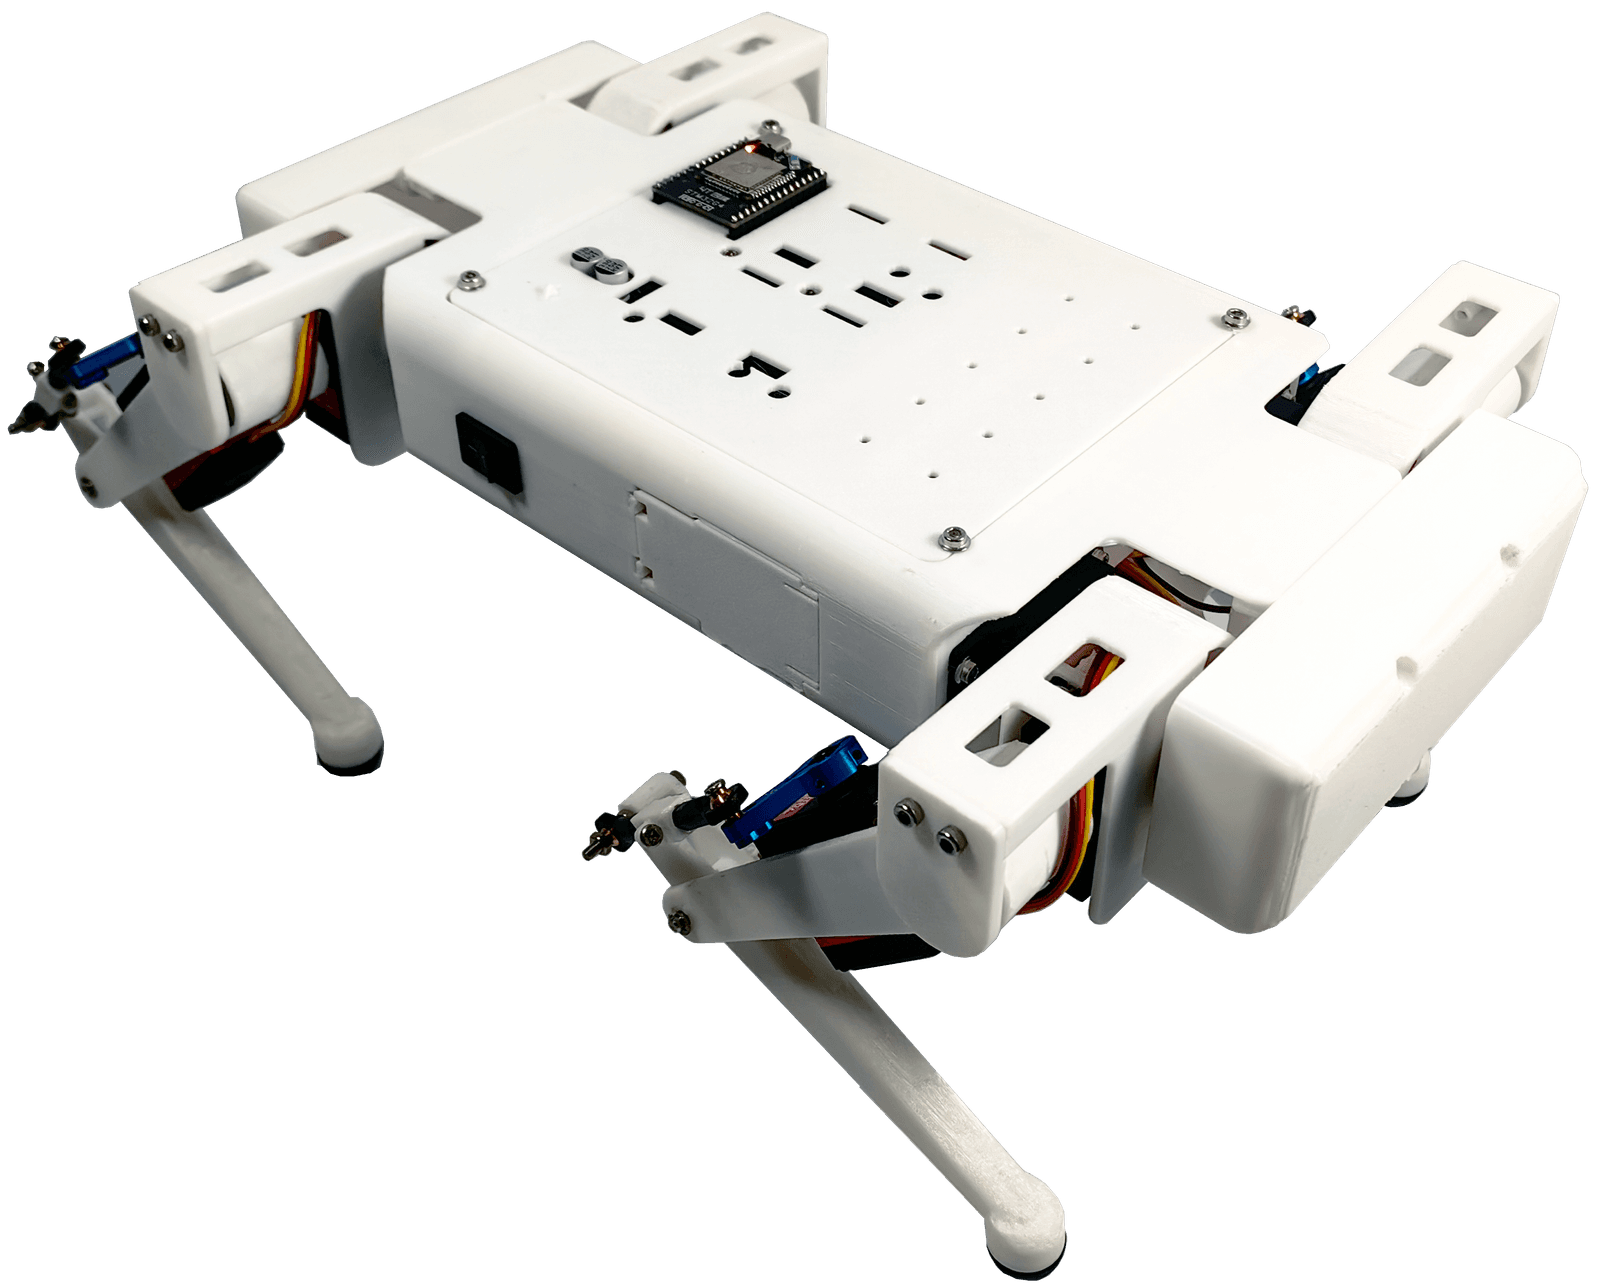
An open-source 12-degree-of-freedom quadruped robot designed for learning, development, and secondary innovation.
A spherical robot that balances and maneuvers in three degrees of freedom using three orthogonal flywheels and a omnidirectional wheel base.
A robotic arm that can be controlled via Python, with servo control, image transmission, and integration with Unity for 3D visualization.
An autonomous self-balancing bicycle robot designed for outdoor track racing, featuring lane detection, obstacle recognition, and balance control algorithms.
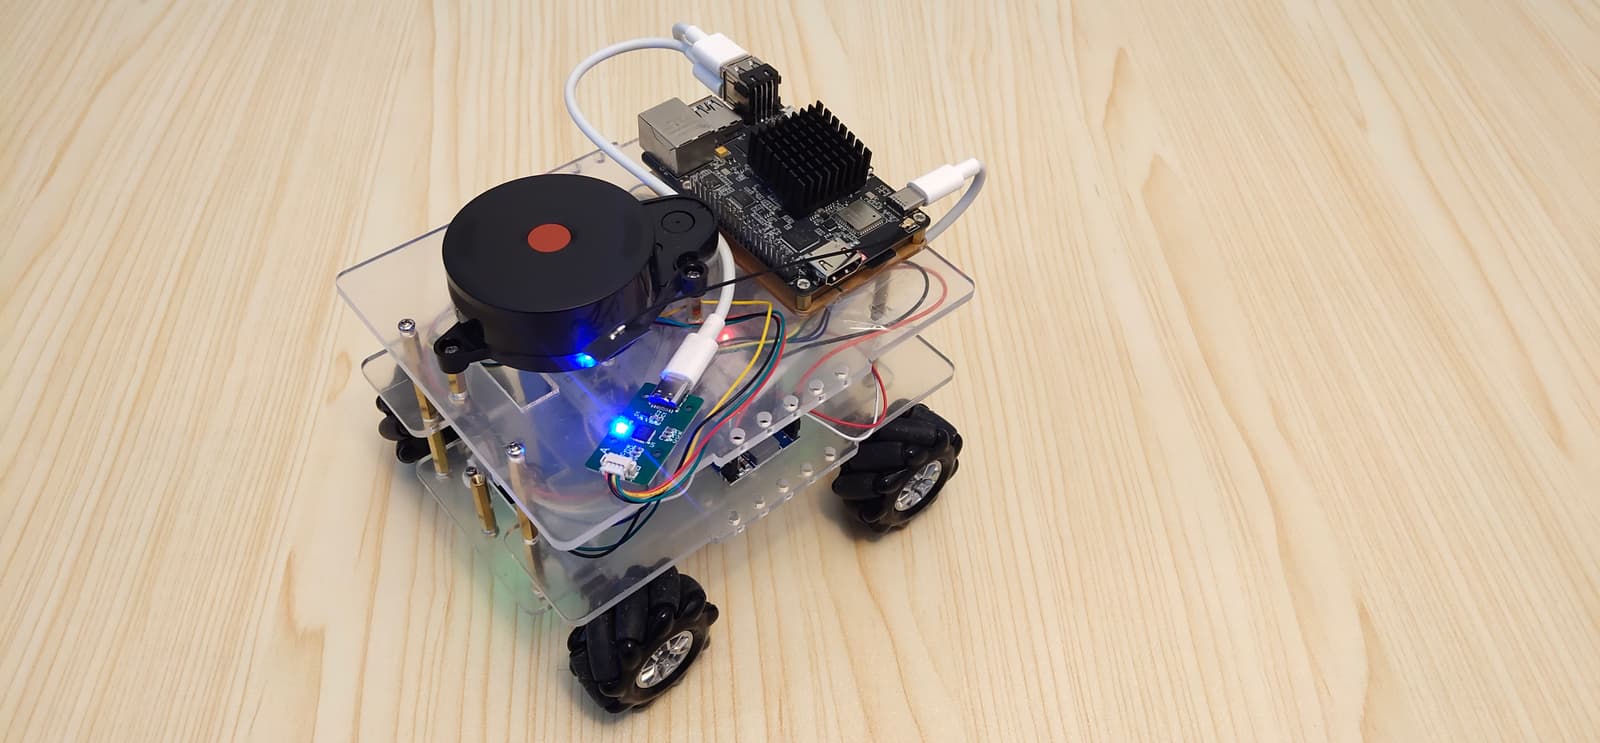
A DIY omnidirectional mobile robot that supports 2D lidar mapping and autonomous navigation using Micro-ROS and ROS2.
A low-cost, small inverted pendulum robot using DengFOC motor driver and SimpleFOC for balance control.
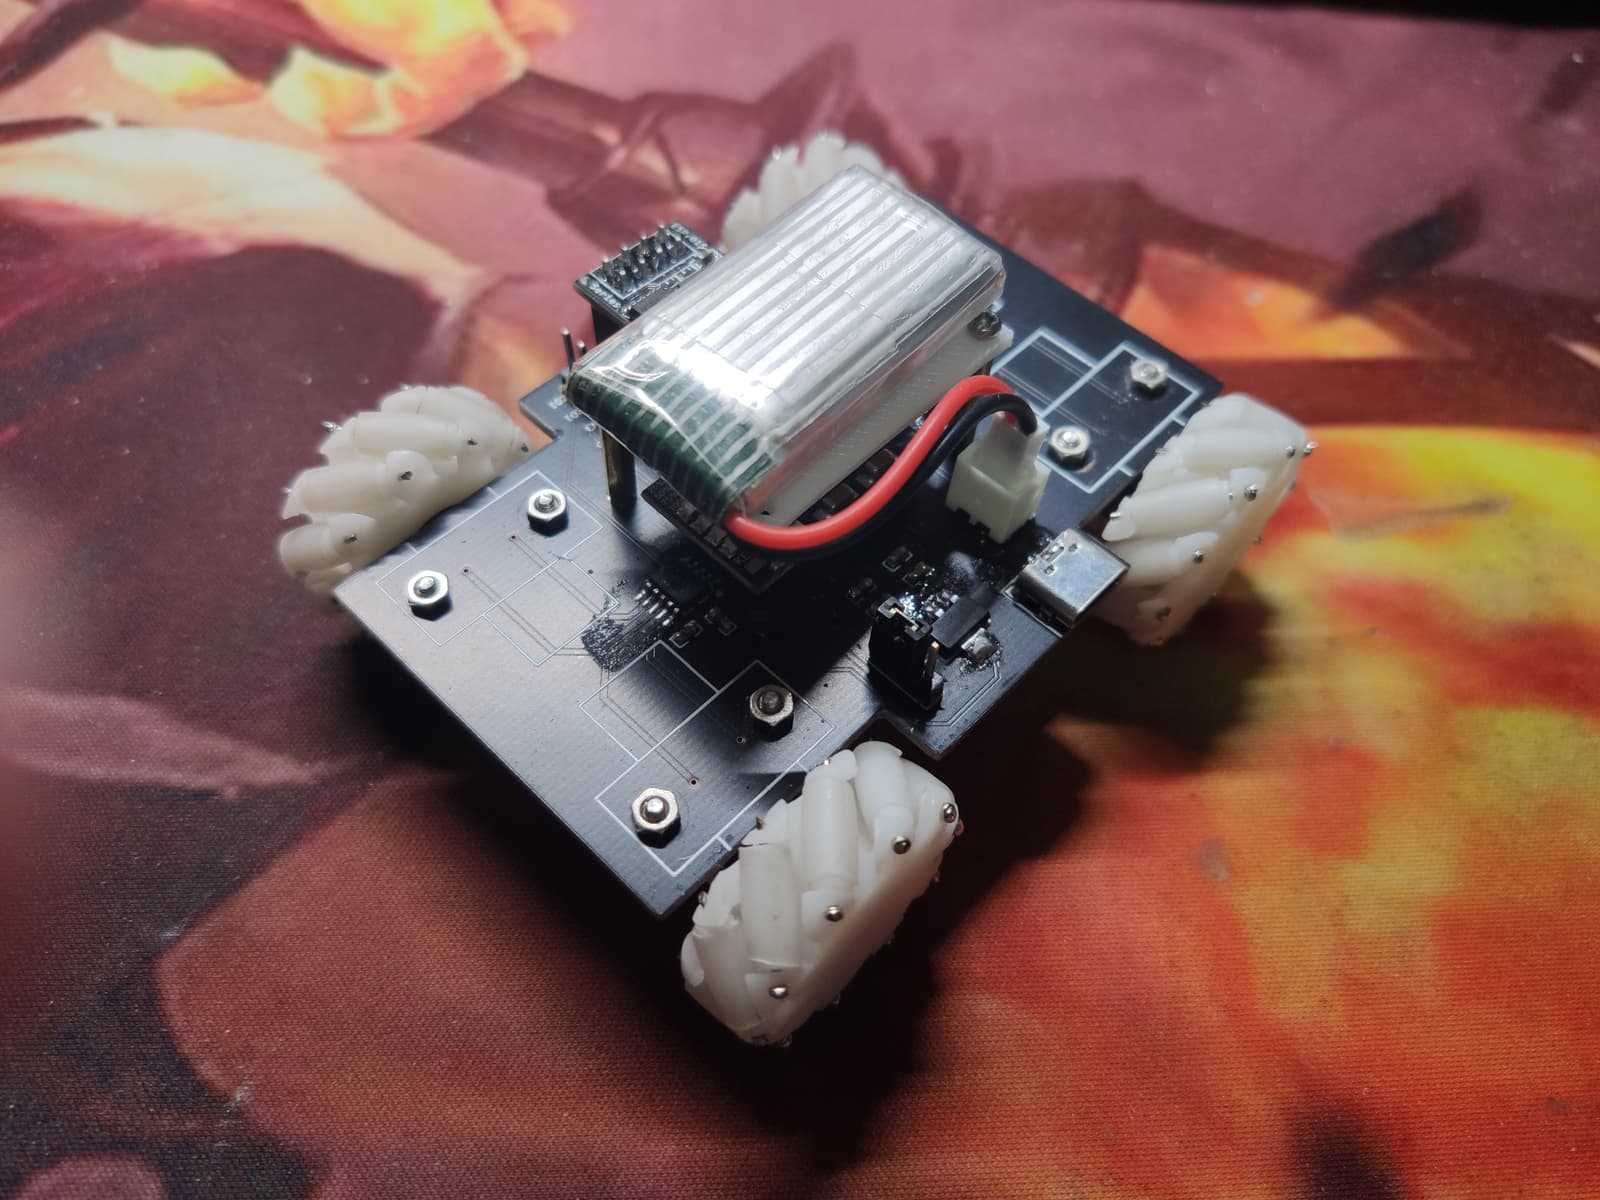
A small Mecanum-wheel car controlled via Wi-Fi using an ESP01S microcontroller.
A desktop quadruped robot based on ESP8266 with voice control, gesture recognition, web remote, and AI conversation.
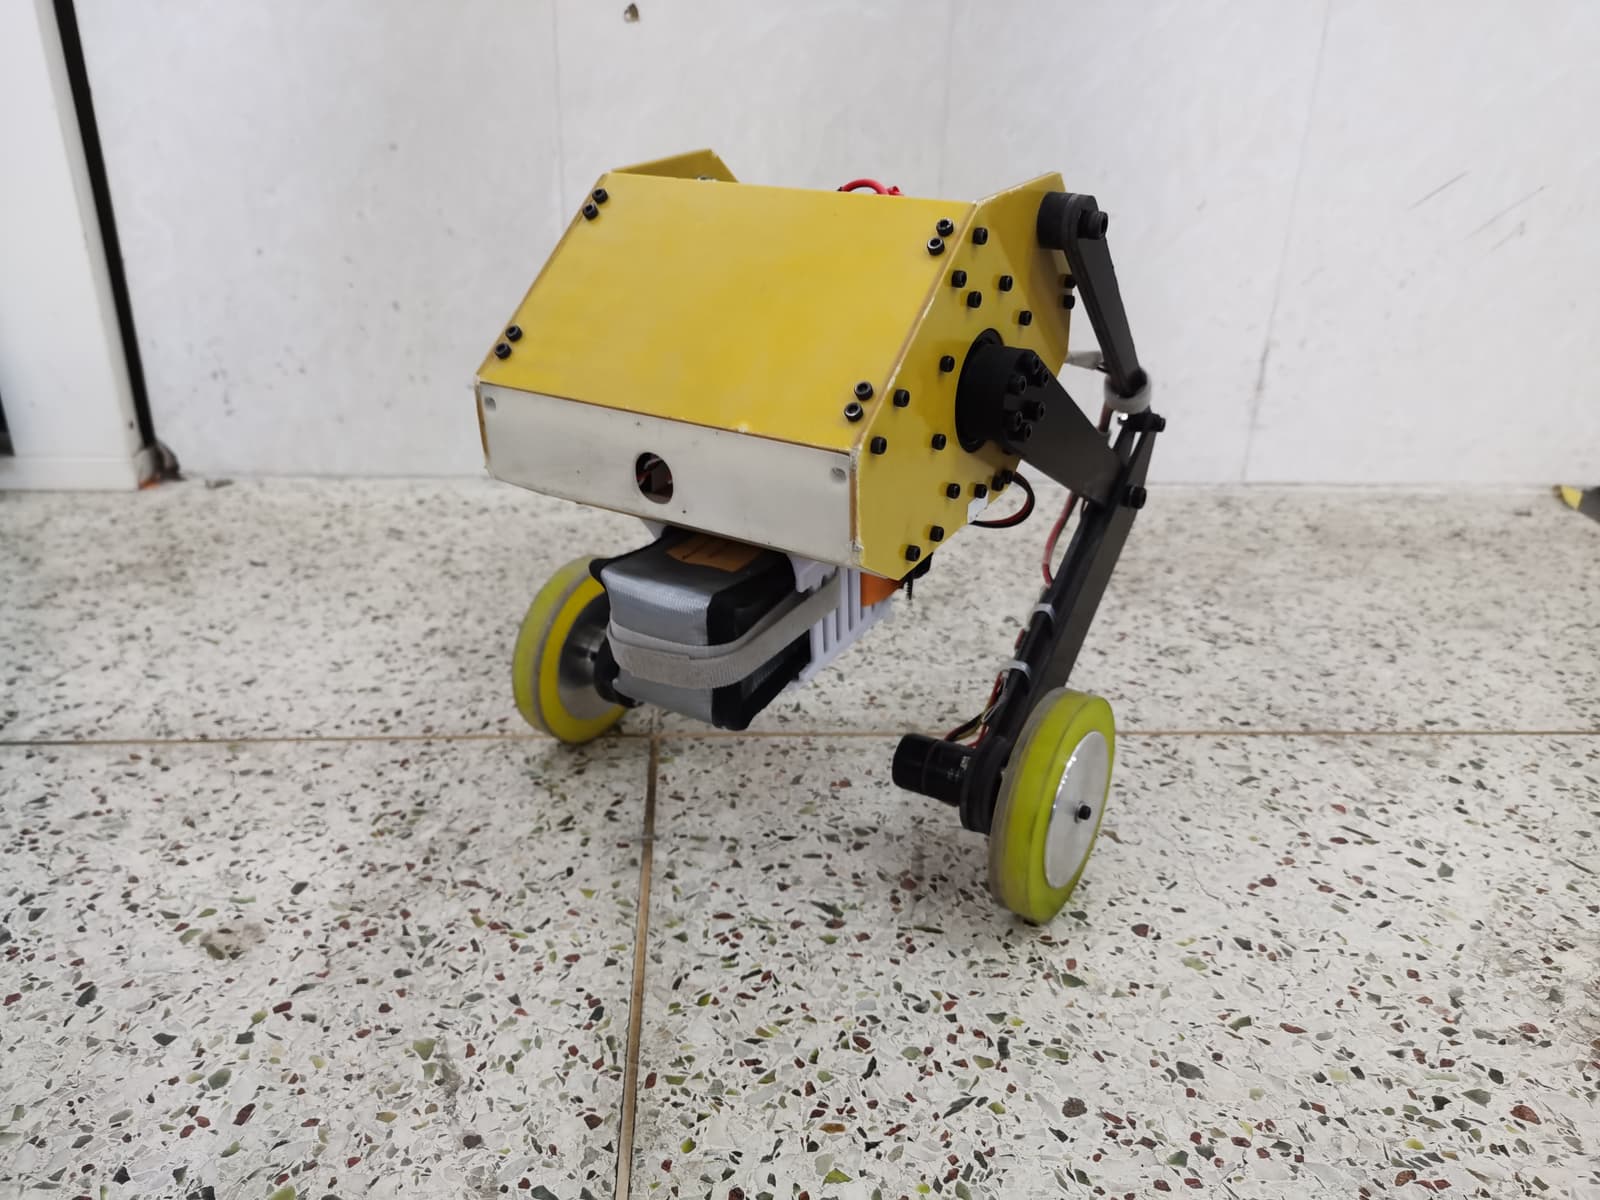
A four-link wheel-legged robot designed for adaptive center of gravity, obstacle crossing, and jumping, controlled via STM32H723 with FreeRTOS.
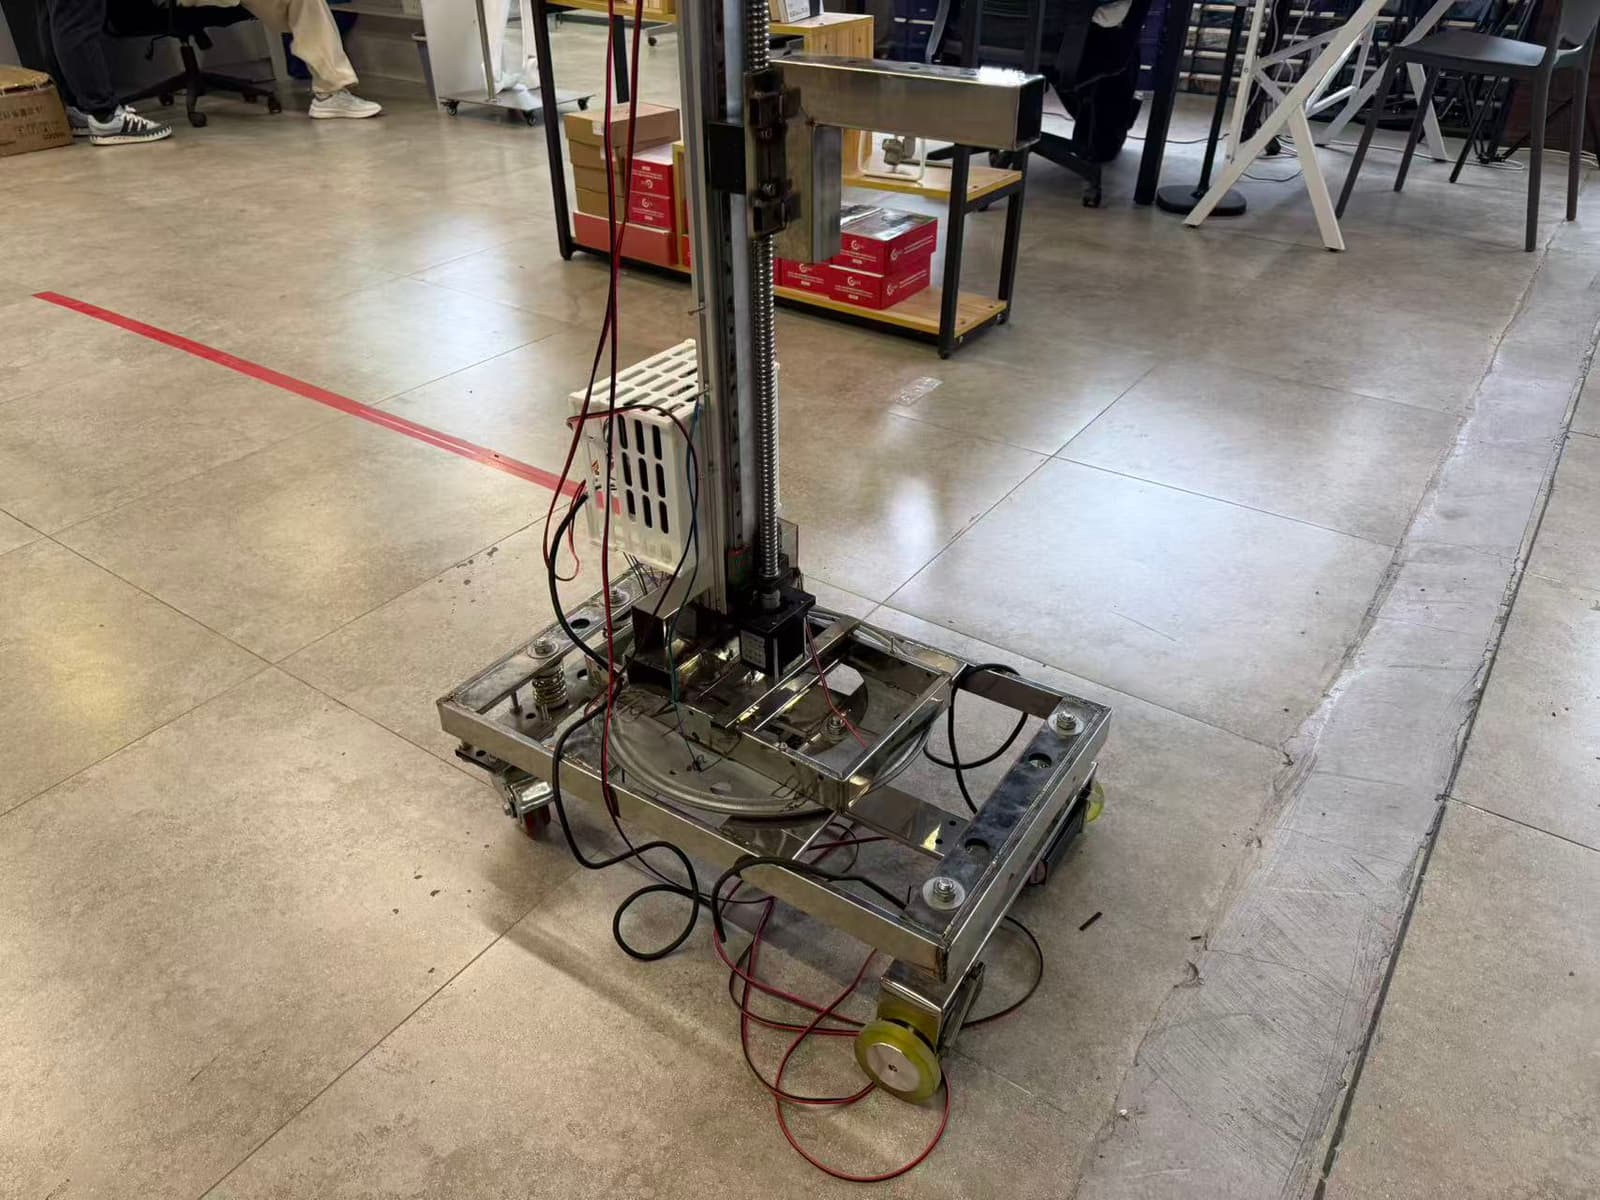
An open-source, low-cost autonomous guided vehicle (AGV) with vertical linear stage capabilities and modular expansion for robotic arm integration.
A six-legged robot powered by a Raspberry Pi Pico, featuring 18 digital servos, IMU auto-leveling, and multiple control inputs.
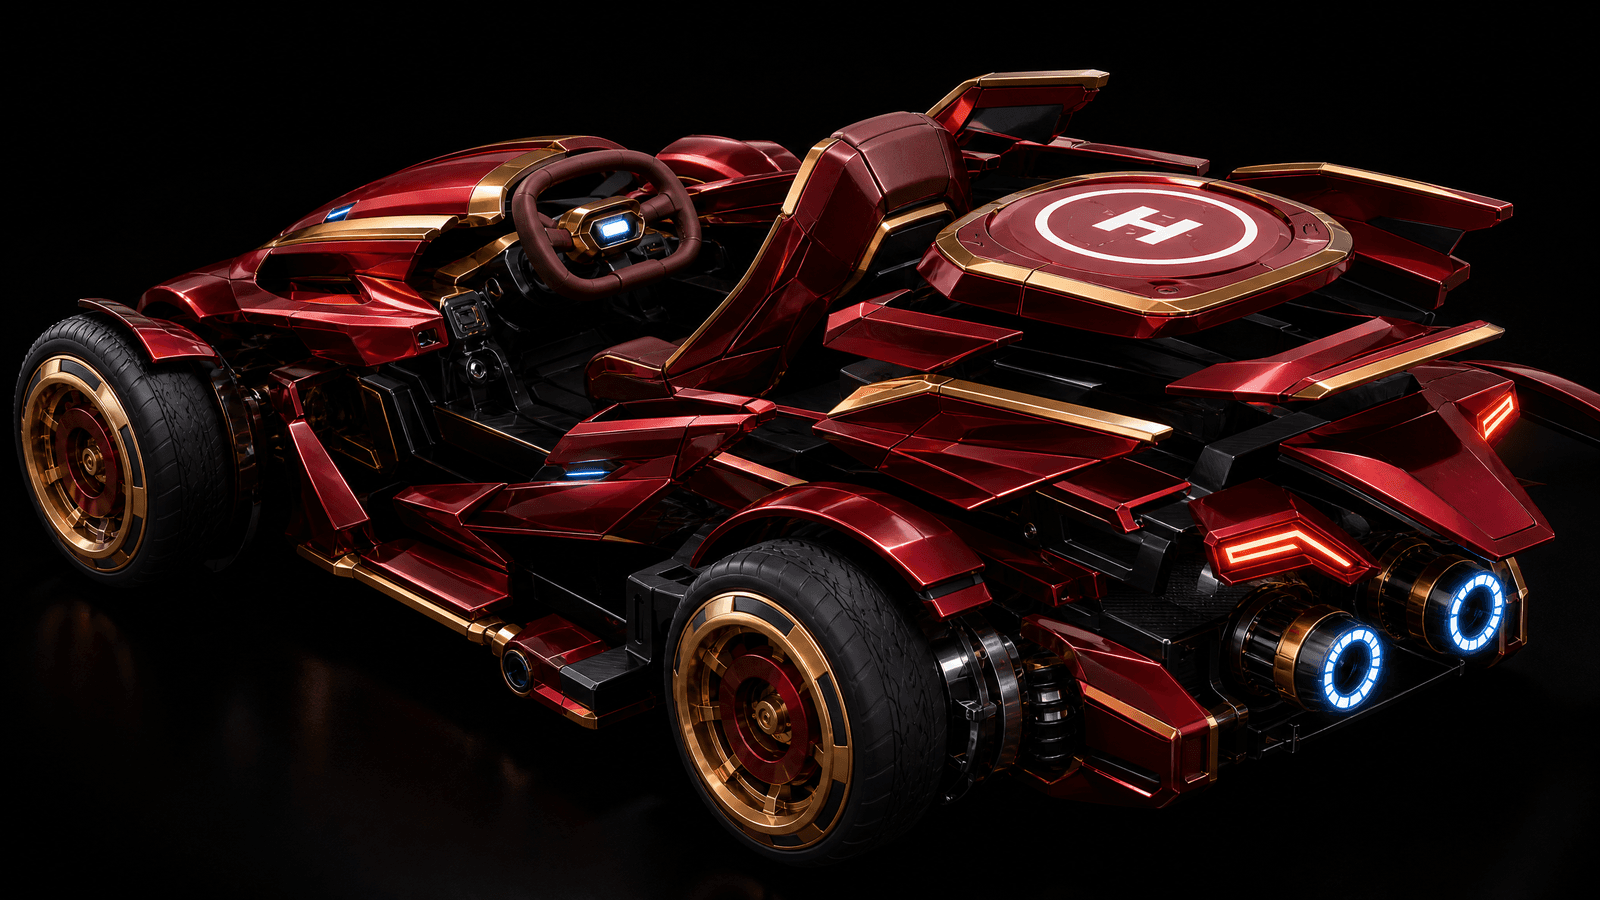
An open-source AI-powered smart children's electric car designed for parent-child co-creation and maker education.
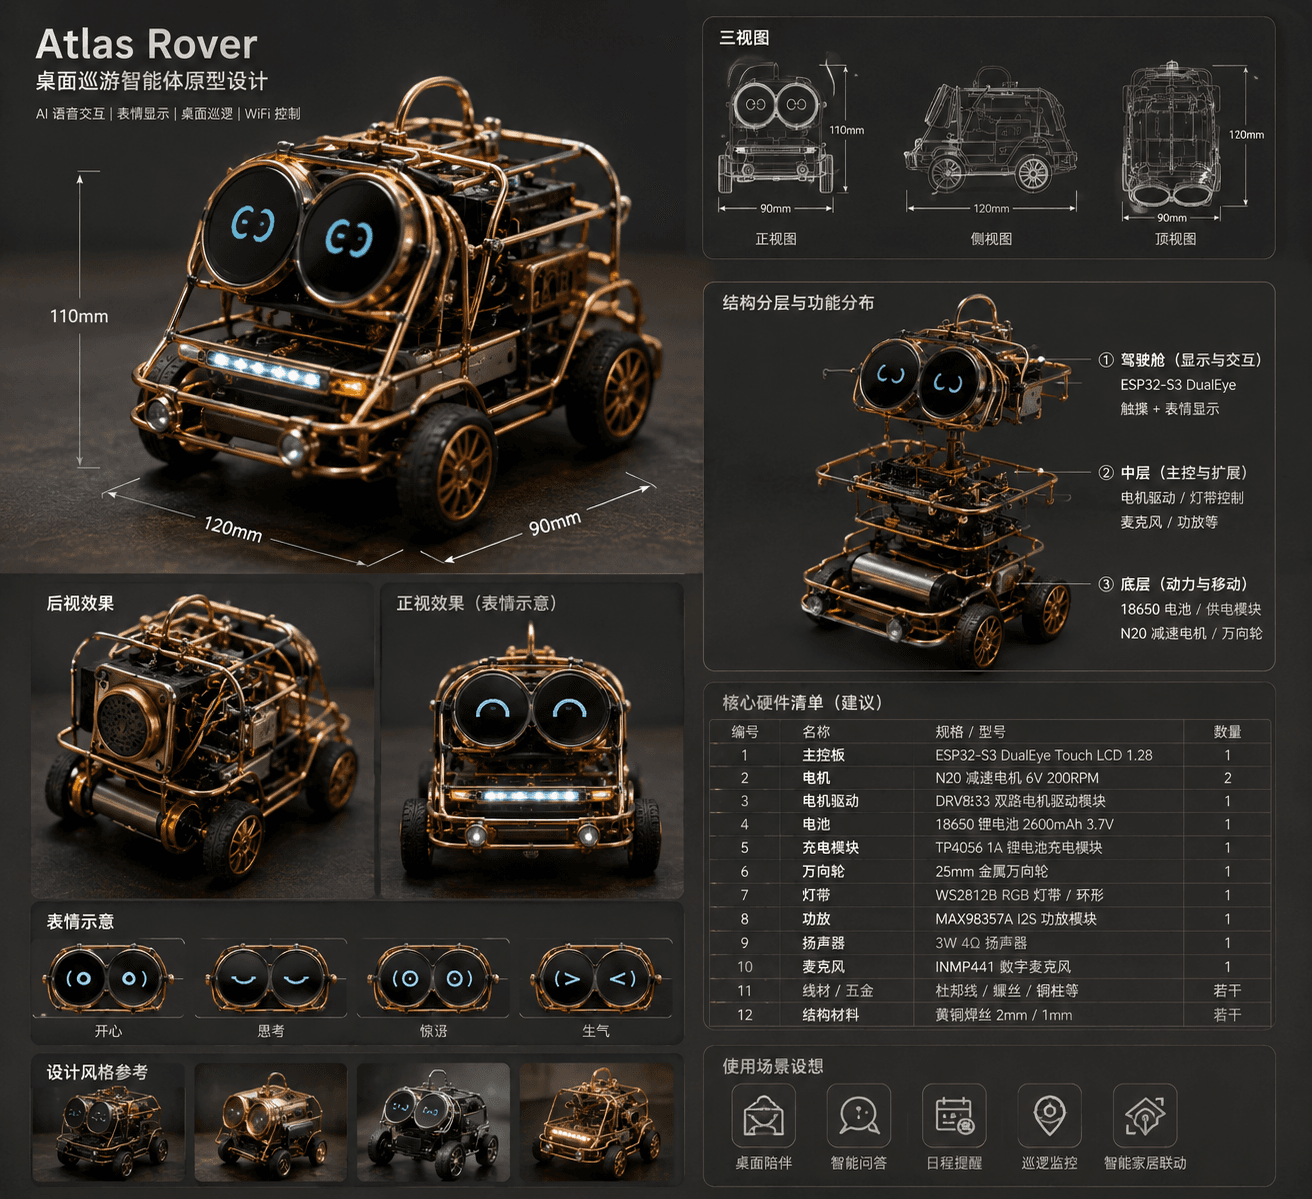
A desktop rover robot prototype with dual circular screens for facial expressions, voice interaction, and manual control.
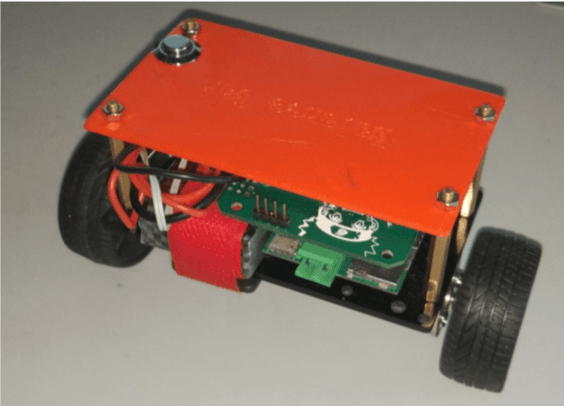
A self-balancing robot car controlled via Bluetooth with STM32 and Android support.
Robots 1–24 of 68