6-DOF Articulated Robot Arm V1
A low-cost, six-degree-of-freedom articulated robotic arm designed for education, research, and small-scale automation tasks.
- Robot arm
- Open source
- arduino
- 3D printable
Suggested by Robotheca, created by @zhangdong-cheku (opens in a new tab), from github.com/zhangdong-cheku/6-DOF_Articulated_Robot_ArmV1 (opens in a new tab). Pinned to commit d078892 (opens in a new tab).
- Hardware license
- MIT (opens in a new tab)
- Software license
- MIT (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
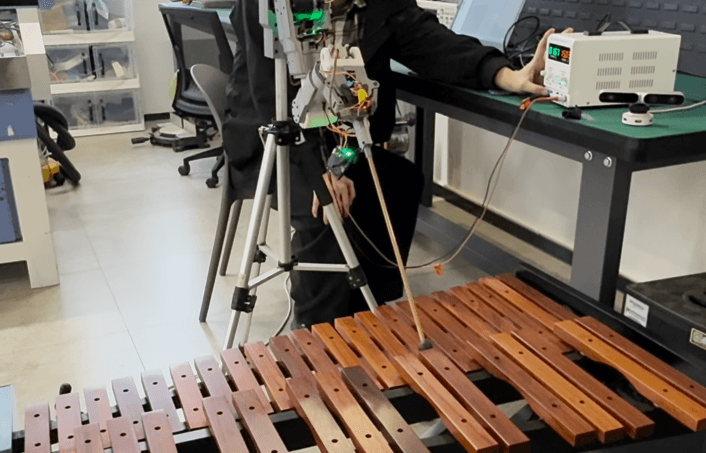
3D preview converted from github.com/zhangdong-cheku/6-DOF_Articulated_Robot_ArmV1 at d078892, under MIT. View the original files from GitHub (3.1 MB) (opens in a new tab)
- Degrees of freedom
- 6
What it can do
Written by Robotheca from the project's documents.
- Moves six joints for articulated arm motion
- Supports precise motion control
- Runs path planning for end-effector movement
- Allows custom task programming via software
- Can be extended with additional end-effectors
Bill of materials
This repository has no parts list Robotheca can read yet.
Build guide
The guide appears here as you scroll.
Guide by @zhangdong-cheku (README.md), under MIT. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- Arduino controller board
- Servo motors for six joints
- Power supply for servos and controller
Connections
- Servo motors connected to Arduino PWM pins
- Power supply wired to servos and Arduino