Robotic Arm
An open-source robotic arm controlled by an ESP32-C3 via a PCA9685 servo driver and an Xbox-compatible gamepad.
- Robot arm
- Open source
- 3D printable
Suggested by Robotheca, created by @michaelliao (opens in a new tab), from github.com/michaelliao/robotic-arm (opens in a new tab). Pinned to commit d6319f9 (opens in a new tab).
- Hardware license
- GPL-3.0-only (opens in a new tab)
- Software license
- GPL-3.0-only (opens in a new tab)
- Commercial use
- Allowed
Photo and 3D model
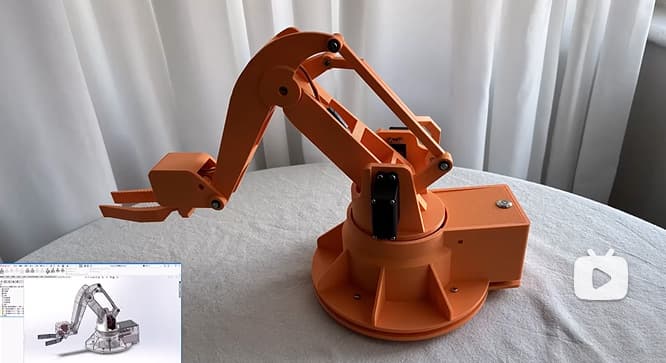
3D preview converted from github.com/michaelliao/robotic-arm at d6319f9, under GPL-3.0-only. View the original files from GitHub (6.8 MB) (opens in a new tab)
- Degrees of freedom
- 4
What it can do
Written by Robotheca from the project's documents.
- Moves four servos to position the robotic arm
- Controlled wirelessly via an Xbox-compatible gamepad
- Uses ESP32-C3 Wi-Fi, Bluetooth, and 2.4 GHz for communication
Bill of materials
30 parts30 of 30 parts shown
≈ € amounts use the ECB reference rate of 14 Oct 2026, for comparison only.
Parts total: ¥481. Read from README.md at the pinned commit.
Build guide
The creator's steps, each with its instructions.
- 1Prepare 3D printed parts
- 2Assemble mechanical structure
- 3Install bearings and screws
- 4Mount servos and electronics
- 5Connect and test control system
The guide appears here as you scroll.
Guide by @michaelliao (README.md), under GPL-3.0-only. The English translation is by Robotheca, shared under the same license.
Wiring and electronics
Notes written by Robotheca from the project's documents.
Main parts
- ESP32-C3 development board
- PCA9685 16-channel PWM servo driver board
- MG996R servos (3 units)
- MG90S servo (1 unit)
- Xbox-compatible gamepad with Bluetooth BLE 5
- 12 mm latching power switch with connector
Connections
- Servo driver board connected to ESP32-C3 via I2C bus
- Servo driver board powers servos directly
- Gamepad communicates with ESP32-C3 over Bluetooth BLE 5
Cables and connectors
From the parts list.
- 12mm自锁开关连接器 × 1
- 10cm杜邦线 × 3
